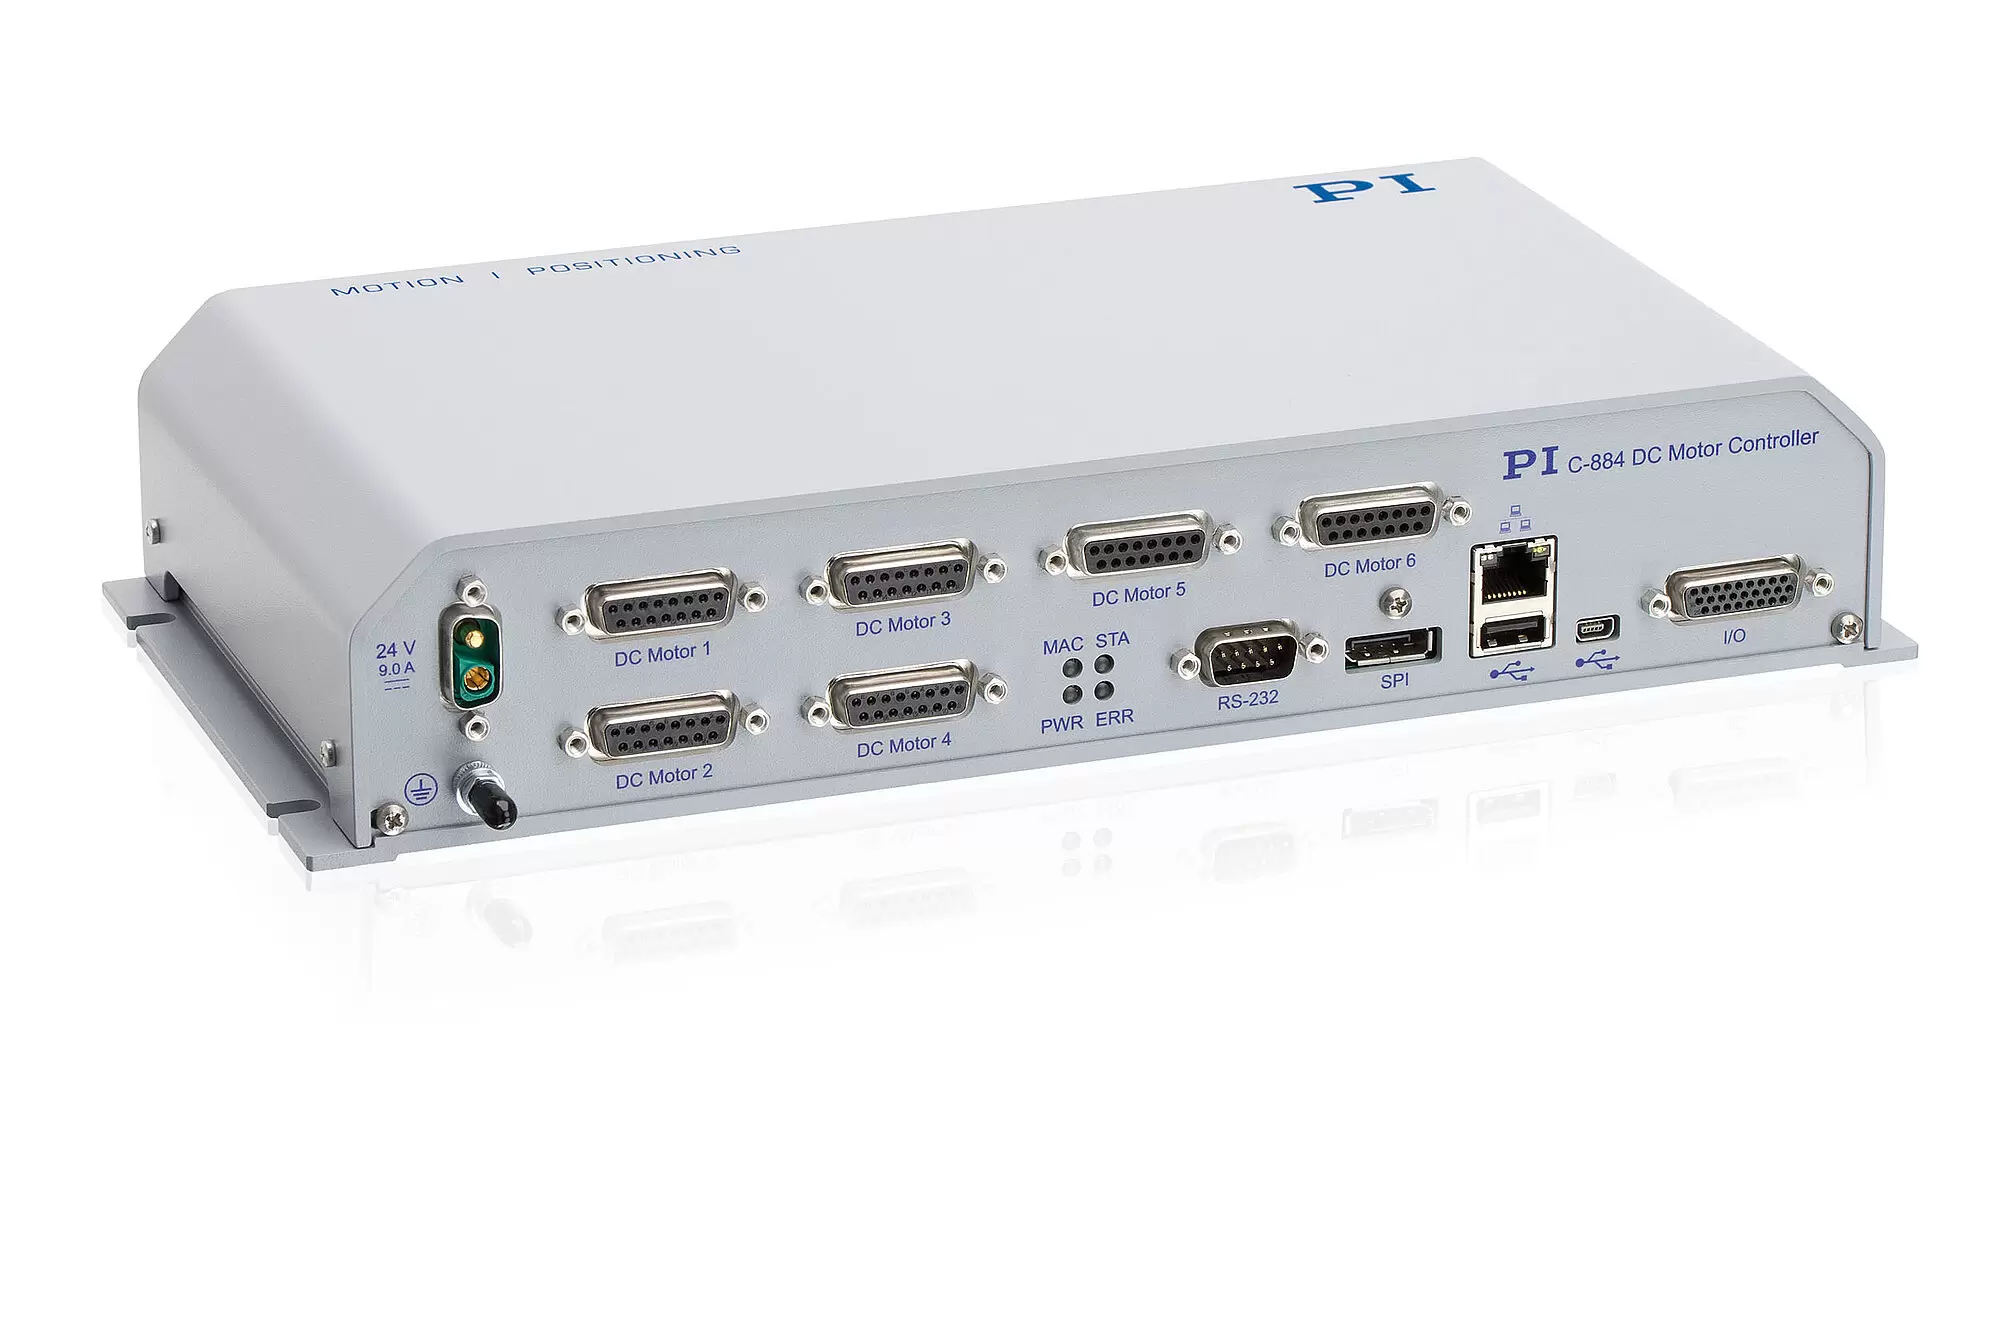
4 or 6 axes. Dual-core architecture for increased performance and flexibility by separating command processing and position control. Simple adaptation / extension possible for OEM products. Motion control of PI positioning systems with DC motors: Direct motor control, PWM control for PI positioning stages with integrated ActiveDrive amplifiers or integrated block commutation (brushless motors). Supports motor brake.
Interfaces: TCP/IP, USB and RS-232 for commands. A/B quadrature encoder input. TTL inputs for limit and reference point switches. I/O lines (analog/digital) for automation. USB interface for human interface devices.
Point-to-point, trapezoidal velocity profile. User-definable trajectories (e.g., circles, sine curves) from externally fed points.
Powerful macro command language. Nonvolatile macro storage, e.g., for stand-alone operation with autostart macro. Data recorder. ID chip detection for fast startup. PID controller, parameter changing during operation. Extensive software support, e.g., for NI LabVIEW, C, C++, MATLAB, Python. PIMikroMove user software.
C-884.4DC/C-884.6DC | |
|---|---|
Function | Position control for closed-loop DC motors |
Processor | Dual-core architecture. Controller on a DSP core, with extendable command interpreter in an ARM core under Linux |
Axes | C-884.4DC: 4 / C-884.6DC: 6 |
Supported functions | Linear vector motion. Point-to-point motion. User-definable trajectories. Startup macro. PI Python. Data recorder for recording operating data such as motor voltage, velocity, position or position error. ID chip detection. |
Motion and servo controller | C-884.4DC/C-884.6DC |
|---|---|
Controller type | PID controller, changing a parameter during operation |
Servo cycle time | 100 µs |
Profile generator | Trapezoidal velocity profile |
Encoder input | A/B quadrature (TTL differential according to RS-422), 50 MHz; BiSS interface |
Stall detection | Automatic motor stop when a programmable position error is exceeded |
Limit switches | 2 × TTL per axis (programmable polarity) |
Reference point switch | 1 × TTL per axis |
Motor brake | 1 × TTL per axis, can be switched by software |
Electrical properties | C-884.4DC/C-884.6DC |
|---|---|
Max. output voltage* | 24 V |
Max. output power | 240 W |
Current limitation | 2.5 A per axis |
Interfaces and operation | C-884.4DC/C-884.6DC |
|---|---|
Communication interfaces | TCP/IP: RJ45/Ethernet; USB: Mini-USB type B; RS-232: Sub-D 9 (m); SPI: DisplayPort |
Motor connector | Sub-D 15 (f) |
I/O lines | 4 analog inputs (-10 to 10 V), resolution: 10-bit 4 digital inputs (5 V TTL) 4 digital outputs (5 V TTL) |
Command set | PI General Command Set (GCS) |
User software | PIMikroMove |
Application programming interfaces | API for C / C++ / C# / VB.NET / MATLAB / Python, drivers for NI LabVIEW |
Manual control | USB interface for HID-compliant devices |
Miscellaneous | C-884.4DC/C-884.6DC |
|---|---|
Operating voltage | External power adapter 24 V / 5 A (120 W) in the scope of delivery |
Max. current consumption | C-884.4DC: 11 A / C-884.6DC: 16 A |
Current consumption without load | 500 mA |
Operating temperature range | 5 to 50 °C |
Mass | C-884.4DC: 1.77 kg / C-884.6DC: 1.97 kg |
Dimensions | 312 mm × 153.4 mm × 59.2 mm (incl. mounting rails) |
* The output voltage depends on the connected power supply.