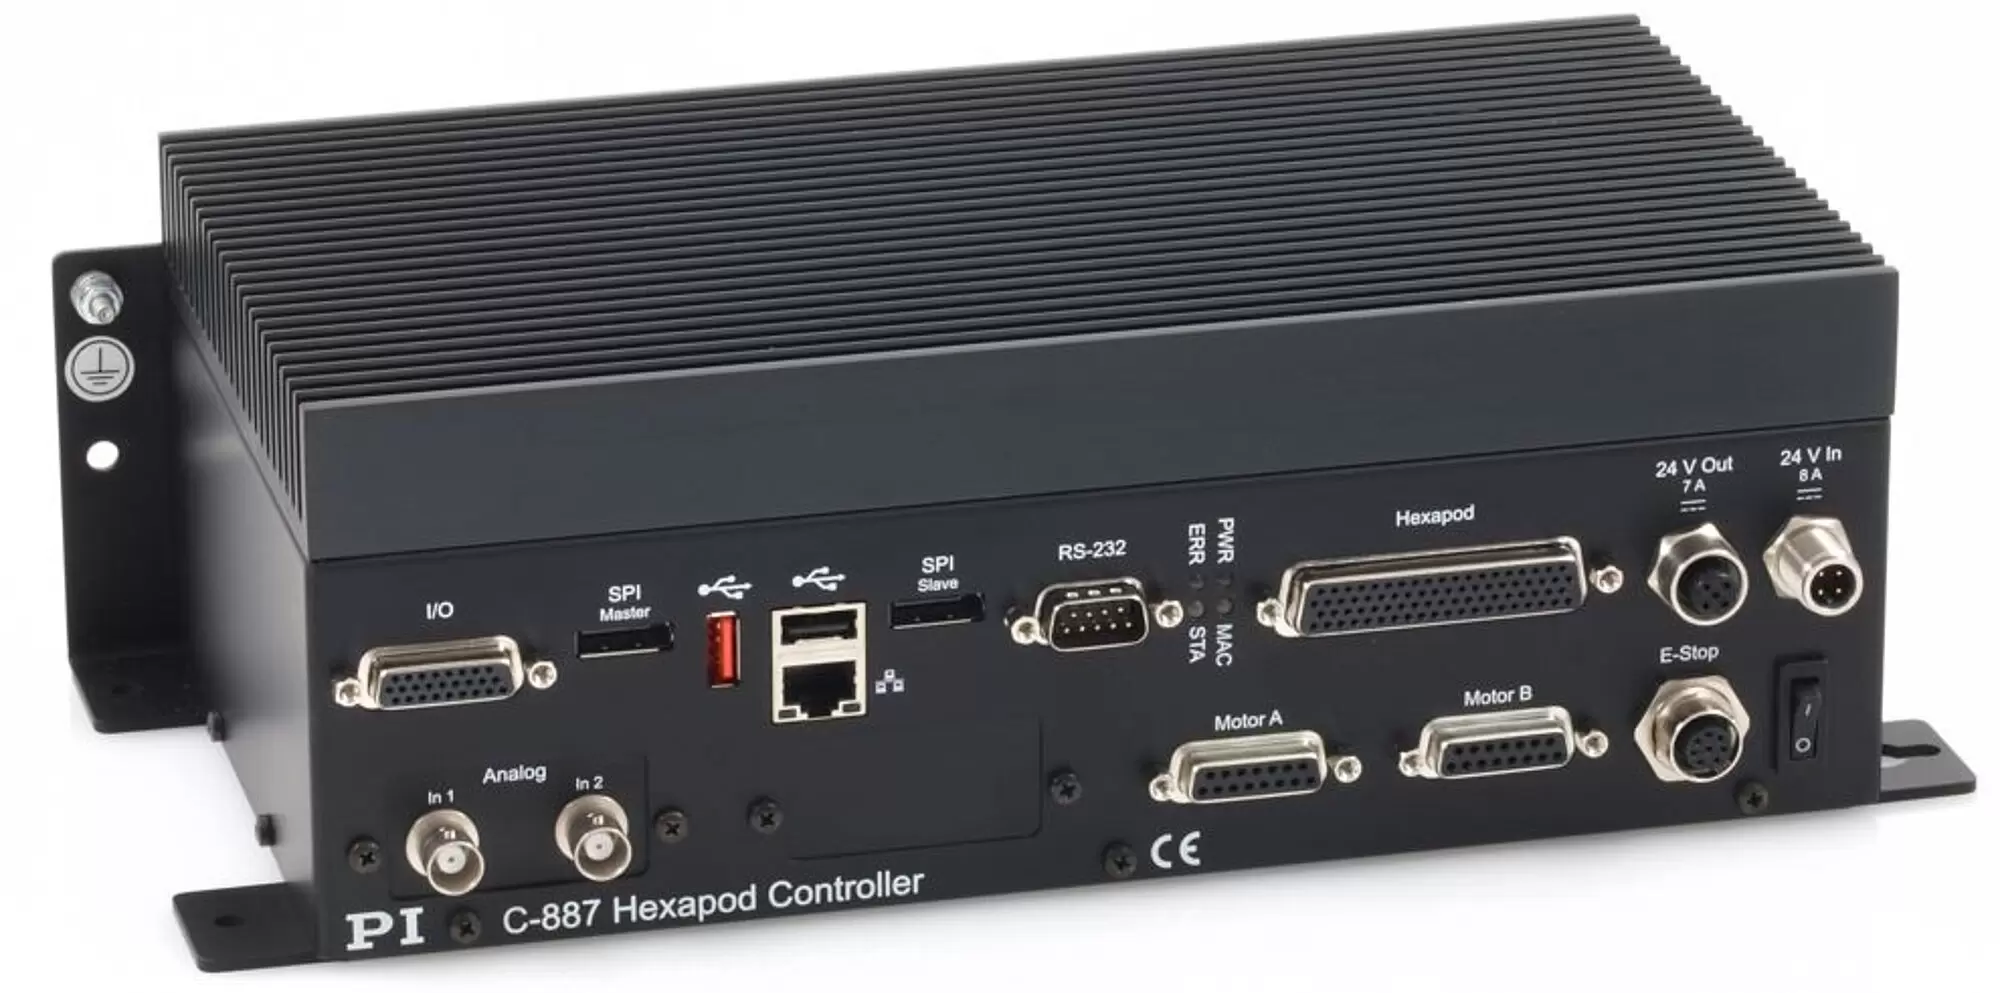
High-performance digital controller for controlling hexapods (6-axis parallel kinematics). Supports various drive types as the controller only provides the control signals, whereas the motor drivers are located in the hexapod or in a separate driver box. In addition, the motor drivers for two further single axes can be controlled.
The position is entered in Cartesian coordinates from which the controller calculates the control of the kinematics. To simplify integration of the hexapod, the coordinate systems (Work, Tool) can be changed. The pivot point can be freely defined. A data recorder can record operating data, e.g., motor control, velocity, position, or position error. The execution of macros and Python scripts on the controller enables stand-alone operation. The controller supports all currently available standard hexapods from PI and, in addition, customer-specific parallel kinematics.
TCP/IP for network-based control and maintenance. RS-232. USB port for manual control unit.
For example, PIMikroMove user software enables fast alignment routines to be depicted graphically. GCS 2.0 command set for PI positioning systems. Extensive set of drivers, e.g., for use with NI LabVIEW, MATLAB, and Python. PIHexapodEmulator for virtual startup and operation without hardware.
The scope of delivery includes the controller, a software package, and a power adapter for the power supply. It is recommended to order the hexapod mechanics and a suitable cable set together with the controller so that the components can be adapted to each other.
| Basics | C-887.52 | C-887.521 | C-887.522 | C-887.523 | |
|---|---|---|---|---|---|
| Axes/channels | 6 | 6 | 6 | 6 | |
| Additional axes | 2 single axes | 2 single axes | 2 single axes | 2 single axes | |
| Processor | Intel Atom dual core (1.8 GHz) | Intel Atom dual core (1.8 GHz) | Intel Atom dual core (1.8 GHz) | Intel Atom dual core (1.8 GHz) | |
| Application-related functions | Controller macros GCS, Controller macros PIPython, Data recorder, Scan procedures, Startup macro | Controller macros GCS, Controller macros PIPython, Data recorder, Fast alignment, Scan procedures, Startup macro | Controller macros GCS, Controller macros PIPython, Data recorder, Scan procedures, Startup macro | Controller macros GCS, Controller macros PIPython, Data recorder, Fast alignment, Scan procedures, Startup macro | |
| ID chip detection | ID chip 2.0 | ID chip 2.0 | ID chip 2.0 | ID chip 2.0 | |
| Configuration management | reading the ID chip, manual parameter input | reading the ID chip, manual parameter input | reading the ID chip, manual parameter input | reading the ID chip, manual parameter input | |
| Protective functions | Switch-off via an external switch | Switch-off via an external switch | |||
| Motion and Servo Controller | C-887.52 | C-887.521 | C-887.522 | C-887.523 | |
| Supported sensor signal | A/B quadrature, RS-422 BiSS-C | A/B quadrature, RS-422 BiSS-C | A/B quadrature, RS-422 BiSS-C | A/B quadrature, RS-422 BiSS-C | |
| Closed-loop values | Position | Position | Position | Position | |
| Maximum control frequency (servo cycle) | 10000 Hz | 10000 Hz | 10000 Hz | 10000 Hz | |
| Motion types | Point-to-point motion with profile generator, Cyclic transfer of target positions, Area scan routines, Gradient search routines, Wave generator | Point-to-point motion with profile generator, Cyclic transfer of target positions, Area scan routines, Gradient search routines, Wave generator | Point-to-point motion with profile generator, Cyclic transfer of target positions, Area scan routines, Gradient search routines, Wave generator | Point-to-point motion with profile generator, Cyclic transfer of target positions, Area scan routines, Gradient search routines, Wave generator | |
| Motion coordination | Coordinated multi-axis motion, User-defined coordinate systems, Work-and-tool coordinate systems | Coordinated multi-axis motion, User-defined coordinate systems, Work-and-tool coordinate systems | Coordinated multi-axis motion, User-defined coordinate systems, Work-and-tool coordinate systems | Coordinated multi-axis motion, User-defined coordinate systems, Work-and-tool coordinate systems | |
| Reference switch input | TTL | TTL | TTL | TTL | |
| Limit switch input | TTL | TTL | TTL | TTL | |
| Interfaces and Operation | C-887.52 | C-887.521 | C-887.522 | C-887.523 | |
| Communication interfaces | RS-232, TCP/IP, USB (only for manual control units) | RS-232, TCP/IP, USB (only for manual control units) | RS-232, TCP/IP, USB (only for manual control units) | RS-232, TCP/IP, USB (only for manual control units) | |
| On/off switch | Hardware switch on/off | Hardware switch on/off | Hardware switch on/off | Hardware switch on/off | |
| Display and indicators | Status LED, Error LED, Power LED, Macro LED | Status LED, Error LED, Power LED, Macro LED | Status LED, Error LED, Power LED, Macro LED | Status LED, Error LED, Power LED, Macro LED | |
| Manual control(s) | Manual control unit with USB interface | Manual control unit with USB interface | Manual control unit with USB interface | Manual control unit with USB interface | |
| Command set | GCS 2.0 | GCS 2.0 | GCS 2.0 | GCS 2.0 | |
| User software | PIMikroMove | PIMikroMove | PIMikroMove | PIMikroMove | |
| Software - APIs | MATLAB, NI LabView, Python | MATLAB, NI LabView, Python | MATLAB, NI LabView, Python | MATLAB, NI LabView, Python | |
| Analog input signal | 4 x -10 to 10 V, 12 bit | 2 x -5 to 5 V, 16 bit, 5 kHz bandwidth; 4 x -10 to 10 V, 12 bit | 4 x -10 to 10 V, 12 bit | 2 x -5 to 5 V, 16 bit, 5 kHz bandwidth; 4 x -10 to 10 V, 12 bit | |
| Digital inputs | 4 | 4 | 4 | 4 | |
| Digital input signal | TTL | TTL | TTL | TTL | |
| Digital outputs | 4 | 4 | 4 | 4 | |
| Digital output signal | TTL | TTL | TTL | TTL | |
| Motion-dependent inputs and outputs | Digital trigger input, Digital trigger output, Analog sensor input | Digital trigger input, Digital trigger output, Analog sensor input | Digital trigger input, Digital trigger output, Analog sensor input | Digital trigger input, Digital trigger output, Analog sensor input | |
| Electrical Properties | C-887.52 | C-887.521 | C-887.522 | C-887.523 | |
| Output voltage | 24 V | 24 V | 24 V | 24 V | |
| Peak output current | 7000 mA | 7000 mA | 7000 mA | 7000 mA | |
| Miscellaneous | C-887.52 | C-887.521 | C-887.522 | C-887.523 | |
| Connector hexapod power supply | M12 4-pole (f) | M12 4-pole (f) | M12 4-pole (f) | M12 4-pole (f) | |
| Connector hexapod data transmission | HD D-sub 78 (f) | HD D-sub 78 (f) | HD D-sub 78 (f) | HD D-sub 78 (f) | |
| Connector additional axes | D-sub 15 (f) | D-sub 15 (f) | D-sub 15 (f) | D-sub 15 (f) | |
| Connector analog input | HD D-sub 26 (f) | BNC HD D-sub 26 (f) | HD D-sub 26 (f) | BNC HD D-sub 26 (f) | |
| Connector digital input | HD D-sub 26 (f) | HD D-sub 26 (f) | HD D-sub 26 (f) | HD D-sub 26 (f) | |
| Connector digital output | HD D-sub 26 (f) | HD D-sub 26 (f) | HD D-sub 26 (f) | HD D-sub 26 (f) | |
| Connector TCP/IP | RJ45 socket, 8P8C | RJ45 socket, 8P8C | RJ45 socket, 8P8C | RJ45 socket, 8P8C | |
| Connector RS-232 | D-sub 9 (m) | D-sub 9 (m) | D-sub 9 (m) | D-sub 9 (m) | |
| Connector for supply voltage | M12 4-pin (m) | M12 4-pin (m) | M12 4-pin (m) | M12 4-pin (m) | |
| Operating voltage | 24 V (ext. power adapter included) | 24 V (ext. power adapter included) | 24 V (ext. power adapter included) | 24 V (ext. power adapter included) | |
| Maximum current consumption | 8 A | 8 A | 8 A | 8 A | |
| Operating temperature range | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | |
| Overall mass | 2800 g | 2800 g | 2800 g | 2800 g |