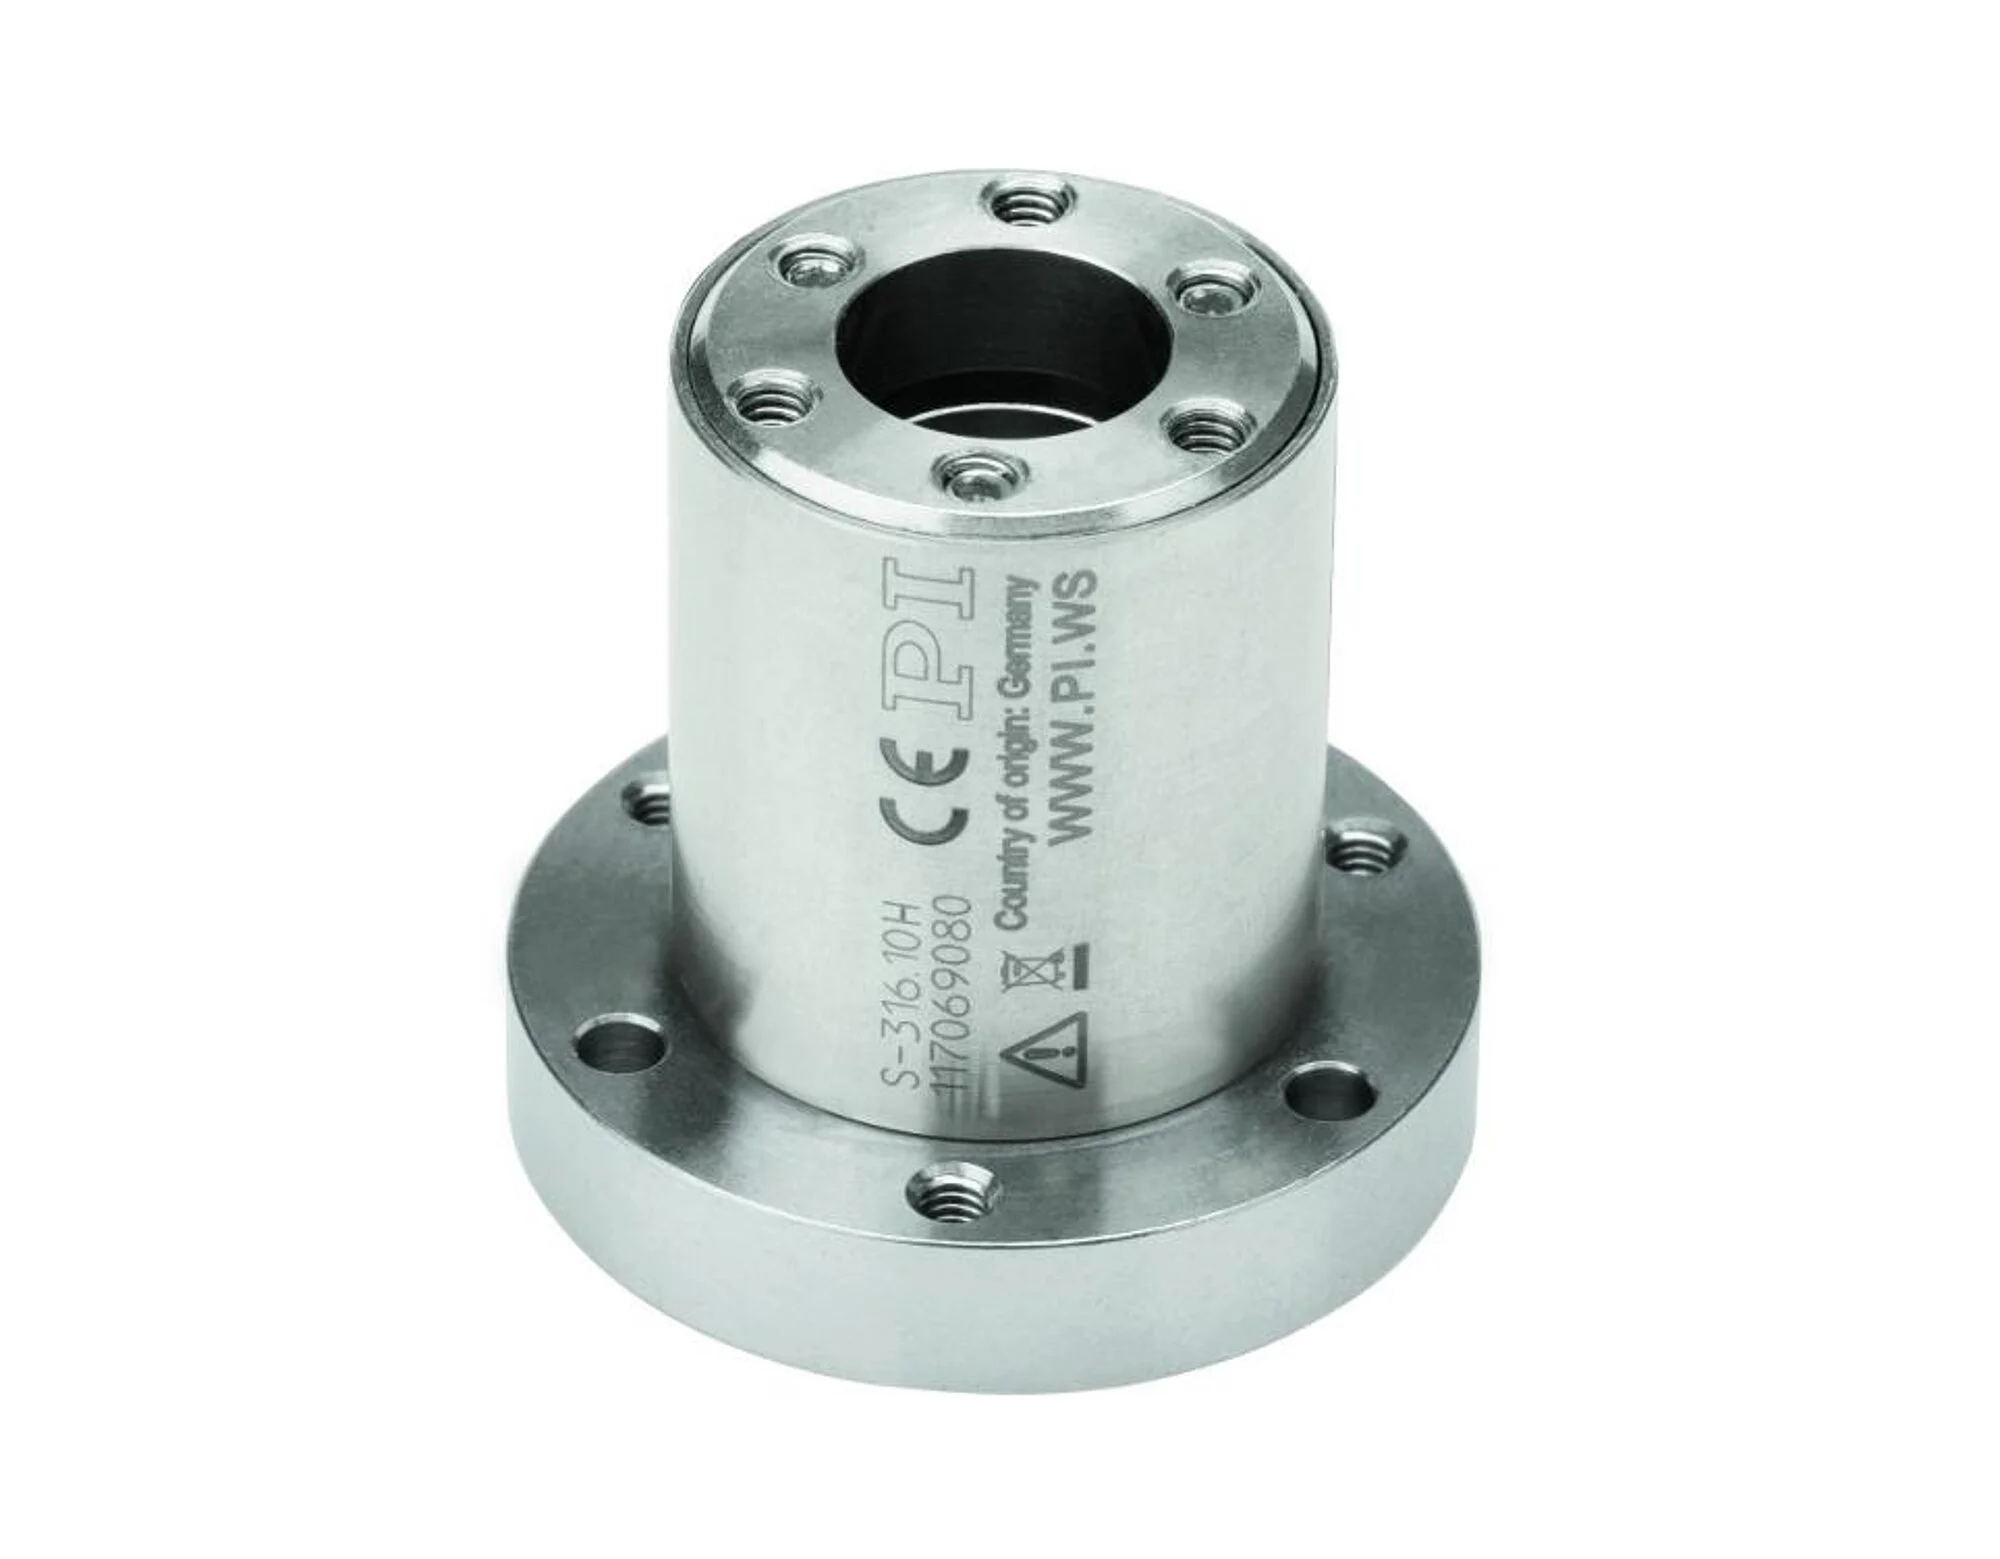
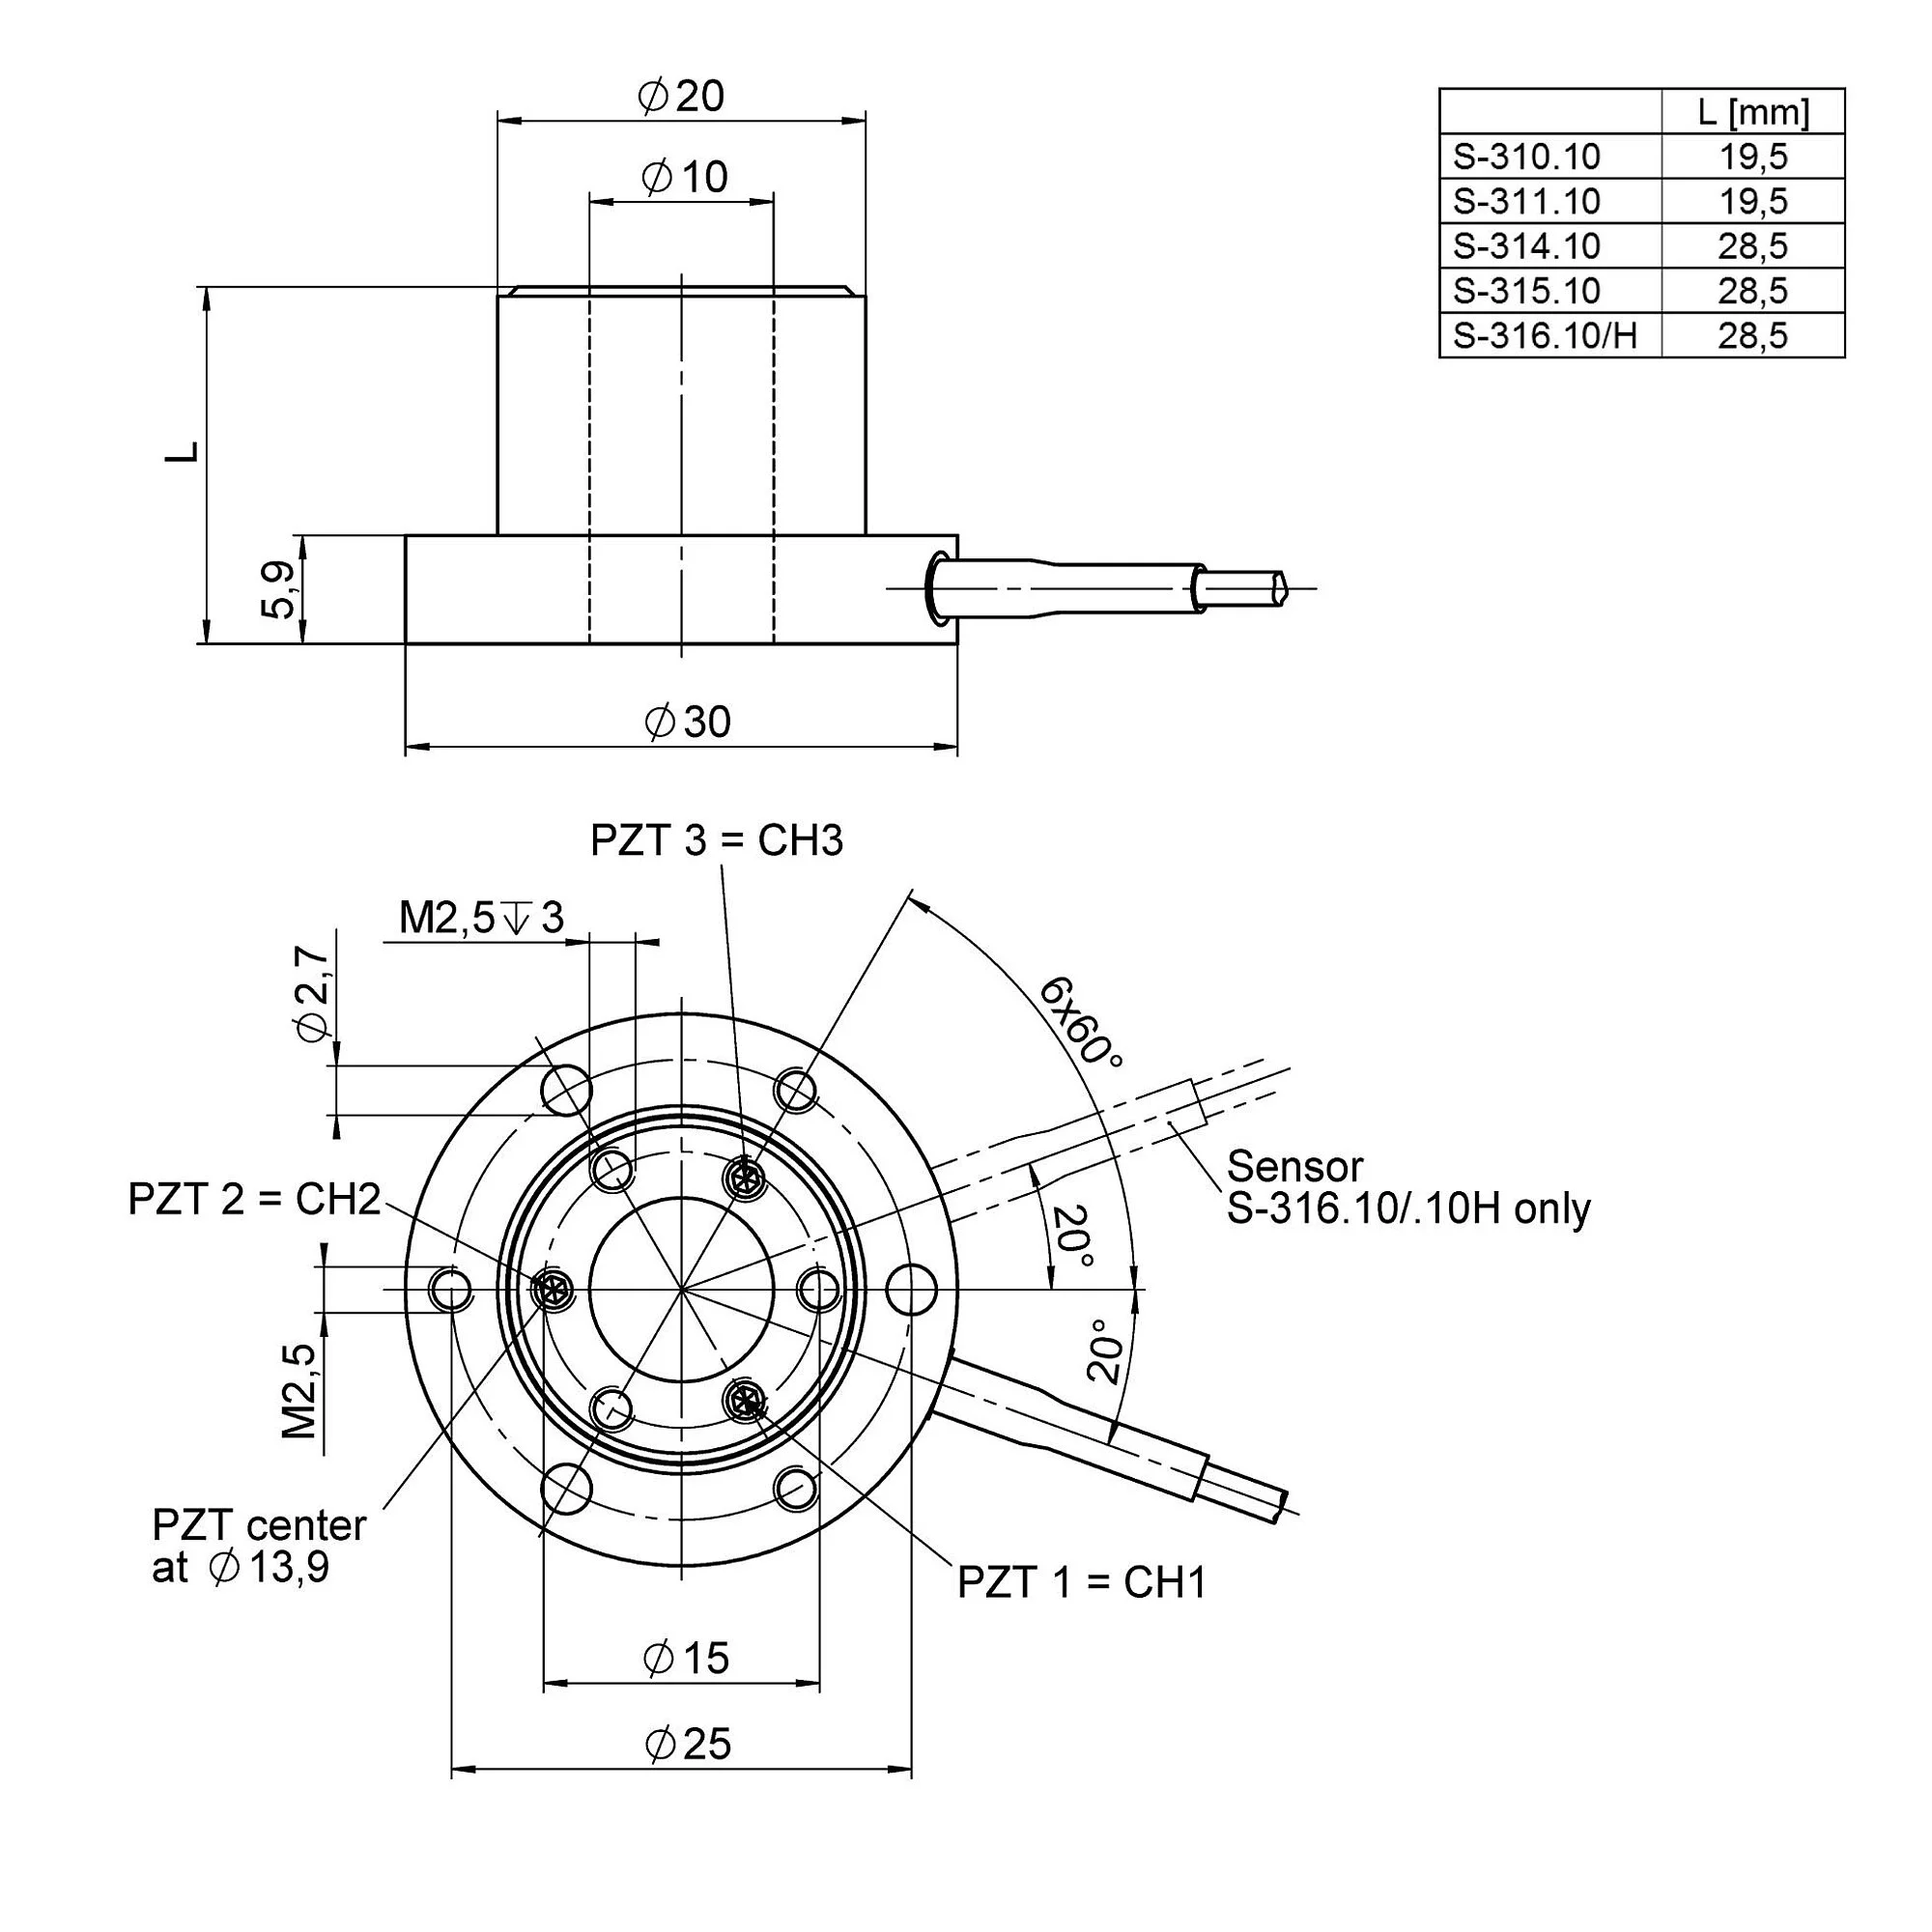
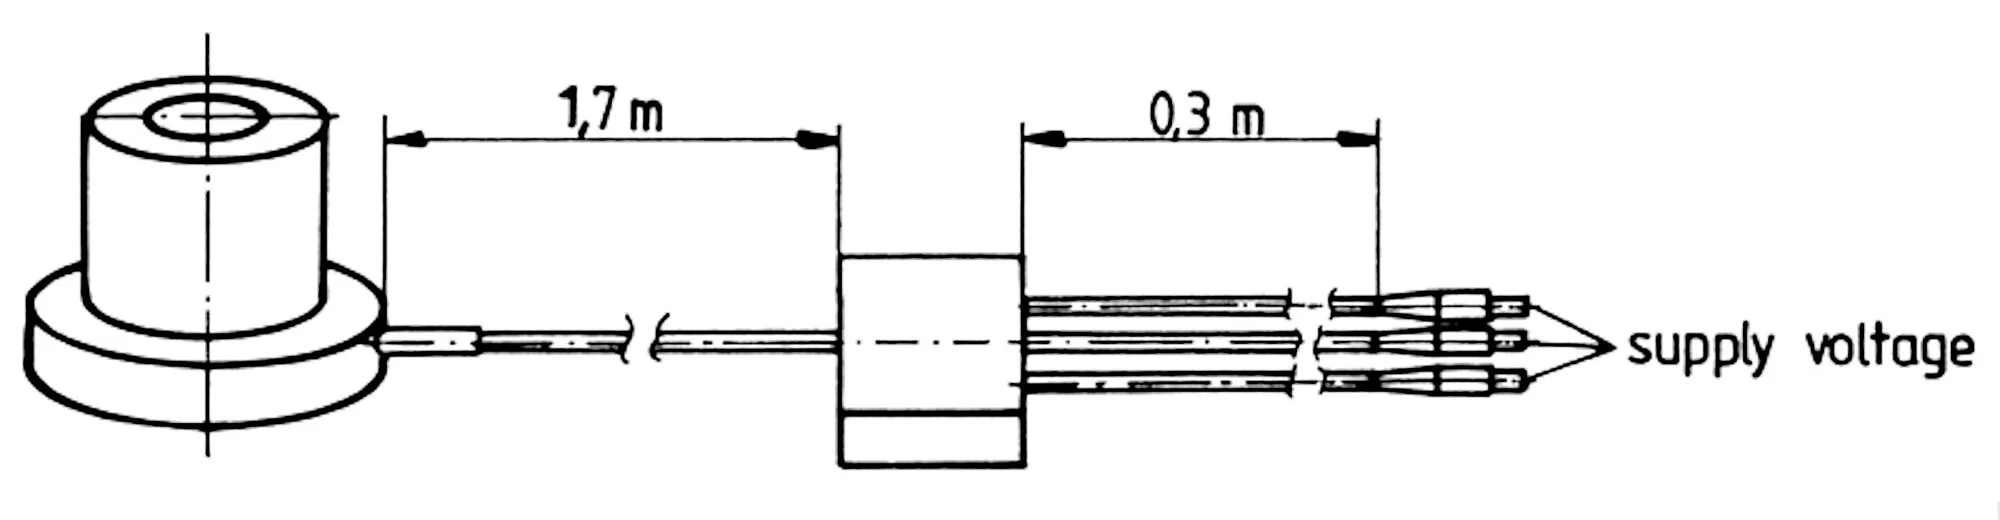
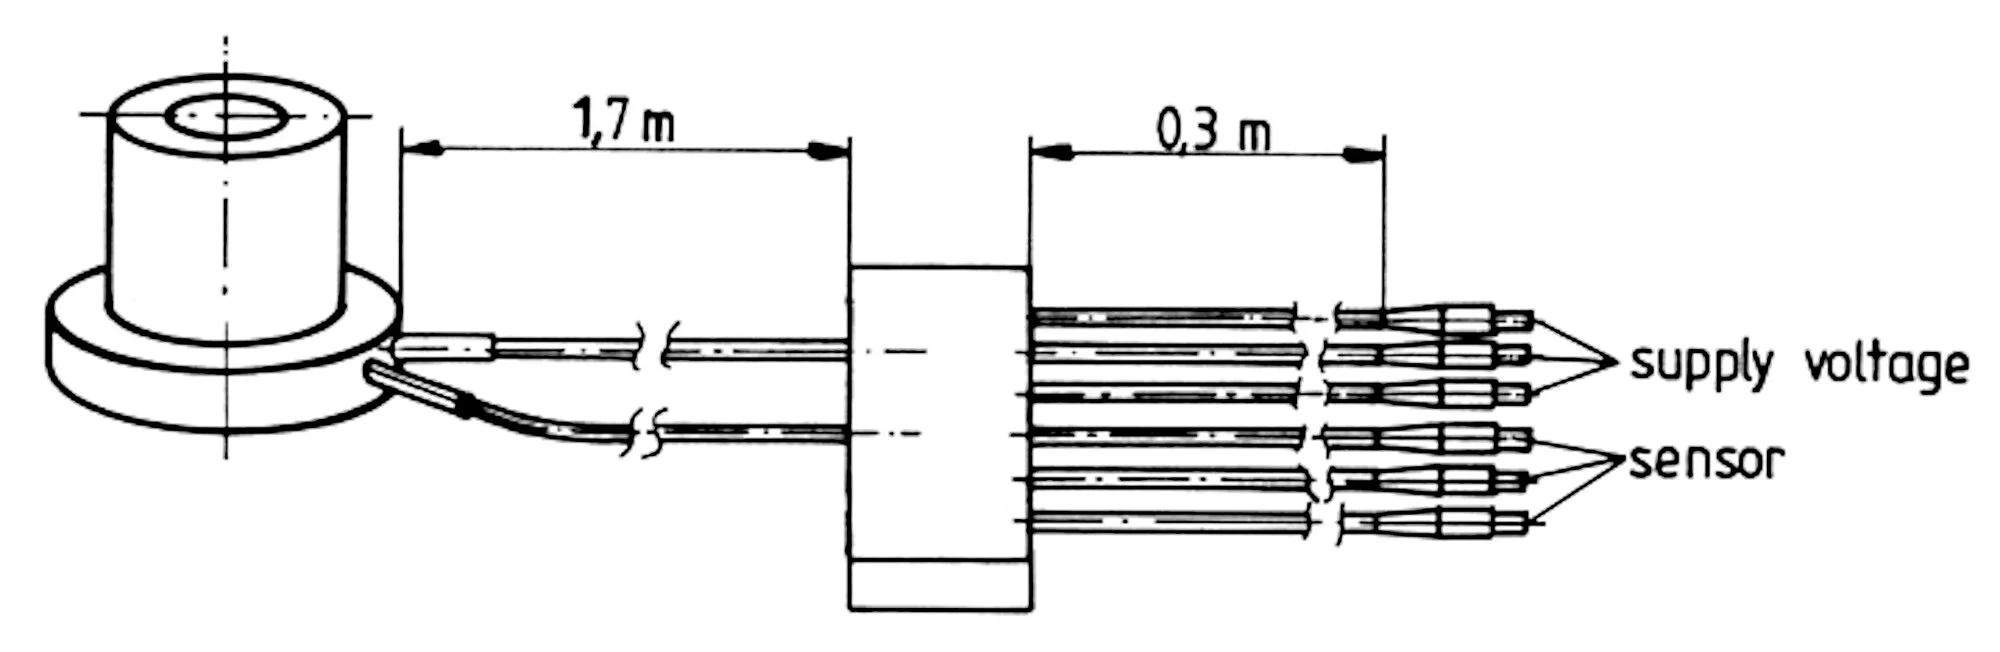
The patented PICMA® piezo actuators are all-ceramic insulated. This protects them against humidity and failure resulting from an increase in leakage current. PICMA® actuators offer an up to ten times longer lifetime than conventional polymer-insulated actuators. 100 billion cycles without a single failure are proven.
Flexure guides are free of maintenance, friction, and wear, and do not require lubrication. Their stiffness allows high load capacity and they are insensitive to shock and vibration. They work in a wide temperature range.
Mechanics and controllers can be combined as required and exchanged quickly. All servo and linearization parameters are stored in the ID chip of the D-sub connector of the mechanics. The autocalibration function of the digital controllers uses this data each time the controller is switched on.
In a parallel-kinematic multi-axis system, all actuators act on a common platform. The minimum mass inertia and the identical design of all axes allow fast, dynamic, and nevertheless precision motion.
| Motion | S-310.10 | S-314.10 | S-311.10 | S-315.10 | S-316.10 | S-316.10H | Tolerance |
|---|---|---|---|---|---|---|---|
| Active axes | Z | Z | Z θX θY | Z θX θY | Z θX θY | Z θX θY | |
| Travel range in Z, open loop | 6 µm | 12 µm | 6 µm | 12 µm | 12 µm | 12 µm | +20 / -0 % |
| Rotation range in θX, open loop | 600 µrad | 1200 µrad | 1200 µrad | 1200 µrad | +20 / -0 % | ||
| Rotation range in θY, open loop | 600 µrad | 1200 µrad | 1200 µrad | 1200 µrad | +20 / -0 % | ||
| Travel range in Z | 12 µm | 12 µm | |||||
| Rotation range in θX | 1200 µrad | 1200 µrad | |||||
| Rotation range in θY | 1200 µrad | 1200 µrad | |||||
| Linearity error in Z | 0.2 % | 0.2 % | typ. | ||||
| Linearity error in θX | 0.2 % | 0.2 % | typ. | ||||
| Linearity error in θY | 0.2 % | 0.2 % | typ. | ||||
| Positioning | S-310.10 | S-314.10 | S-311.10 | S-315.10 | S-316.10 | S-316.10H | Tolerance |
| Resolution in Z, open loop | 0.1 nm | 0.2 nm | 0.1 nm | 0.2 nm | 0.2 nm | 0.2 nm | typ. |
| Resolution in θX, open loop | 0.02 µrad | 0.05 µrad | 0.05 µrad | 0.05 µrad | typ. | ||
| Resolution in θY, open loop | 0.02 µrad | 0.05 µrad | 0.05 µrad | 0.05 µrad | typ. | ||
| Integrated sensor | SGS, indirect position measuring | SGS, indirect position measuring | |||||
| System resolution in Z | 0.4 nm | 0.4 nm | |||||
| System resolution in θX | 0.1 µrad | 0.1 µrad | |||||
| System resolution in θY | 0.1 µrad | 0.1 µrad | |||||
| Drive Properties | S-310.10 | S-314.10 | S-311.10 | S-315.10 | S-316.10 | S-316.10H | Tolerance |
| Drive type | PICMA® | PICMA® | PICMA® | PICMA® | PICMA® | PICMA® | |
| Electrical capacitance in Z | 0.39 µF | 0.93 µF | 0.13 µF | 0.31 µF | 0.31 µF | 0.31 µF | ±20 % |
| Electrical capacitance in θX | 0.13 µF | 0.31 µF | 0.31 µF | 0.31 µF | ±20 % | ||
| Electrical capacitance in θY | 0.13 µF | 0.31 µF | 0.31 µF | 0.31 µF | ±20 % | ||
| Mechanical Properties | S-310.10 | S-314.10 | S-311.10 | S-315.10 | S-316.10 | S-316.10H | Tolerance |
| Guide | Flexure guide with lever amplification | Flexure guide with lever amplification | Flexure guide with lever amplification | Flexure guide with lever amplification | Flexure guide with lever amplification | Flexure guide with lever amplification | |
| Stiffness in Z | 20 N/µm | 10 N/µm | 20 N/µm | 10 N/µm | 10 N/µm | 10 N/µm | ±20 % |
| Resonant frequency in Z, unloaded | 9.5 kHz | 5.5 kHz | 9.5 kHz | 5.5 kHz | 5.5 kHz | 5.5 kHz | ±20 % |
| Resonant frequency in Z, under load with glass mirror (Ø 15 mm; thickness 4 mm) | 6.5 kHz | 4.4 kHz | 6.5 kHz | 4.1 kHz | 4.1 kHz | 4.1 kHz | ±20 % |
| Resonant frequency in Z, under load with glass mirror (Ø 20 mm; thickness 4 mm) | 6.1 kHz | 4.2 kHz | 6.1 kHz | 3.4 kHz | 3.4 kHz | 3.4 kHz | ±20 % |
| Overall mass | 53 g | 55 g | 45 g | 55 g | 55 g | 55 g | ±5 % |
| Material | Steel | Steel | Steel | Steel | Steel | Steel | |
| Distance of pivot point to platform surface | 5 mm | 5 mm | 5 mm | 5 mm | ±0,5 mm | ||
| Resonant frequency in X, under load with glass mirror (Ø 15 mm; thickness 4 mm) | 6.5 kHz | 4.1 kHz | 4.1 kHz | 4.1 kHz | ±20 % | ||
| Resonant frequency in X, under load with glass mirror (Ø 20 mm; thickness 4 mm) | 6.1 kHz | 3.4 kHz | 3.4 kHz | 3.4 kHz | ±20 % | ||
| Moved mass in Z, unloaded | 150 g | 150 g | |||||
| Moment of inertia in θX, unloaded | 150 g·mm² | 150 g·mm² | 150 g·mm² | 150 g·mm² | ±20 % | ||
| Moment of inertia in θY, unloaded | 150 g·mm² | 150 g·mm² | 150 g·mm² | 150 g·mm² | ±20 % | ||
| Miscellaneous | S-310.10 | S-314.10 | S-311.10 | S-315.10 | S-316.10 | S-316.10H | Tolerance |
| Operating temperature range | -20 to 80 °C | -20 to 80 °C | -20 to 80 °C | -20 to 80 °C | -20 to 80 °C | -20 to 80 °C | |
| Connector | LEMO LVPZT | LEMO LVPZT | LEMO LVPZT | LEMO LVPZT | LEMO LVPZT | D-sub 37-pin (m) | |
| Cable length | 2 m | 2 m | 2 m | 2 m | 2 m | 2 m | +100 / -0 mm |
| Recommended controllers / drivers | E-505, E-610 | E-505, E-610 | E-503, E-505, E-610 | E-503, E-505, E-610 | E-503, E-505, E-509, E-610, E-625 | E-727 | |
| Sensor connector | LEMO for strain gauge sensors |
The resolution of the system is limited only by the noise of the amplifier and the measuring technology because PI piezo nanopositioning systems are free of friction.
Mechanical tilt, optical beam deflection is twice as large. For maximum tilt range, all three piezo actuators must be biased at 50 V. Due to the parallel-kinematics design, linear travel and tip/tilt angle are interdependent. The specified values are the maximum for pure linear respectively tilt motion.