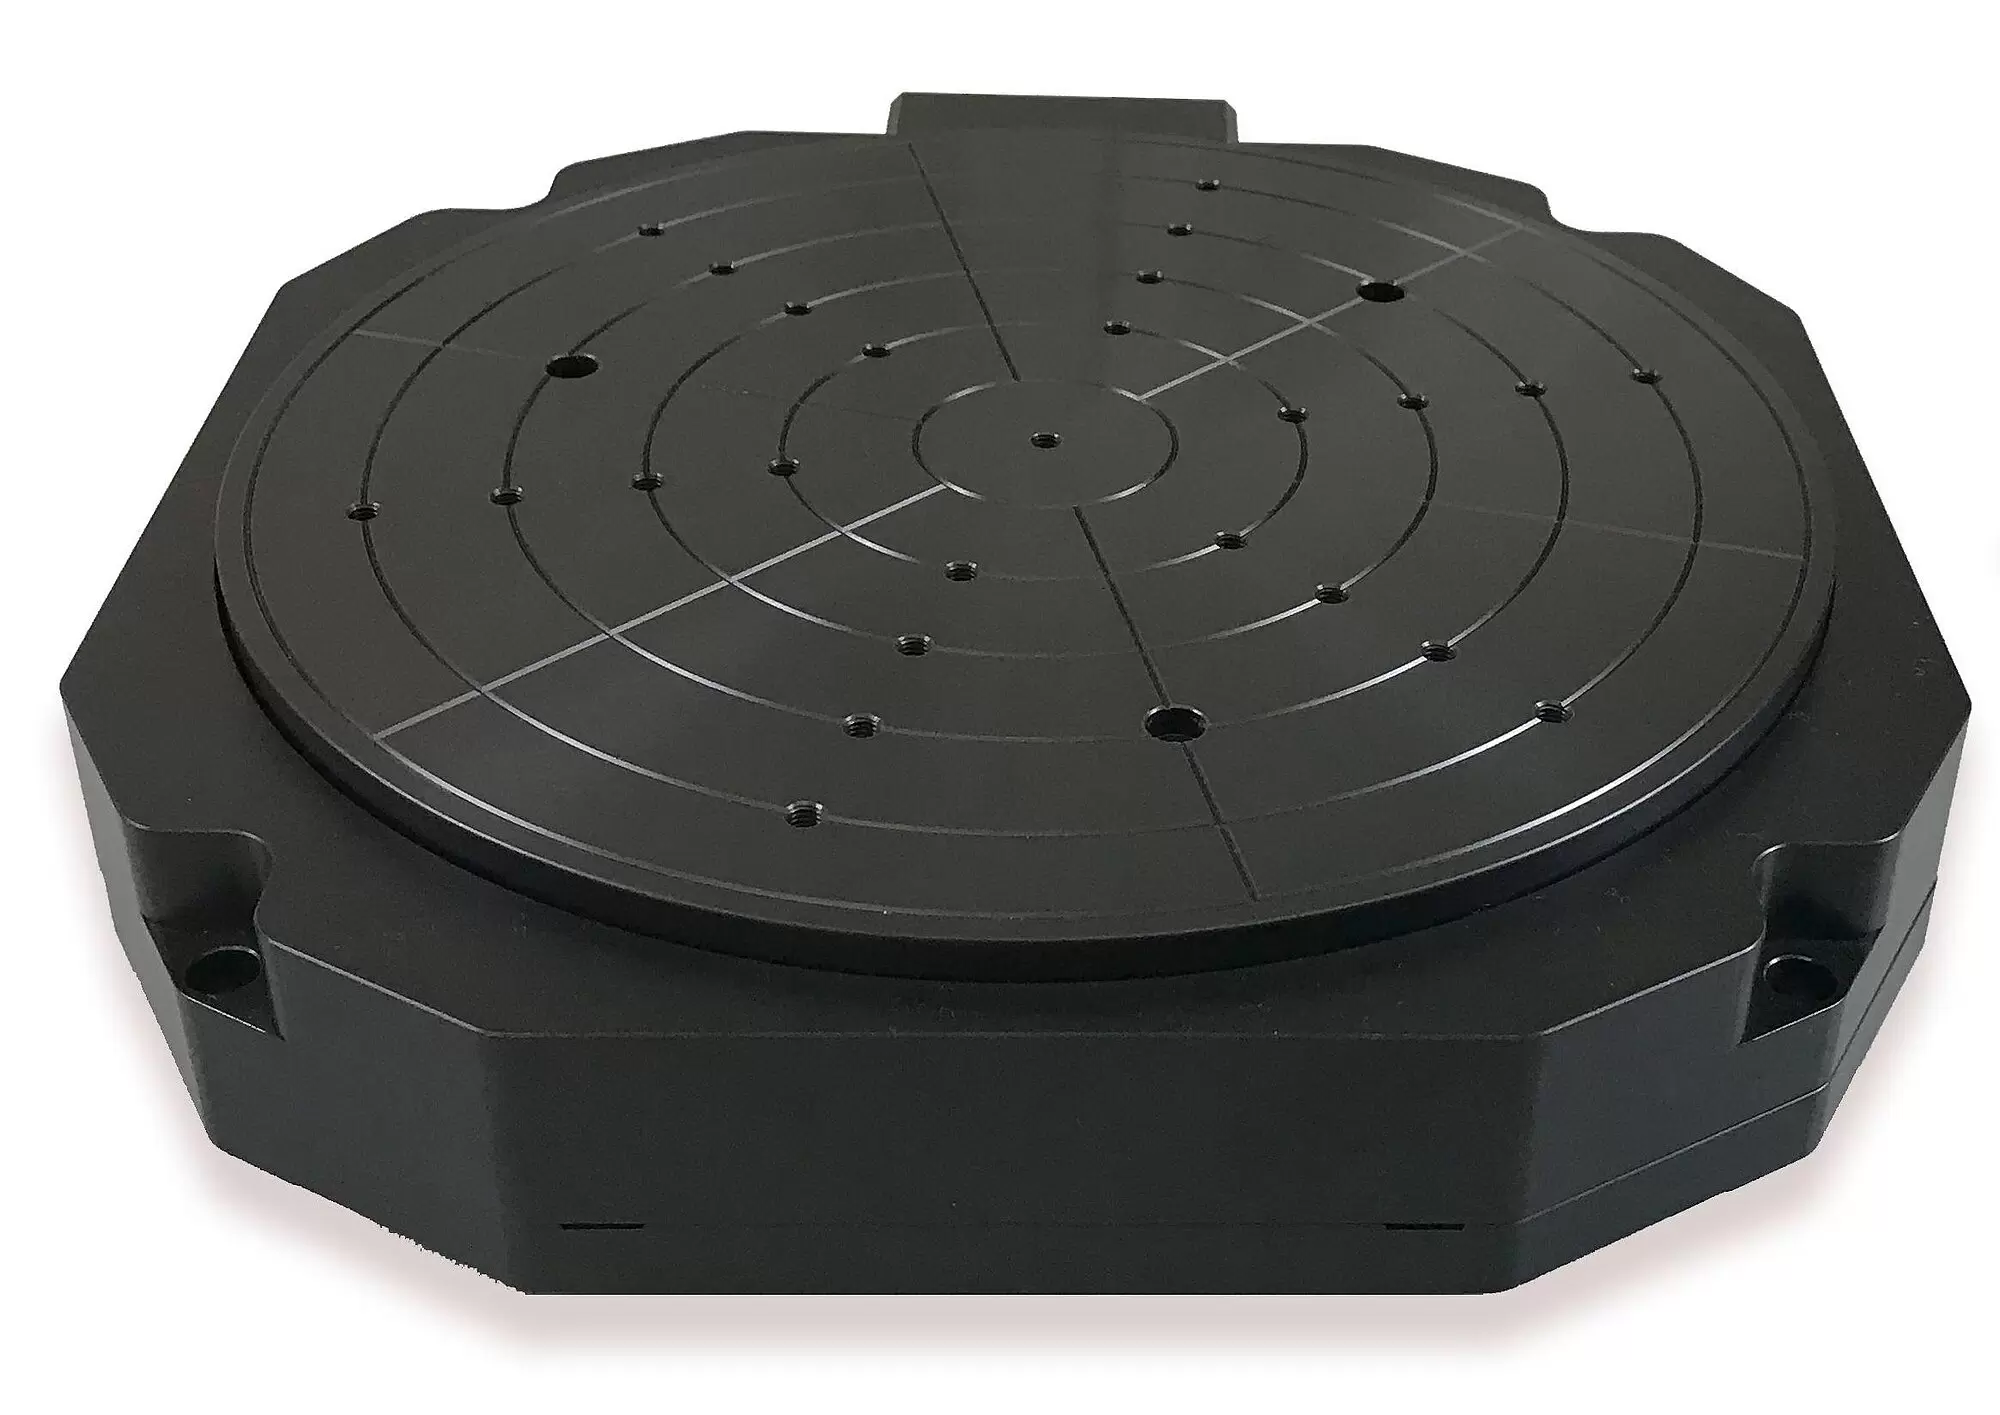
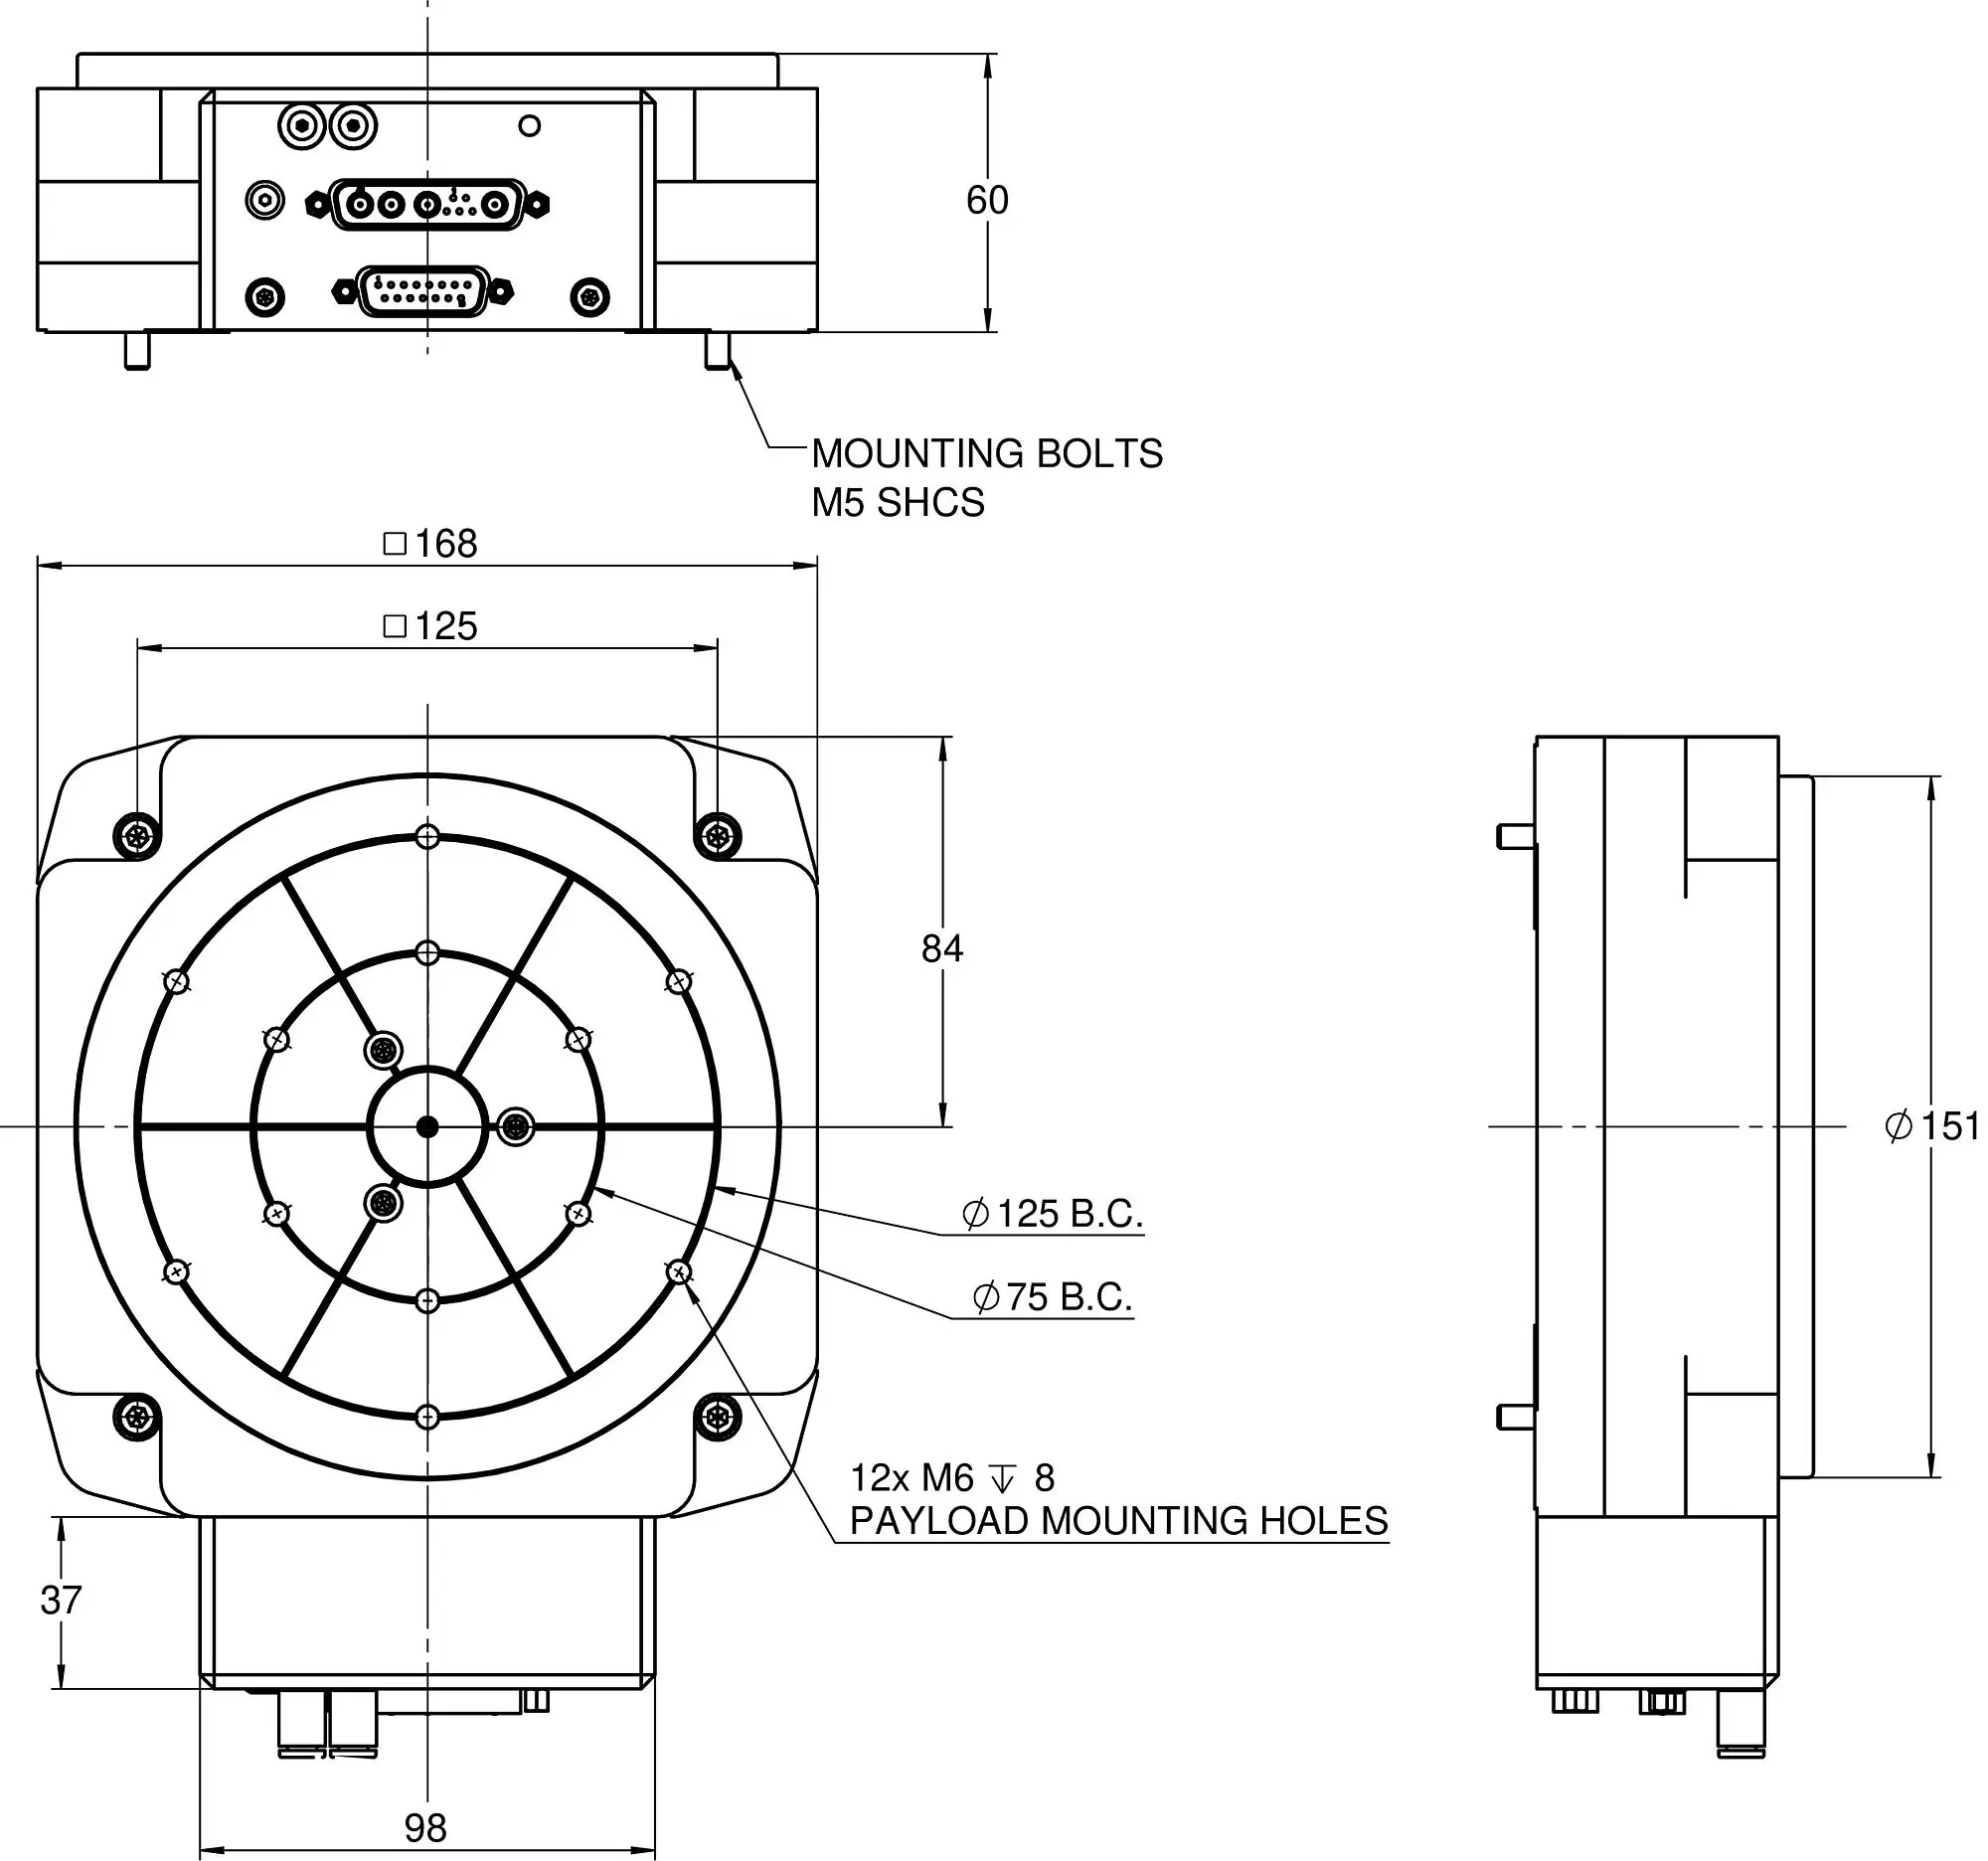
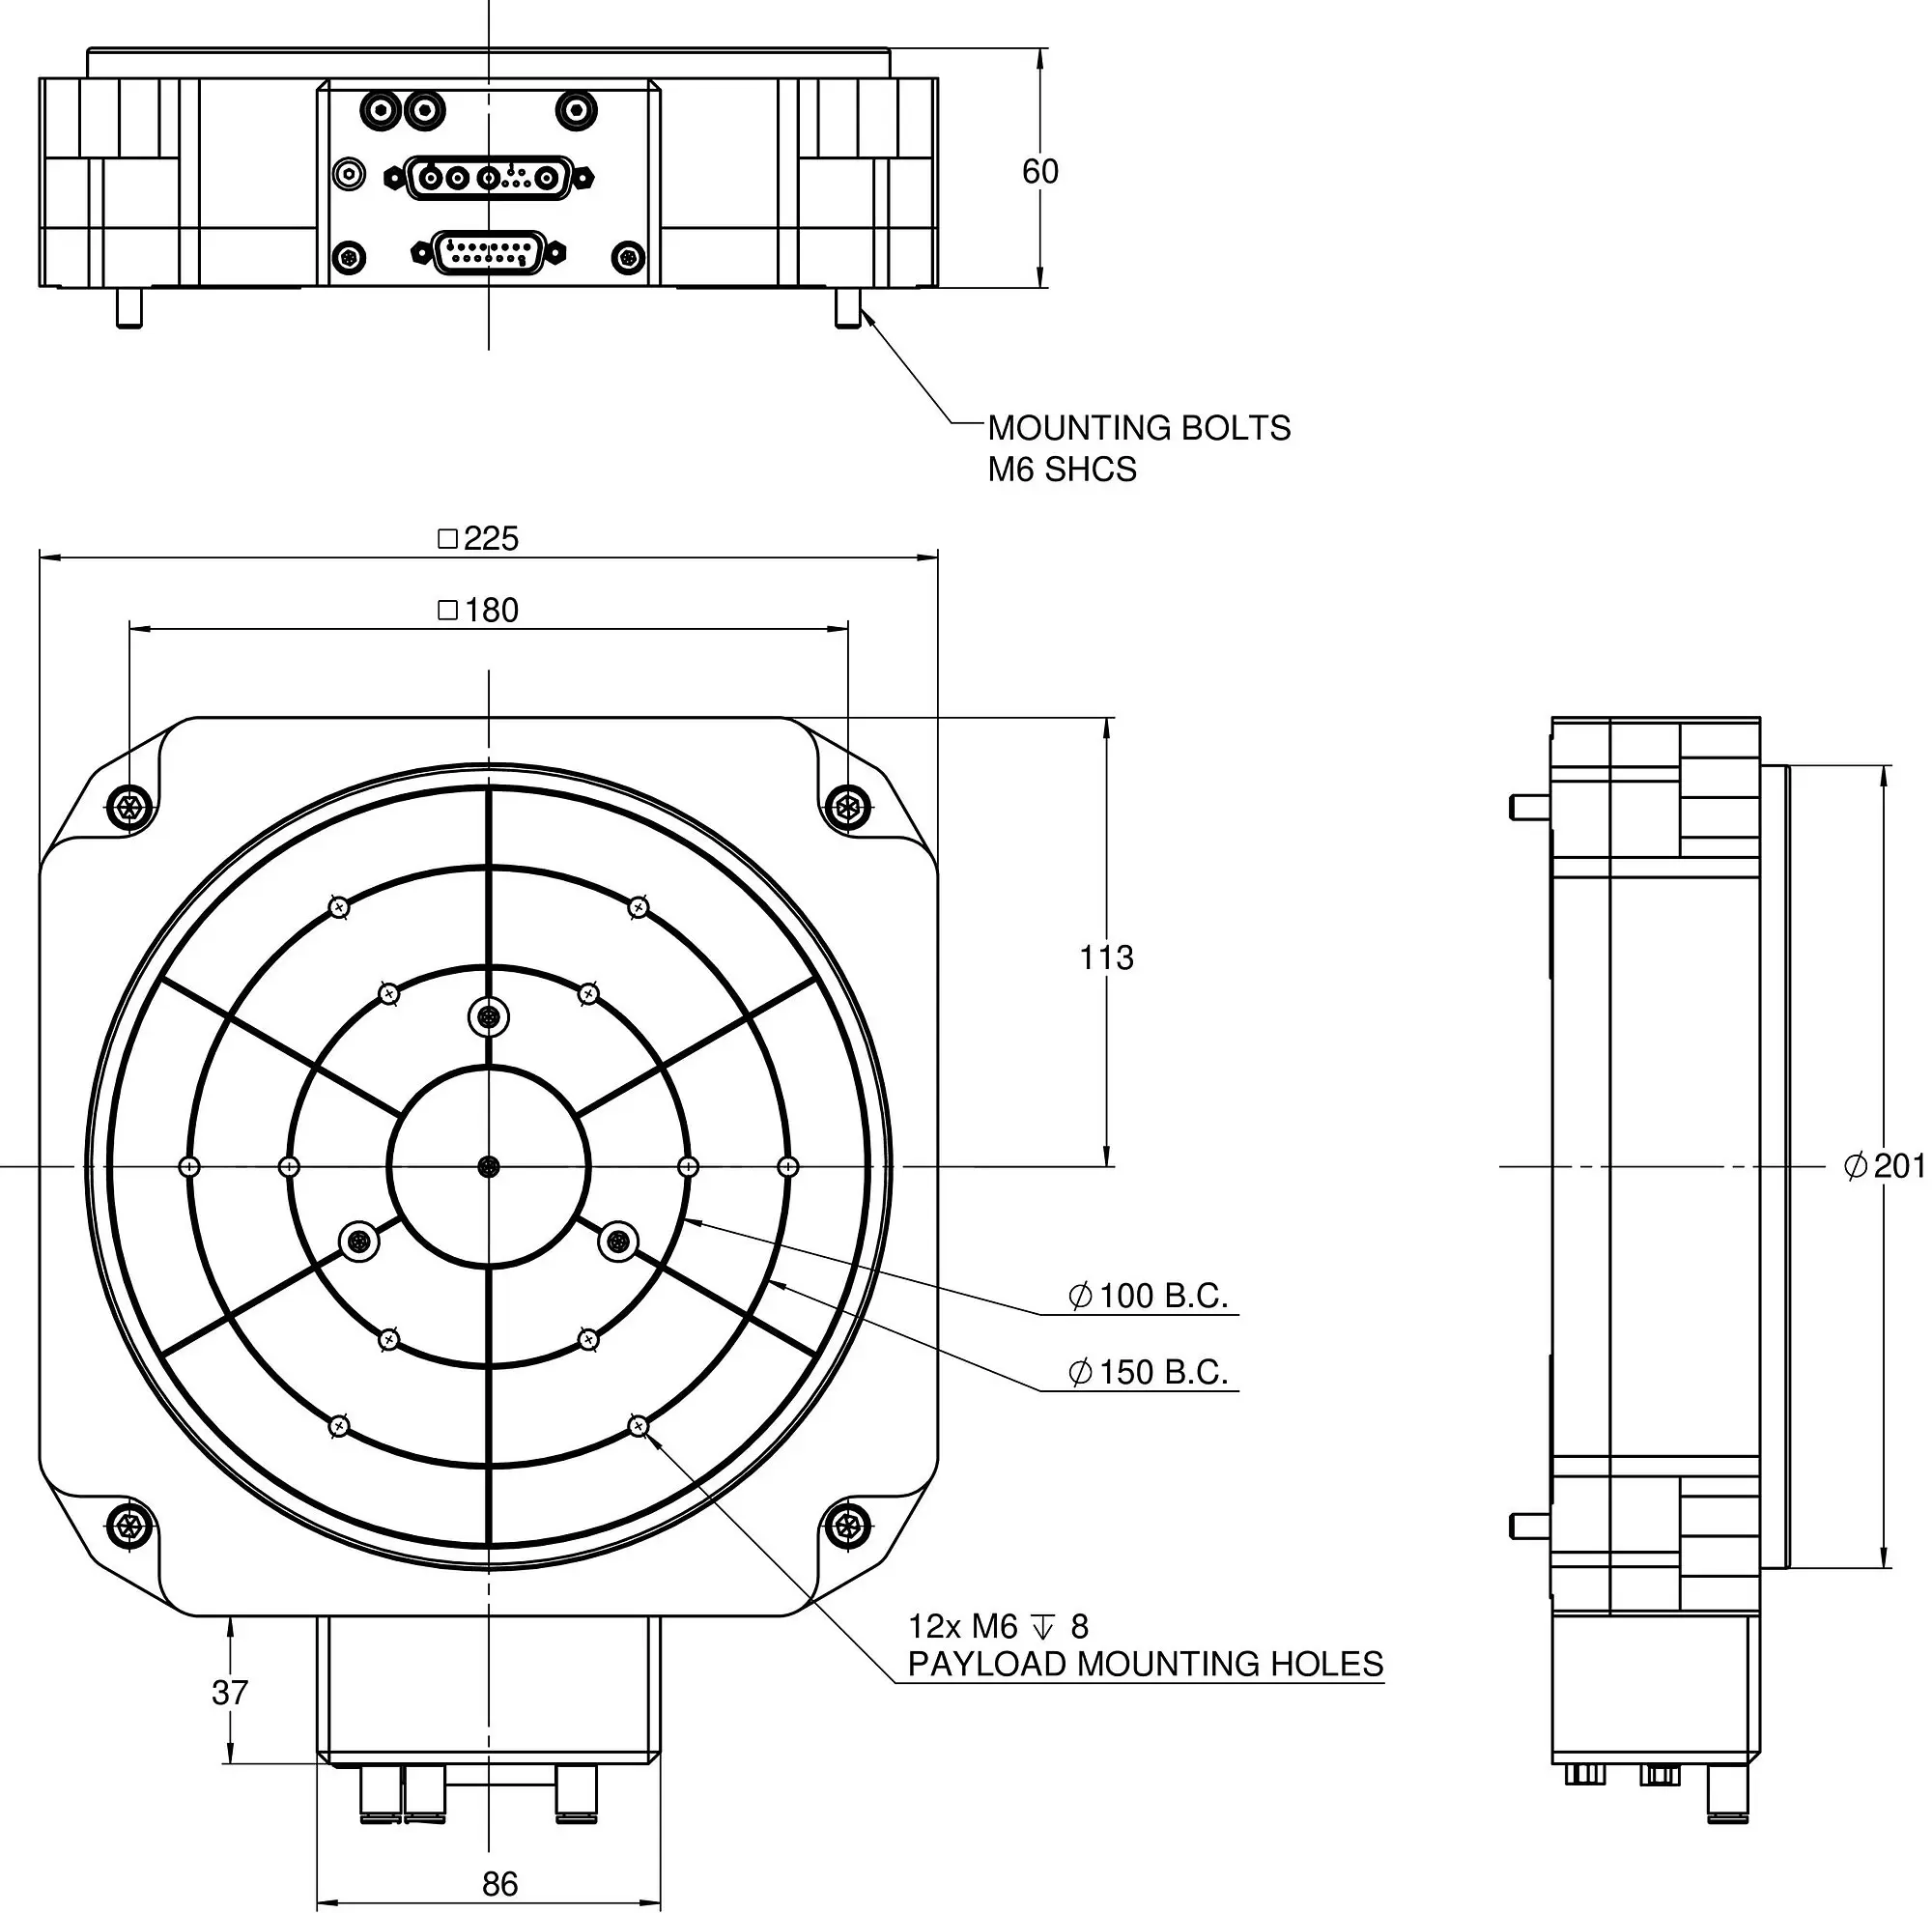
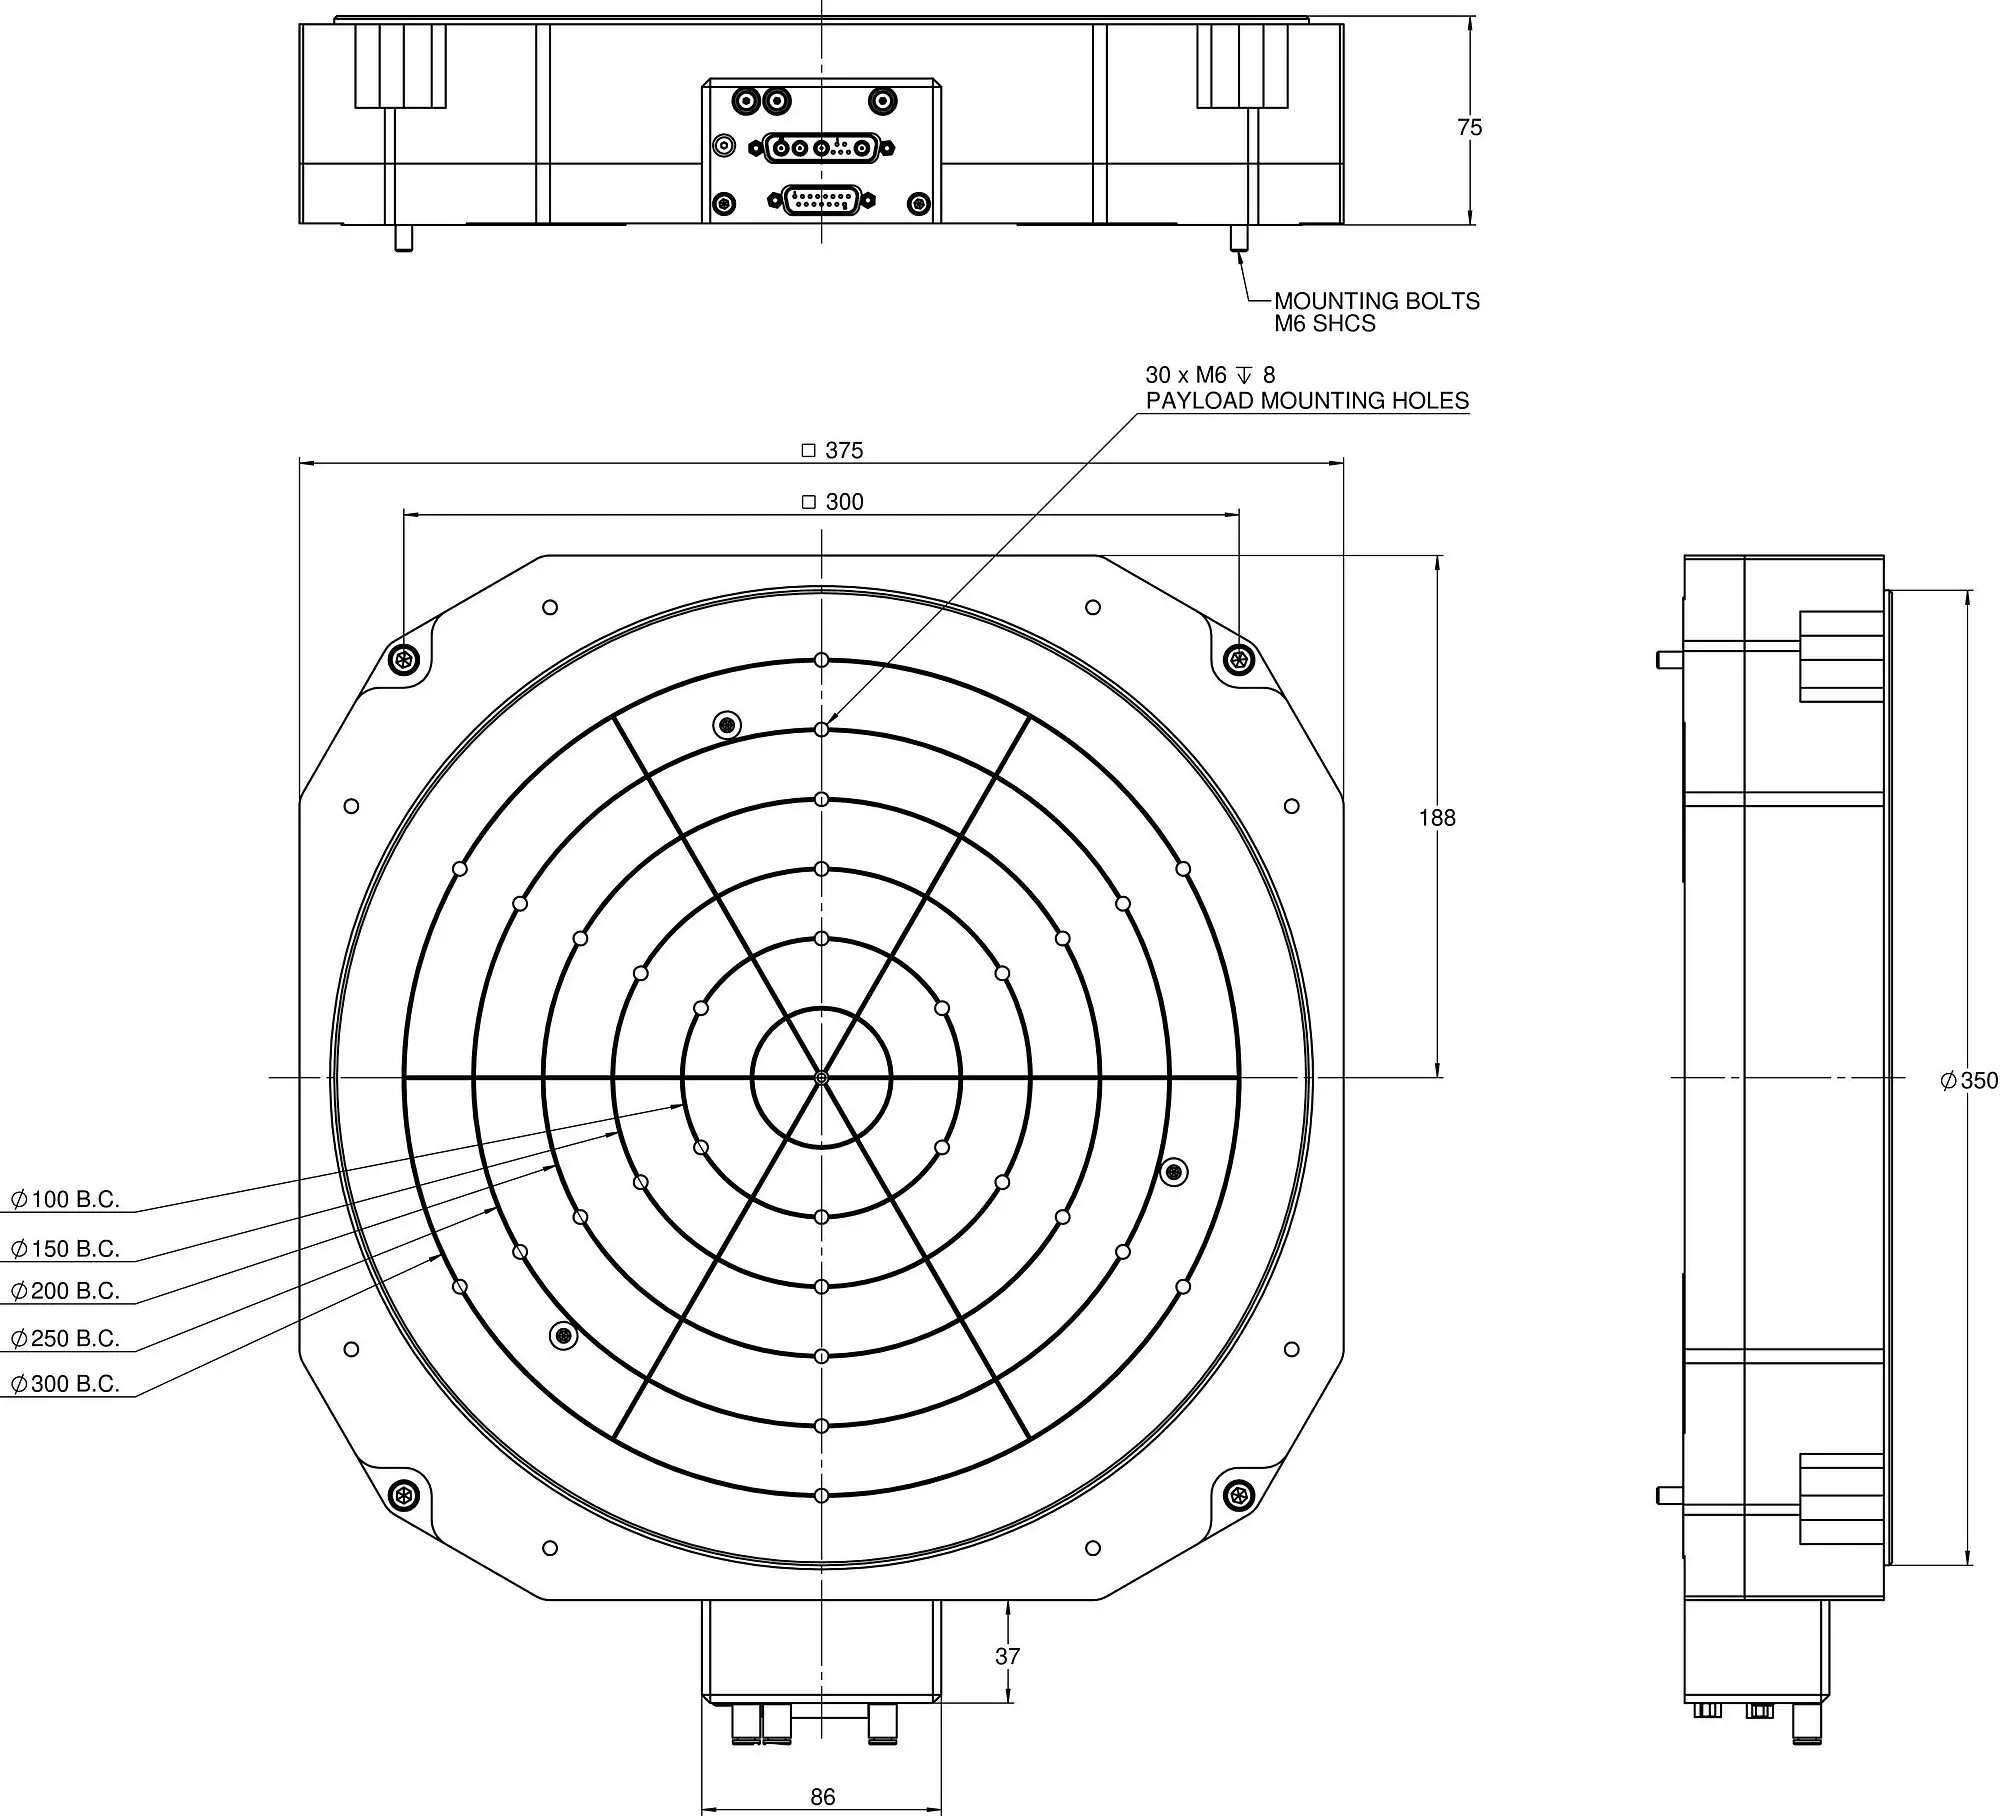
The directly driven low-profile rotation stages of the PIglide RL series are designed for the highest precision with low-profile design. Various options can be combined to create a solution ideal for point-to-point indexing or constant velocity scanning. The RL stages offer superior travel accuracy, flatness, and wobble performance.
Absolute encoders supply explicit position information that enables immediate determination of the position. This means that referencing is not required during switch-on, which increases efficiency and safety during operation.
Optical alignment, wafer inspection, wafer alignment, measuring technology, inspection systems, calibration, scanning.
Thanks to the friction-free motion, no particles are formed, which makes PIglide stages ideal for cleanroom applications.
| Motion | A-634.A100 | A-634.B100 | A-635.A100 | A-635.B100 | A-638.A100 | A-638.B100 | Tolerance |
|---|---|---|---|---|---|---|---|
| Active axes | θZ | θZ | θZ | θZ | θZ | θZ | |
| Rotation range in θZ | 360 ° | 360 ° | 360 ° | 360 ° | 360 ° | 360 ° | |
| Maximum angular velocity in θZ, unloaded | 500 min⁻¹ | 500 min⁻¹ | 500 min⁻¹ | 500 min⁻¹ | 500 min⁻¹ | 500 min⁻¹ | |
| Linear crosstalk in X with motion in θZ | ± 0.1 µm | ± 0.1 µm | ± 0.075 µm | ± 0.075 µm | ± 0.005 µm | ± 0.005 µm | max. |
| Linear crosstalk in Y with motion in θZ | ± 0.1 µm | ± 0.1 µm | ± 0.075 µm | ± 0.075 µm | ± 0.005 µm | ± 0.005 µm | max. |
| Linear crosstalk in Z with motion in θZ | ± 0.038 µm | ± 0.038 µm | ± 0.038 µm | ± 0.038 µm | ± 0.025 µm | ± 0.025 µm | max. |
| Rotational crosstalk in θX with motion in θZ | ± 1 µrad | ± 1 µrad | ± 1 µrad | ± 1 µrad | ± 0.5 µrad | ± 0.5 µrad | max. |
| Rotational crosstalk in θY with motion in θZ | ± 1 µrad | ± 1 µrad | ± 1 µrad | ± 1 µrad | ± 0.5 µrad | ± 0.5 µrad | max. |
| Positioning | A-634.A100 | A-634.B100 | A-635.A100 | A-635.B100 | A-638.A100 | A-638.B100 | Tolerance |
| Integrated sensor | Incremental angle-measuring system | Absolute angle-measuring system | Incremental angle-measuring system | Absolute angle-measuring system | Incremental angle-measuring system | Absolute angle-measuring system | |
| Bidirectional repeatability in θZ | ± 4 µrad | ± 4 µrad | ± 4 µrad | ± 4 µrad | ± 4 µrad | ± 4 µrad | typ. |
| Positioning accuracy in θZ, calibrated | ± 8 µrad | ± 8 µrad | ± 8 µrad | ± 8 µrad | ± 8 µrad | ± 8 µrad | typ. |
| Sensor signal | Sin/cos, 1 V peak-peak | BiSS-C | Sin/cos, 1 V peak-peak | BiSS-C | Sin/cos, 1 V peak-peak | BiSS-C | |
| Sensor signal periods / U | 23600 | 31488 | 31488 | ||||
| Sensor resolution, rotational | 0.06 µrad | 0.0015 µrad | 0.05 µrad | 0.0015 µrad | 0.05 µrad | 0.0015 µrad | |
| Reference switch | 1 / revolution, differential pulse over one sensor signal period, 1 V peak-peak | 1 / revolution, differential pulse over one sensor signal period, 1 V peak-peak | 1 / revolution, differential pulse over one sensor signal period, 1 V peak-peak | ||||
| Drive Properties | A-634.A100 | A-634.B100 | A-635.A100 | A-635.B100 | A-638.A100 | A-638.B100 | Tolerance |
| Drive type | Ironless 3-phase torque motor | Ironless 3-phase torque motor | Ironless 3-phase torque motor | Ironless 3-phase torque motor | Ironless 3-phase torque motor | Ironless 3-phase torque motor | |
| Nominal voltage | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | |
| Peak voltage | 80 V | 80 V | 80 V | 80 V | 80 V | 80 V | |
| Nominal current, RMS | 2.3 A | 2.3 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | typ. |
| Peak current, RMS | 6.9 A | 6.9 A | 13.9 A | 13.9 A | 13.9 A | 13.9 A | typ. |
| Drive torque counterclockwise in θZ | 1.6 N·m | 1.6 N·m | 2.8 N·m | 2.8 N·m | 2.8 N·m | 2.8 N·m | max. |
| Drive torque clockwise in θZ | 1.6 N·m | 1.6 N·m | 2.8 N·m | 2.8 N·m | 2.8 N·m | 2.8 N·m | max. |
| Peak torque counterclockwise in θZ | 4.7 N·m | 4.7 N·m | 8.5 N·m | 8.5 N·m | 8.5 N·m | 8.5 N·m | max. |
| Peak torque clockwise in θZ | 4.7 N·m | 4.7 N·m | 8.5 N·m | 8.5 N·m | 8.5 N·m | 8.5 N·m | max. |
| Torque constant | 0.59 N·m/A | 0.59 N·m/A | 0.66 N·m/A | 0.66 N·m/A | 0.66 N·m/A | 0.66 N·m/A | typ. |
| Resistance phase-phase | 6.7 Ω | 6.7 Ω | 4.5 Ω | 4.5 Ω | 4.5 Ω | 4.5 Ω | typ. |
| Inductance phase-phase | 0.9 mH | 0.9 mH | 0.6 mH | 0.6 mH | 0.6 mH | 0.6 mH | |
| Back EMF, phase-phase, rotational | 71 V/kRPM | 71 V/kRPM | 80 V/kRPM | 80 V/kRPM | 80 V/kRPM | 80 V/kRPM | max. |
| Mechanical Properties | A-634.A100 | A-634.B100 | A-635.A100 | A-635.B100 | A-638.A100 | A-638.B100 | Tolerance |
| Bearing type | Air bearings with magnetic preload | Air bearings with magnetic preload | Air bearings with magnetic preload | Air bearings with magnetic preload | Air bearings with magnetic preload | Air bearings with magnetic preload | |
| Moved mass in θZ, unloaded | 1900 g | 1900 g | 3600 g | 3600 g | 11000 g | 11000 g | ±5 % |
| Moment of inertia in θZ, unloaded | 6640 kg·mm² | 6640 kg·mm² | 23400 kg·mm² | 23400 kg·mm² | 146655 kg·mm² | 146655 kg·mm² | ±20% |
| Permissible push force in X | 40 N | 40 N | 80 N | 80 N | 200 N | 200 N | max. |
| Permissible push force in Y | 40 N | 40 N | 80 N | 80 N | 200 N | 200 N | max. |
| Permissible push force in Z | 190 N | 190 N | 320 N | 320 N | 1200 N | 1200 N | max. |
| Permissible torque in θx | 4.5 N·m | 4.5 N·m | 12 N·m | 12 N·m | 130 N·m | 130 N·m | max. |
| Permissible torque in θY | 4.5 N·m | 4.5 N·m | 12 N·m | 12 N·m | 130 N·m | 130 N·m | max. |
| Overall mass | 4600 g | 4600 g | 7500 g | 7500 g | 24000 g | 24000 g | ±5 % |
| Material | Hardcoat aluminum, stainless steel mounting hardware | Hardcoat aluminum, stainless steel mounting hardware | Hardcoat aluminum, stainless steel mounting hardware | Hardcoat aluminum, stainless steel mounting hardware | Hardcoat aluminum, stainless steel mounting hardware | Hardcoat aluminum, stainless steel mounting hardware | |
| A-634.A100 | A-634.B100 | A-635.A100 | A-635.B100 | A-638.A100 | A-638.B100 | Tolerance | |
| Connector | D-sub 9W4 (m) | D-sub 9W4 (m) | D-sub 9W4 (m) | D-sub 9W4 (m) | D-sub 9W4 (m) | D-sub 9W4 (m) | |
| Sensor connector | D-sub 15-pole (m) | D-sub 15-pole (m) | D-sub 15-pole (m) | D-sub 15-pole (m) | D-sub 15-pole (m) | D-sub 15-pole (m) | |
| Operating pressure | 515 to 585 kPa | 515 to 585 kPa | 515 to 585 kPa | 515 to 585 kPa | 515 to 585 kPa | 515 to 585 kPa | |
| Air consumption | 56 L/min | 56 L/min | 56 L/min | 56 L/min | 56 L/min | 56 L/min | max. |
| Air quality | Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 | Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 | Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 | Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 | Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 | Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 | |
| Recommended controllers / drivers | A-81x (1, 2, or 4 axes) A-82x (4, 6, or 8 axes) | A-81x (1, 2, or 4 axes) A-82x (4, 6, or 8 axes) | A-81x (1, 2, or 4 axes) A-82x (4, 6, or 8 axes) | A-81x (1, 2, or 4 axes) A-82x (4, 6, or 8 axes) | A-81x (1, 2, or 4 axes) A-82x (4, 6, or 8 axes) | A-81x (1, 2, or 4 axes) A-82x (4, 6, or 8 axes) | |
| Operating temperature range | 15 to 25 °C | 15 to 25 °C | 15 to 25 °C | 15 to 25 °C | 15 to 25 °C | 15 to 25 °C |
Note on linear and rotational crosstalk: Dependent on the quality of the underlying surface, the payload, orientation, and forces that act on the stage from the outside. Please contact PI for application-specific parameters. The specified values are static (no rotary motion during measuring) and without load.
Note on permissible push force and permissible torque: The values listed assume a supply pressure of 550 kPa (80 psi). Please contact PI if other pressures are required.
Note on angular velocity: May be limited by the payload, payload imbalance, controller or drive.
Note on sensor resolution for A-63x.A100: Assumes 4096x interpolation. Contact PI for the use of other factors.
Note on positioning accuracy: The specified values are based on error compensation controlled by the controller. The stage must be ordered with an A-8xx series controller from PI to reach these values. Accuracy values assume short-term duration and do not consider the long-term effects of thermal drift on the stage.
Note on operating pressure: To protect the stage against damage, it is recommended to connect an air pressure sensor to the Motion-Stop input of the controller.
Ask about customized versions.