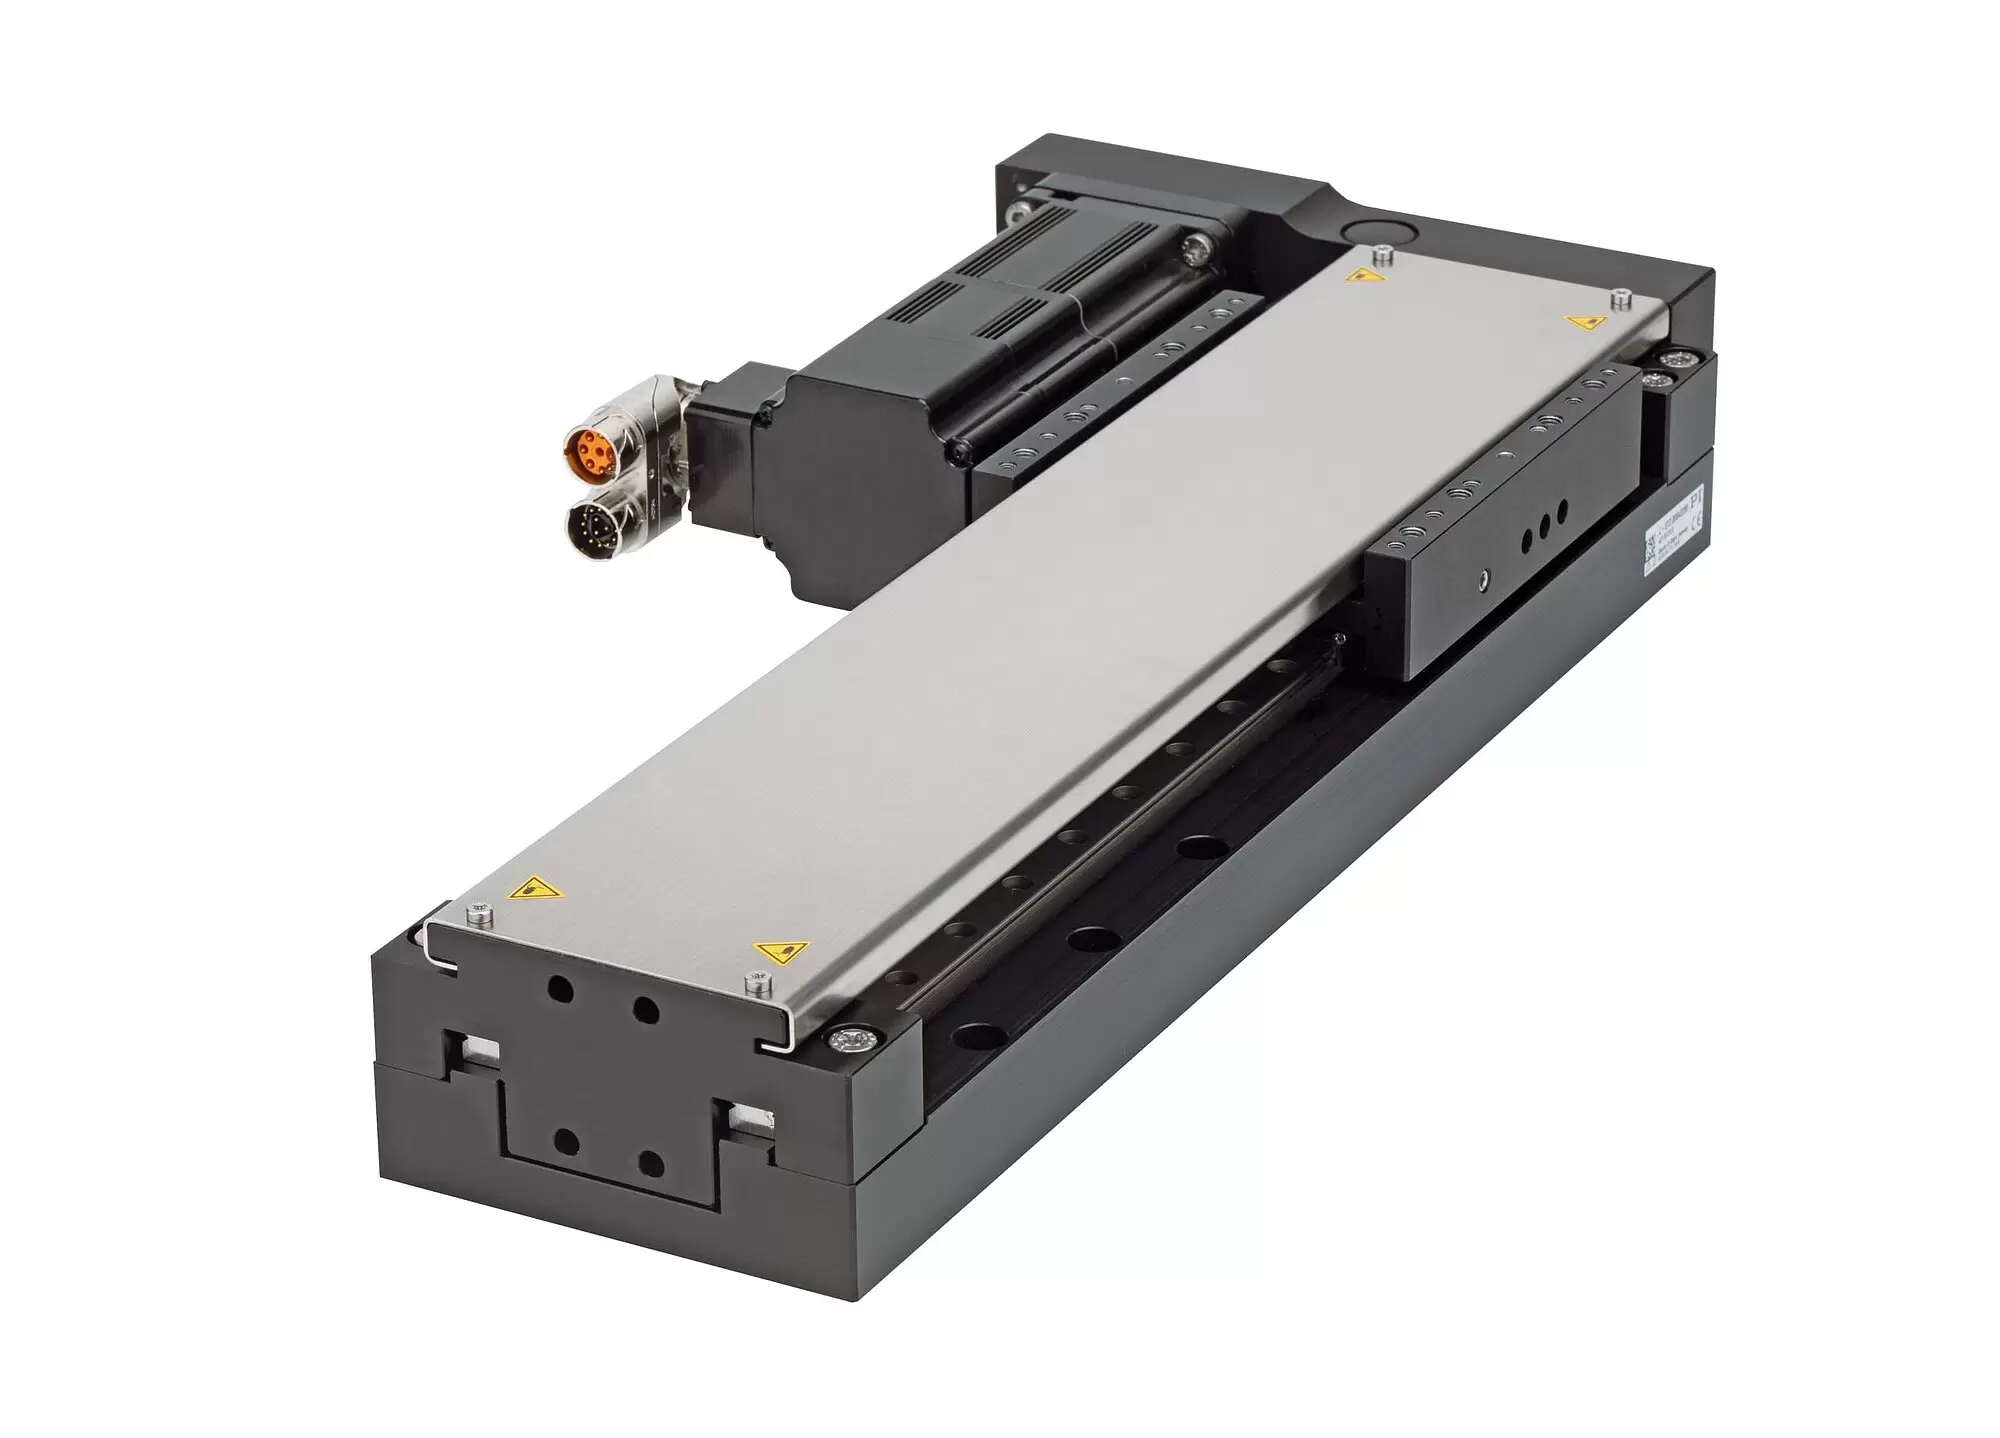
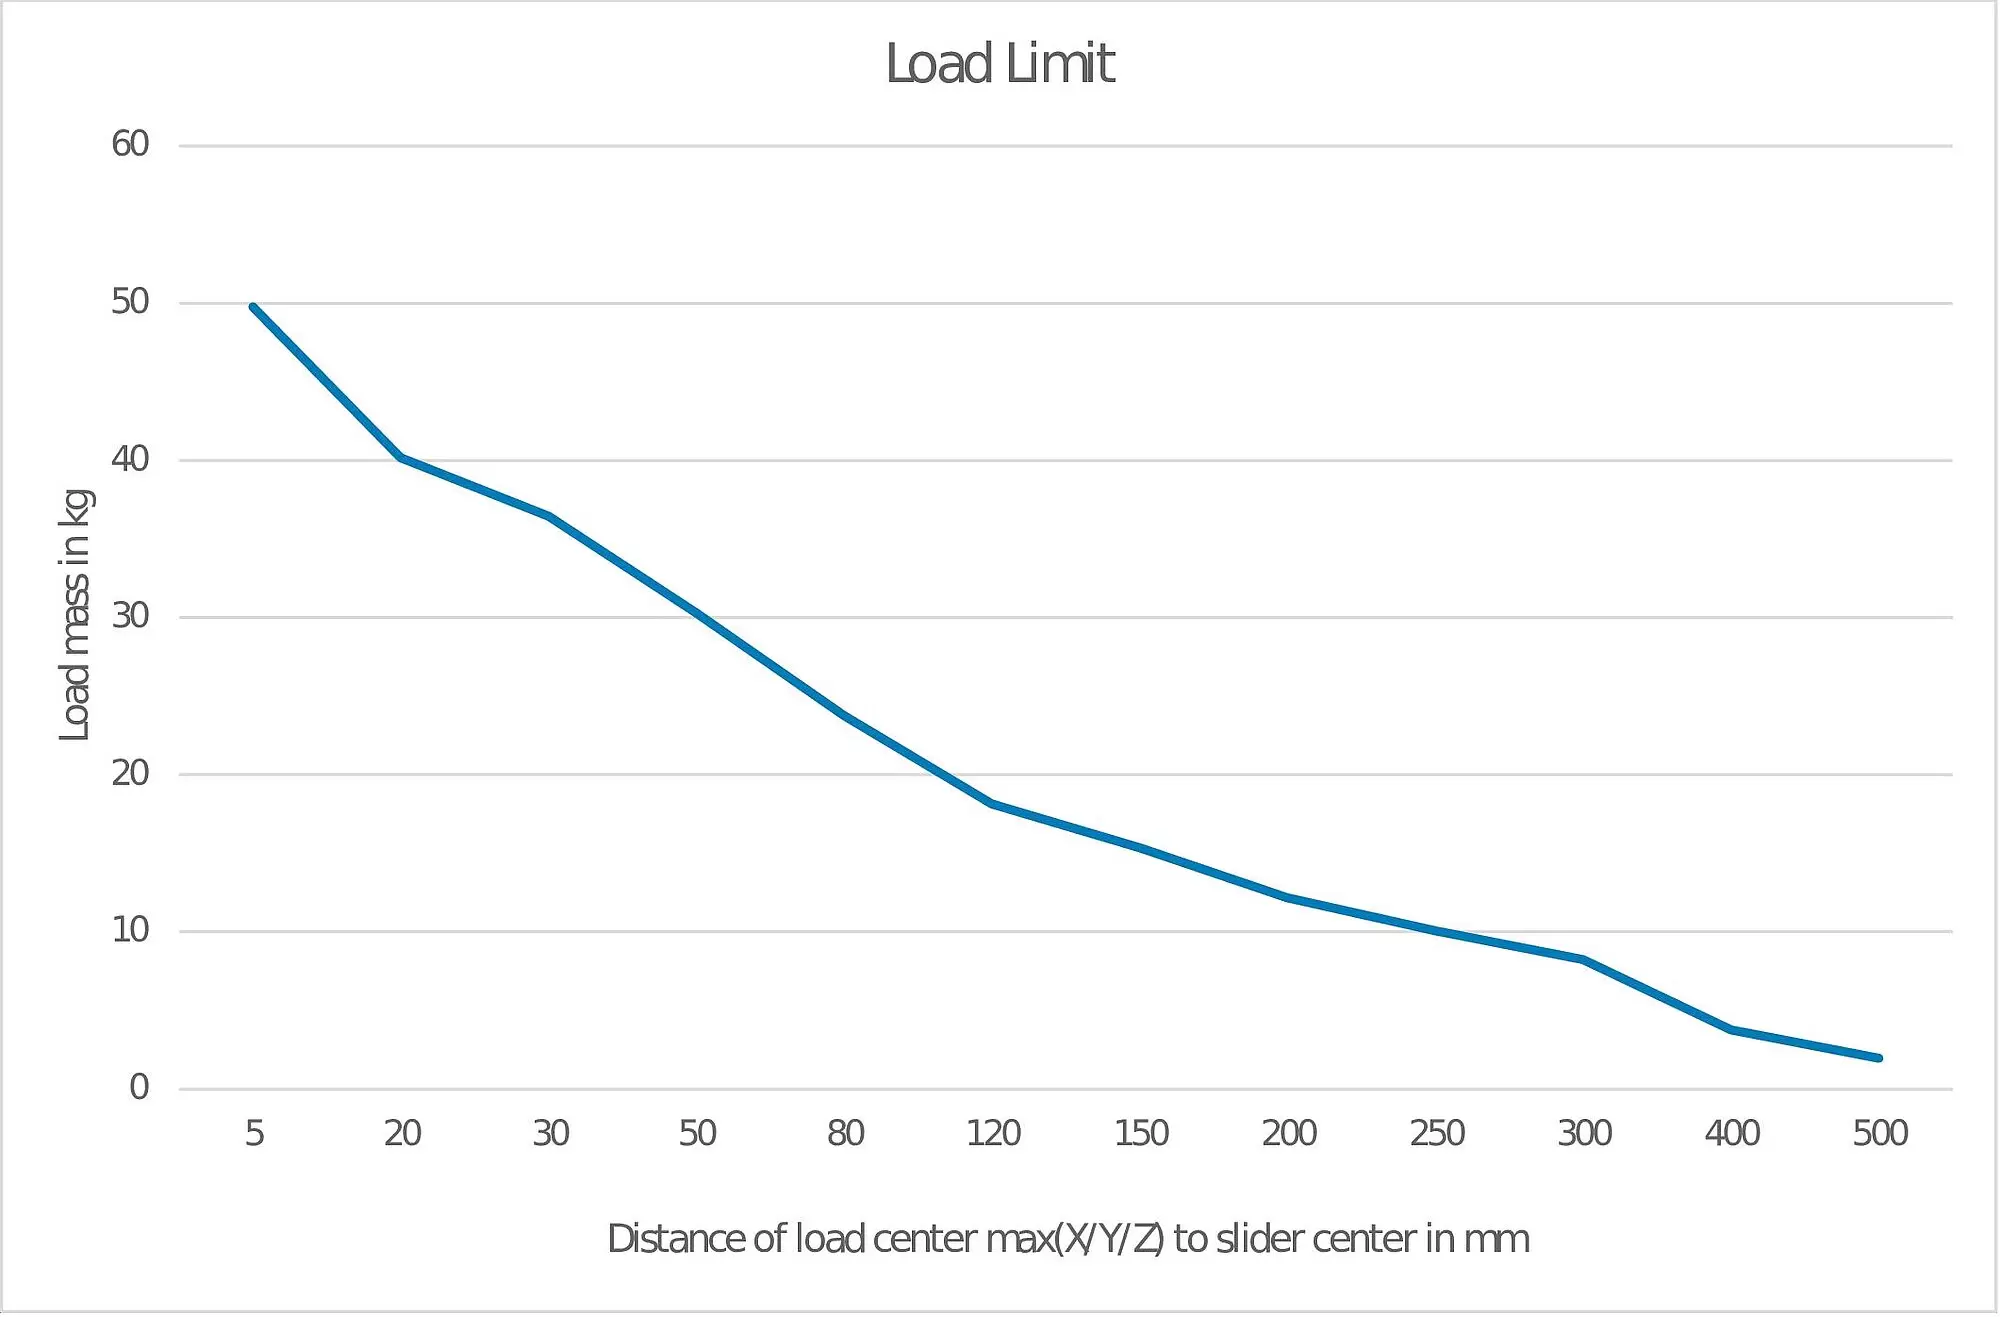
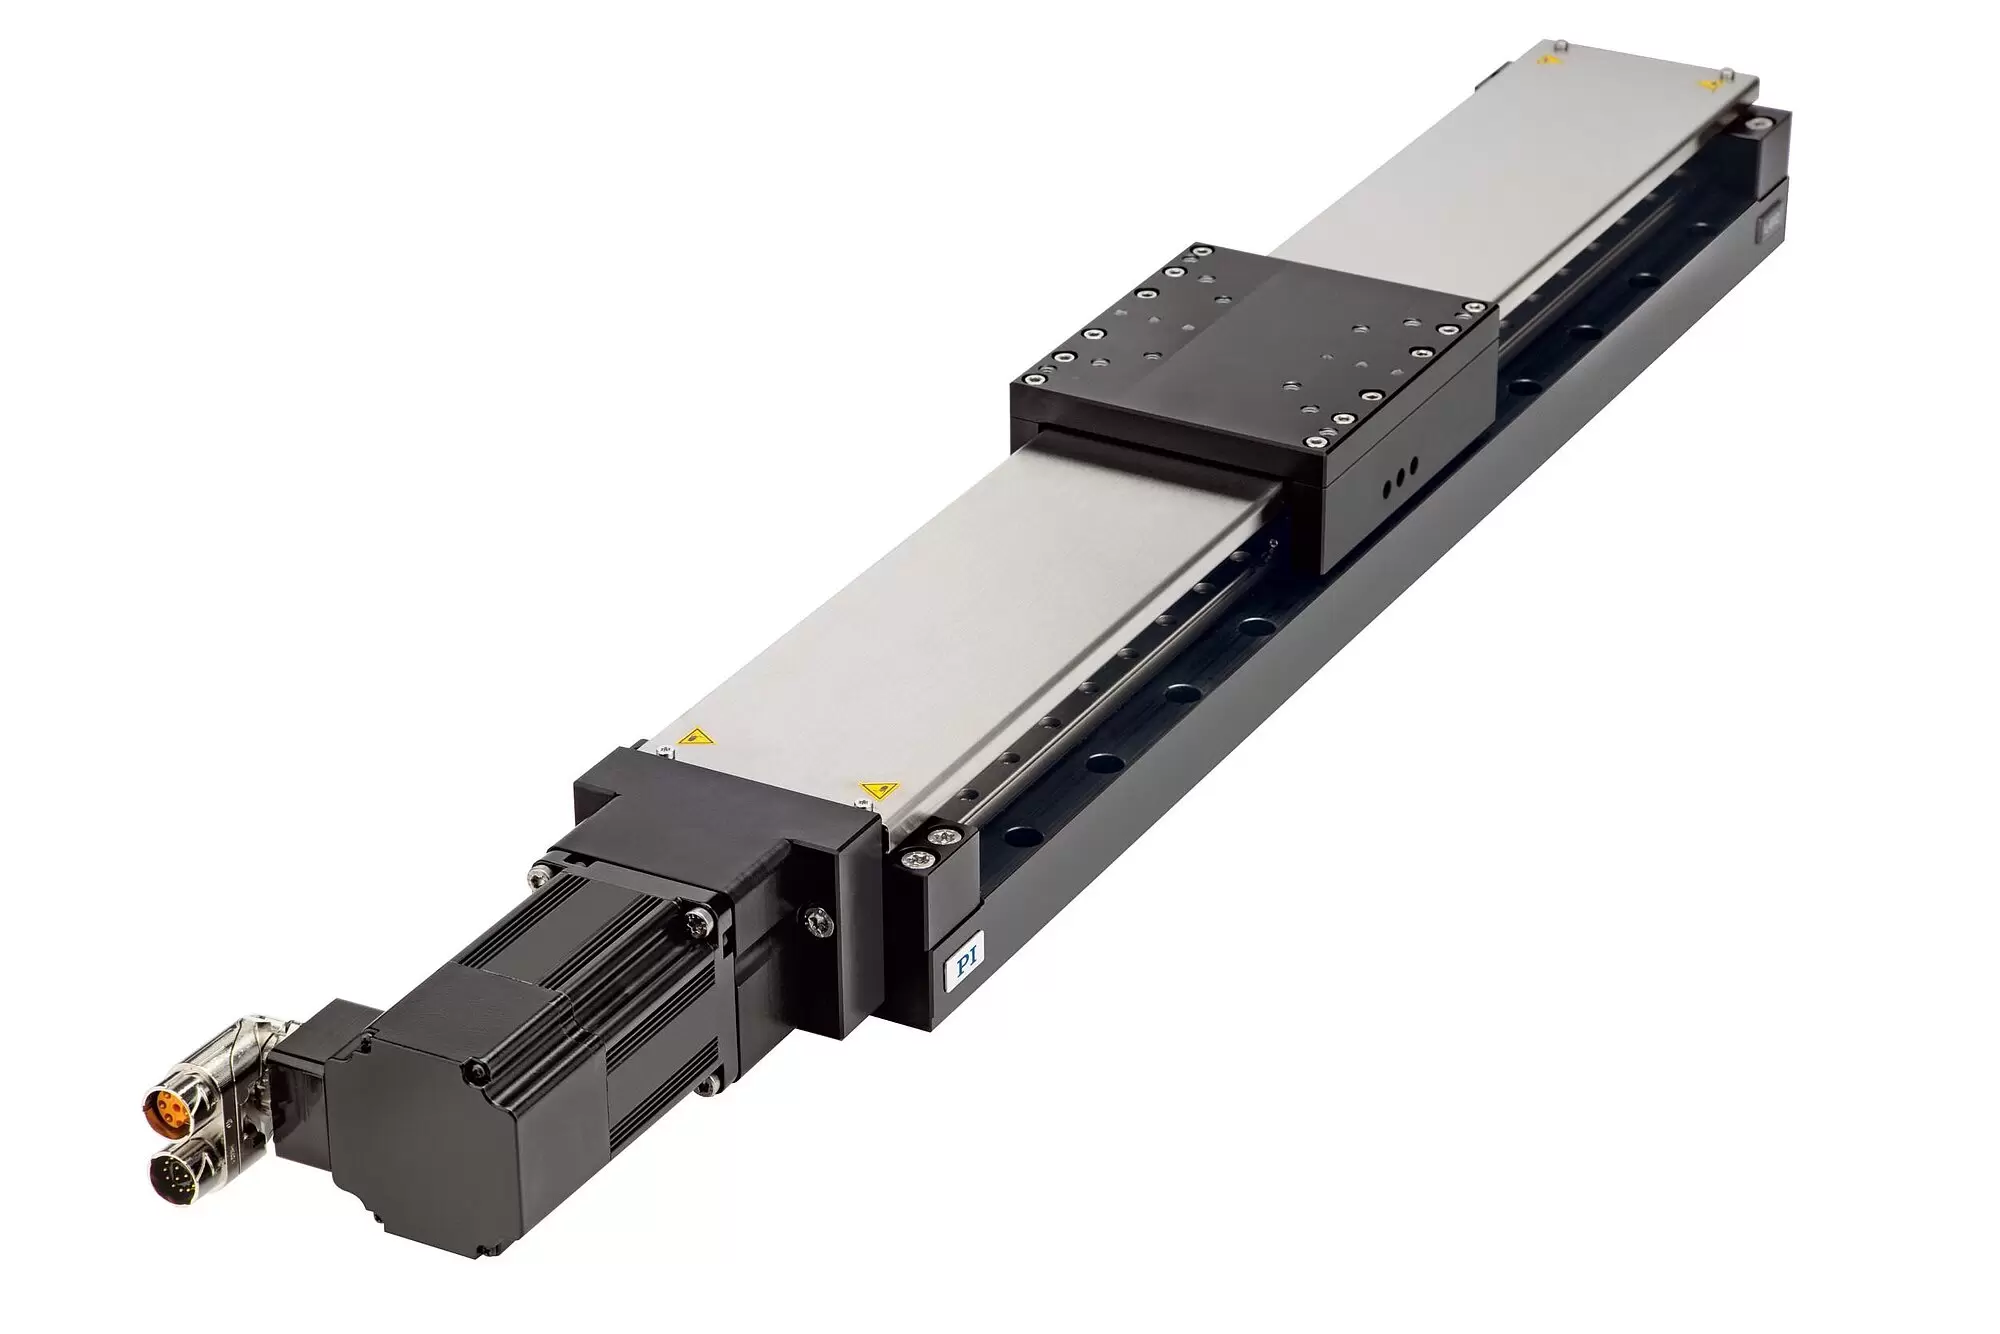
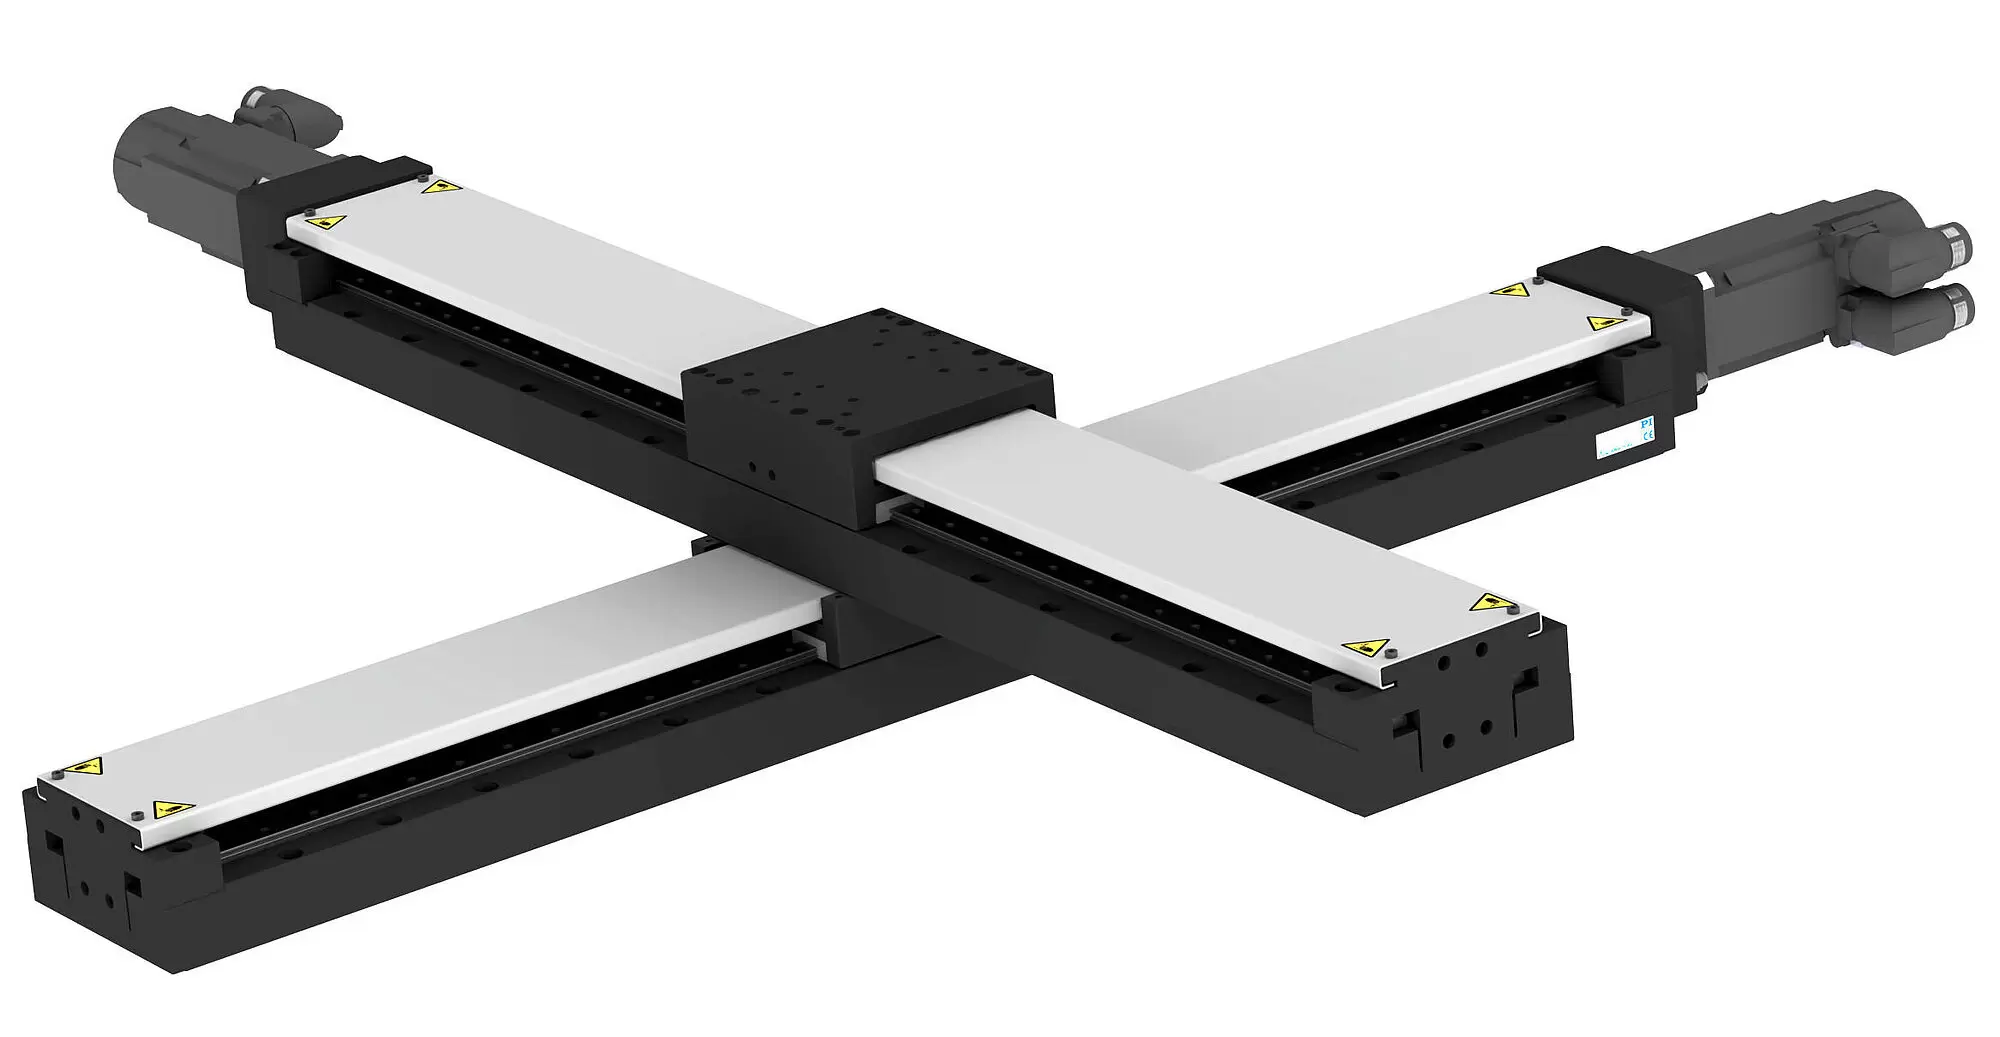
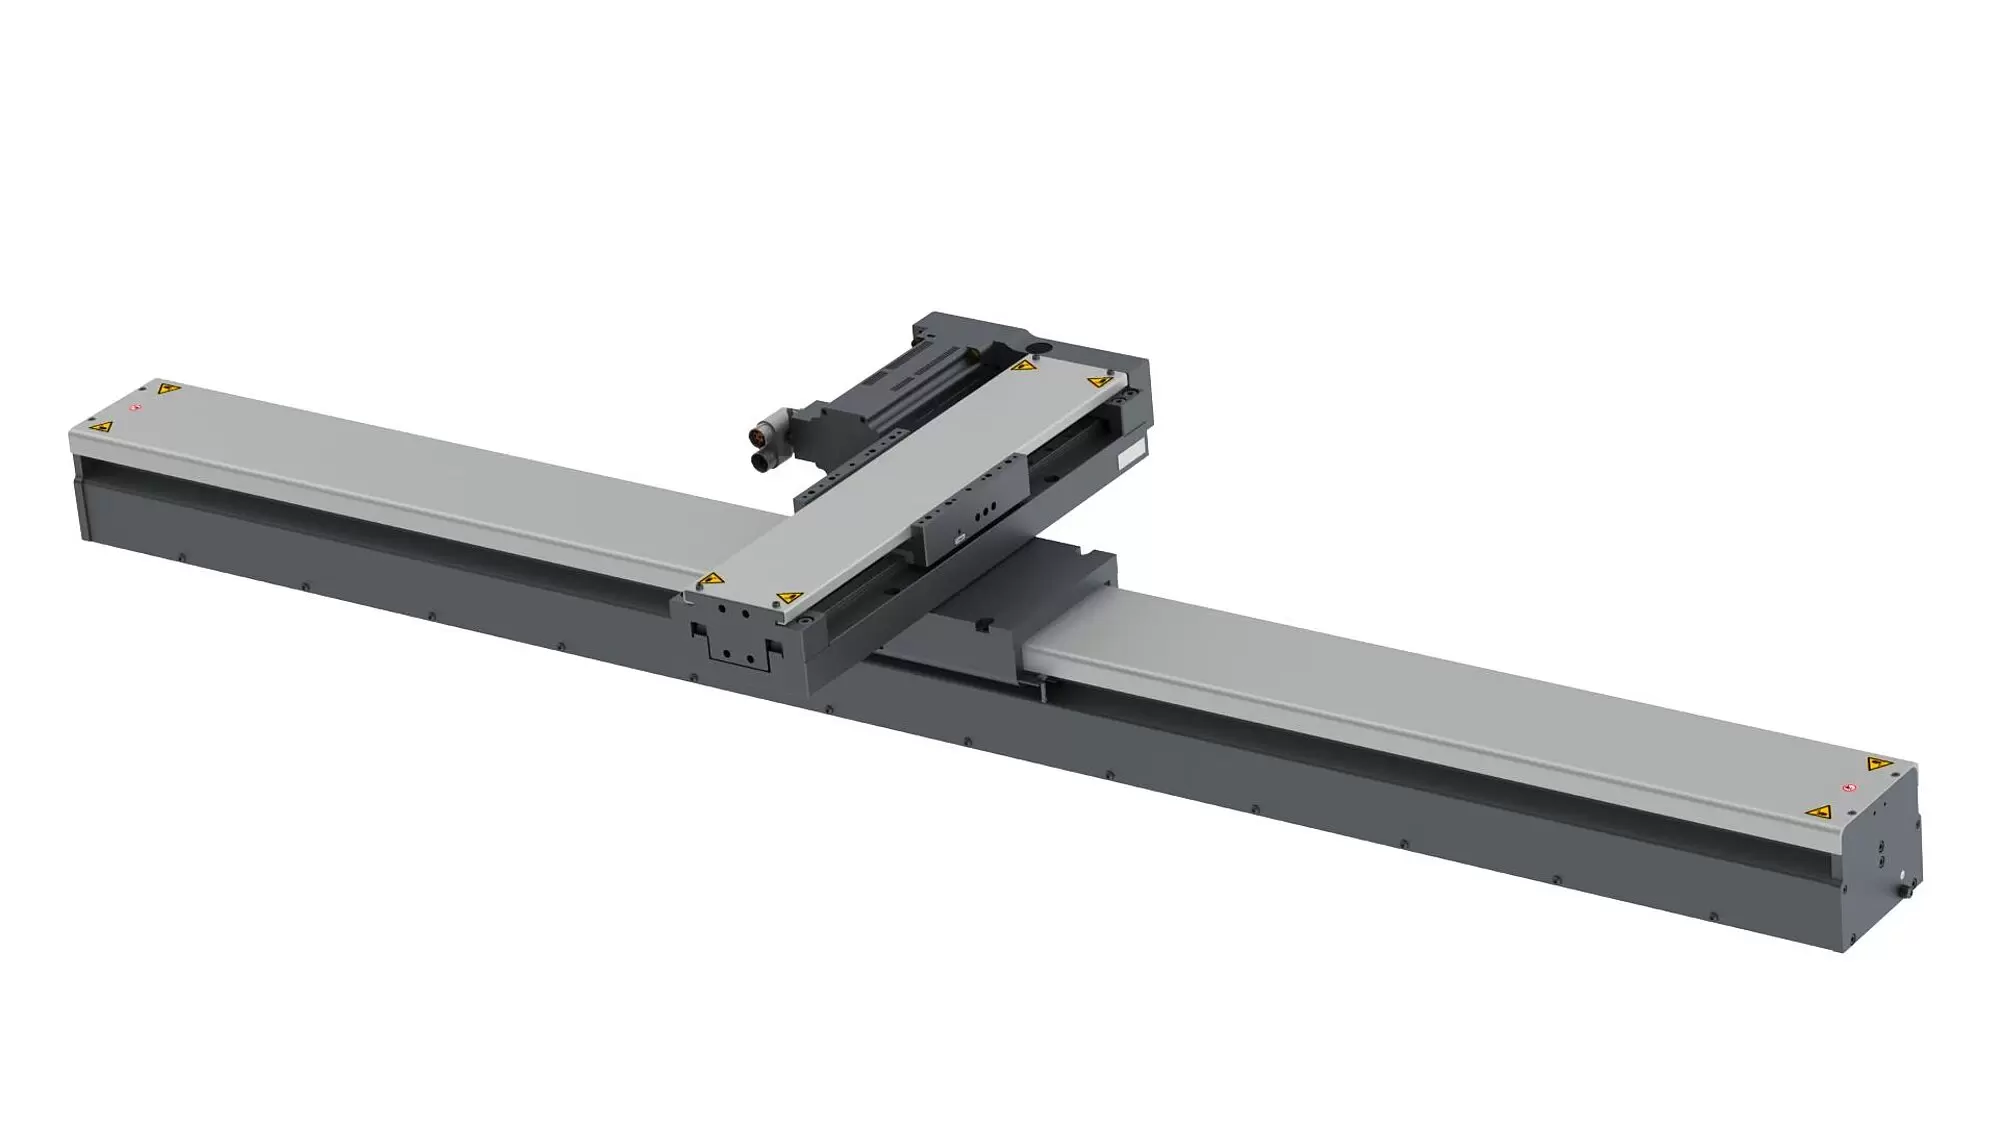
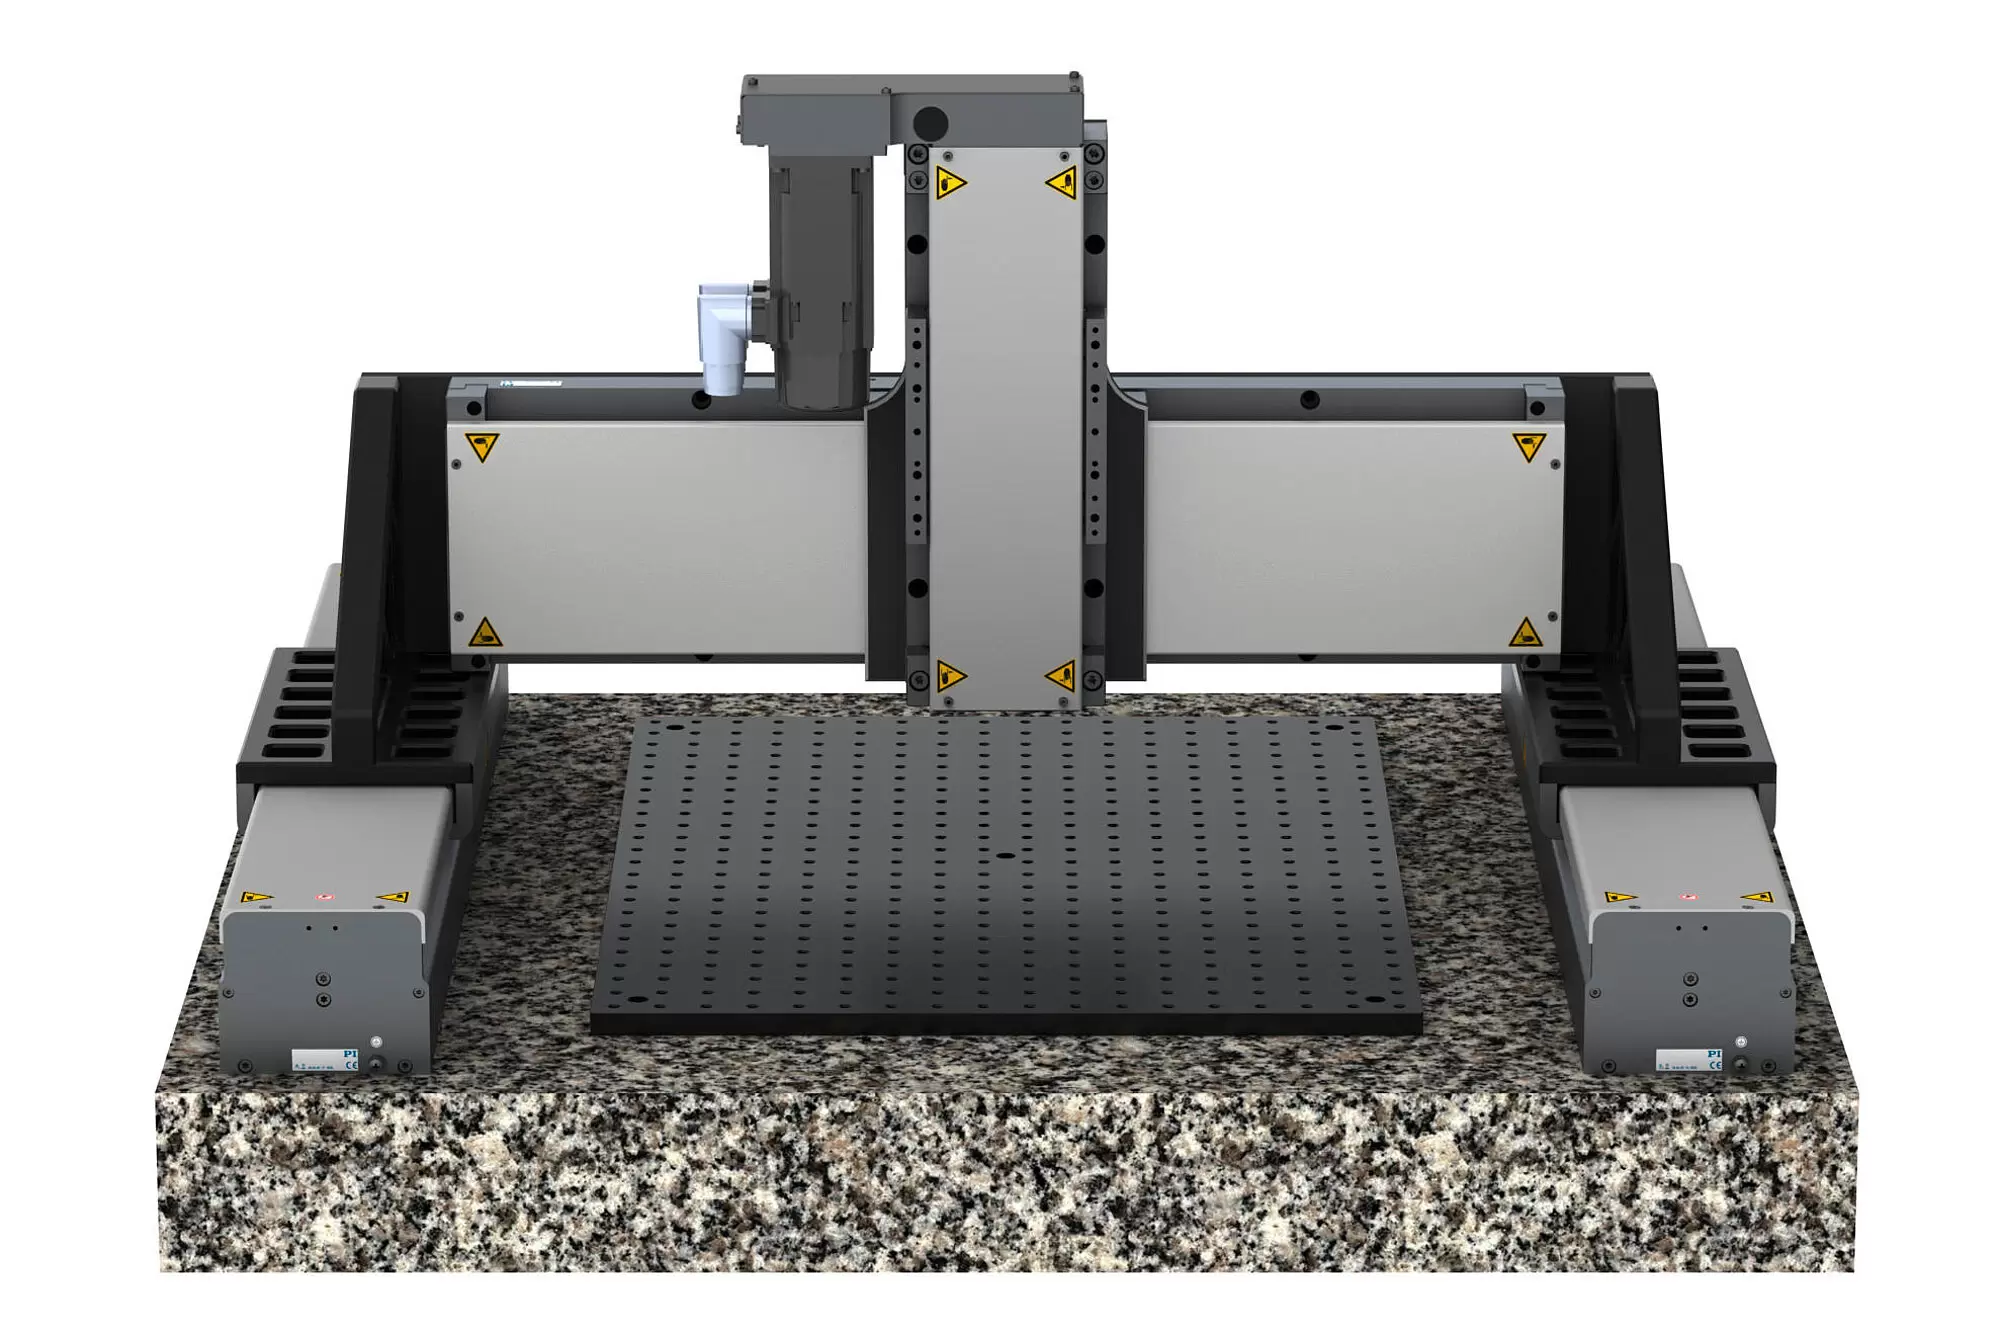
Precision ball screws, high-performance stepper or synchronous servo motors, heavy-duty recirculating ball bearings, and precision rotary encoders enable continuous and reliable operation under high load. The optional holding brake allows use as Z axis. The ball screw can be relubricated from the outside without disassembling to ensure high reliability and long lifetimes.
The recirculating ball bearing guides of the L-812 series are designed for high load capacity and dynamics. The high resolution of the motors allows improved tracking performance, smaller tracking errors, and improved settling times.
These motors have high positioning accuracy and high overload capacity over a large rotation speed range. High torque and low inertia ensure the high dynamics of the drives. The long lifetime, high performance, and robustness of these motors allow excellent results in industrial automation applications.
Powerful and low-vibration 2-phase stepper motors allow for accurate positioning even without position control.
| Motion | L-812.051400 | L-812.051400B | L-812.051400BF | L-812.091400 | L-812.091400B | L-812.091400BF | L-812.171400 | L-812.171400B | L-812.171400BF | L-812.251400 | L-812.251400B | L-812.251400BF | L-812.059432 | L-812.059432B | L-812.059432BF | L-812.099432 | L-812.099432B | L-812.099432BF | L-812.139432 | L-812.179432 | L-812.179432B | L-812.179432BF | L-812.259432 | L-812.259432B | L-812.259432BF | L-812.059453 | L-812.059453B | L-812.059453BF | L-812.099453 | L-812.099453B | L-812.099453BF | L-812.179453 | L-812.179453B | L-812.179453BF | L-812.259453 | L-812.259453B | L-812.259453BF | Tolerance |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Active axes | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | |
| Travel range in X | 102 mm | 102 mm | 102 mm | 204 mm | 204 mm | 204 mm | 407 mm | 407 mm | 407 mm | 610 mm | 610 mm | 610 mm | 102 mm | 102 mm | 102 mm | 204 mm | 204 mm | 204 mm | 304 mm | 407 mm | 407 mm | 407 mm | 610 mm | 610 mm | 610 mm | 102 mm | 102 mm | 102 mm | 204 mm | 204 mm | 204 mm | 407 mm | 407 mm | 407 mm | 610 mm | 610 mm | 610 mm | |
| Acceleration in X, unloaded | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | 10 m/s² | max. |
| Maximum velocity in X, unloaded | 100 mm/s | 100 mm/s | 100 mm/s | 100 mm/s | 100 mm/s | 100 mm/s | 100 mm/s | 100 mm/s | 100 mm/s | 100 mm/s | 100 mm/s | 100 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | 300 mm/s | |
| Straightness (Linear crosstalk in Y with motion in X) | ± 4 µm | ± 4 µm | ± 4 µm | ± 6 µm | ± 6 µm | ± 6 µm | ± 10 µm | ± 10 µm | ± 10 µm | ± 14 µm | ± 14 µm | ± 14 µm | ± 4 µm | ± 4 µm | ± 4 µm | ± 6 µm | ± 6 µm | ± 6 µm | ± 10 µm | ± 10 µm | ± 10 µm | ± 10 µm | ± 14 µm | ± 14 µm | ± 14 µm | ± 4 µm | ± 4 µm | ± 4 µm | ± 6 µm | ± 6 µm | ± 6 µm | ± 10 µm | ± 10 µm | ± 10 µm | ± 14 µm | ± 14 µm | ± 14 µm | max. |
| Flatness (Linear crosstalk in Z with motion in X) | ± 4 µm | ± 4 µm | ± 4 µm | ± 6 µm | ± 6 µm | ± 6 µm | ± 10 µm | ± 10 µm | ± 10 µm | ± 14 µm | ± 14 µm | ± 14 µm | ± 4 µm | ± 4 µm | ± 4 µm | ± 6 µm | ± 6 µm | ± 6 µm | ± 10 µm | ± 10 µm | ± 10 µm | ± 10 µm | ± 14 µm | ± 14 µm | ± 14 µm | ± 4 µm | ± 4 µm | ± 4 µm | ± 6 µm | ± 6 µm | ± 6 µm | ± 10 µm | ± 10 µm | ± 10 µm | ± 14 µm | ± 14 µm | ± 14 µm | max. |
| Pitch (Rotational crosstalk in θY with motion in X) | ± 21 µrad | ± 21 µrad | ± 21 µrad | ± 28.5 µrad | ± 28.5 µrad | ± 28.5 µrad | ± 58.5 µrad | ± 58.8 µrad | ± 58.5 µrad | ± 88.5 µrad | ± 88.5 µrad | ± 88.5 µrad | ± 21 µrad | ± 21 µrad | ± 21 µrad | ± 29 µrad | ± 29 µrad | ± 29 µrad | ± 59 µrad | ± 59 µrad | ± 59 µrad | ± 59 µrad | ± 87 µrad | ± 87 µrad | ± 87 µrad | ± 21 µrad | ± 21 µrad | ± 21 µrad | ± 29 µrad | ± 29 µrad | ± 29 µrad | ± 59 µrad | ± 59 µrad | ± 59 µrad | ± 87 µrad | ± 87 µrad | ± 87 µrad | max. |
| Yaw (Rotational crosstalk in θZ with motion in X) | ± 21 µrad | ± 21 µrad | ± 21 µrad | ± 27 µrad | ± 27 µrad | ± 27 µrad | ± 59 µrad | ± 59 µrad | ± 59 µrad | ± 87 µrad | ± 87 µrad | ± 87 µrad | ± 21 µrad | ± 21 µrad | ± 21 µrad | ± 29 µrad | ± 29 µrad | ± 29 µrad | ± 59 µrad | ± 59 µrad | ± 59 µrad | ± 59 µrad | ± 87 µrad | ± 87 µrad | ± 87 µrad | ± 21 µrad | ± 21 µrad | ± 21 µrad | ± 29 µrad | ± 29 µrad | ± 29 µrad | ± 59 µrad | ± 59 µrad | ± 59 µrad | ± 87 µrad | ± 87 µrad | ± 87 µrad | max. |
| Positioning | L-812.051400 | L-812.051400B | L-812.051400BF | L-812.091400 | L-812.091400B | L-812.091400BF | L-812.171400 | L-812.171400B | L-812.171400BF | L-812.251400 | L-812.251400B | L-812.251400BF | L-812.059432 | L-812.059432B | L-812.059432BF | L-812.099432 | L-812.099432B | L-812.099432BF | L-812.139432 | L-812.179432 | L-812.179432B | L-812.179432BF | L-812.259432 | L-812.259432B | L-812.259432BF | L-812.059453 | L-812.059453B | L-812.059453BF | L-812.099453 | L-812.099453B | L-812.099453BF | L-812.179453 | L-812.179453B | L-812.179453BF | L-812.259453 | L-812.259453B | L-812.259453BF | Tolerance |
| Minimum incremental motion in X | 3 µm | 3 µm | 3 µm | 3 µm | 3 µm | 3 µm | 3 µm | 3 µm | 3 µm | 3 µm | 3 µm | 3 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | 1.5 µm | max. |
| Positioning accuracy in X, uncalibrated | ± 20 µm | ± 20 µm | ± 20 µm | ± 25 µm | ± 25 µm | ± 25 µm | ± 30 µm | ± 30 µm | ± 30 µm | ± 35 µm | ± 35 µm | ± 35 µm | ± 20 µm | ± 20 µm | ± 20 µm | ± 25 µm | ± 25 µm | ± 25 µm | ± 30 µm | ± 30 µm | ± 30 µm | ± 30 µm | ± 35 µm | ± 35 µm | ± 35 µm | ± 20 µm | ± 20 µm | ± 20 µm | ± 25 µm | ± 25 µm | ± 25 µm | ± 30 µm | ± 30 µm | ± 30 µm | ± 35 µm | ± 35 µm | ± 35 µm | max. |
| Bidirectional repeatability in X | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | ± 5 µm | max. |
| Limit switches | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | Inductive, N/C contact,, 5 V, NPN | |
| Integrated sensor | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Absolute rotary encoder, multi-turn | Absolute rotary encoder, multi-turn | Absolute rotary encoder, multi-turn | Absolute rotary encoder, multi-turn | Absolute rotary encoder, multi-turn | Absolute rotary encoder, multi-turn | Absolute rotary encoder, multi-turn | Absolute rotary encoder, multi-turn | Absolute rotary encoder, multi-turn | Absolute rotary encoder, multi-turn | Absolute rotary encoder, multi-turn | Absolute rotary encoder, multi-turn | |||||||||||||
| Motor encoder: Sensor signal | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | BiSS-C | BiSS-C | BiSS-C | BiSS-C | BiSS-C | BiSS-C | BiSS-C | BiSS-C | BiSS-C | BiSS-C | BiSS-C | BiSS-C | |||||||||||||
| Resolution, motor encoder | 10000 Cts./rev. | 10000 Cts./rev. | 10000 Cts./rev. | 10000 Cts./rev. | 10000 Cts./rev. | 10000 Cts./rev. | 10000 Cts./rev. | 10000 Cts./rev. | 10000 Cts./rev. | 10000 Cts./rev. | 10000 Cts./rev. | 10000 Cts./rev. | 10000 Cts./rev. | |||||||||||||||||||||||||
| Resolution, motor encoder, bit width | 24 bit | 24 bit | 24 bit | 24 bit | 24 bit | 24 bit | 24 bit | 24 bit | 24 bit | 24 bit | 24 bit | 24 bit | ||||||||||||||||||||||||||
| Number of revolutions, motor encoder, bit width | 12 bit | 12 bit | 12 bit | 12 bit | 12 bit | 12 bit | 12 bit | 12 bit | 12 bit | 12 bit | 12 bit | 12 bit | ||||||||||||||||||||||||||
| Drive Properties | L-812.051400 | L-812.051400B | L-812.051400BF | L-812.091400 | L-812.091400B | L-812.091400BF | L-812.171400 | L-812.171400B | L-812.171400BF | L-812.251400 | L-812.251400B | L-812.251400BF | L-812.059432 | L-812.059432B | L-812.059432BF | L-812.099432 | L-812.099432B | L-812.099432BF | L-812.139432 | L-812.179432 | L-812.179432B | L-812.179432BF | L-812.259432 | L-812.259432B | L-812.259432BF | L-812.059453 | L-812.059453B | L-812.059453BF | L-812.099453 | L-812.099453B | L-812.099453BF | L-812.179453 | L-812.179453B | L-812.179453BF | L-812.259453 | L-812.259453B | L-812.259453BF | Tolerance |
| Drive type | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | Synchronous servo motor | |
| Maximum power consumption | 10 W | 10 W | 10 W | 10 W | 10 W | 10 W | 10 W | 10 W | 10 W | 10 W | 10 W | 10 W | ||||||||||||||||||||||||||
| Motor resolution | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | ||||||||||||||||||||||||||
| Nominal voltage | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | 310 V | |
| Nominal current, RMS | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | 1.5 A | typ. |
| Peak current, RMS | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.2 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | 4.5 A | typ. |
| Drive force in positive direction of motion in X | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | typ. |
| Drive force in negative direction of motion in X | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 377 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | 800 N | typ. |
| Resistance phase-phase | 0.5 Ω | 0.5 Ω | 0.5 Ω | 0.5 Ω | 0.5 Ω | 0.5 Ω | 0.5 Ω | 0.5 Ω | 0.5 Ω | 0.5 Ω | 0.5 Ω | 0.5 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω | 10.1 Ω |
3D Modeller
Veri Sayfası
Dokümantasyon
x
Teklif Listesi
Teklif listeniz şu anda boş.
x
0
0
Whatsapp
Döküman Talebi
İndirme listeniz şu anda boş.
|