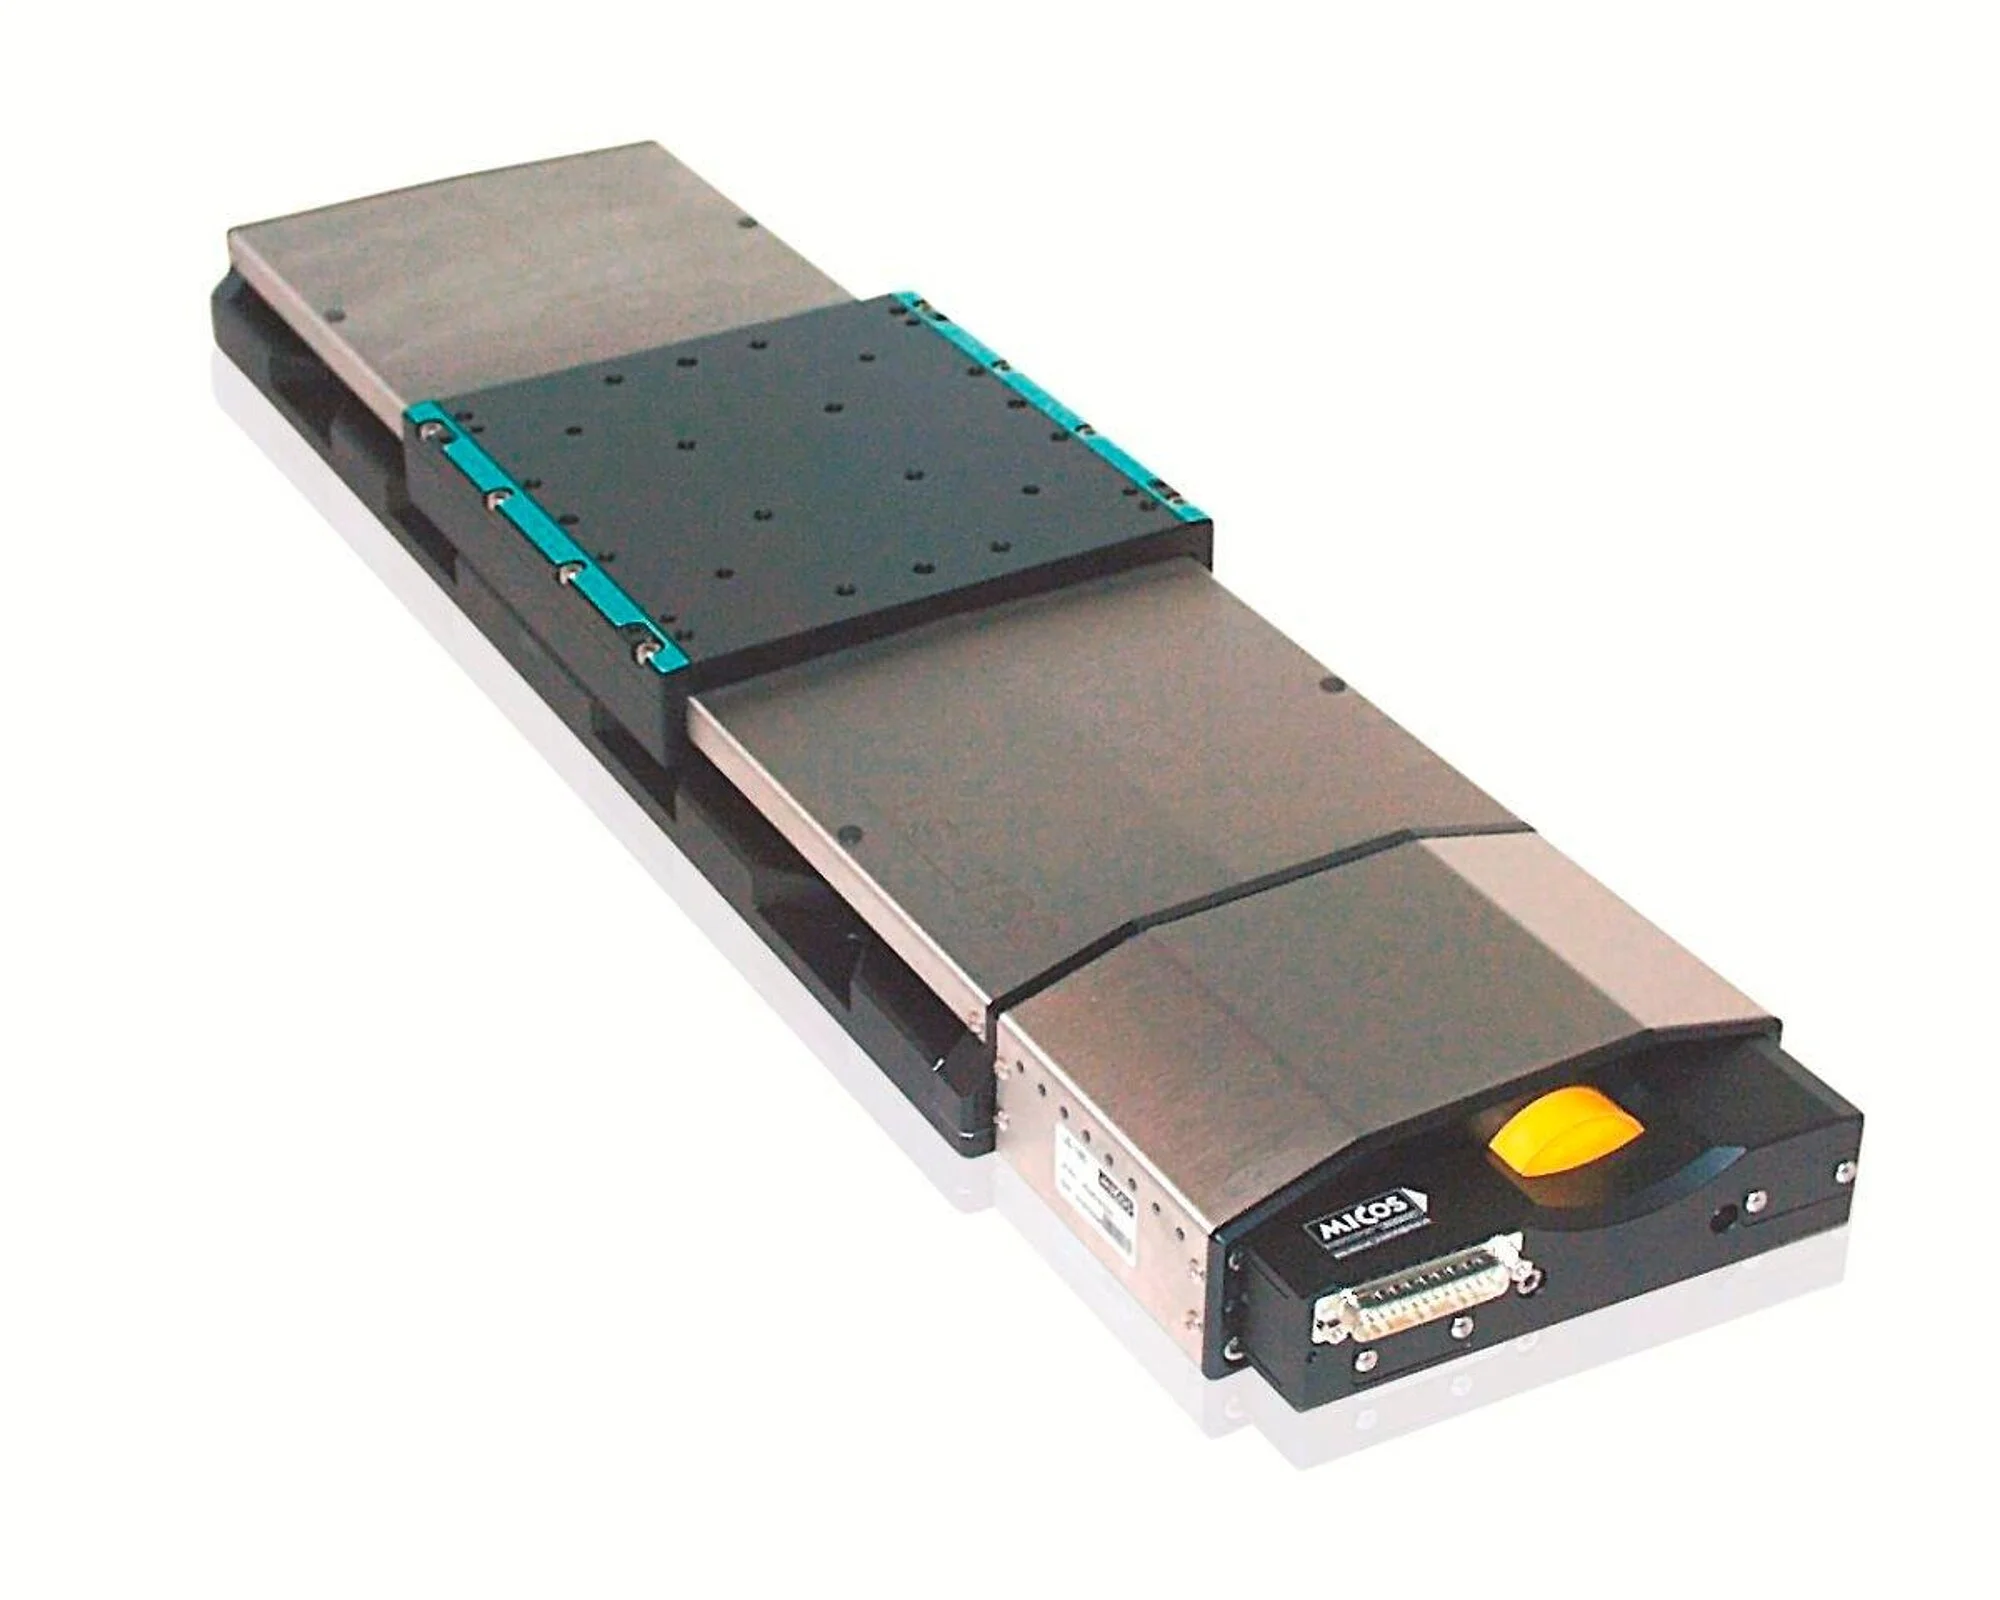
High travel accuracy and load capacity thanks to recirculating ball bearing guides. Precision ball screw with 5 mm pitch. Stress-relieved aluminum base for high stability. Noncontact inductive limit switches.
Noncontact optical linear encoders measure the position directly at the platform with the greatest accuracy. Nonlinearity, mechanical play or elastic deformation have no influence on the measurement.
When carefully assembled, recirculating ball bearing guides are distinguished by a beneficial combination of high load capacity, lifetime, maintenance-free operation, and guide accuracy. The moving part of the stages is supported by four preloaded recirculating ball bearing units, which run on two guide rails. Each bearing unit is made up of two independent rows of circulating ball bearings.
In conjunction with the SMC Hydra controller, versions with stepper motor and integrated linear encoder achieve repeatable minimum incremental motion in the range of the sensor resolution. The same configuration achieves constant low velocities of a few sensor increments per second.
Sample inspection. Scanning. Research. Semiconductor technology.
| Motion | 62409110 | 62409120 | 62409130 | 62409150 | 62409111 | 62409121 | 62409131 | 62409151 | 62409210-0000 | 62409220 | 62409230-0000 | 62409250 | 62409211-0001 | 62409221-0001 | 62409231-0001 | 62409251-0001 | Tolerance |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Active axes | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | X | |
| Travel range in X | 155 mm | 205 mm | 305 mm | 508 mm | 155 mm | 205 mm | 305 mm | 508 mm | 155 mm | 205 mm | 305 mm | 508 mm | 155 mm | 205 mm | 305 mm | 508 mm | |
| Maximum velocity in X, unloaded | 150 mm/s | 150 mm/s | 150 mm/s | 150 mm/s | 150 mm/s | 150 mm/s | 150 mm/s | 150 mm/s | 75 mm/s | 75 mm/s | 75 mm/s | 75 mm/s | 75 mm/s | 75 mm/s | 75 mm/s | 75 mm/s | |
| Straightness (Linear crosstalk in Y with motion in X) | ± 2 µm | ± 3 µm | ± 4 µm | ± 6 µm | ± 2 µm | ± 3 µm | ± 4 µm | ± 6 µm | ± 2 µm | ± 3 µm | ± 4 µm | ± 6 µm | ± 2 µm | ± 3 µm | ± 4 µm | ± 6 µm | typ. |
| Flatness (Linear crosstalk in Z with motion in X) | ± 2 µm | ± 3 µm | ± 4 µm | ± 6 µm | ± 2 µm | ± 3 µm | ± 4 µm | ± 6 µm | ± 2 µm | ± 3 µm | ± 4 µm | ± 6 µm | ± 2 µm | ± 3 µm | ± 4 µm | ± 6 µm | typ. |
| Pitch (Rotational crosstalk in θY with motion in X) | ± 40 µrad | ± 50 µrad | ± 60 µrad | ± 80 µrad | ± 40 µrad | ± 50 µrad | ± 60 µrad | ± 80 µrad | ± 40 µrad | ± 50 µrad | ± 60 µrad | ± 80 µrad | ± 40 µrad | ± 50 µrad | ± 60 µrad | ± 80 µrad | typ. |
| Yaw (Rotational crosstalk in θZ with motion in X) | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | ± 50 µrad | typ. |
| Positioning | 62409110 | 62409120 | 62409130 | 62409150 | 62409111 | 62409121 | 62409131 | 62409151 | 62409210-0000 | 62409220 | 62409230-0000 | 62409250 | 62409211-0001 | 62409221-0001 | 62409231-0001 | 62409251-0001 | Tolerance |
| Integrated sensor | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder | Incremental linear encoder | |||||
| Unidirectional repeatability in X | 0.5 µm | 0.5 µm | 0.5 µm | 0.5 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.5 µm | 0.5 µm | 0.5 µm | 0.5 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | typ. |
| Bidirectional repeatability in X | ± 2.5 µm | ± 2.5 µm | ± 2.5 µm | ± 2.5 µm | ± 0.1 µm | ± 0.1 µm | ± 0.1 µm | ± 0.1 µm | ± 2.5 µm | ± 2.5 µm | ± 2.5 µm | ± 2.5 µm | ± 0.1 µm | ± 0.1 µm | ± 0.1 µm | ± 0.1 µm | typ. |
| Minimum incremental motion in X | 0.5 µm | 0.5 µm | 0.5 µm | 0.5 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.5 µm | 0.5 µm | 0.5 µm | 0.5 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | typ. |
| Sensor signal | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | Sin/cos, 1 V peak-peak | Sin/cos, 1 V peak-peak | Sin/cos, 1 V peak-peak | Sin/cos, 1 V peak-peak | |||||
| Sensor resolution | 20000 Cts./rev. | 20000 Cts./rev. | 20000 Cts./rev. | 20000 Cts./rev. | |||||||||||||
| Limit switches | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | Inductive, N/C contact, 10 V to 30 V, PNP | |
| Sensor resolution | 50 nm | 50 nm | 50 nm | 50 nm | |||||||||||||
| Reference switch | Encoder index | Encoder index | Encoder index | Encoder index | Encoder index | Encoder index | Encoder index | Encoder index | |||||||||
| Motor encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | |||||||||||||
| Resolution, motor encoder | 20000 Cts./rev. | 20000 Cts./rev. | 20000 Cts./rev. | 20000 Cts./rev. | |||||||||||||
| Motor encoder: Sensor signal | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | |||||||||||||
| Sensor signal period | 20 µm | 20 µm | 20 µm | 20 µm | |||||||||||||
| Drive Properties | 62409110 | 62409120 | 62409130 | 62409150 | 62409111 | 62409121 | 62409131 | 62409151 | 62409210-0000 | 62409220 | 62409230-0000 | 62409250 | 62409211-0001 | 62409221-0001 | 62409231-0001 | 62409251-0001 | Tolerance |
| Drive type | DC motor | DC motor | DC motor | DC motor | DC motor | DC motor | DC motor | DC motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | |
| Nominal voltage | 24 V | 24 V | 24 V | 24 V | 24 V | 24 V | 24 V | 24 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | |
| Peak voltage | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | |
| Peak current, RMS | 3.8 A | 3.8 A | 3.8 A | 3.8 A | 3.8 A | 3.8 A | 3.8 A | 3.8 A | 2 A | 2 A | 2 A | 2 A | 2 A | 2 A | typ. | ||
| Drive force in positive direction of motion in X | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | typ. |
| Drive force in negative direction of motion in X | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | 200 N | typ. |
| Time constant | 6 ms | 6 ms | 6 ms | 6 ms | 6 ms | 6 ms | 6 ms | 6 ms | |||||||||
| Resistance phase-phase | 0.62 Ω | 0.62 Ω | 0.62 Ω | 0.62 Ω | 0.62 Ω | 0.62 Ω | 0.62 Ω | 0.62 Ω | 2.4 Ω | 2.4 Ω | 2.4 Ω | 2.4 Ω | 2.4 Ω | 2.4 Ω | 2.4 Ω | 2.4 Ω | typ. |
| Inductance phase-phase | 0.13 mH | 0.13 mH | 0.13 mH | 0.13 mH | 0.13 mH | 0.13 mH | 0.13 mH | 0.13 mH | 2.87 mH | 2.87 mH | 2.87 mH | 2.87 mH | 2.87 mH | 2.87 mH | 2.87 mH | 2.87 mH | |
| Back EMF, phase-phase, rotational | 0.0035 V/kRPM | 0.0035 V/kRPM | 0.0035 V/kRPM | 0.0035 V/kRPM | 0.0035 V/kRPM | 0.0035 V/kRPM | 0.0035 V/kRPM | 0.0035 V/kRPM | max. | ||||||||
| Motor resolution | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | |||||||||
| Nominal current, RMS | 2 A | 2 A | 2 A | 2 A | typ. | ||||||||||||
| Mechanical Properties | 62409110 | 62409120 | 62409130 | 62409150 | 62409111 | 62409121 | 62409131 | 62409151 | 62409210-0000 | 62409220 | 62409230-0000 | 62409250 | 62409211-0001 | 62409221-0001 | 62409231-0001 | 62409251-0001 | Tolerance |
| Guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | Recirculating ball bearing guide | |
| Drive screw type | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | |
| Drive screw pitch | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | 5 mm | |
| Holding force in X, passive | 20 N | 20 N | 20 N | 20 N | 20 N | 20 N | 20 N | 20 N | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | |
| Moved mass in X, unloaded | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | 2.2 g | |
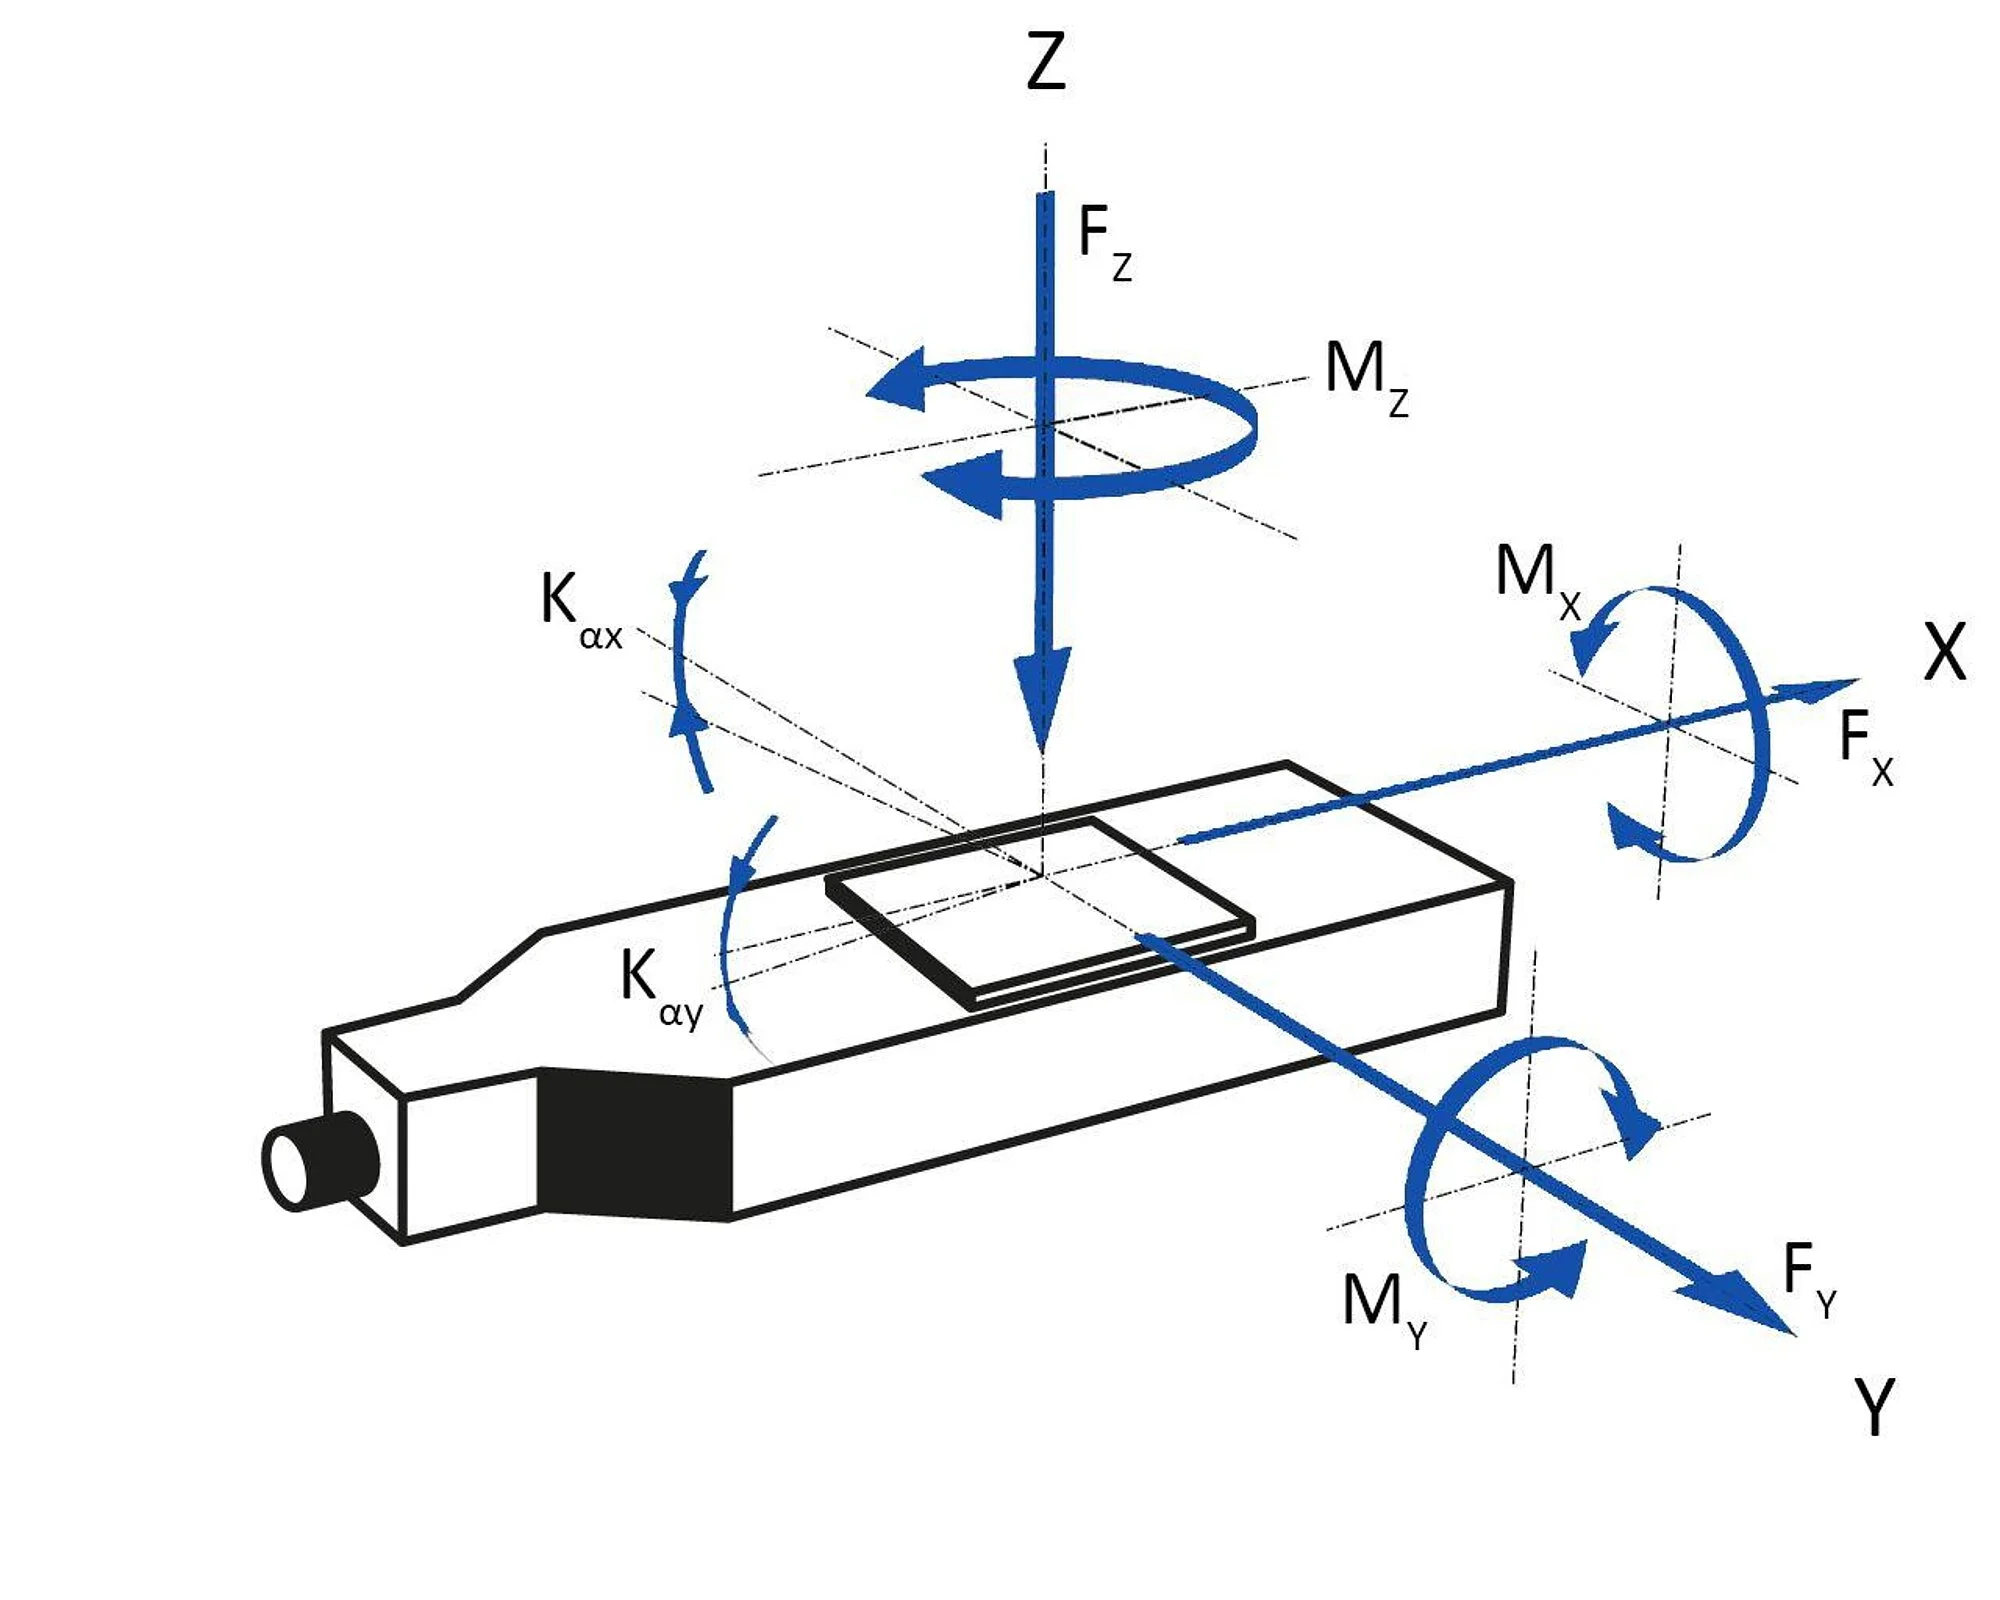
| Permissible push force in Y | 500 N | 500 N | 500 N | 500 N | 500 N | 500 N | 500 N | 500 N | 500 N | 500 N | 500 N | 500 N | 500 N | 500 N | 500 N | 500 N | max. |
| Permissible push force in Z | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | 1000 N | max. |
| Permissible torque in θx | 250 N·m | 250 N·m | 250 N·m | 250 N·m | 250 N·m | 250 N·m | 250 N·m | 250 N·m | 250 N·m | 250 N·m | 250 N·m | 250 N·m | 2500 N·m | 250 N·m | 250 N·m | 250 N·m | max. |
| Permissible torque in θY | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | 132 N·m | max. |
| Permissible torque in θZ | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | 125 N·m | max. |
| Overall mass | 7800 g | 8400 g | 9400 g | 10600 g | 8500 g | 9100 g | 10300 g | 11500 g | 8300 g | 8900 g | 9900 g | 11000 g | 9000 g | 9600 g | 10800 g | 12000 g | |
| Material | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | Aluminum, steel | |
| Miscellaneous | 62409110 | 62409120 | 62409130 | 62409150 | 62409111 | 62409121 | 62409131 | 62409151 | 62409210-0000 | 62409220 | 62409230-0000 | 62409250 | 62409211-0001 | 62409221-0001 | 62409231-0001 | 62409251-0001 | Tolerance |
| Operating temperature range | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 0 to 55 °C | 0 to 55 °C | 0 to 55 °C | 0 to 55 °C | |
| Connector | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | D-sub 25-pin (m) | |
| Recommended controllers / drivers | C-863 with C-863.AD11 Line driver, C-884 with C-863.AD11 Line driver, C-885 with C-863.20C885 and C-863.AD11 Line driver, Modular ACS controller | C-863 with C-863.AD11 Line driver, C-884 with C-863.AD11 Line driver, C-885 with C-863.20C885 and C-863.AD11 Line driver, Modular ACS controller | C-863 with C-863.AD11 Line driver, C-884 with C-863.AD11 Line driver, C-885 with C-863.20C885 and C-863.AD11 Line driver, Modular ACS controller | C-863 with C-863.AD11 Line driver, C-884 with C-863.AD11 Line driver, C-885 with C-863.20C885 and C-863.AD11 Line driver, Modular ACS controller | C-863 with C-863.AD11 Line driver, C-884 with C-863.AD11 Line driver, C-885 with C-863.20C885 and C-863.AD11 Line driver, Modular ACS controller | C-863 with C-863.AD11 Line driver, C-884 with C-863.AD11 Line driver, C-885 with C-863.20C885 and C-863.AD11 Line driver, Modular ACS controller | C-863 with C-863.AD11 Line driver, C-884 with C-863.AD11 Line driver, C-885 with C-863.20C885 and C-863.AD11 Line driver, Modular ACS controller | C-863 with C-863.AD11 Line driver, C-884 with C-863.AD11 Line driver, C-885 with C-863.20C885 and C-863.AD11 Line driver, Modular ACS controller | C-663.12, C-885 with C-663.12C885, Modular ACS controller | C-663.12, C-885 with C-663.12C885, Modular ACS controller | C-663.12, C-885 with C-663.12C885, Modular ACS controller | C-663.12, C-885 with C-663.12C885, Modular ACS controller | C-663.12, C-885 with C-663.12C885, Modular ACS controller | C-663.12, C-885 with C-663.12C885, Modular ACS controller | C-663.12, C-885 with C-663.12C885, Modular ACS controller | C-663.12, C-885 with C-663.12C885, Modular ACS controller | |
| Sensor connector | D-sub 9-pin (m) | D-sub 9-pin (m) | D-sub 9-pin (m) | D-sub 9-pin (m) | D-sub 9-pin (m) | D-sub 9-pin (m) | D-sub 9-pin (m) | D-sub 9-pin (m) |