Products PI - Hexapods Positioning Hexapods for Loads up to 250 kg
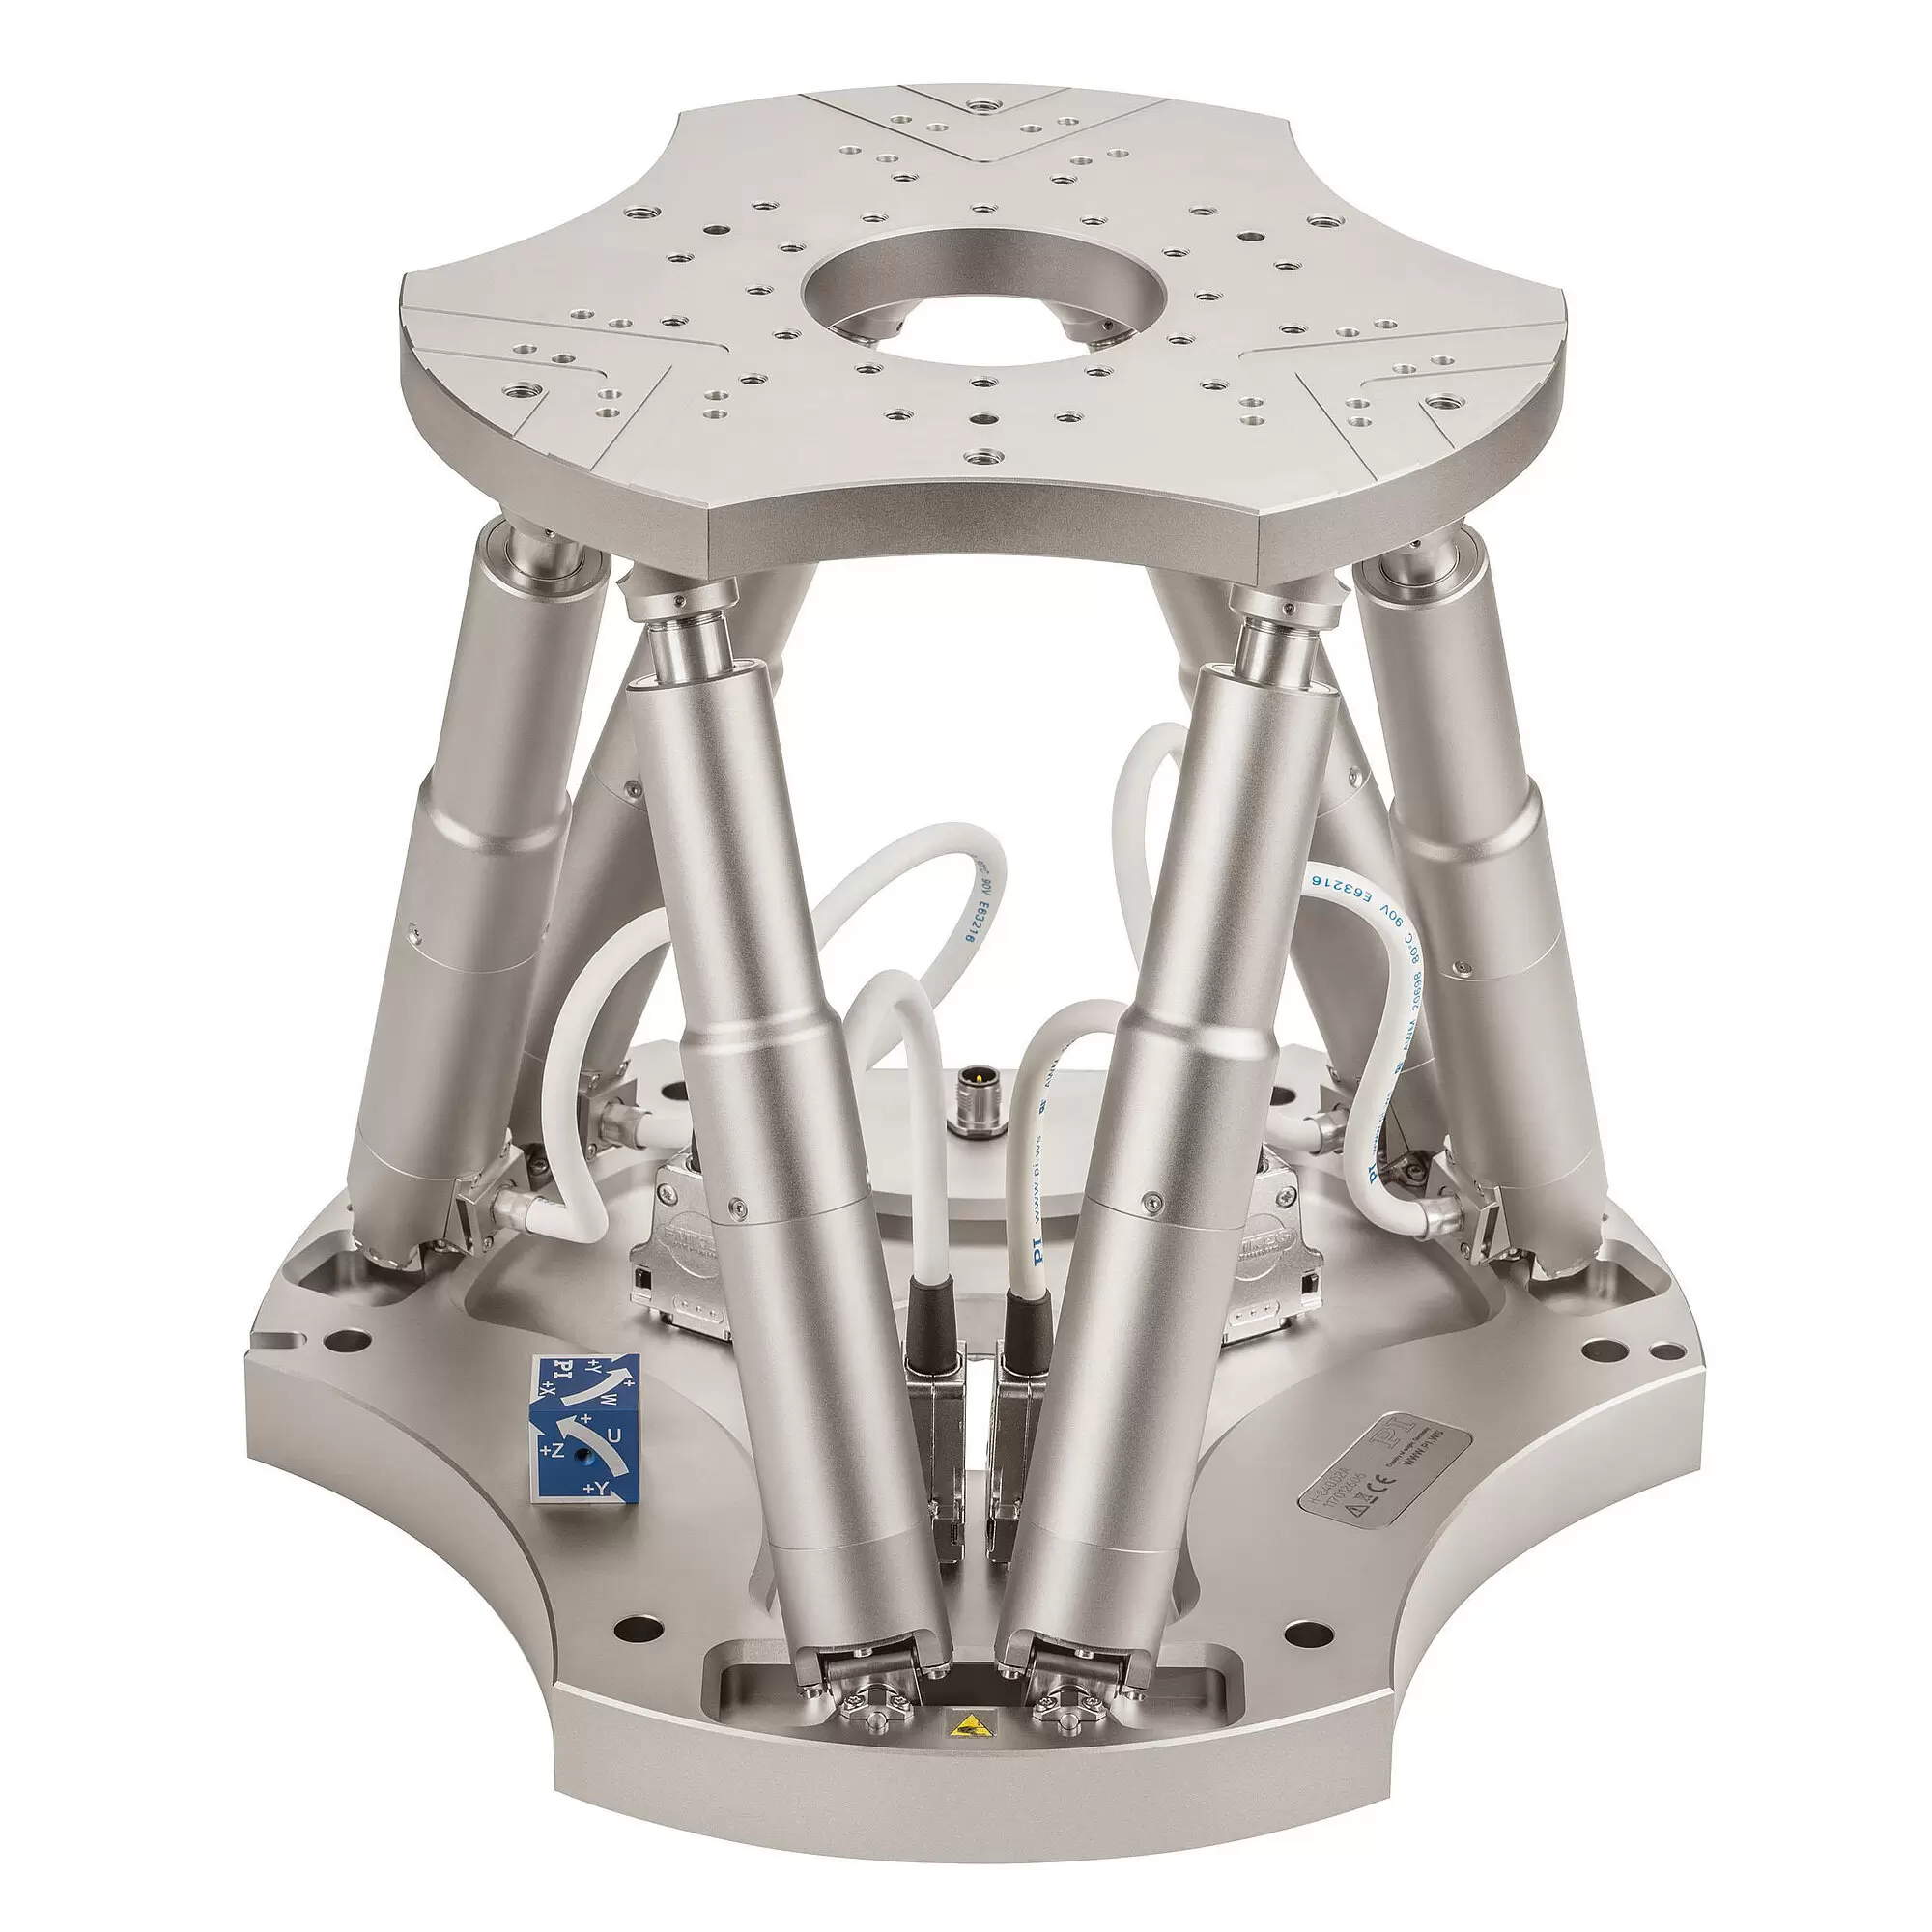
H-840 Hexapod 6-Axis Positioning System
Precise, Versatile, Fast, Excellent Value
  • Brushless motors and absolute position encoder options
  • Position repeatability to ±0.1 µm
  • Load capacity to 40 kg
  • Travel ranges to ±50 mm / ±30°
  • CIPA certified for camera tests
  • Works in any orientation

The H-840 hexapod 6-axis precision positioning system provides high resolution motion in 6 degrees of freedom. PI hexapod 6-axis stages are based on the Stewart Platform parallel kinematics principle, with 6 high performance motorized actuators working in parallel between two platforms. H-840 hexapod positioning systems come in different variants, optimized for specific motion and positioning applications. With a precision gear box deployed within each of the six actuators, the H-840.G hexapod models provide higher load capacity and higher resolution. In contrast, the H-840.D models use brushless servo motors to drive the actuators directly, provide higher dynamics and enable velocities to 60 mm/s. For applications that require even higher resolution, the H-840.G2IHP variant with minimum incremental motion to 20 nanometers is offered.

High Performance Parallel-Kinematic Micro Robot Design

H-840 high resolution hexapods are parallel-kinematic positioning systems, widely referred to as parallel kinematic machines or 6-DOF parallel micro robots. The parallel kinematics principle offers extreme versatility and a more compact and stiffer design than conventional, multi-axis positioning systems (serial kinematics or stacked stages).

Why Use Hexapod Positioning Systems?

Hexapod 6-axis positioning and motion systems provide better multi-axis accuracy repeatability than conventional stacked multi-axis stages and support greater motion profile flexibility in a compacter setting. In a stacked 6-axis stage, the bottom stage must carry the load of all 5 axes above while the lightweight moving platform of a hexapod is supported by all 6 actuators in parallel. Due to the significantly reduced moved mass, hexapod positioning systems can provide higher dynamics with a similar performance across all motion axes. Cable management is not an issue for PI H-840 hexapod positioners because all 6 actuators are connected to the stationary base platform. With only two cables to plug into the static hexapod base platform, one for power and one for position information feedback to the hexapod controller, cable management and connectivity are greatly simplified within the local applications. Unlike stacked multi-axis stages, there are no moving cables.Servo controller tuning is also easier to manage since all six hexapod actuators are identical and generally support a similar load. In most hexapod applications, users need not modify the default factory servo parameter settings on the hexapod controller.

Why Use Absolute Encoders in a High Precision Hexapod Positioning System?

H-840 6-axis hexapods are available with absolute measuring position encoders. Absolute encoders supply the correct position information to its motion controller immediately after startup, rendering referencing moves unnecessary and thus increasing efficiency and safety in case of a power outage or connectivity loss.

Four Decades of Parallel-Kinematics Motion Systems Design Experience

PI began developing parallel-kinematic nanopositioning systems over 40 years ago and was a pioneer in the early 1990s, introducing motorized, high precision 6-axis hexapod motion and positioning devices for demanding optics and astronomy applications. Today, PI is the world leading supplier of highly accurate parallel kinematic motion systems for sub-micrometer to sub-nanometer ranges, multi-axis positioning, alignment and motion applications.

Superior Mechanical Design

The H-840 mechanics employ cardanic joints with Z-offset for increased stiffness and low-friction, as well as high precision ball screws and high-resolution encoders. With several decades of innovation, our design teams have continuously optimized and refined the mechanical design.

6-Axis Motion Controller / Programming / Software

PI’s highly integrated, C-887 6-axis hexapod controller allows quick and simple operation of the H-840 hexapod systems. The user need not deal with the specific hexapod kinematics as all coordinate transformations are executed internally. As with conventional, stacked multi-axis positioning systems, all positions can be easily addressed using Cartesian coordinates. With the powerful C-887 hexapod controller and PI’s intuitive software packages, users can easily program arbitrary pivot points, a very important feature when creating alignment applications for fibers, optics, lenses or large panels. PI’s C-887 hexapod motion controller supports user-programmable coordinate systems and offers interface options that include EtherCat®, USB, Ethernet and analog inputs.

Brushless Servo Motors (BLDC) for High Duty Cycles

The six hexapod actuators are driven by brushless DC servo motors (BLDC). Unlike conventional brushed servo motors, BLDC motors do not generate particles and provide higher torque over a longer lifetime.

Manual 6-Axis Control

PI hexapods can be manually controlled over all 6 degrees of freedom using the C-887.MC2 manual control unit, a great advantage and time saver when setting up an application. This hand-held controller plugs into the hexapod controller and provides six individual knobs, one for each axis (X, Y, Z, Pitch, Yaw, Roll), similar to conventional 6-axis stages. The current position information is shown on an LCD display.

PI Hexapod Simulation Software Tool / Collision Avoidance Software

The hexapod simulation software simulates the limits of the workspace and load capacity of a hexapod, allowing users to verify that a specific hexapod model can handle the required loads, forces, and torques that occur in an application. The simulation software tool takes the position and motion of the hexapod into account as well as the pivot point and several reference coordinate systems. The C-887.VM1 software helps users avoid motion profiles that would cause the hexapod or assemblies mounted on the hexapod to collide with objects in the vicinity.

Smaller and Larger Hexapods, High Speed Hexapods

The H-840 six axis system is a mid-size hexapod for medium loads. With a wide range of standard hexapod models and multiple configuration options, PI offers the largest range of precision positioning hexapods: from palm-sized-devices such as the H-811 to large units with hundreds of kilograms of load capacity. PI hexapods are used in all kinds of applications, from micro-lens and fiber-alignment, machining and automated assembly of complex parts, and automotive to aerospace. A special voice-coil actuator hexapod is available for high precision, high-velocity motion simulation. When nanometer and sub-nanometer precision and millisecond responsiveness are required, PI offers piezo-based multi-axis nanopositioning systems, such as the PIMars 6DOF stage family.

Hexapod Applications: What Are Hexapods Used For?

H-840 hexapod 6-axis positioning systems are deployed in a wide range of industrial, automation and research applications, including micromanufacturing, micromanipulation, fiber alignment, automated optical and mechanical alignment, satellite sensor testing, optical metrology, tool inspection, X-ray diffraction, beamline sample positioning, and life sciences. The direct-drive high-speed version of the H-840 is CIPA certified for motion simulation, critical for imaging sensors and camera quality test.

Motion H-840.D2A H-840.D2I H-840.G2A H-840.G2I Tolerance
Active axes X Y Z θX θY θZ X Y Z θX θY θZ X Y Z θX θY θZ X Y Z θX θY θZ  
Travel range in X ± 50 mm ± 50 mm ± 50 mm ± 50 mm  
Travel range in Y ± 50 mm ± 50 mm ± 50 mm ± 50 mm  
Travel range in Z ± 25 mm ± 25 mm ± 25 mm ± 25 mm  
Rotation range in θX ± 15 ° ± 15 ° ± 15 ° ± 15 °  
Rotation range in θY ± 15 ° ± 15 ° ± 15 ° ± 15 °  
Rotation range in θZ ± 30 ° ± 30 ° ± 30 ° ± 30 °  
Maximum velocity in X 60 mm/s 60 mm/s 2.5 mm/s 2.5 mm/s  
Maximum velocity in Y 60 mm/s 60 mm/s 2.5 mm/s 2.5 mm/s  
Maximum velocity in Z 60 mm/s 60 mm/s 2.5 mm/s 2.5 mm/s  
Maximum angular velocity in θX 700 mrad/s 700 mrad/s 30 mrad/s 30 mrad/s  
Maximum angular velocity in θY 700 mrad/s 700 mrad/s 30 mrad/s 30 mrad/s  
Maximum angular velocity in θZ 700 mrad/s 700 mrad/s 30 mrad/s 30 mrad/s  
Typical velocity in X 40 mm/s 40 mm/s 2 mm/s 2 mm/s  
Typical velocity in Y 40 mm/s 40 mm/s 2 mm/s 2 mm/s  
Typical velocity in Z 40 mm/s 40 mm/s 2 mm/s 2 mm/s  
Typical angular velocity in θX 480 mrad/s 480 mrad/s 25 mrad/s 25 mrad/s  
Typical angular velocity in θY 480 mrad/s 480 mrad/s 25 mrad/s 25 mrad/s  
Typical angular velocity in θZ 480 mrad/s 480 mrad/s 25 mrad/s 25 mrad/s  
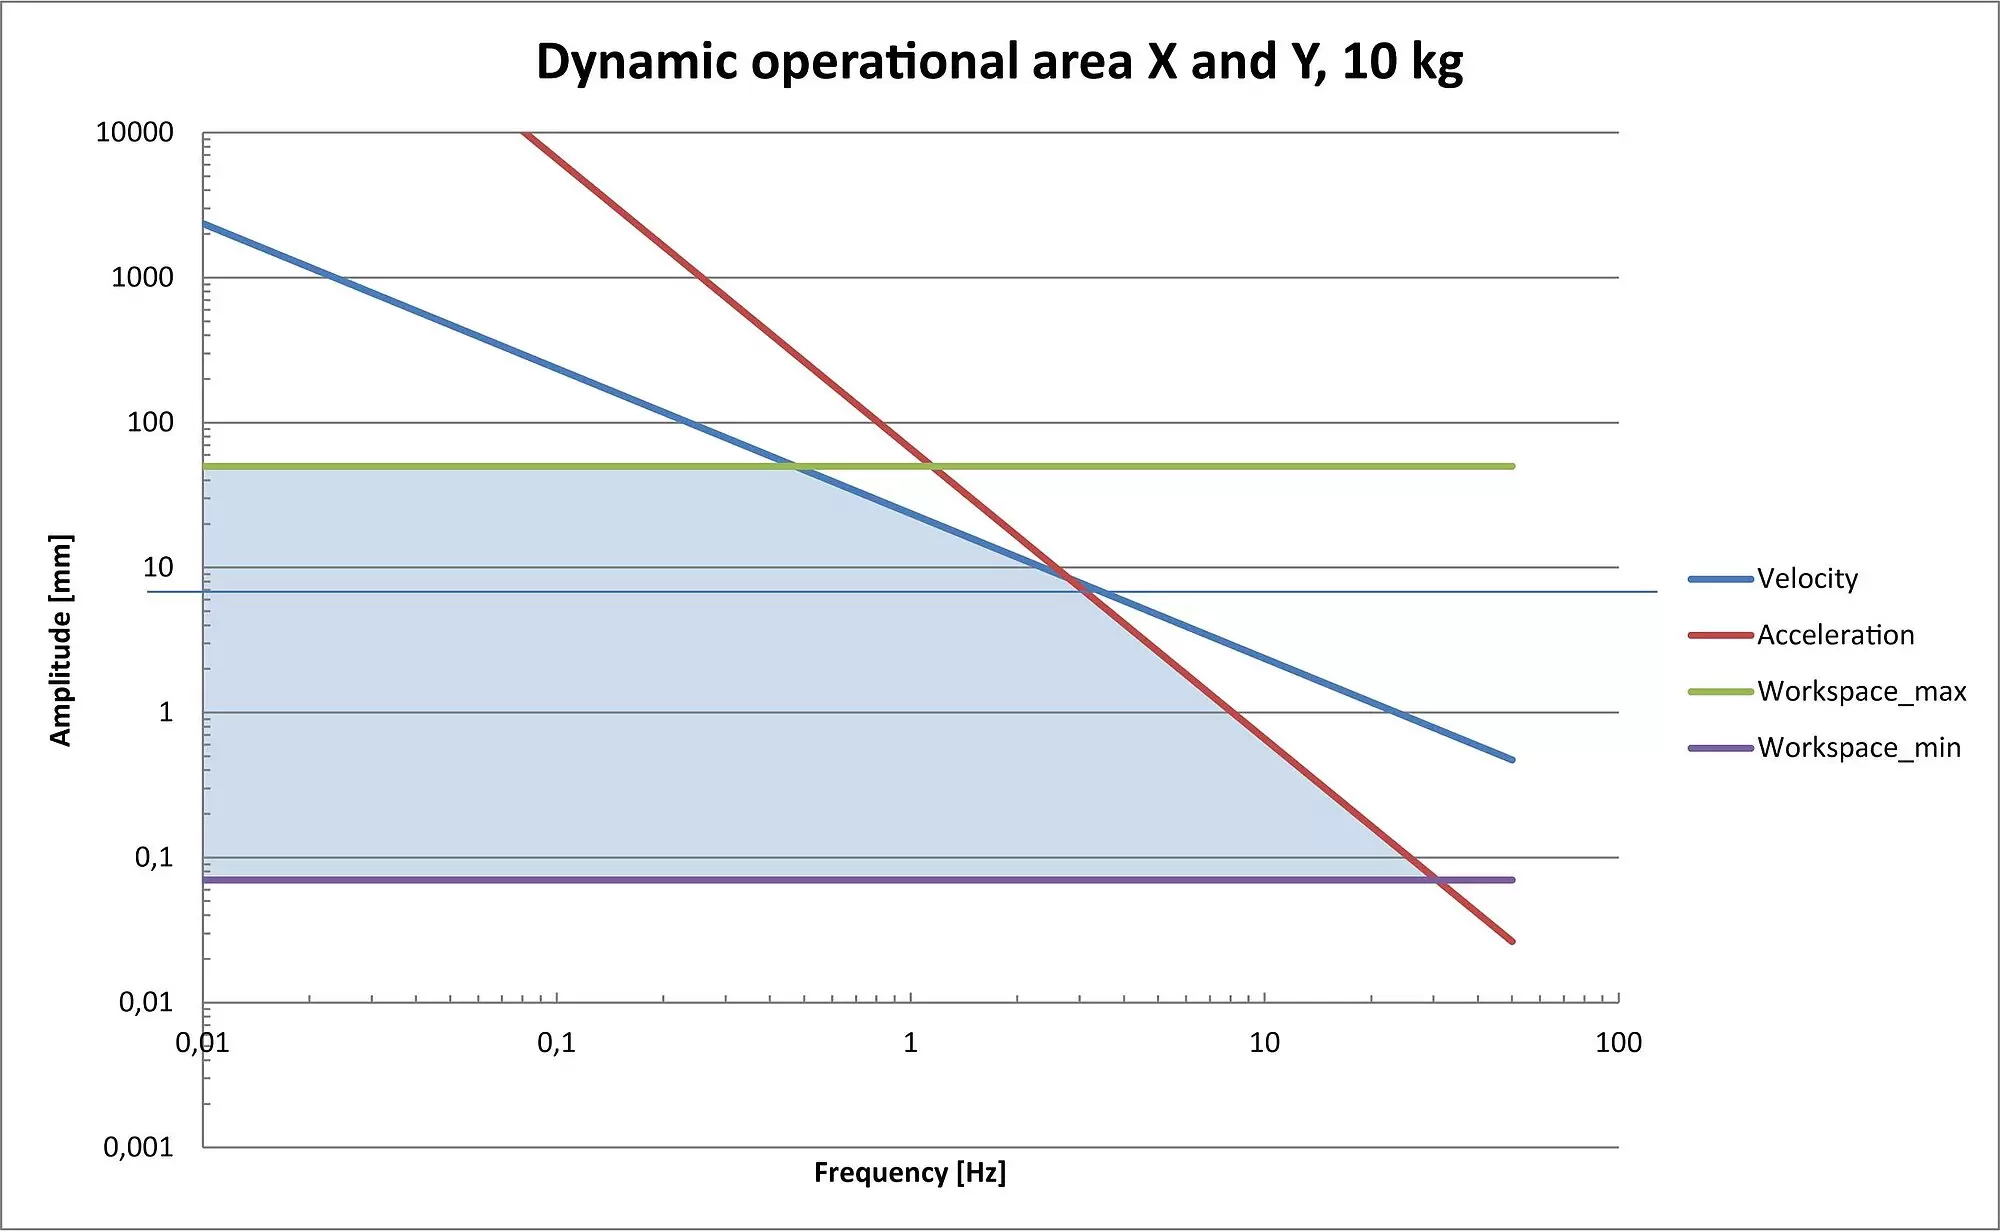
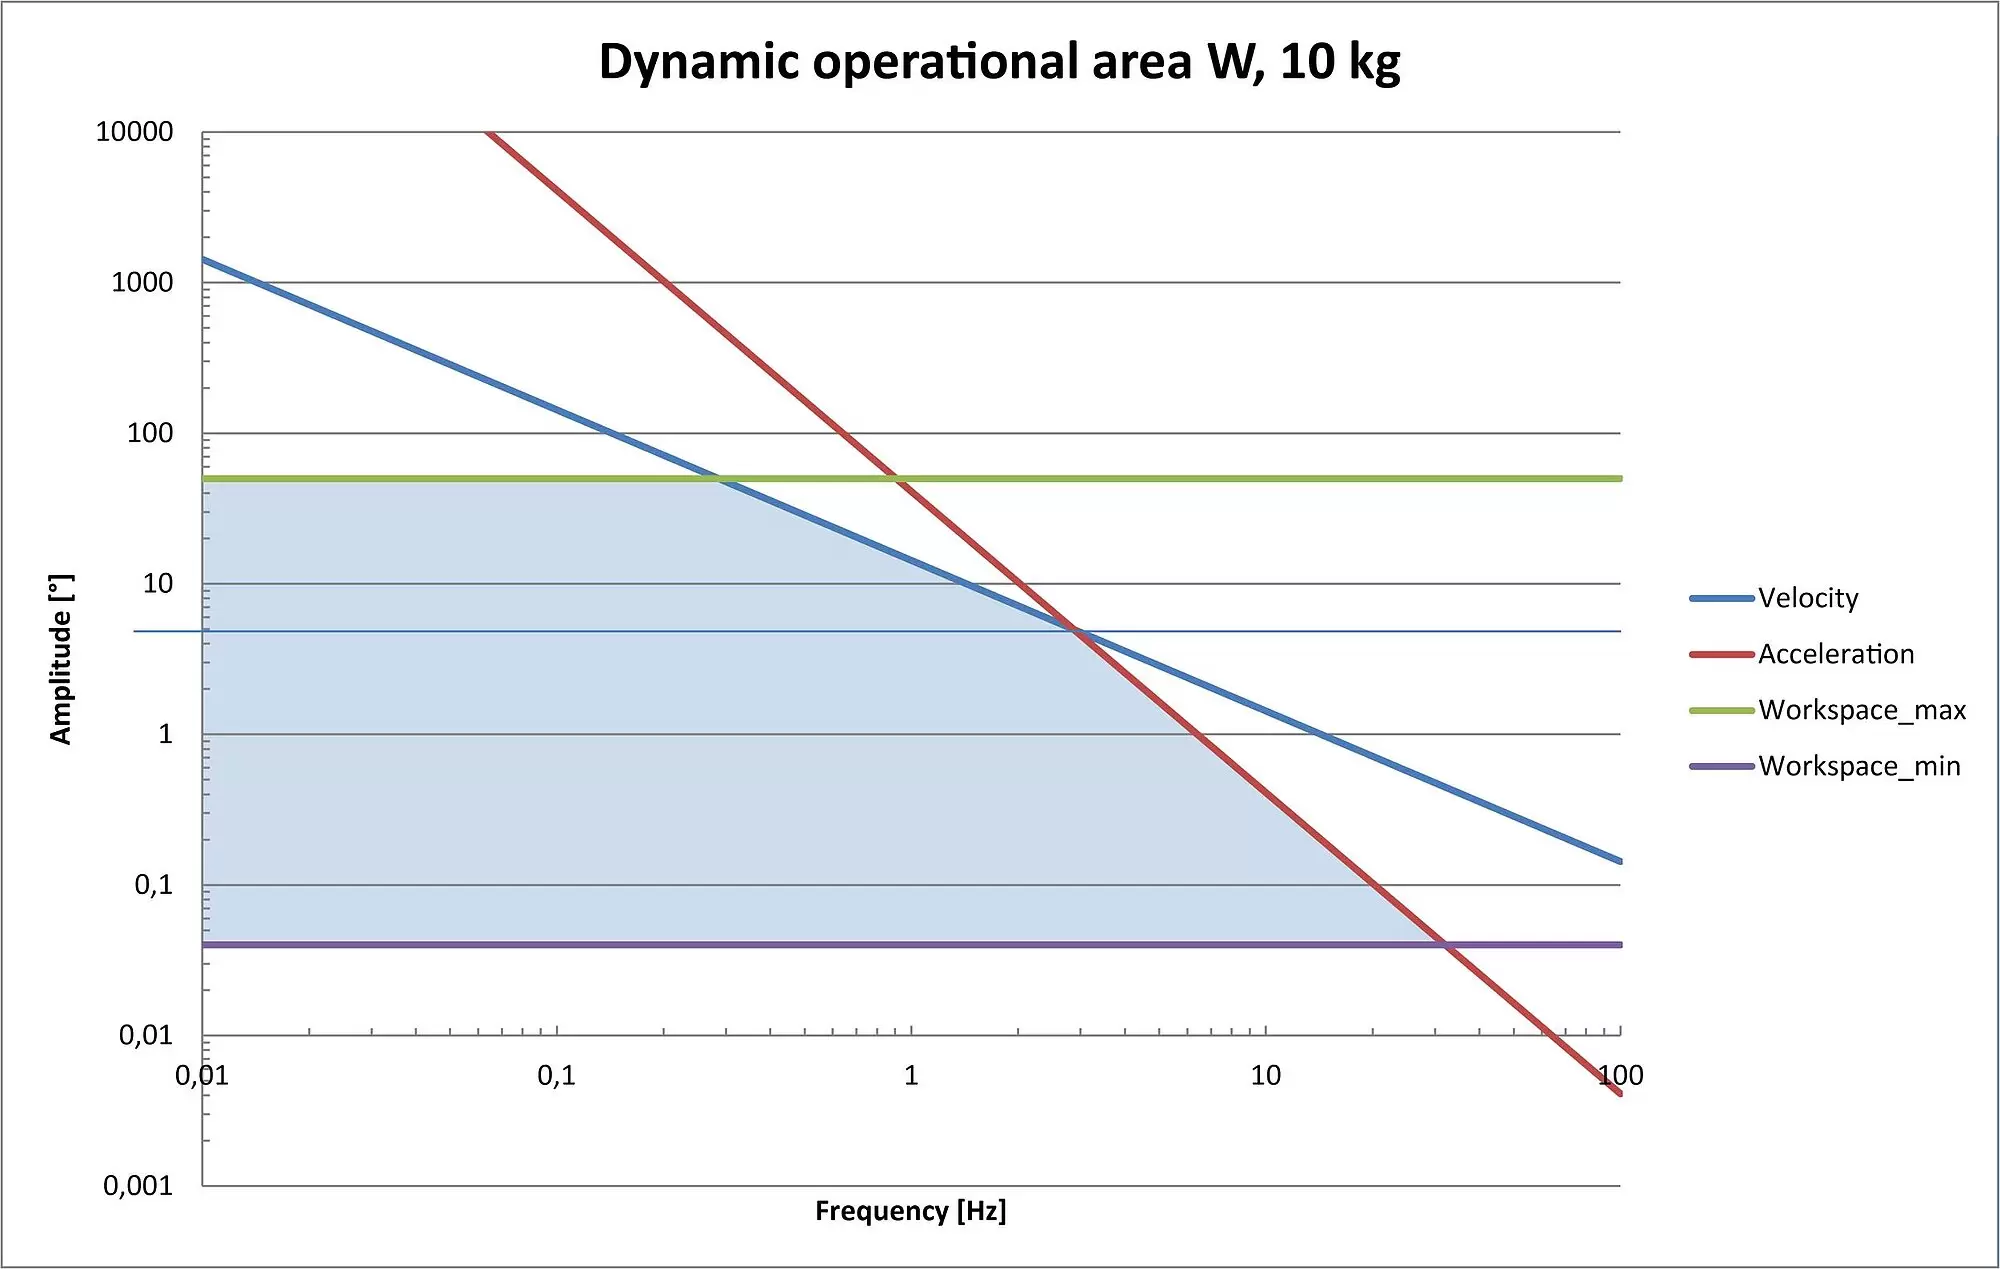
Amplitude-frequency product in X 23.6 mm·Hz 23.6 mm·Hz      
Amplitude-frequency product in Y 23.6 mm·Hz 23.6 mm·Hz      
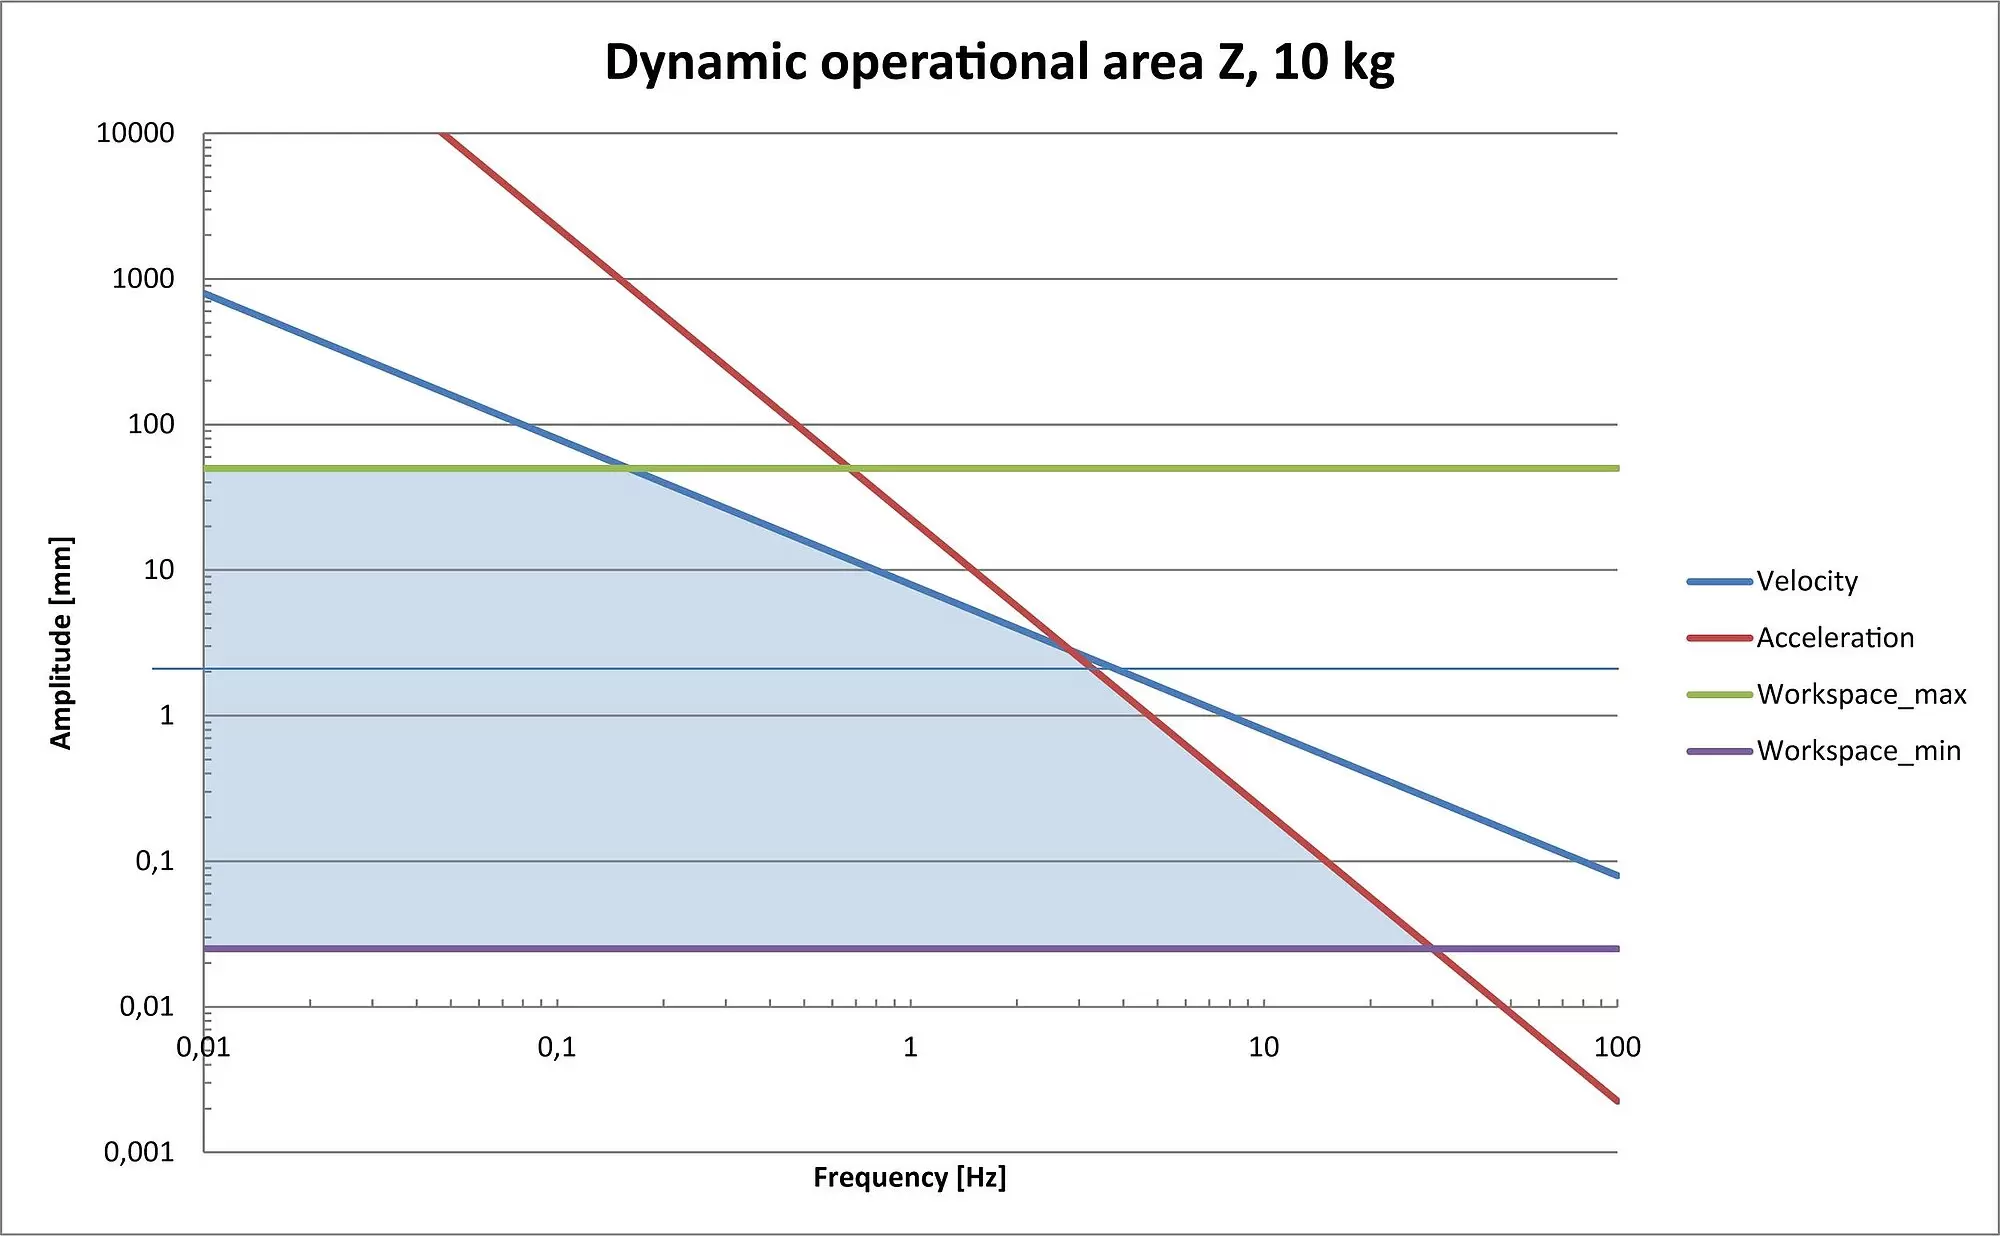
Amplitude-frequency product in Z 8 mm·Hz 8 mm·Hz      
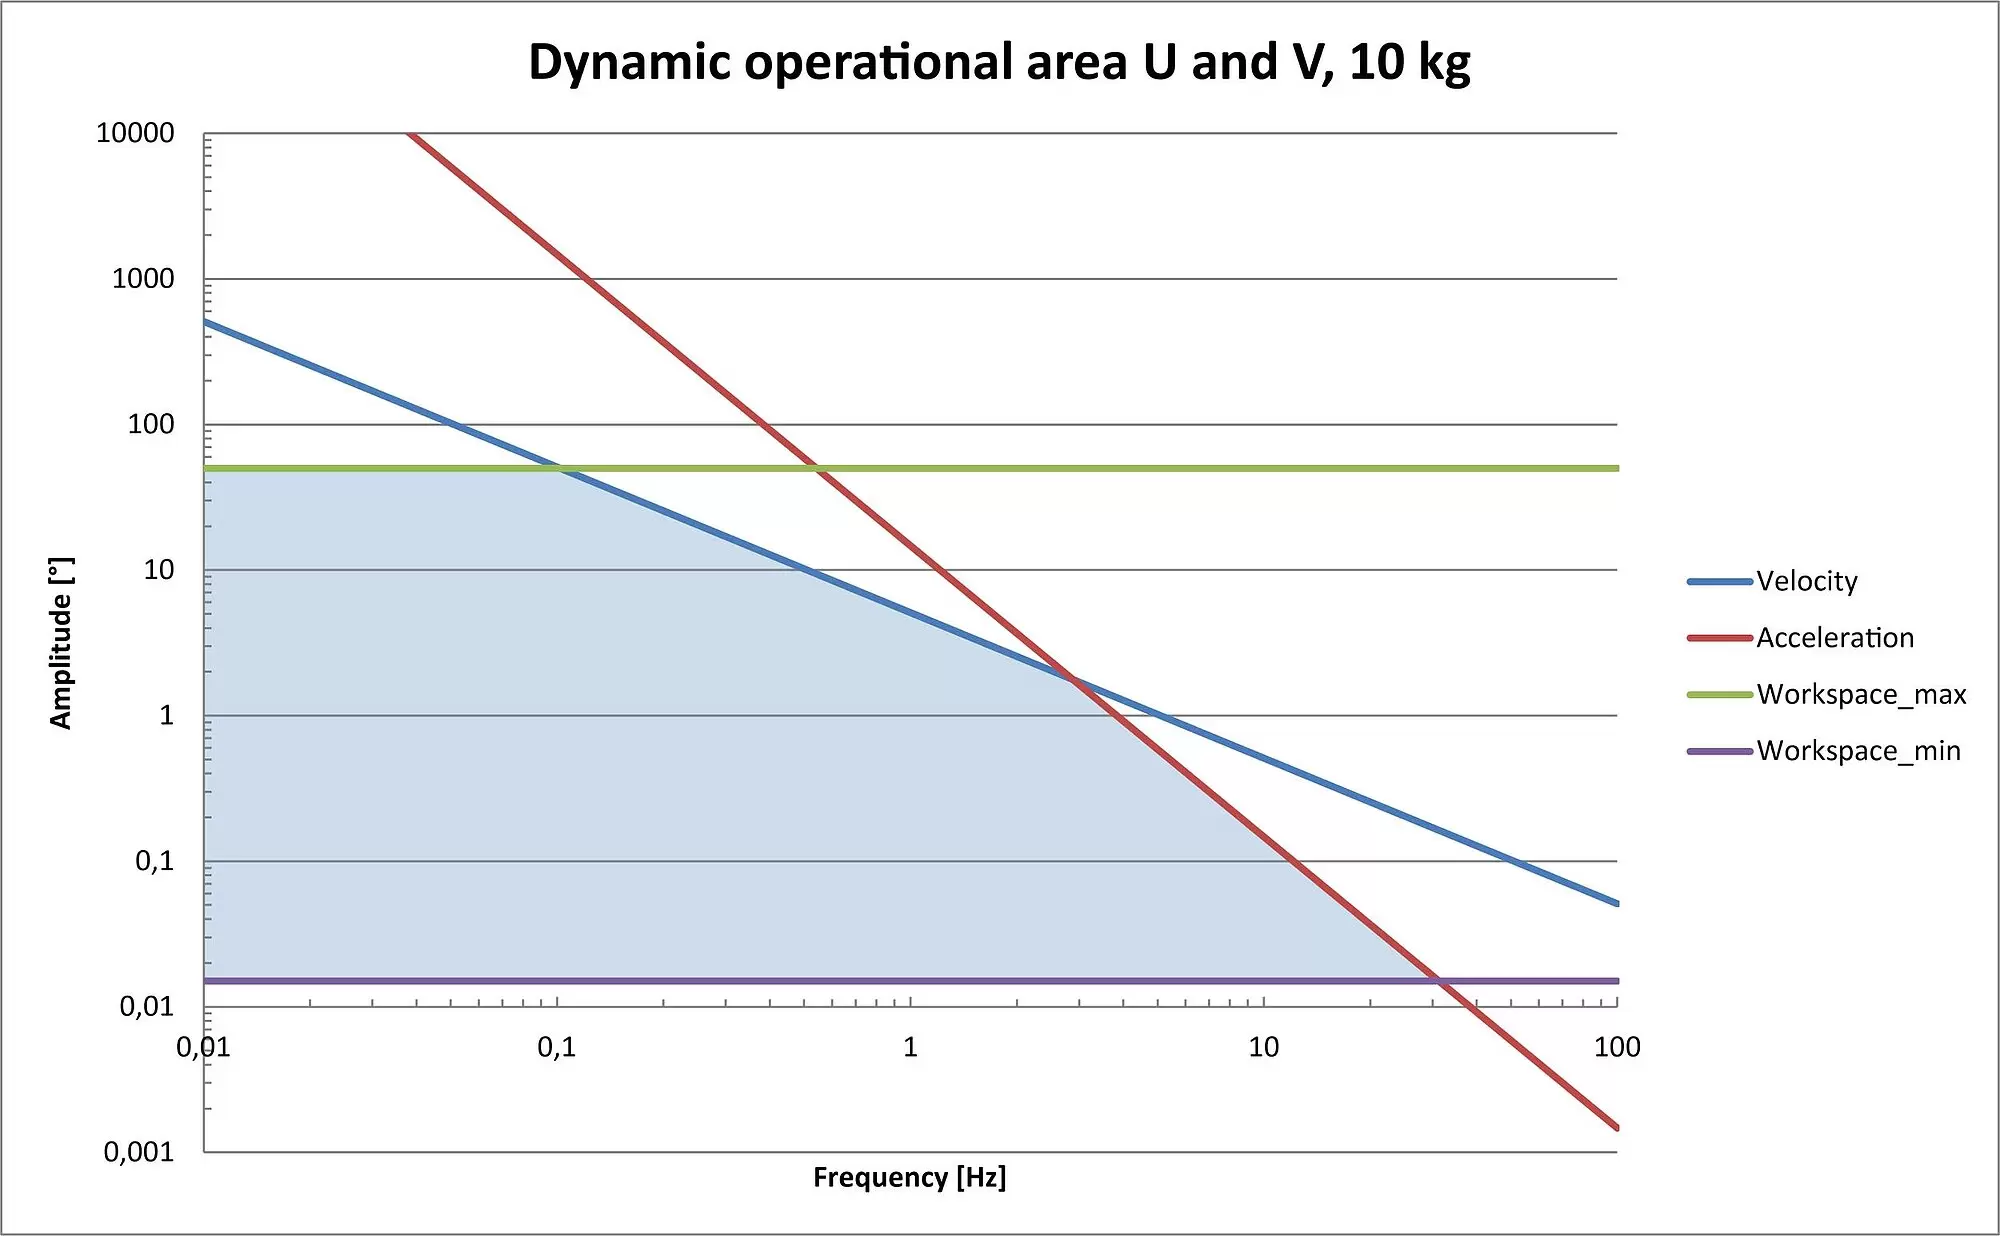
Amplitude-frequency product in θX 5.1 °·Hz 5.1 °·Hz      
Amplitude-frequency product in θY 5.1 °·Hz 5.1 °·Hz      
Amplitude-frequency product in θZ 14 °·Hz 14 °·Hz      
Amplitude-frequency² product in X 65.9 mm·Hz² 65.9 mm·Hz²      
Amplitude-frequency² product in Y 65.9 mm·Hz² 65.9 mm·Hz²      
Amplitude-frequency² product in Z 22.5 mm·Hz² 22.5 mm·Hz²      
Amplitude-frequency² product in θX 14.7 °·Hz² 14.7 °·Hz²      
Amplitude-frequency² product in θY 14.7 °·Hz² 14.7 °·Hz²      
Amplitude-frequency² product in θZ 41 °·Hz² 41 °·Hz²      
Amplitude error 10 % 10 %     max.
Phase error 60 ° 60 °     max.
Maximum frequency 30 Hz 30 Hz      
Positioning H-840.D2A H-840.D2I H-840.G2A H-840.G2I Tolerance
Integrated sensor Absolute rotary encoder, multi-turn Incremental rotary encoder Absolute rotary encoder, multi-turn Incremental rotary encoder  
Unidirectional repeatability in X ± 0.3 µm ± 0.3 µm ± 0.3 µm ± 0.3 µm typ.
Unidirectional repeatability in Y ± 0.3 µm ± 0.3 µm ± 0.3 µm ± 0.3 µm typ.
Unidirectional repeatability in Z ± 0.1 µm ± 0.1 µm ± 0.1 µm ± 0.1 µm typ.
Unidirectional repeatability in θX ± 1.5 µrad ± 1.5 µrad ± 2.5 µrad ± 2.5 µrad typ.
Unidirectional repeatability in θY ± 1.5 µrad ± 1.5 µrad ± 2.5 µrad ± 2.5 µrad typ.
Unidirectional repeatability in θZ ± 3 µrad ± 3 µrad ± 3 µrad ± 3 µrad typ.
Minimum incremental motion in X 1.5 µm 0.5 µm 0.3 µm 0.25 µm typ.
Minimum incremental motion in Y 1.5 µm 0.5 µm 0.3 µm 0.25 µm typ.
Minimum incremental motion in Z 1 µm 0.25 µm 0.2 µm 0.15 µm typ.
Minimum incremental motion in θX 10 µrad 3 µrad 2 µrad 2 µrad typ.
Minimum incremental motion in θY 10 µrad 3 µrad 2 µrad 2 µrad typ.
Minimum incremental motion in θZ 2 µrad 5 µrad 4 µrad 4 µrad typ.
Backlash in X 1.5 µm 1.5 µm 2 µm 2 µm typ.
Backlash in Y 1.5 µm 1.5 µm 2 µm 2 µm typ.
Backlash in Z 0.2 µm 0.25 µm 0.3 µm 0.3 µm typ.
Backlash in θX 4 µrad 4 µrad 5 µrad 5 µrad typ.
Backlash in θY 4 µrad 4 µrad 5 µrad 5 µrad typ.
Backlash in θZ 8 µrad 8 µrad 10 µrad 10 µrad typ.
Drive Properties H-840.D2A H-840.D2I H-840.G2A H-840.G2I Tolerance
Drive type Brushless DC motor Brushless DC motor Brushless DC gear motor Brushless DC gear motor  
Mechanical Properties H-840.D2A H-840.D2I H-840.G2A H-840.G2I Tolerance
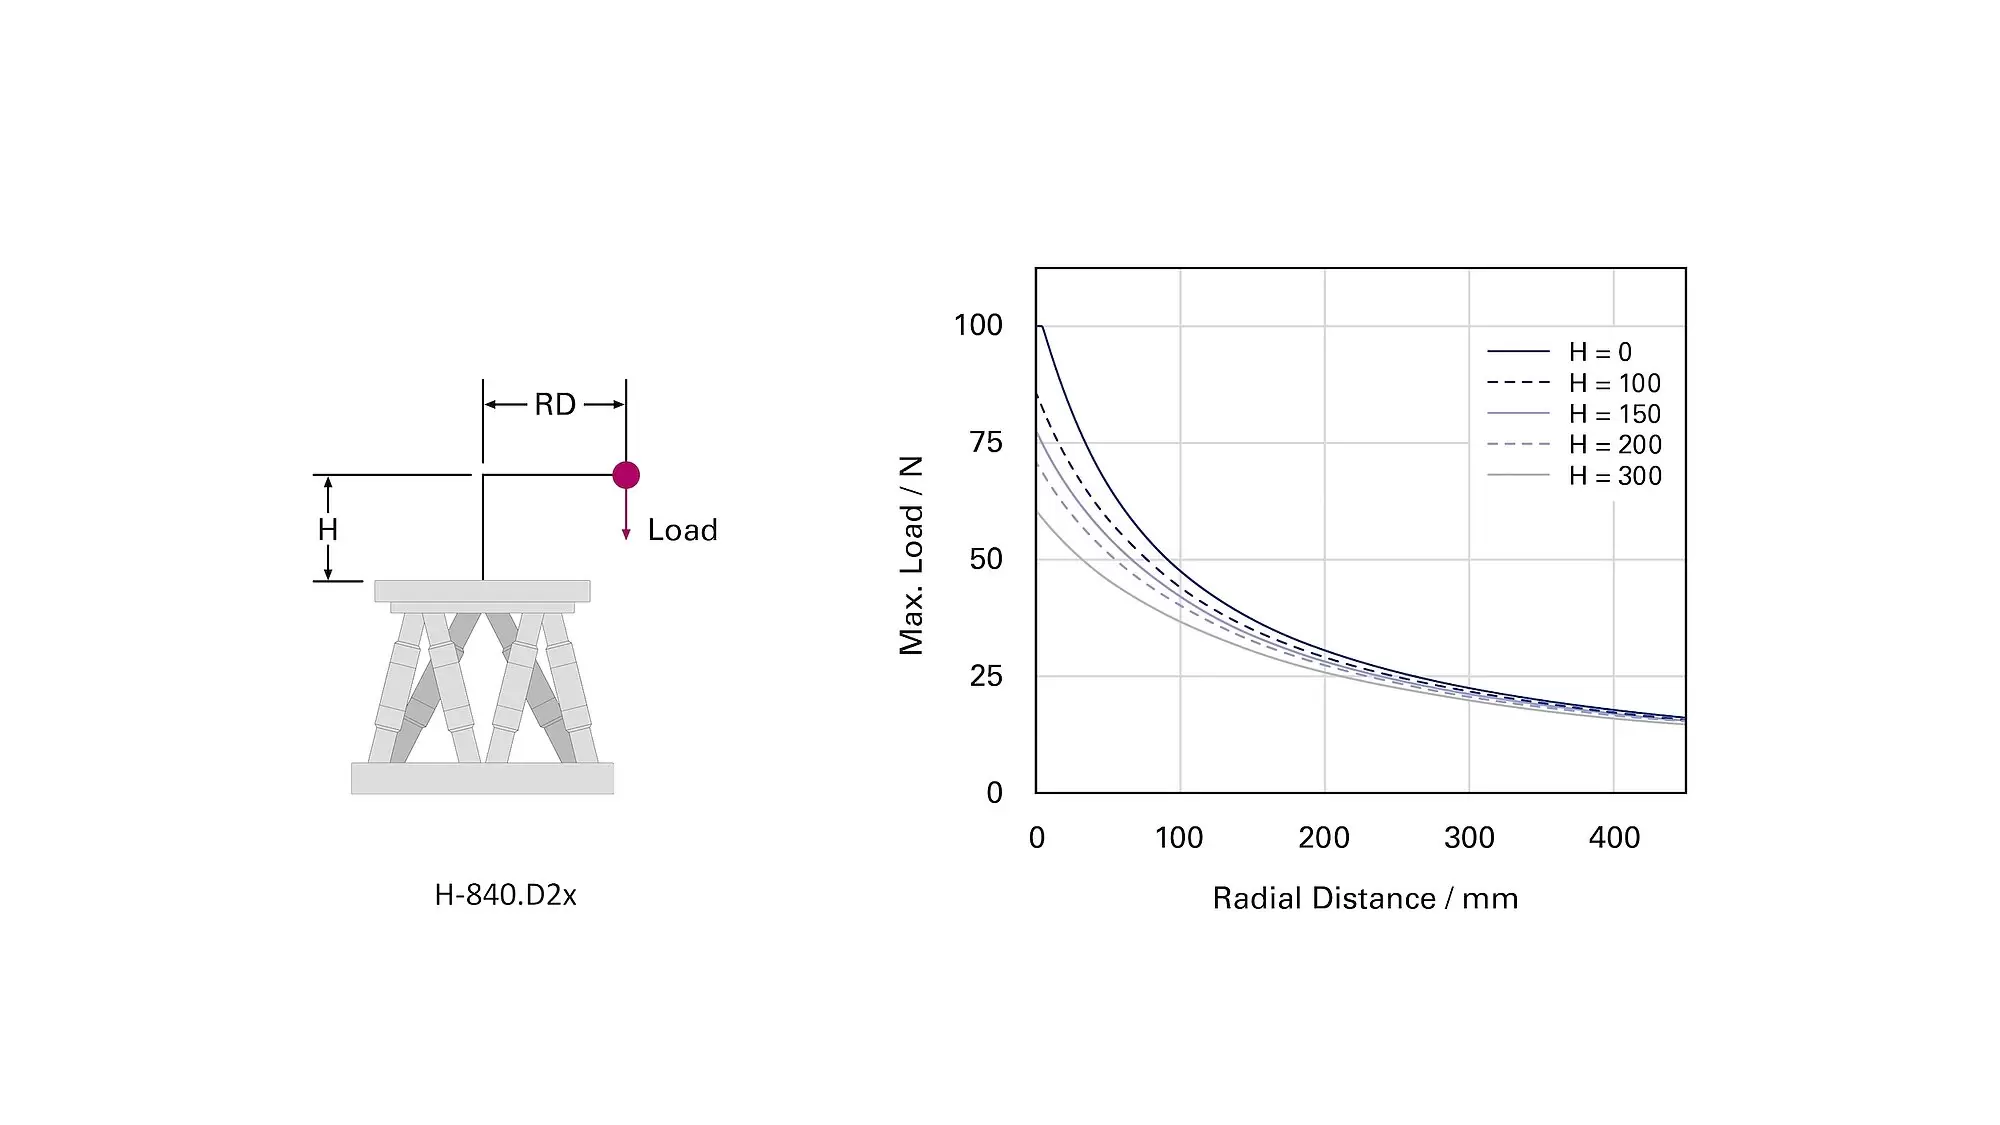
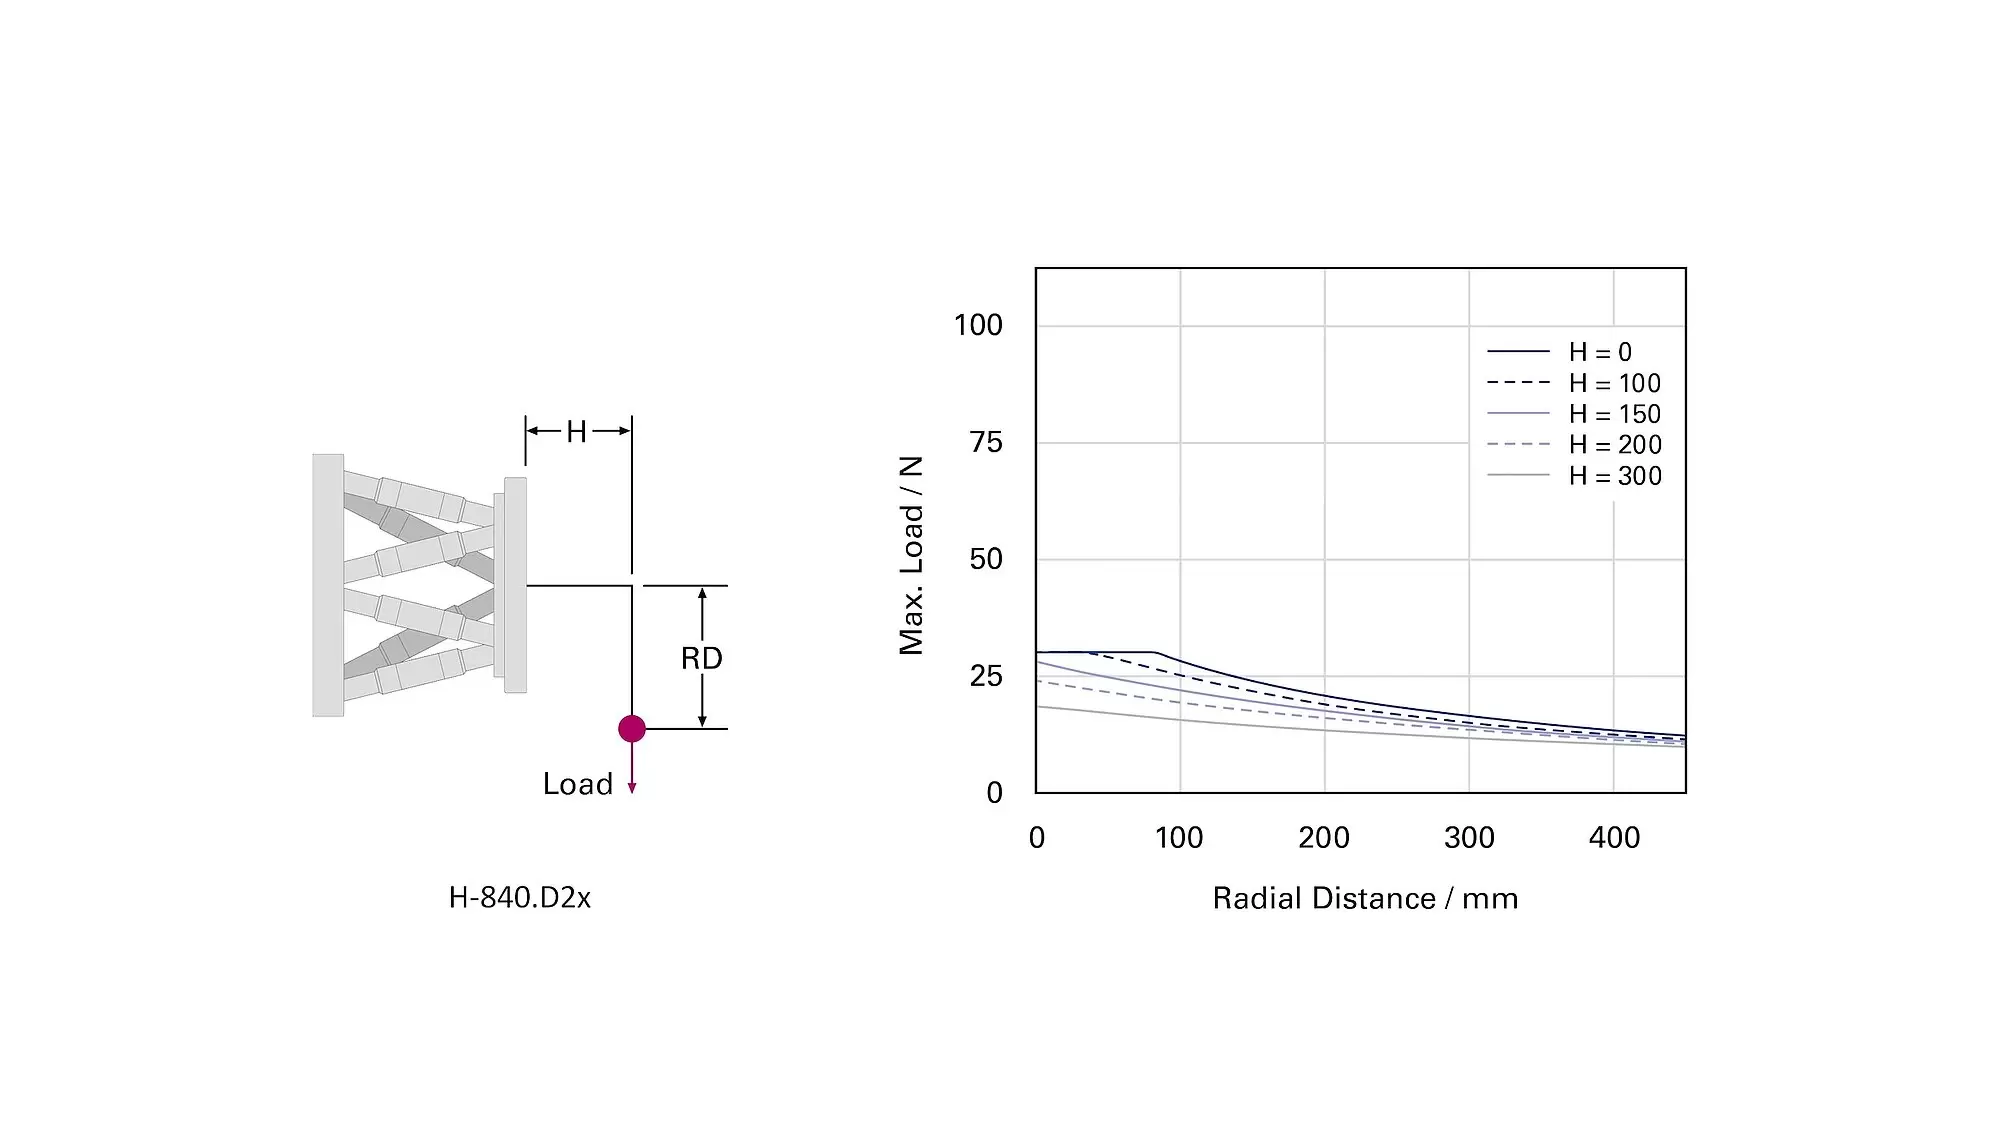
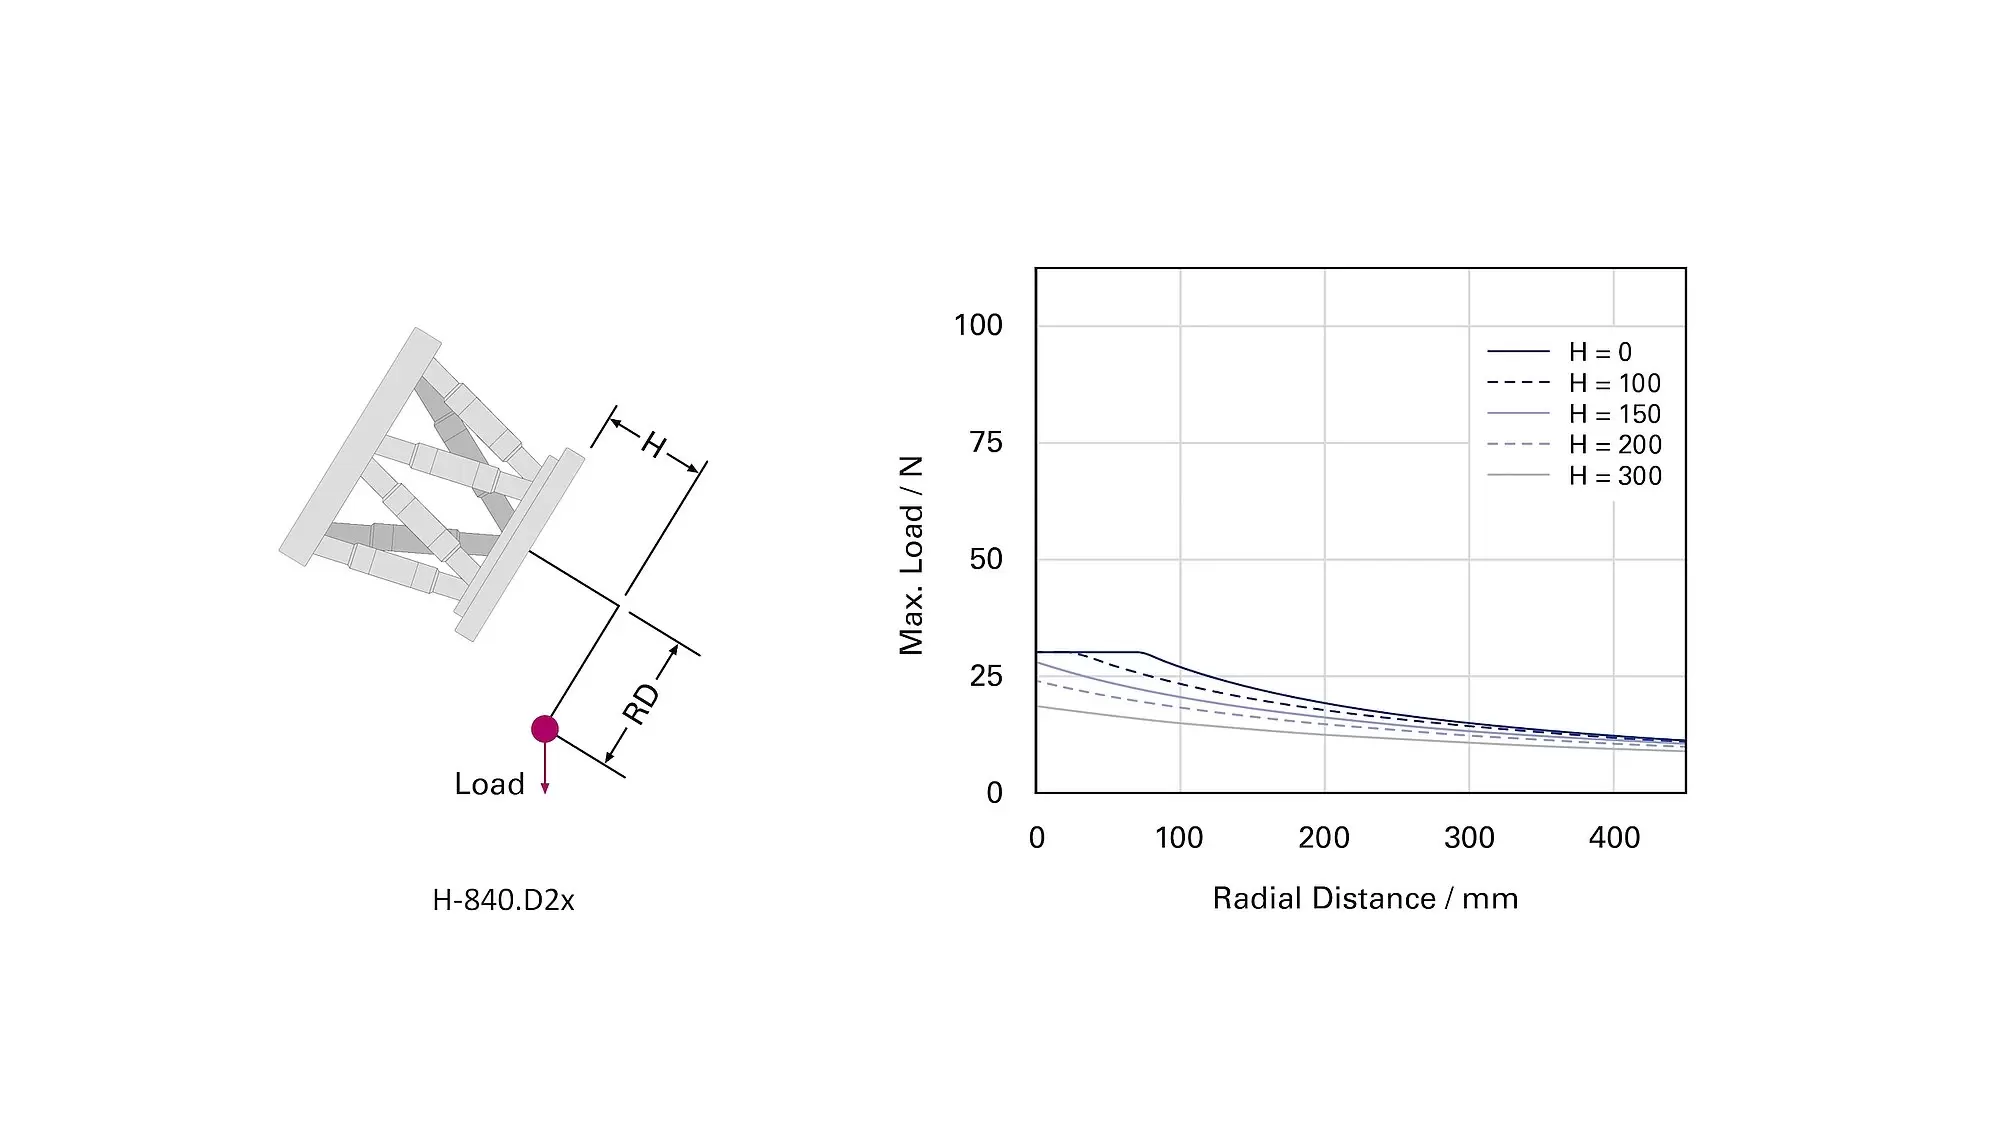
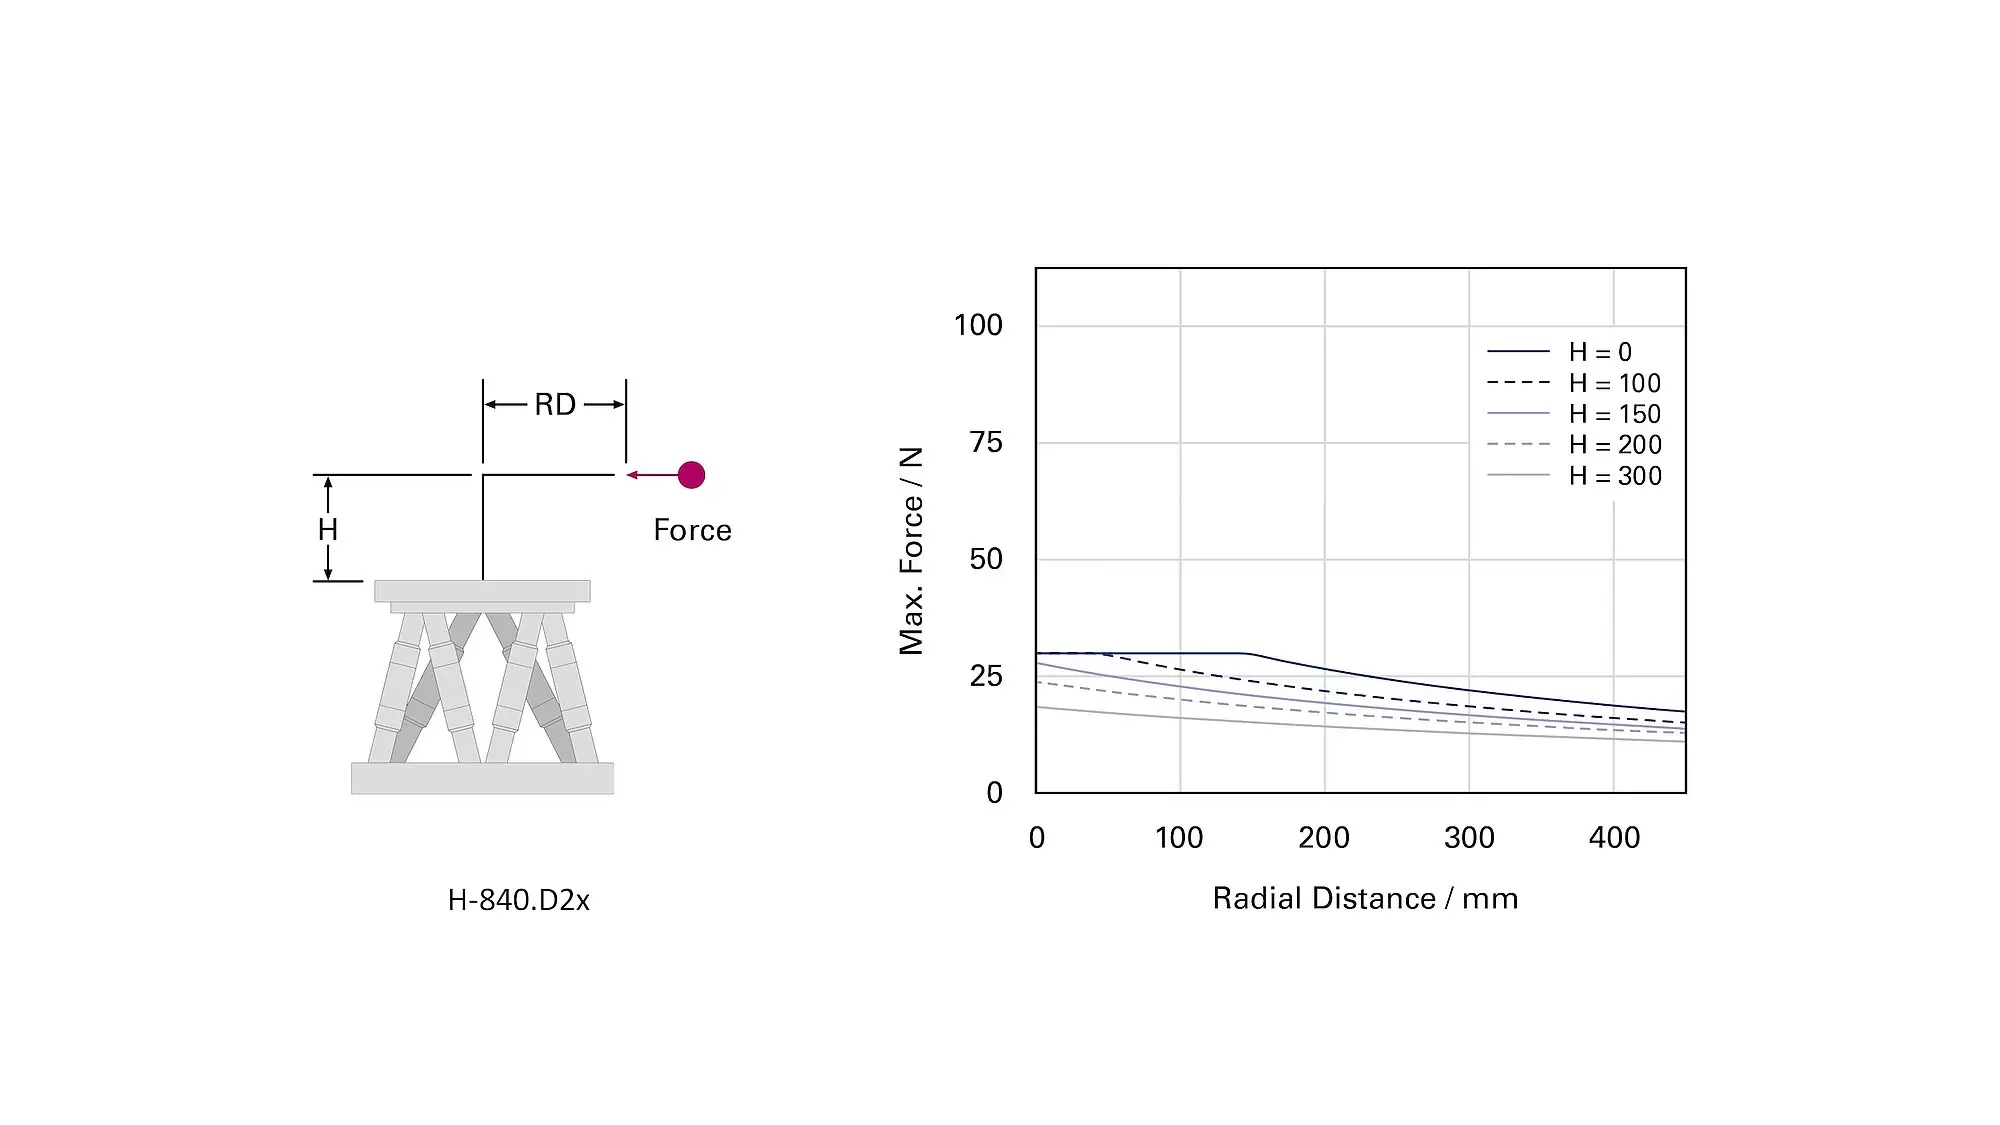
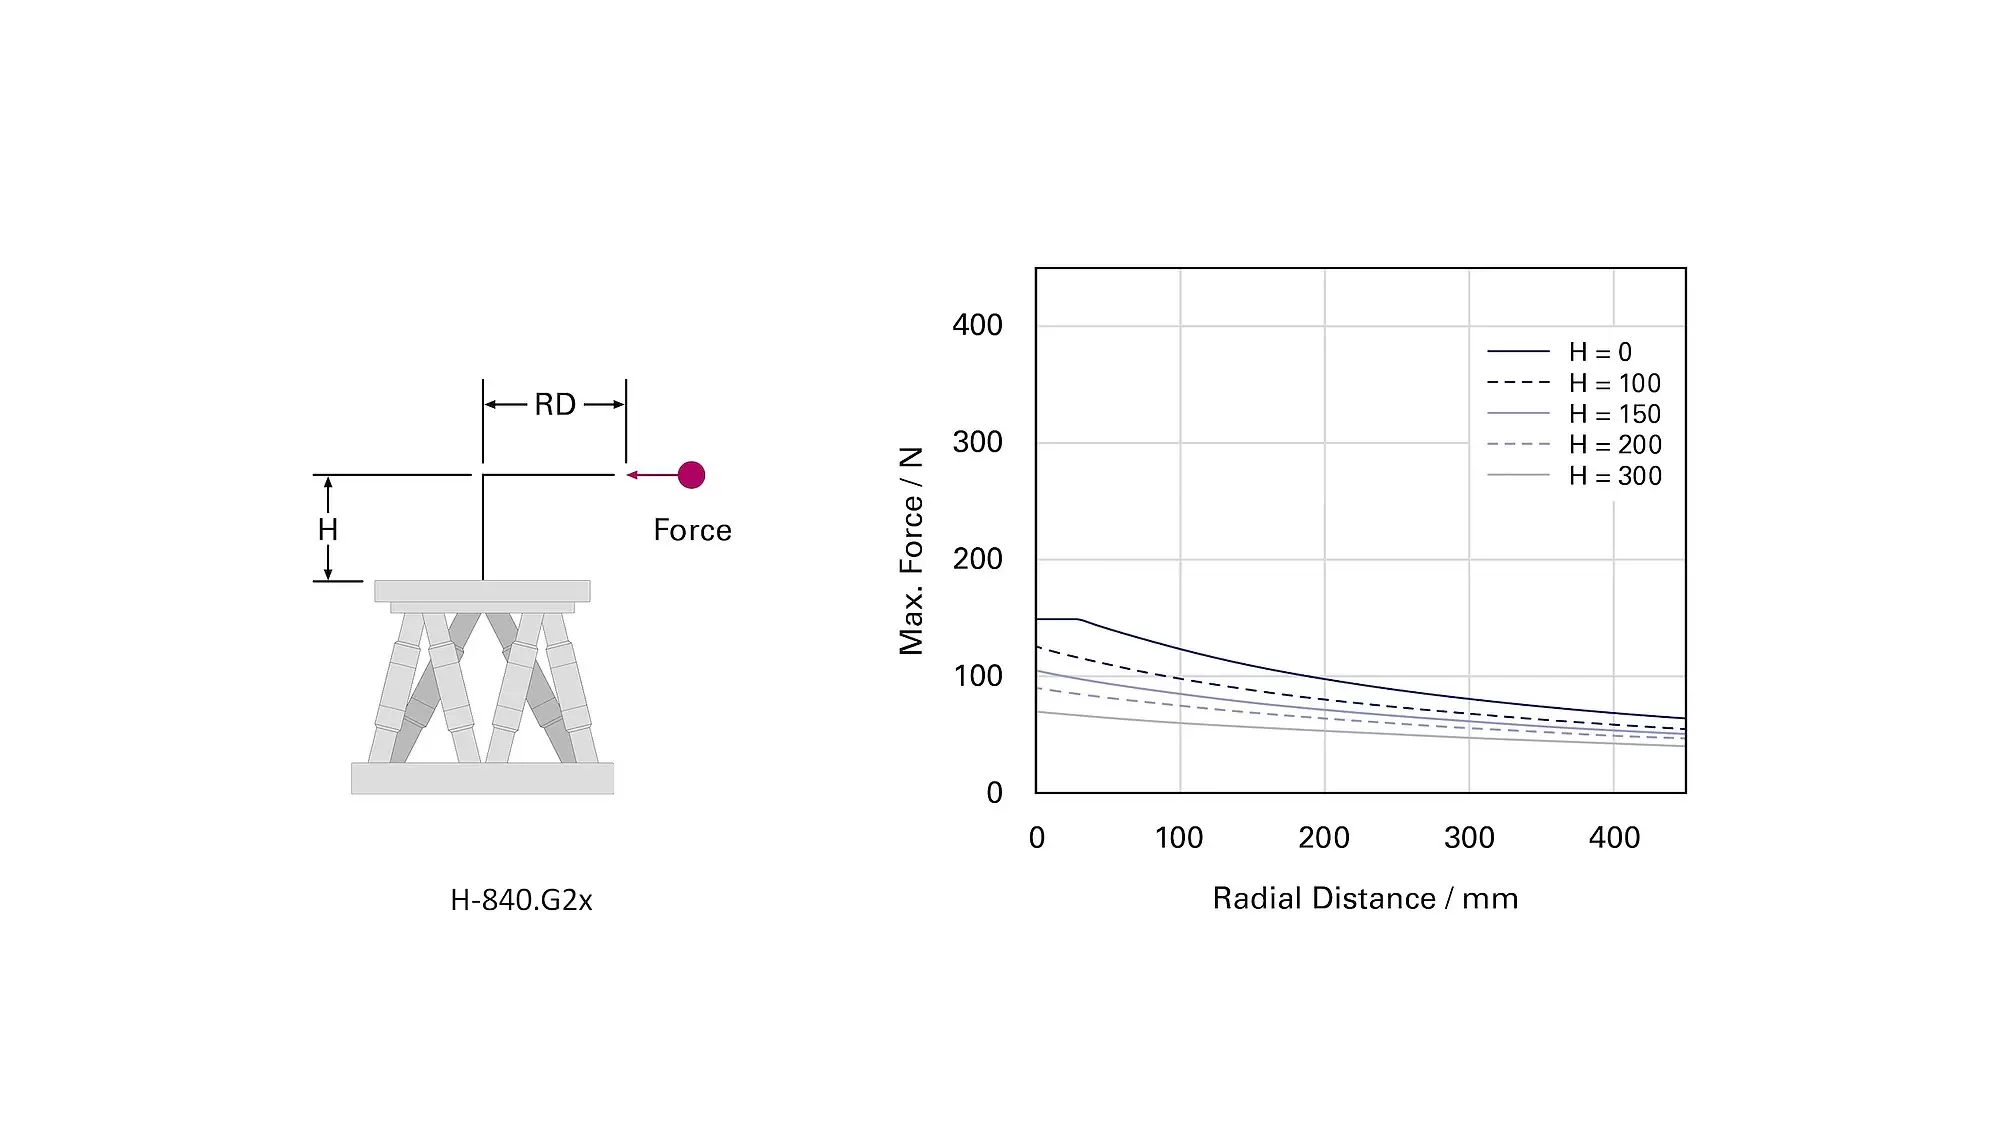
Maximum holding force, base plate in any orientation 5 N 5 N 25 N 25 N  
Maximum holding force, base plate horizontal 15 N 15 N 100 N 100 N  
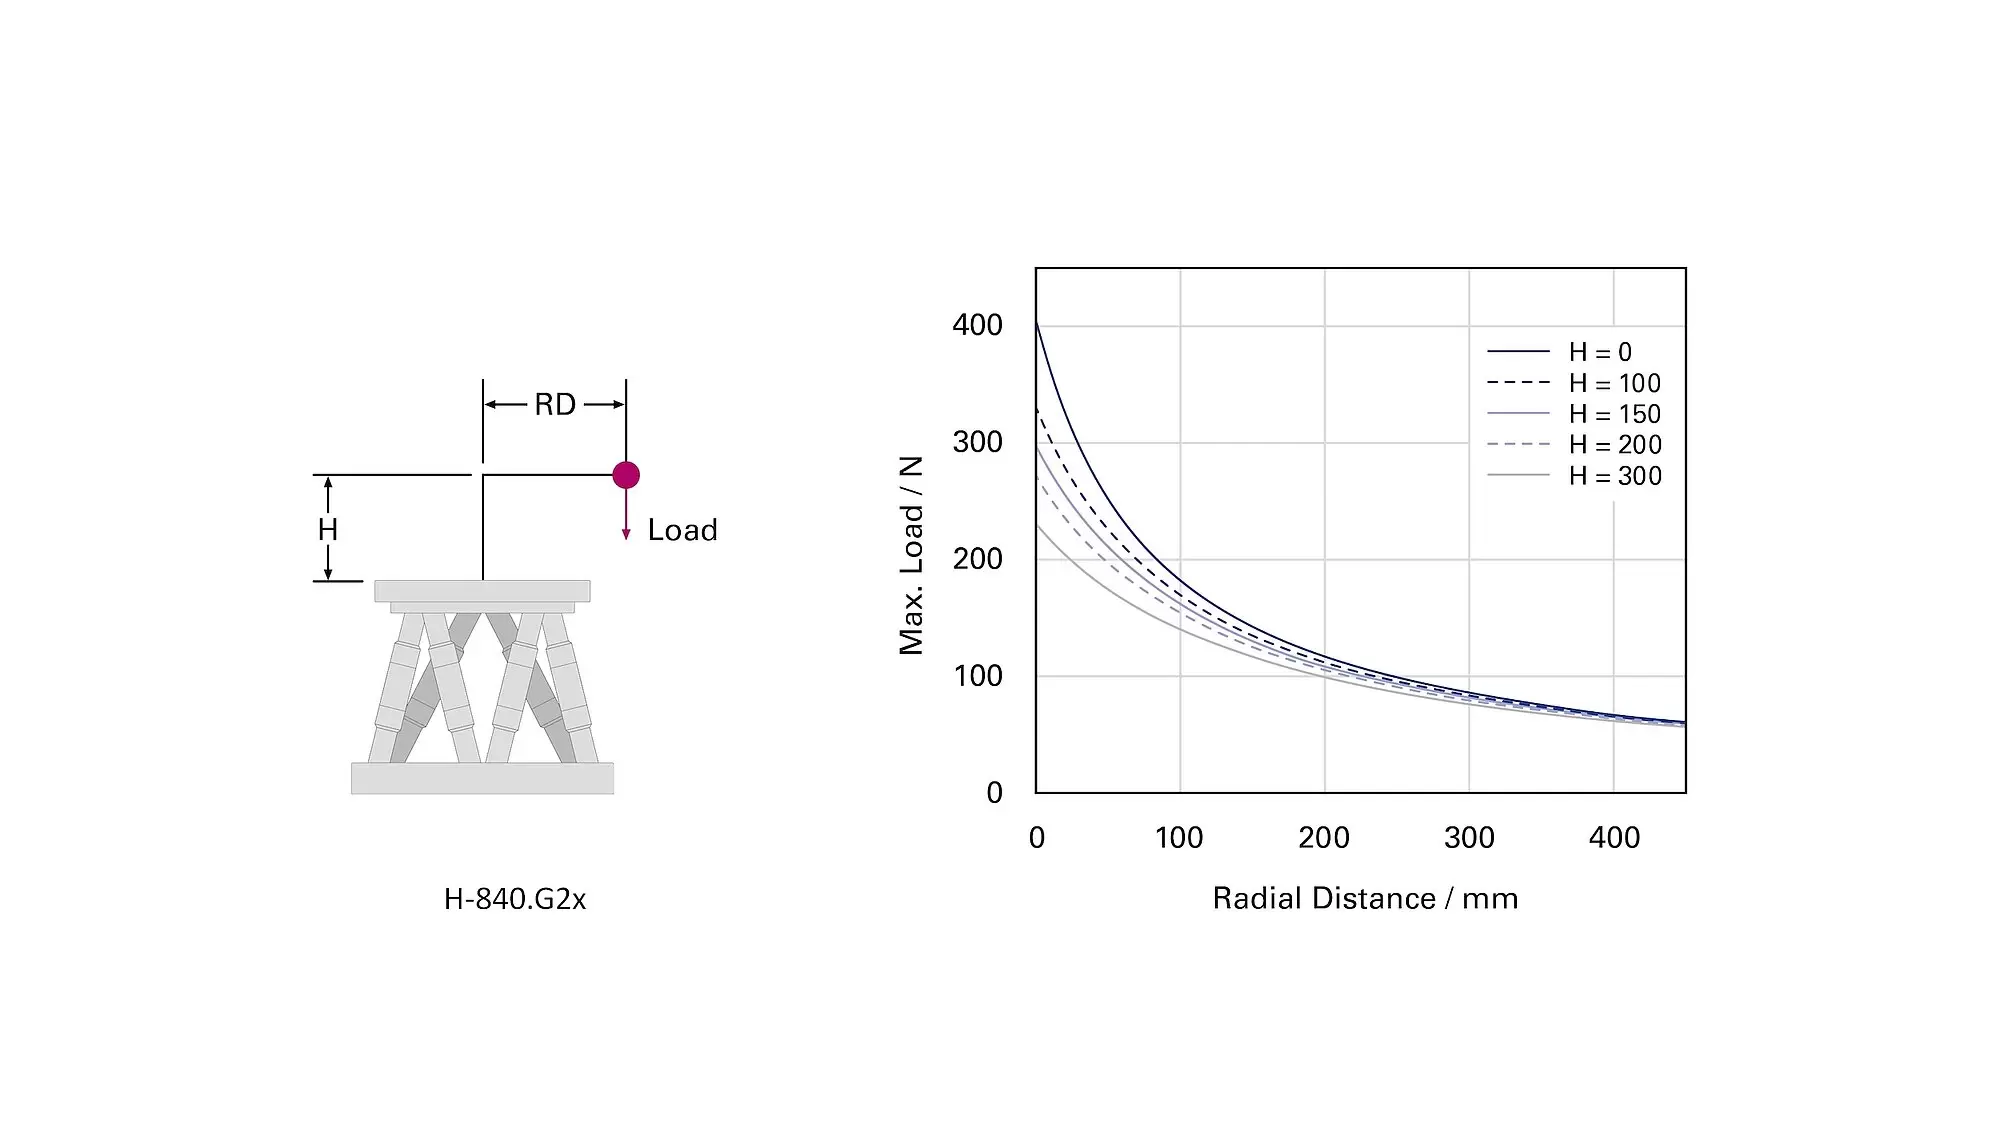
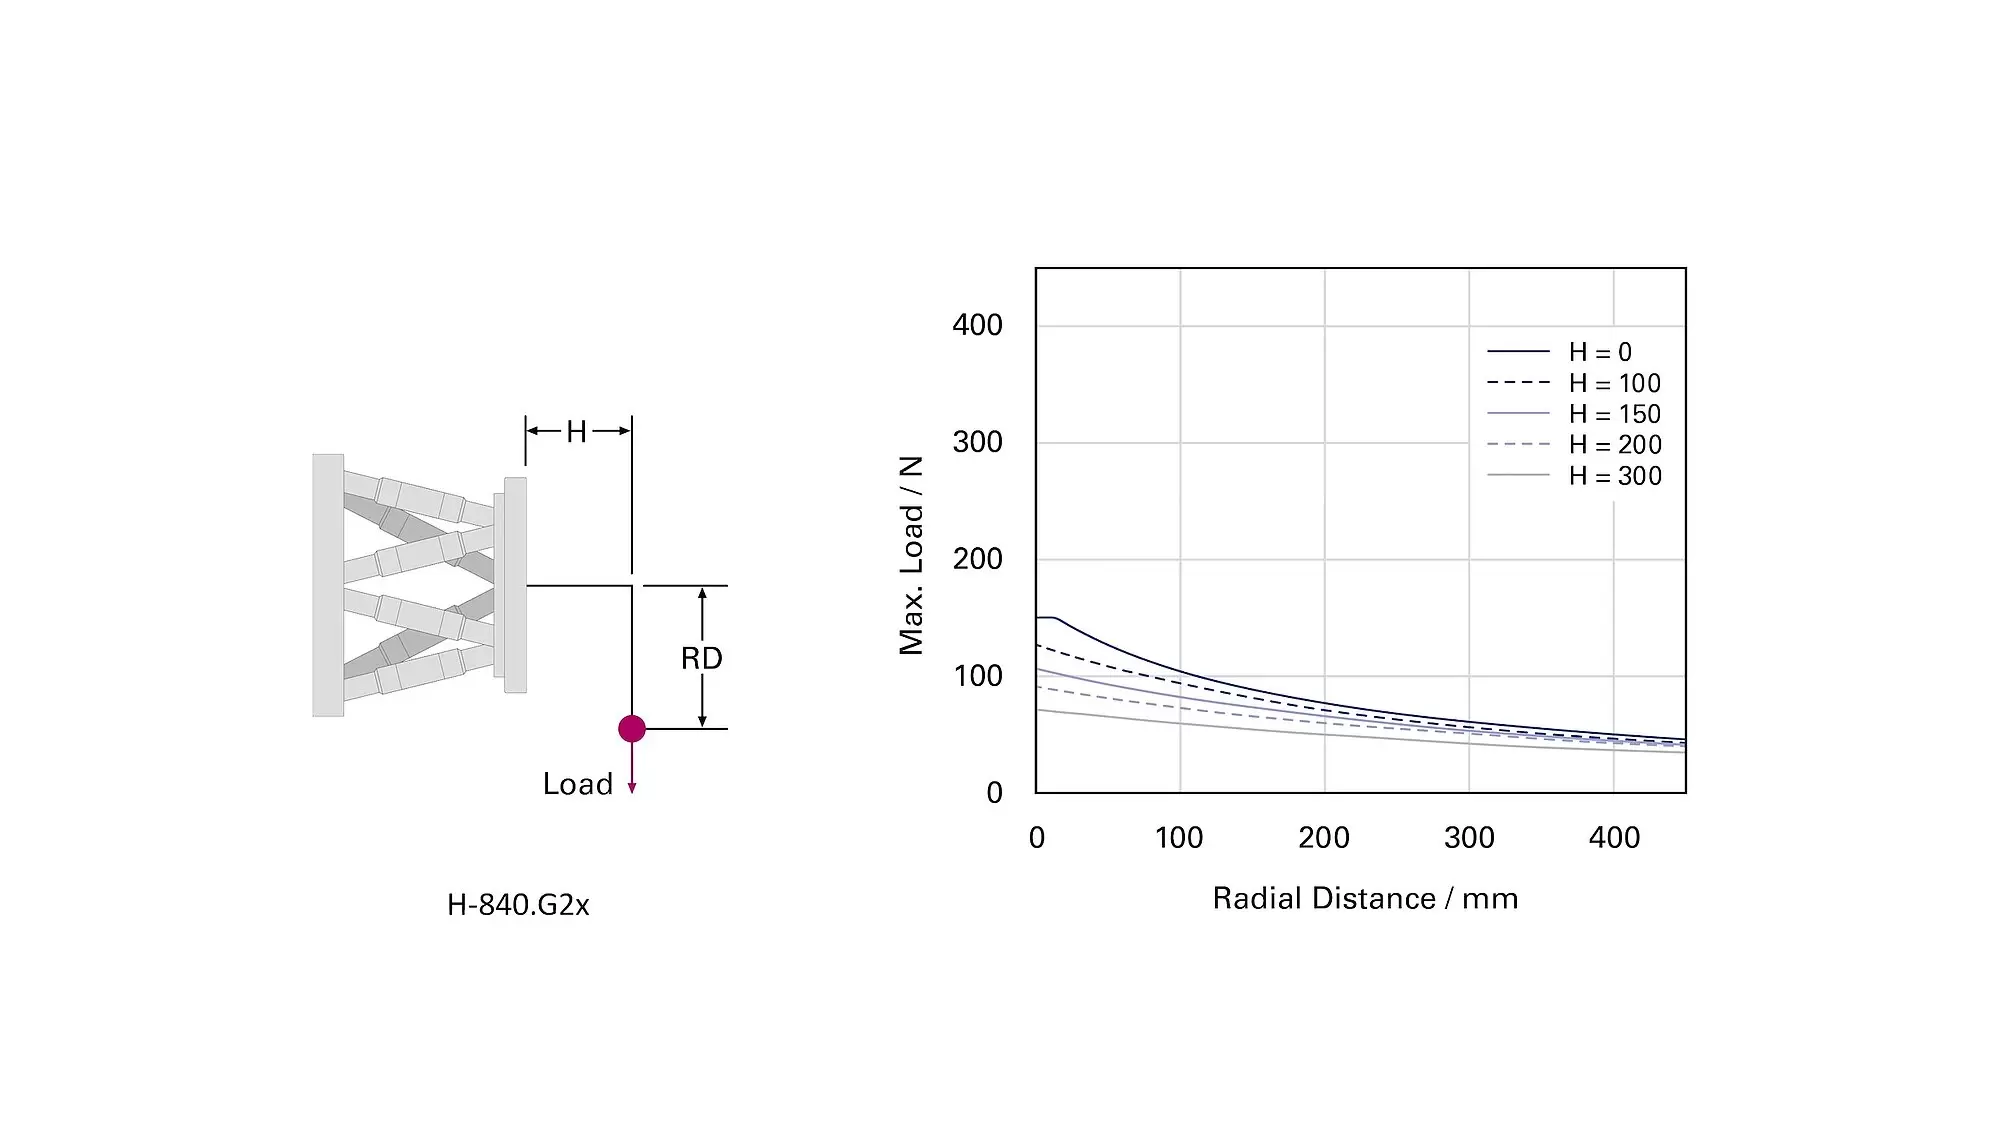
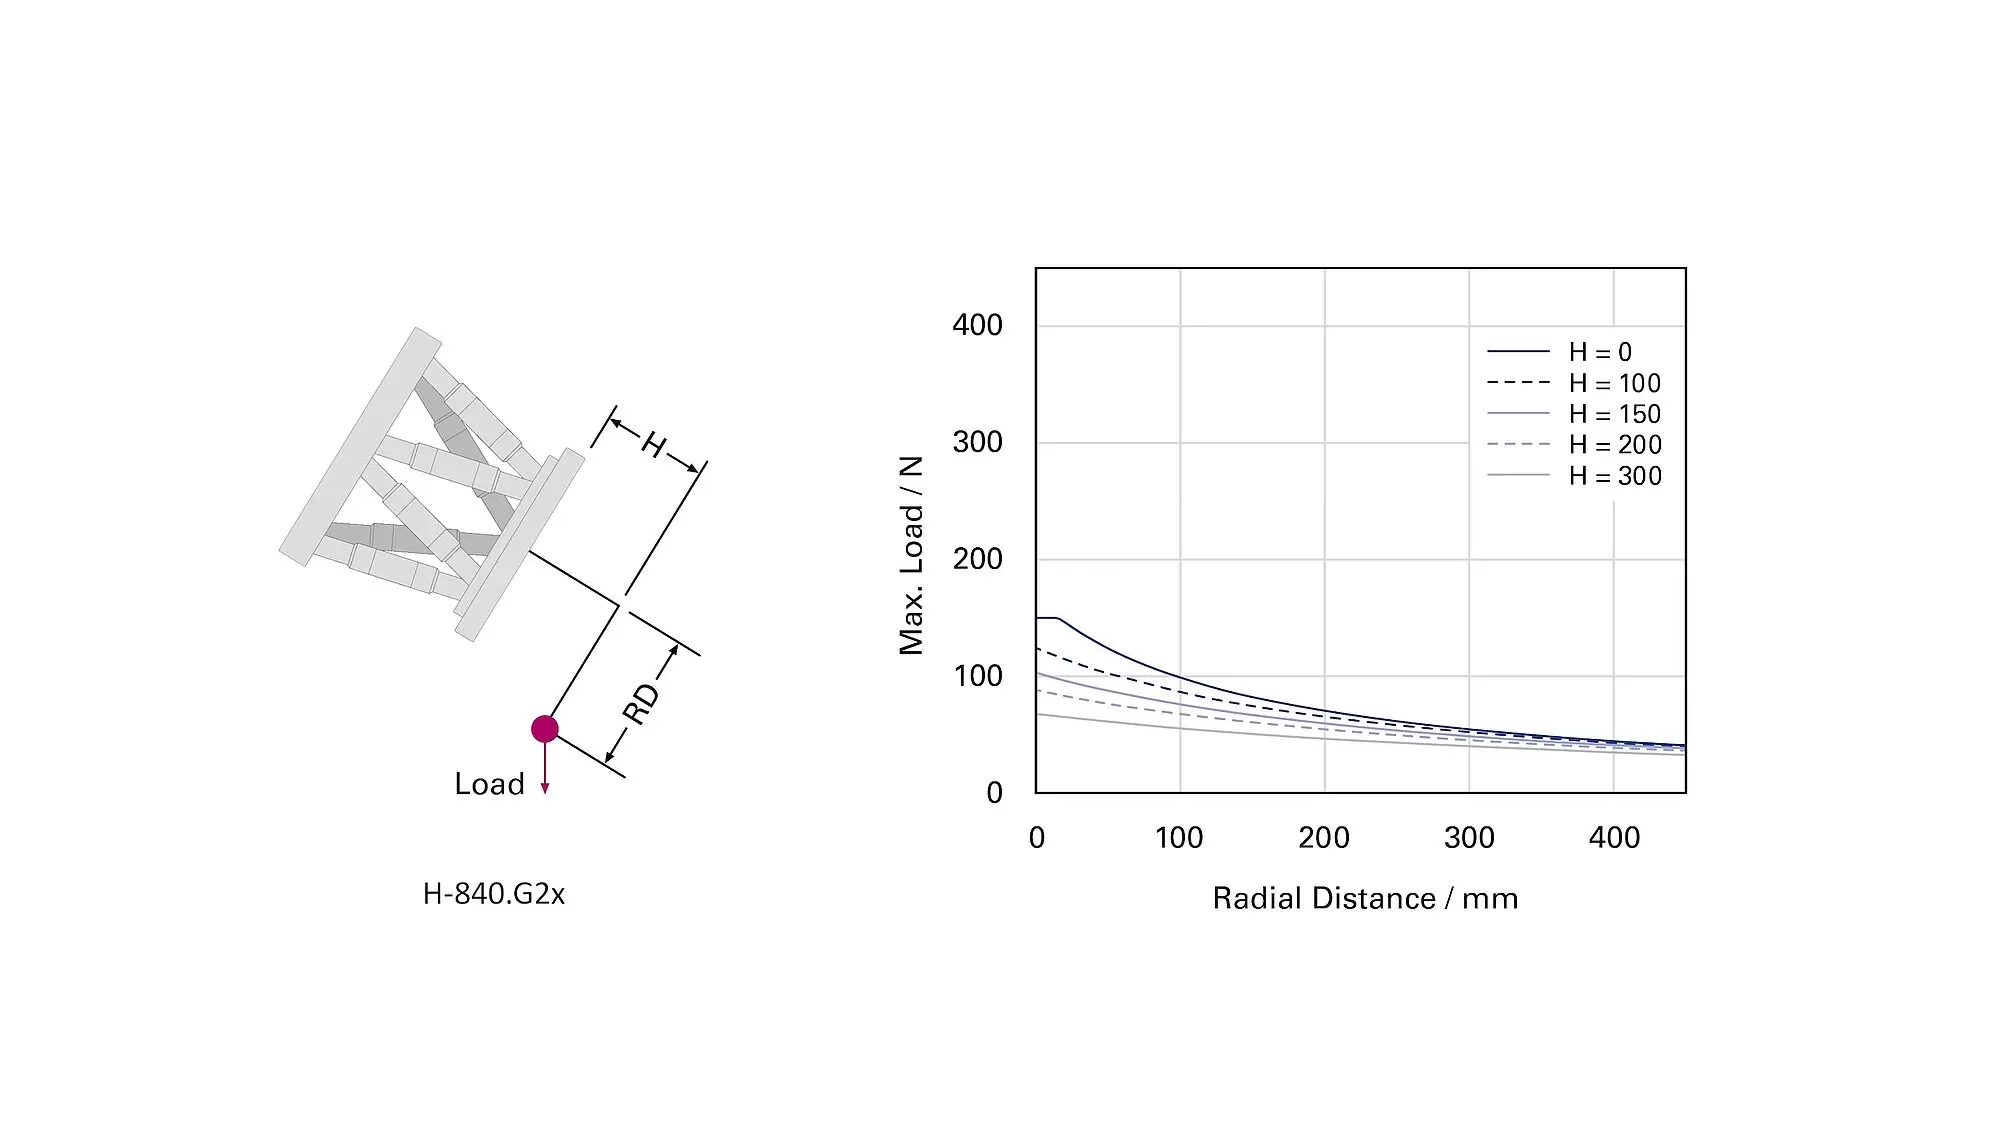
Maximum load capacity, base plate in any orientation 3 kg 3 kg 15 kg 15 kg  
Maximum load capacity, base plate horizontal 10 kg 10 kg 40 kg 40 kg  
Overall mass 12 kg 12 kg 12 kg 12 kg  
Material

Aluminum, steel

Aluminum, steel

Aluminum, steel

Aluminum, steel

 
Miscellaneous H-840.D2A H-840.D2I H-840.G2A H-840.G2I Tolerance
Connector for supply voltage M12 4-pin (m) M12 4-pin (m) M12 4-pin (m) M12 4-pin (m)  
Recommended controllers / drivers

C-887.5xx

C-887.5xx

C-887.5xx

C-887.5xx

 
Operating temperature range -10 to 50 °C -10 to 50 °C -10 to 50 °C -10 to 50 °C  
Connector for data transmission HD D-sub 78-pin (m) HD D-sub 78-pin (m) HD D-sub 78-pin (m) HD D-sub 78-pin (m)  

Technical data specified at 22±3 °C.

The maximum travel ranges of the individual coordinates (X, Y, Z, θX, θY, θZ) are interdependent. The data for each axis shows its maximum travel range when all other axes are in the zero position of the nominal travel range and the default coordinate system is in use, or rather when the pivot point is set to 0,0,0.

Connecting cables are not included in the scope of delivery and must be ordered separately.

Ask about customized versions.

3D Models
3D Models
H-840.x2x 3-D model
Version / Date
2020-09-24
zip - 2 MB
Datasheet
Datasheet
Datasheet H-840
Version / Date
2022-08-22
pdf - 2 MB
Documentation
Documentation
Short Instructions MS247EK
Hexapod Systems: H-xxx Hexapod with C-887.5xx Controller
Version / Date
2.0.0 06/2020
pdf - 2 MB
Documentation
PI Certificate of Registration of Vibratory Apparatus H-840
Certificate of Registration of Vibratory Apparatus
Version / Date

pdf - 303 KB
Documentation
User Manual MS201
H-840 Hexapod Microrobot
Version / Date
2.6.0 2023-01-13
pdf - 4 MB
Product Note
Product Note
Product Change Notification Motor Driven Products
Version / Date
2021-04-19
pdf - 917 KB
Product Note
Product Change Notification Hexapod Cables
Version / Date
2021-01-15
pdf - 186 KB
Product Note
Product Change Notification H-840.D2, H-840.G2
Version / Date
2020-06-02
pdf - 56 KB
Product Note
Product Change Notification H-206.x1x, H-8xx.x1x, H-8xx.xVx, F-206.S
Version / Date
2019-04-04
pdf - 367 KB
Software File
Software File
Hexapod Simulation Tool
Version / Date
2022-01-26
zip - 18 MB
White Papers
White Papers
Industrial Safety Device for Hexapods
How to Connect a Safety Light Barrier to a Hexapod System
Version / Date
WP4025E 2020-02
pdf - 1 MB
H-840.D2A
Motion hexapod microrobot, brushless DC motor, absolute encoder, 10 kg load capacity, 60 mm/s velocity. Connecting cables are not included in the scope of delivery and must be ordered separately.
H-840.D2I
Motion hexapod microrobot, brushless DC motor, incremental rotary encoder, 10 kg load capacity, 60 mm/s velocity. Connecting cables are not included in the scope of delivery and must be ordered separately.
H-840.G2A
Precision hexapod microrobot, brushless DC gear motor, absolute encoder, 40 kg load capacity, 2.5 mm/s velocity. Connecting cables are not included in the scope of delivery and must be ordered separately.
H-840.G2I
Precision hexapod microrobot, brushless DC gear motor, incremental rotary encoder, 40 kg load capacity, 2.5 mm/s velocity. Connecting cables are not included in the scope of delivery and must be ordered separately.
Direct the future with the power of the past.
Expertise
Markets Technologies
Contact
Nano Dünya Mak. San. Tic. Ltd. Şti.
Parseller Mah. Gündoğan Sok. No:8/A
Ümraniye/İstanbul

02166140039
info@nanodunya.com.tr
Copyright © 2024 by Nano Dünya. All rights reserved.
x
Quote List
Your quote list is currently empty.
x
Download Request
Your download list is currently empty.
0 0 Whatsapp