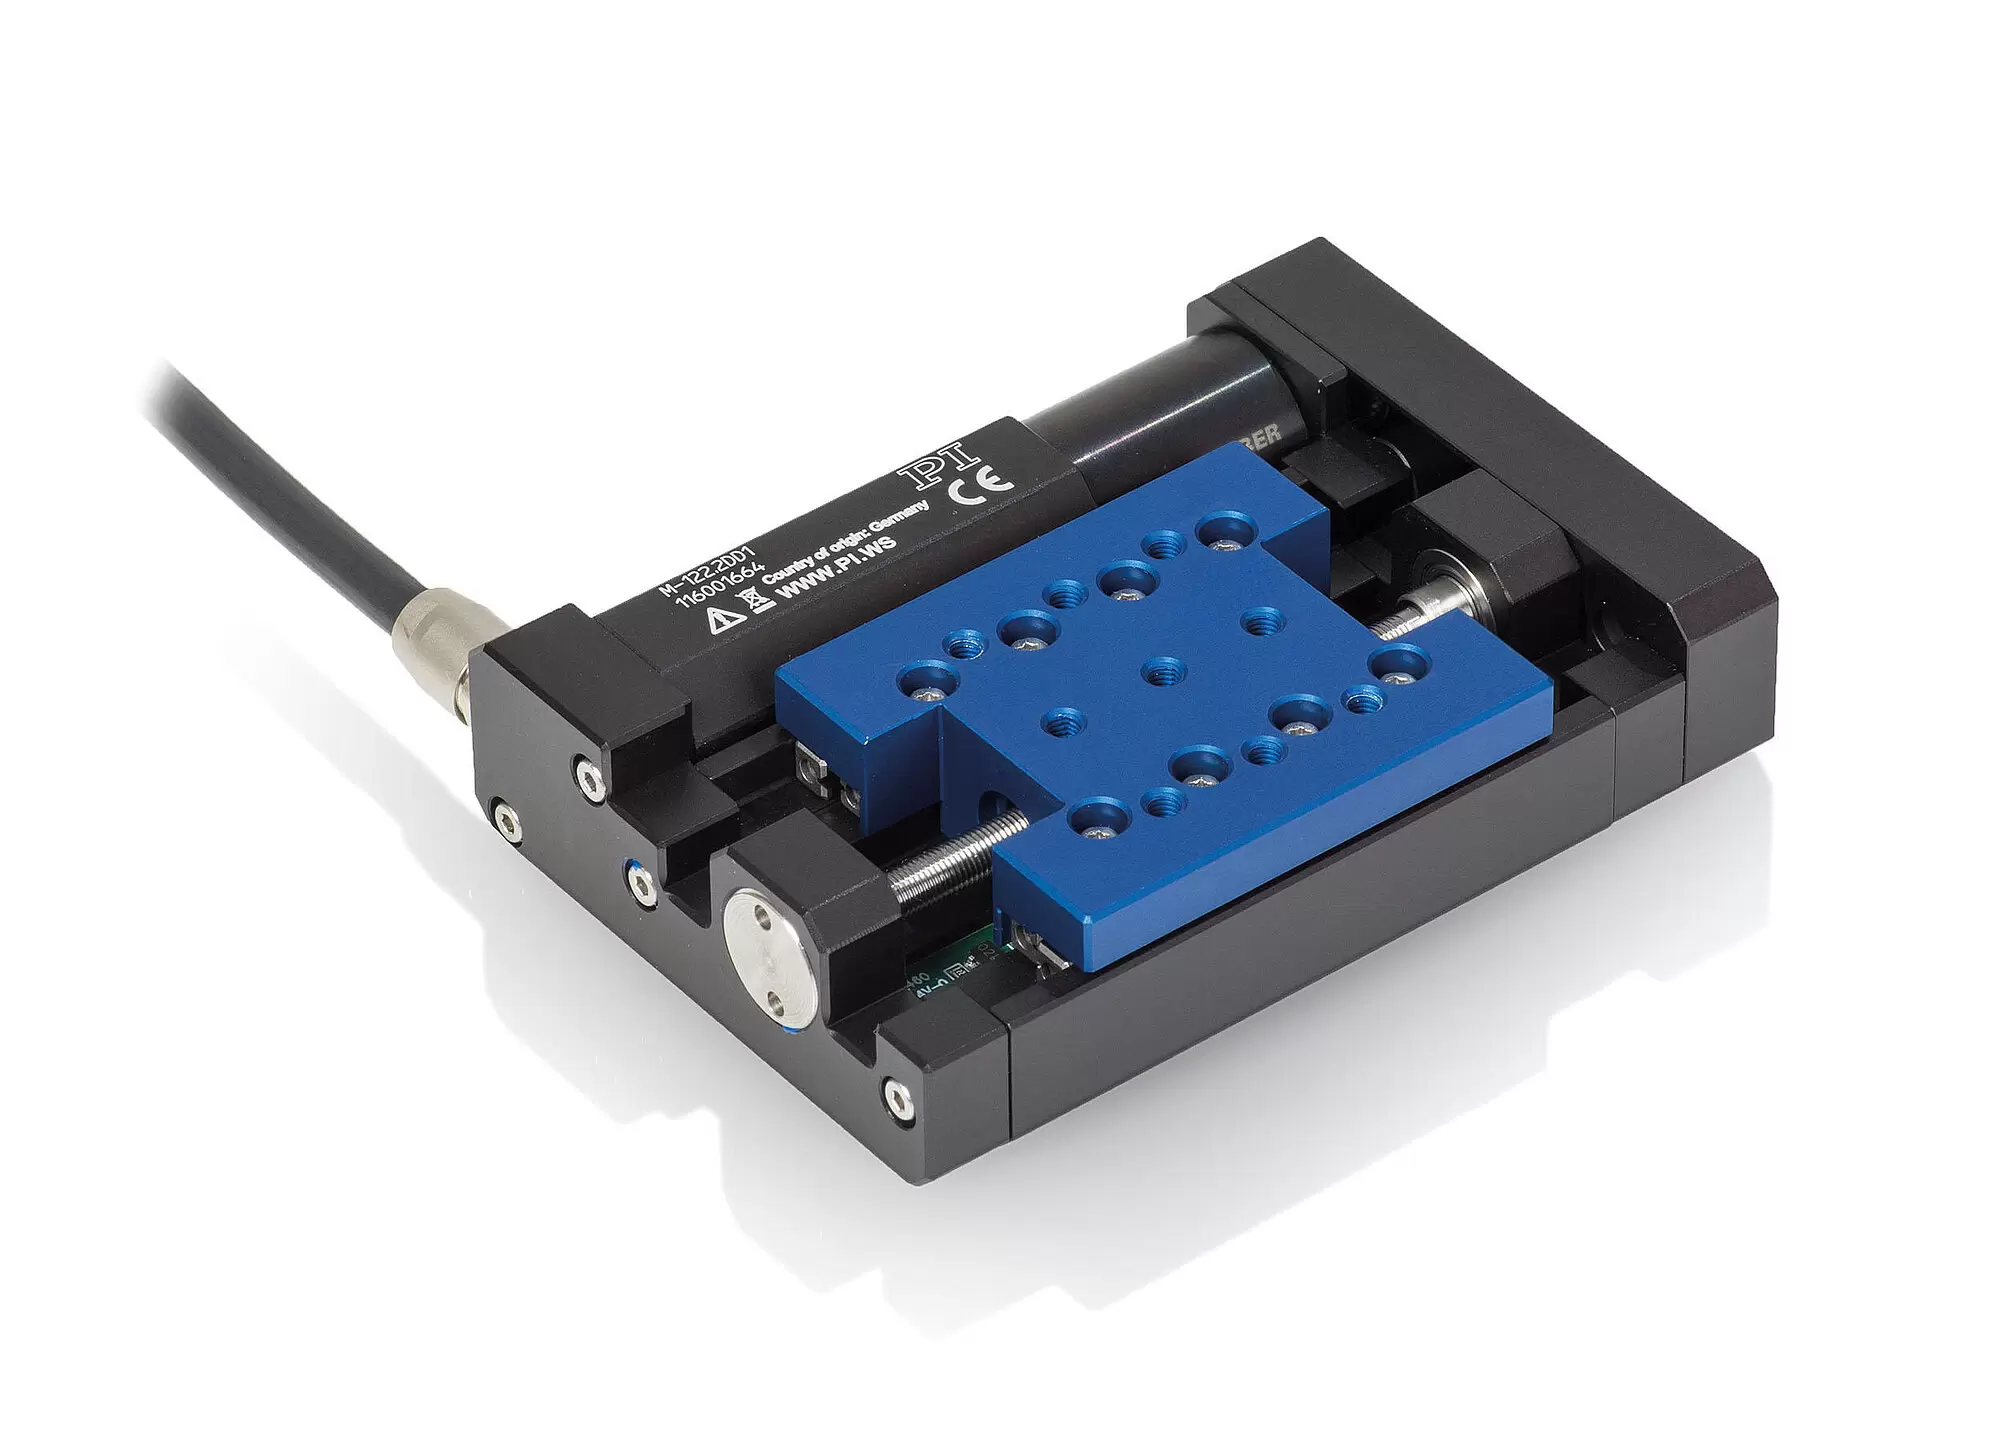
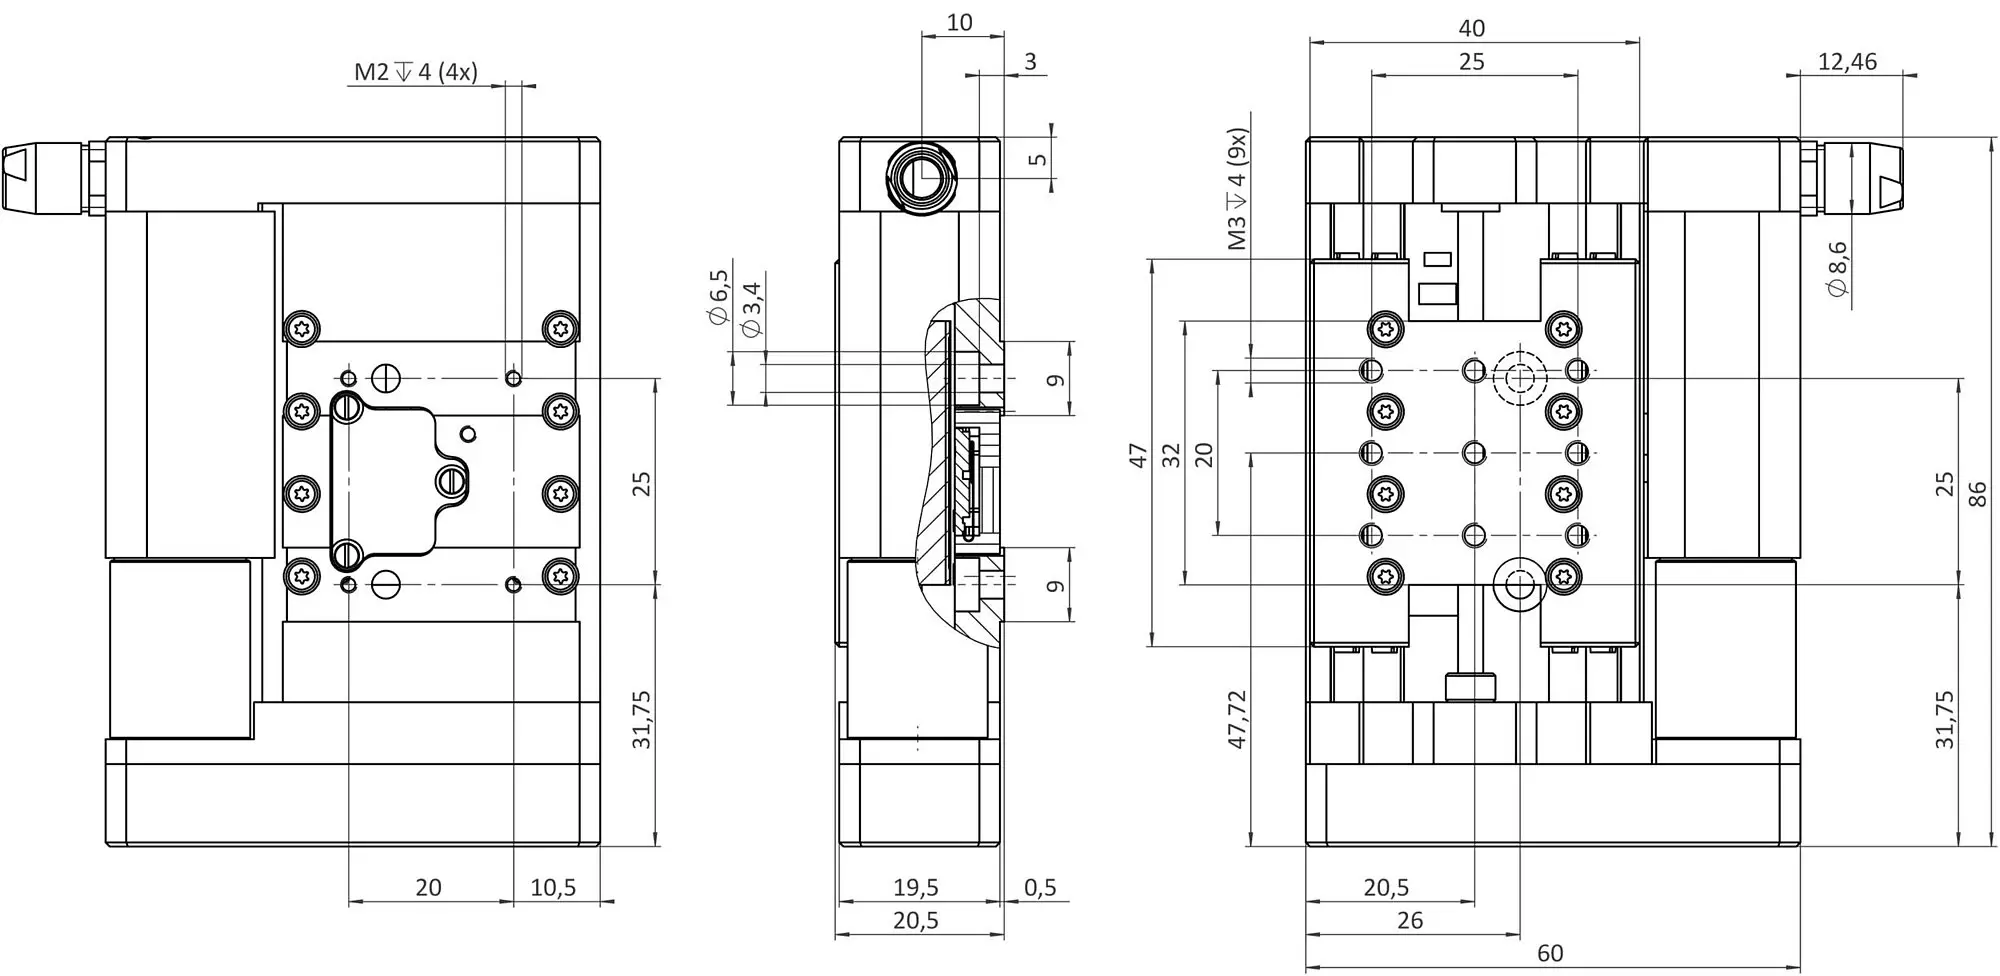
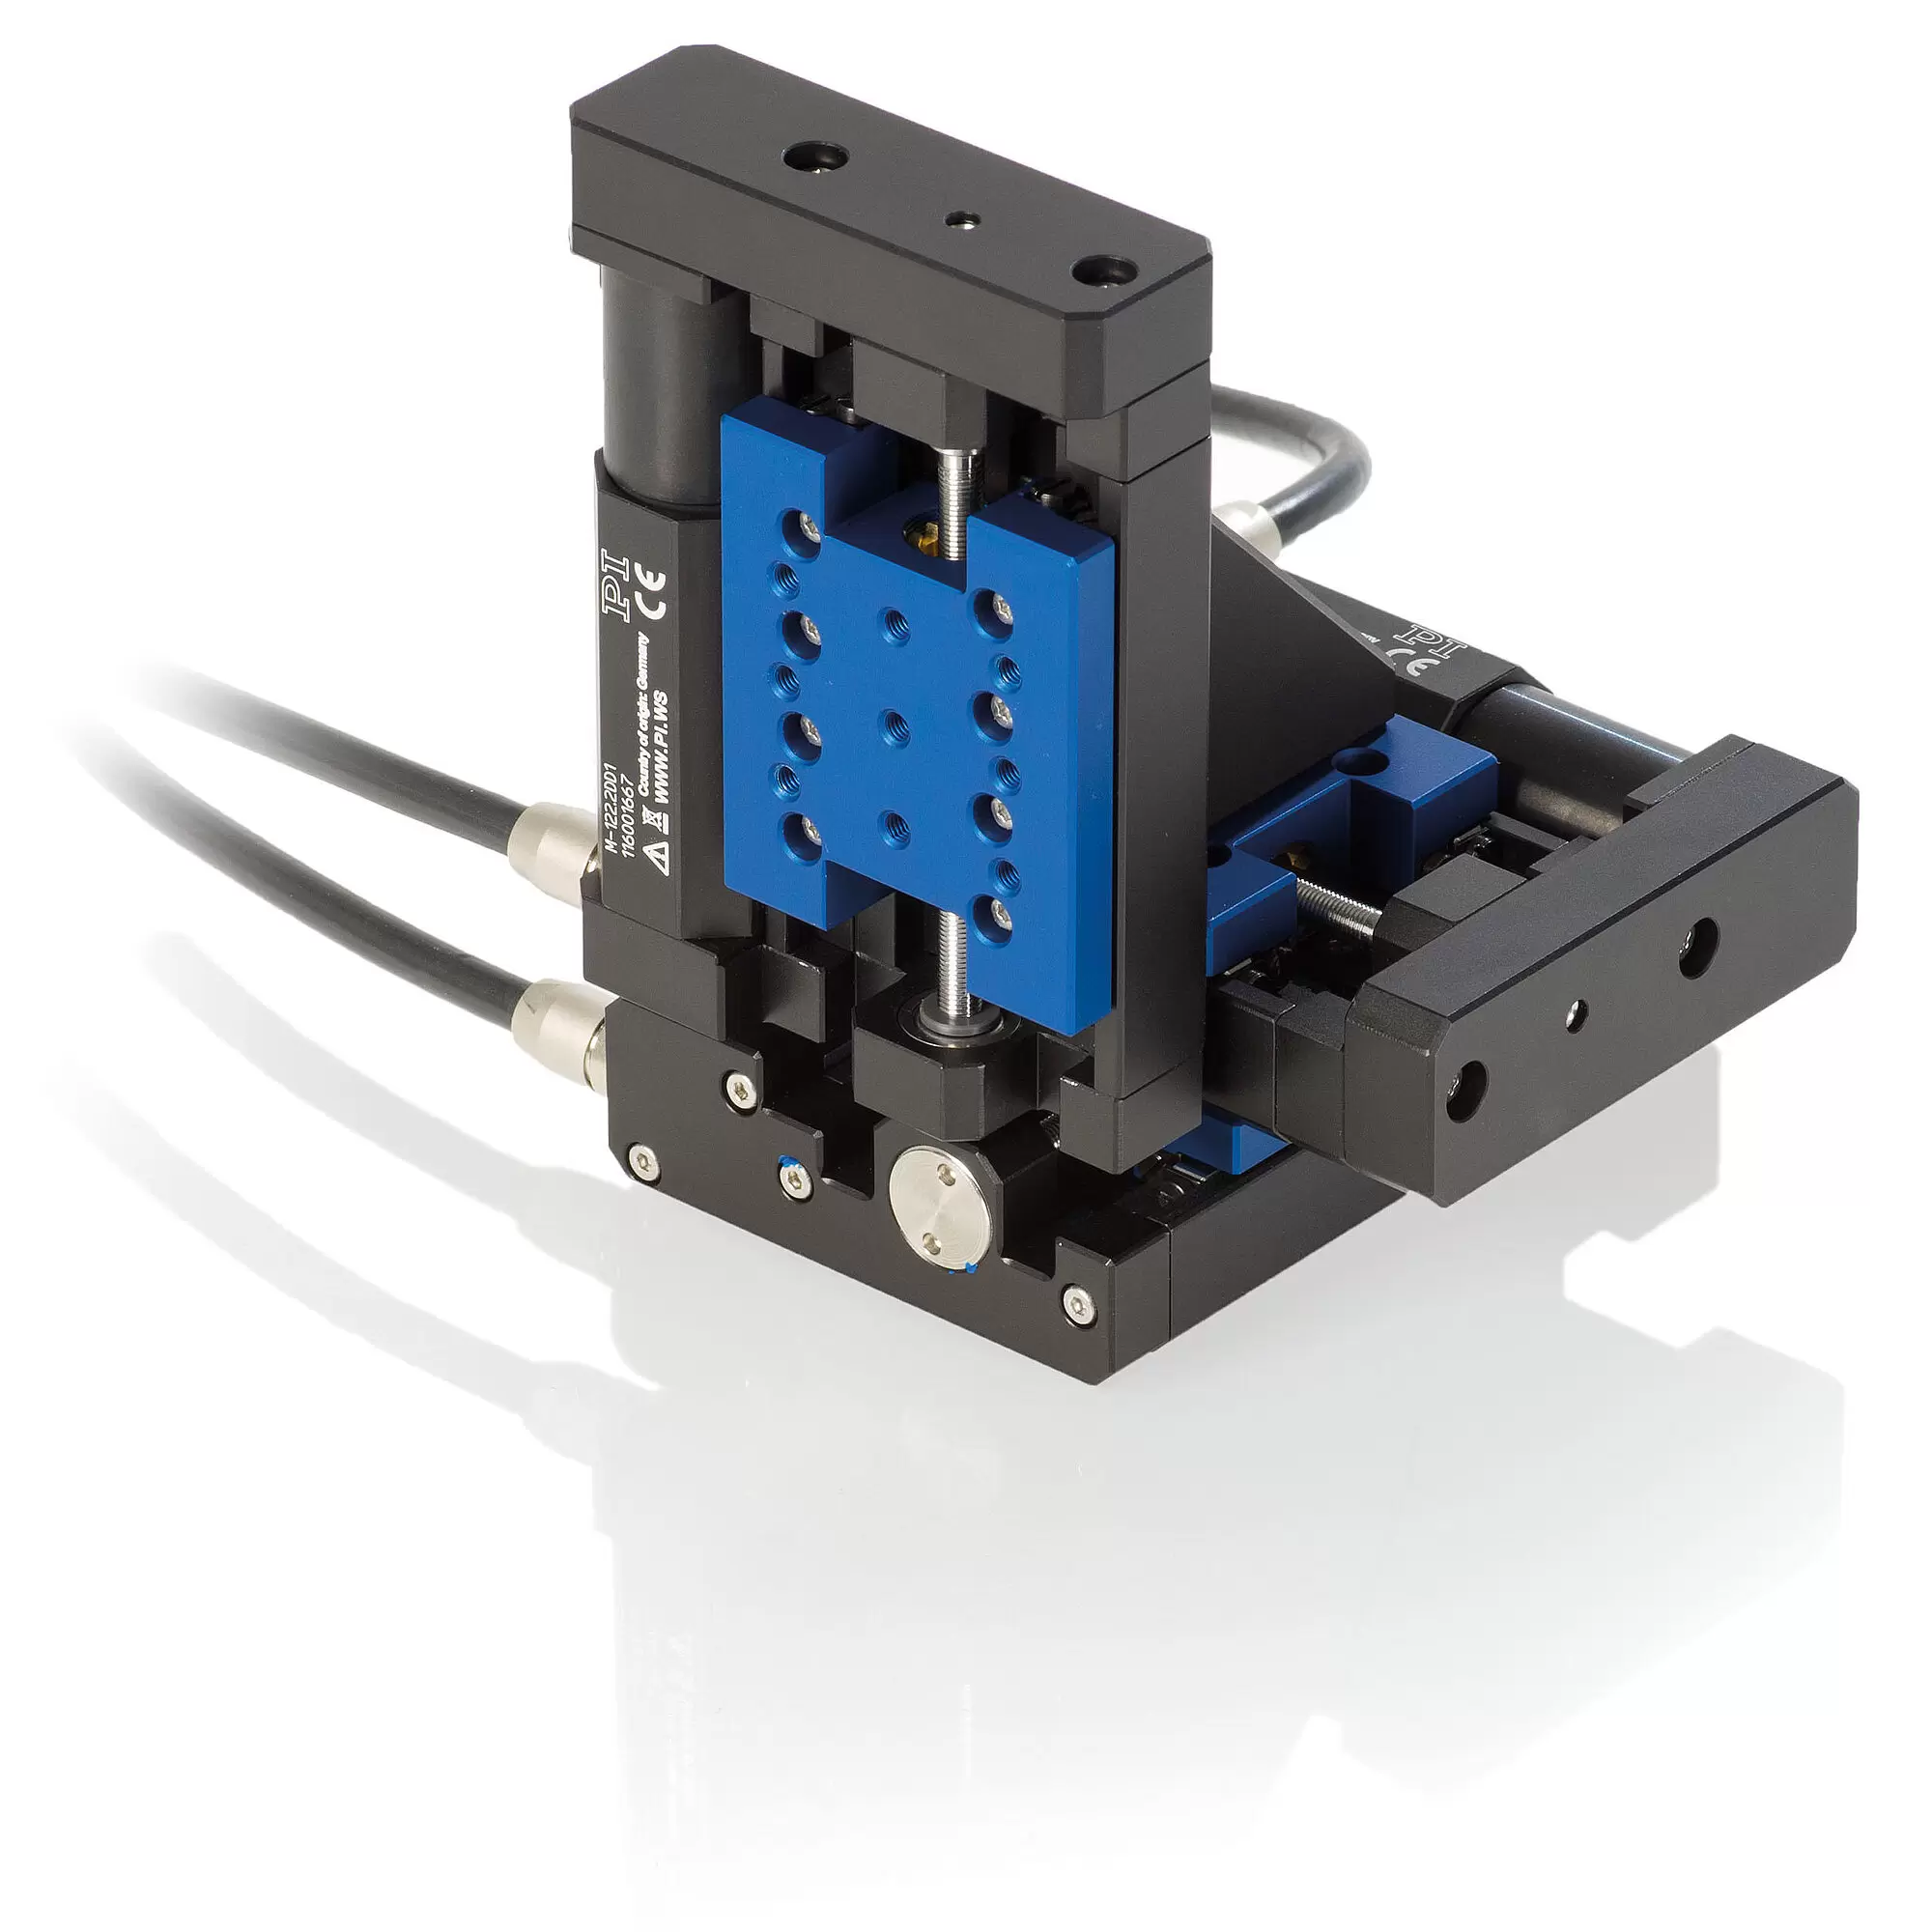
| Motion | M-122.2DD1 | Tolerance |
|---|---|---|
| Active axes | X | |
| Travel range in X | 25 mm | |
| Maximum velocity in X, unloaded | 20 mm/s | |
| Pitch (Rotational crosstalk in θY with motion in X) | ± 150 µrad | typ. |
| Yaw (Rotational crosstalk in θZ with motion in X) | ± 150 µrad | typ. |
| Positioning | M-122.2DD1 | Tolerance |
| Integrated sensor | Incremental linear encoder | |
| Unidirectional repeatability in X | 0.15 µm | typ. |
| Bidirectional repeatability in X | ± 0.2 µm | max. |
| Minimum incremental motion in X | 0.2 µm | typ. |
| Backlash in X | 0.2 µm | typ. |
| Sensor signal | A/B quadrature, RS-422 | |
| Sensor resolution | 100 nm | |
| Reference switch | Hall effect | |
| Reference switch repeatability | 1 µm | |
| Limit switches | Hall effect | |
| Drive Properties | M-122.2DD1 | Tolerance |
| Drive type | DC motor | |
| Maximum power consumption | 2.25 W | |
| Nominal voltage | 12 V | |
| Nominal current, RMS | 0.188 A | typ. |
| Peak current, RMS | 0.45 A | typ. |
| Drive force in negative direction of motion in X | 20 N | typ. |
| Drive force in positive direction of motion in X | 20 N | typ. |
| Torque constant | 0.014 N·m/A | typ. |
| Time constant | 9 ms | |
| Resistance phase-phase | 13.8 Ω | typ. |
| Inductance phase-phase | 0.32 mH | |
| Number of pole pairs | 1 | |
| Mechanical Properties | M-122.2DD1 | Tolerance |
| Guide | Ball guide | |
| Drive screw type | Ball screw | |
| Drive screw pitch | 0.5 mm | |
| Stiffness in X | 0.25 N/µm | |
| Moved mass in X, unloaded | 50 g | |
| Permissible push force in Y | 25 N | max. |
| Permissible push force in Z | 50 N | max. |
| Permissible torque in θx | 0.15 N·m | max. |
| Permissible torque in θY | 0.15 N·m | max. |
| Permissible torque in θZ | 0.15 N·m | max. |
| Overall mass | 220 g | |
| Material | Aluminum, steel | |
| Miscellaneous | M-122.2DD1 | Tolerance |
| Connector | D-sub 15-pin (m) | |
| Recommended controllers / drivers | C-863 C-884 | |
| Cable length | 0.5 m | |
| Operating temperature range | 10 to 50 °C |