Products PI - XY Stages XY Metrology Stages
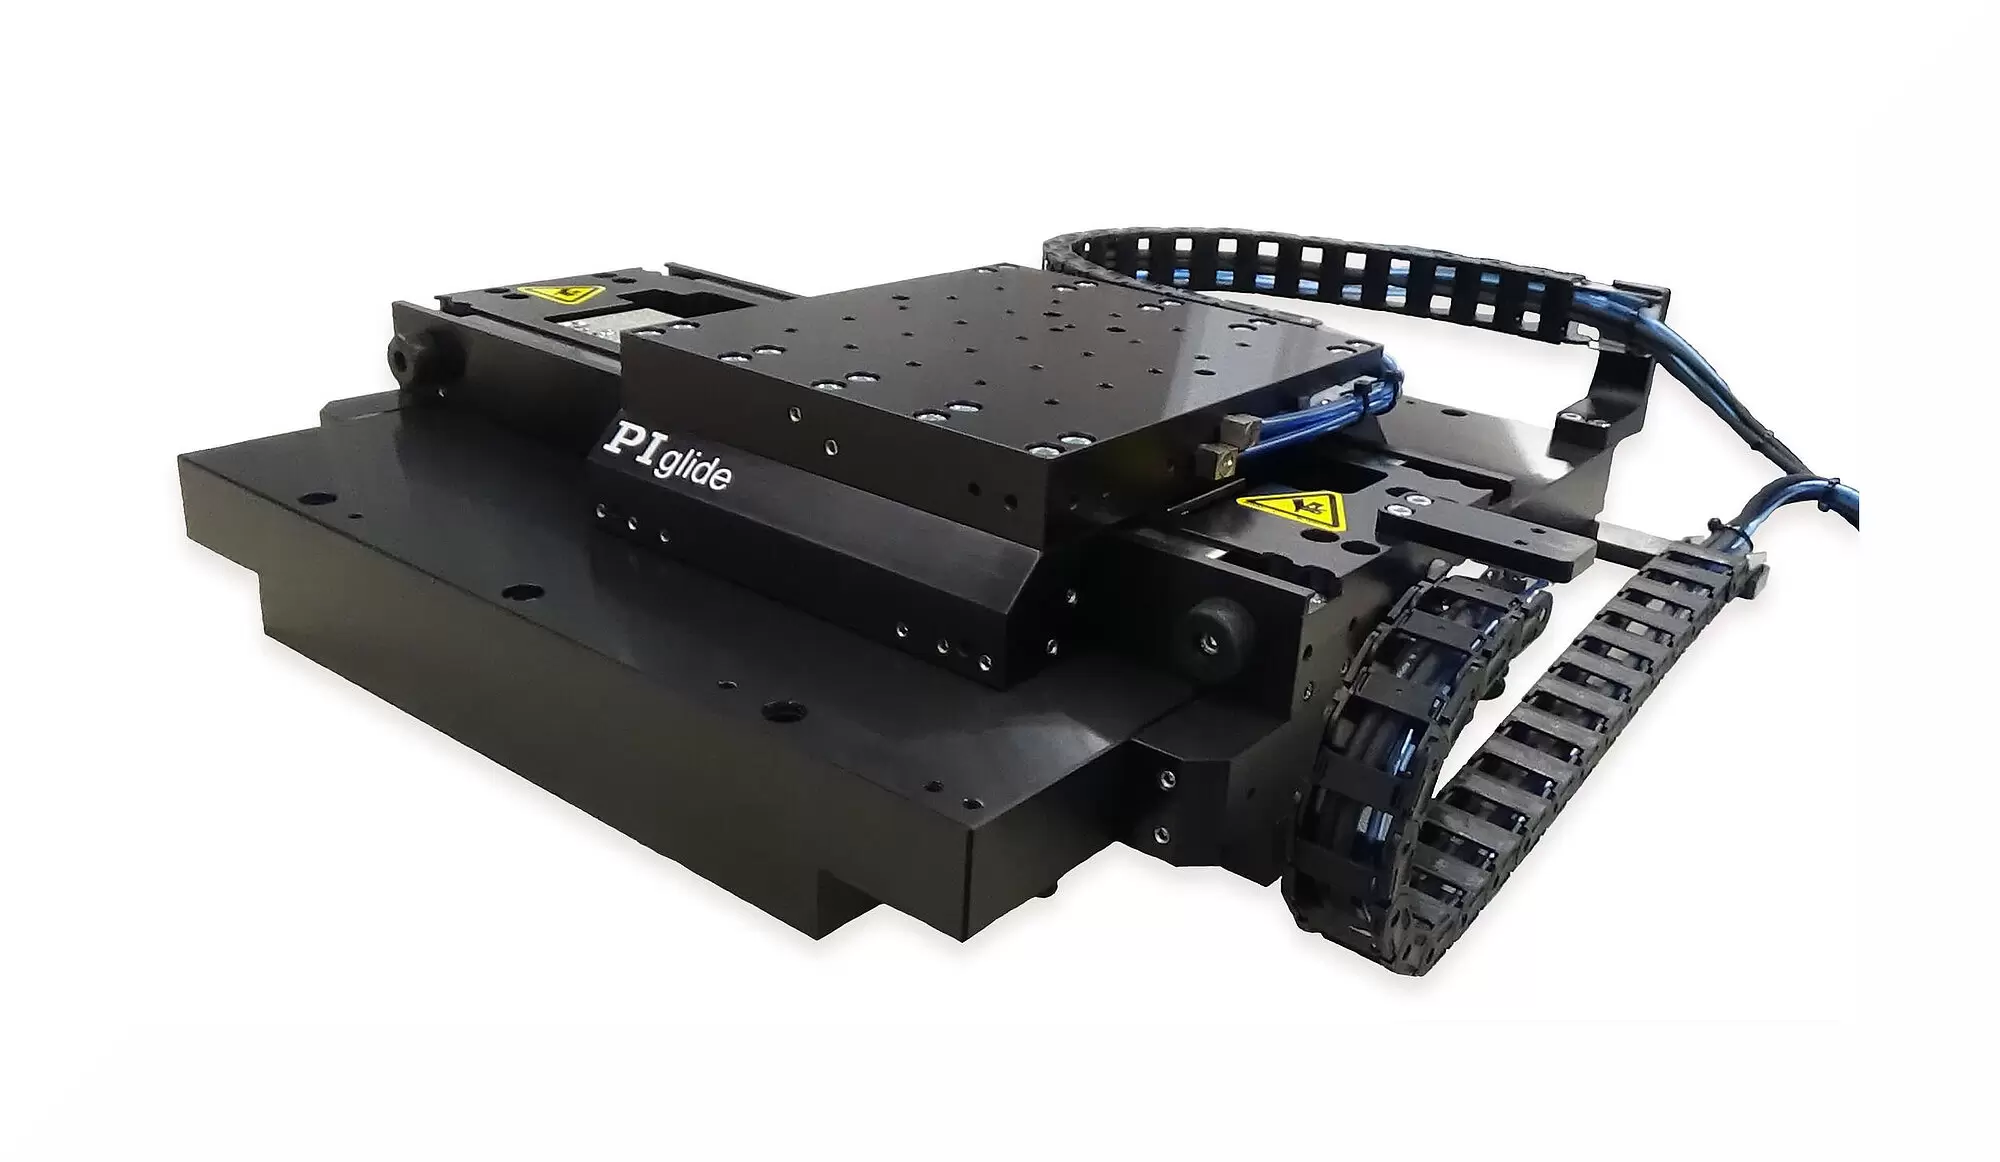
A-311 PIglide IS Planar Scanner with Air Bearing
High-Performance, Compact XY Nanopositioning System
  • Ideal for scanning applications or high-precision positioning
  • Cleanroom compatible
  • Travel ranges to 300 mm × 400 mm
  • Load capacity to 147 N
  • Low profile
  • Resolution to 1 nm

Product overview

The high-precision PIglide IS XY planar scanner with air bearing has a flat design and is an alternative to the stacked XY stages. The efficient, compact design saves space in machines with limited installation space.

Accessories and options

  • Encoder
  • PIglide filter and air preparation kit
  • Multi-axis motion controller and direct drives
  • Machine bases
  • Base plates made of granite and systems for reducing vibration

PIMag® magnetic direct drive

3-phase magnetic direct drives do not use mechanical components in the drivetrain, they transmit the drive force to the motion platform directly and without friction. The drives reach high velocities and accelerations. Ironless motors are particularly suitable for positioning tasks with the highest demands on precision because there is no undesirable interaction with the permanent magnets. This allows smooth running even at the lowest velocities and at the same time, there is no vibration at high velocities. Nonlinearity in control behavior is avoided and any position can be controlled easily. The drive force can be set freely.

Operation with digital controllers from leading manufacturers offers advanced control algorithms for improving the dynamics and error compensation.

Application fields

PIglide positioning systems are ideally suited for high-precision applications, such as inspection systems, laser marking, microscopy or scanning.

Motion A-311.DA1 A-311.DB1 A-311.AA1 A-311.AB1 A-311.BA1 A-311.BB1 A-311.CA1 A-311.CB1 A-311.FB1 A-311.GB1 Tolerance
Active axes X Y X Y X Y X Y X Y X Y X Y X Y X Y X Y  
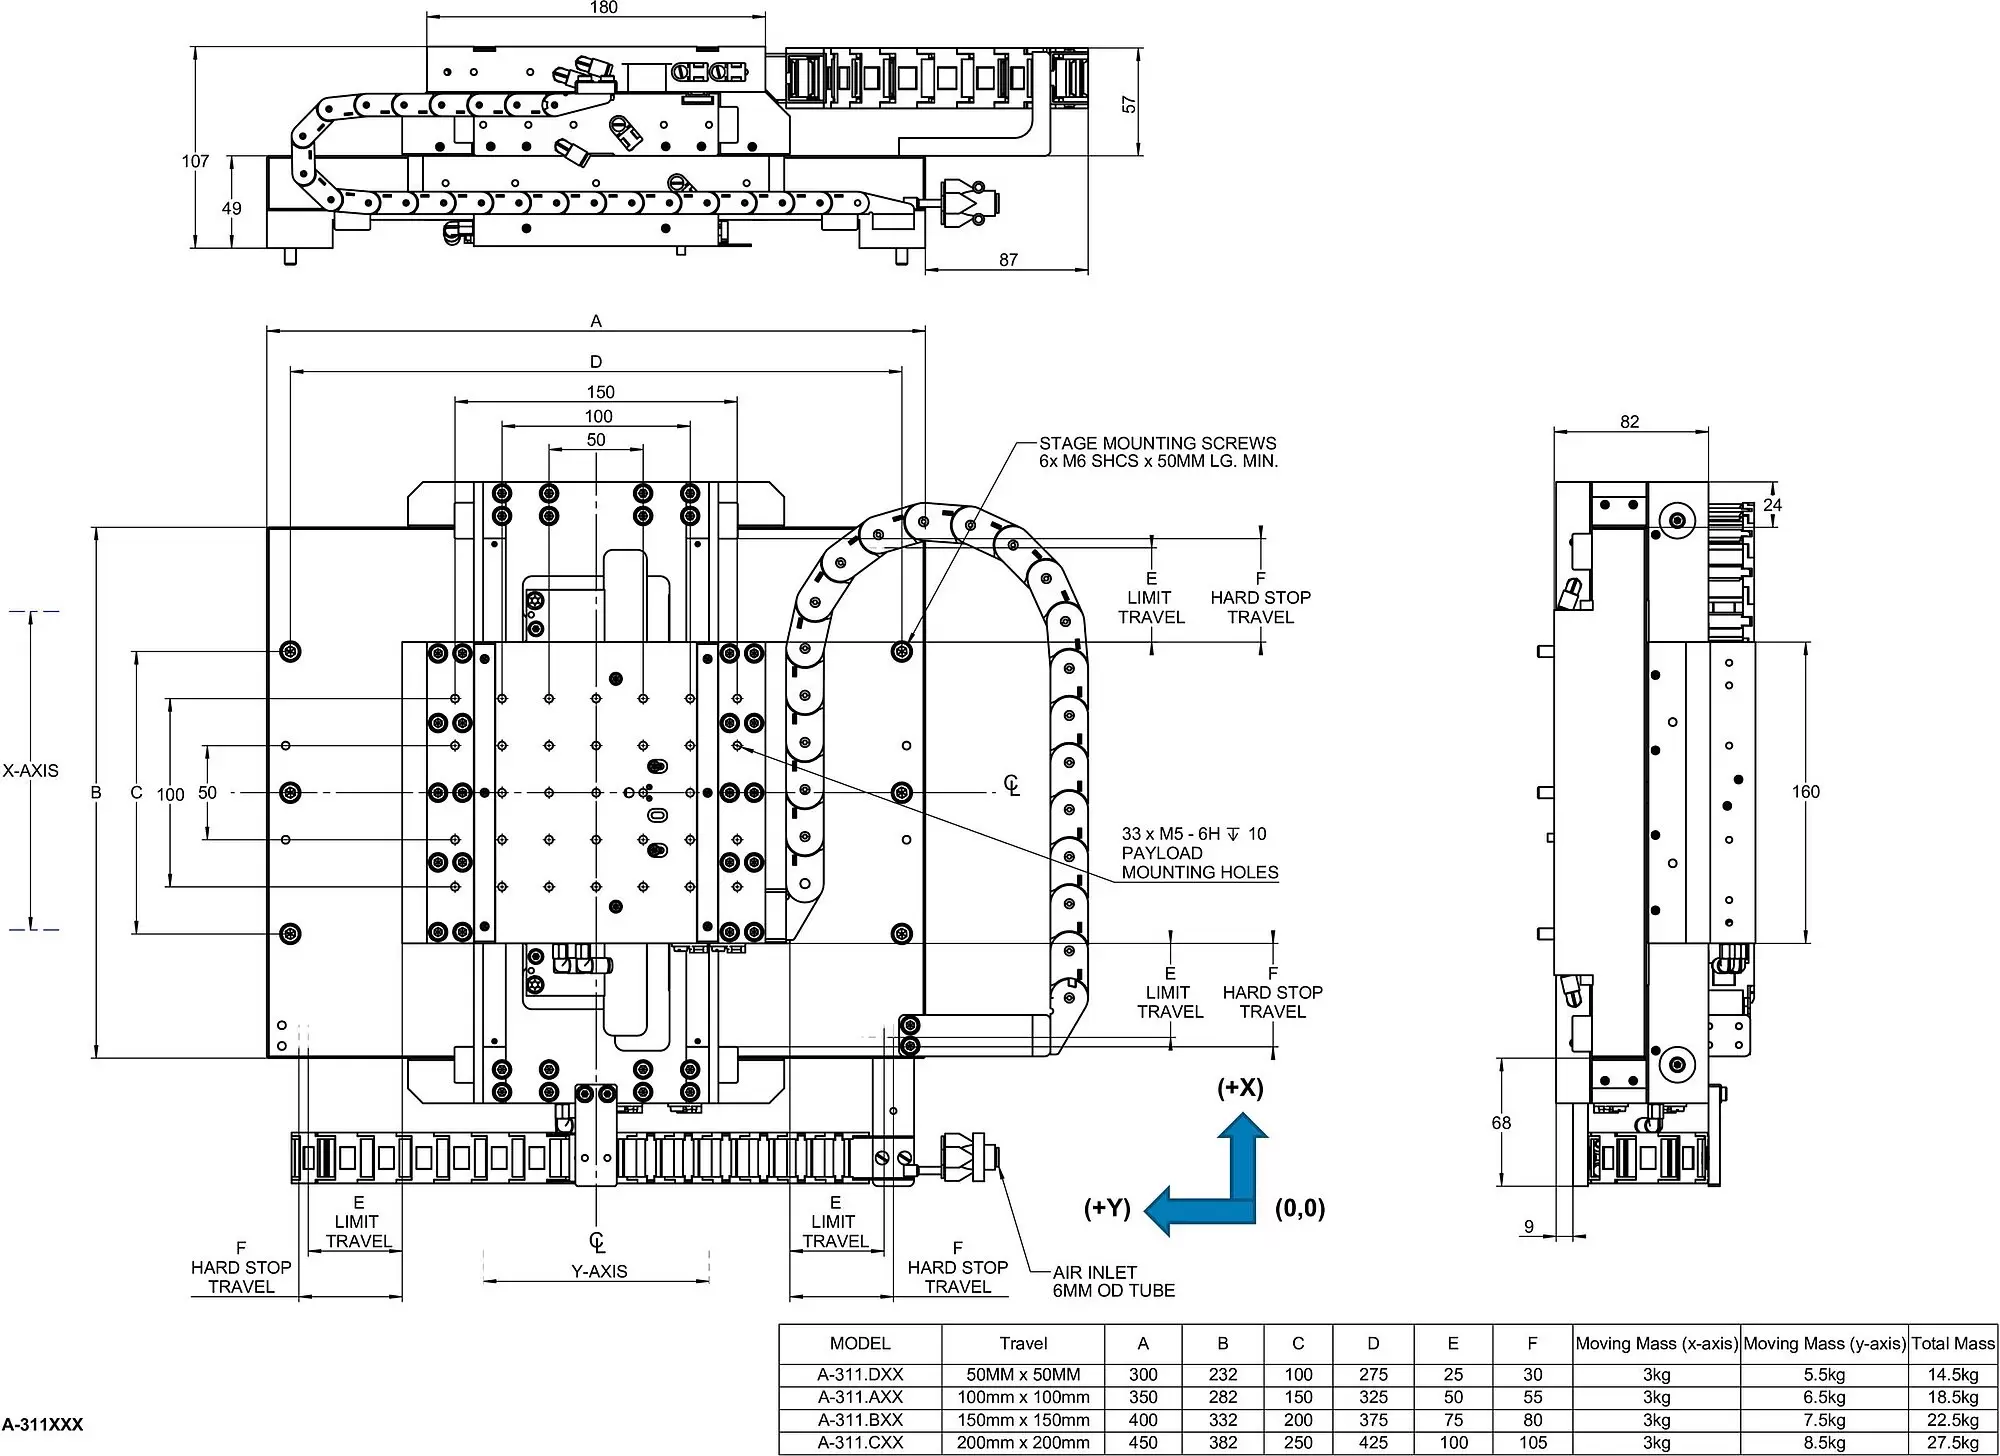
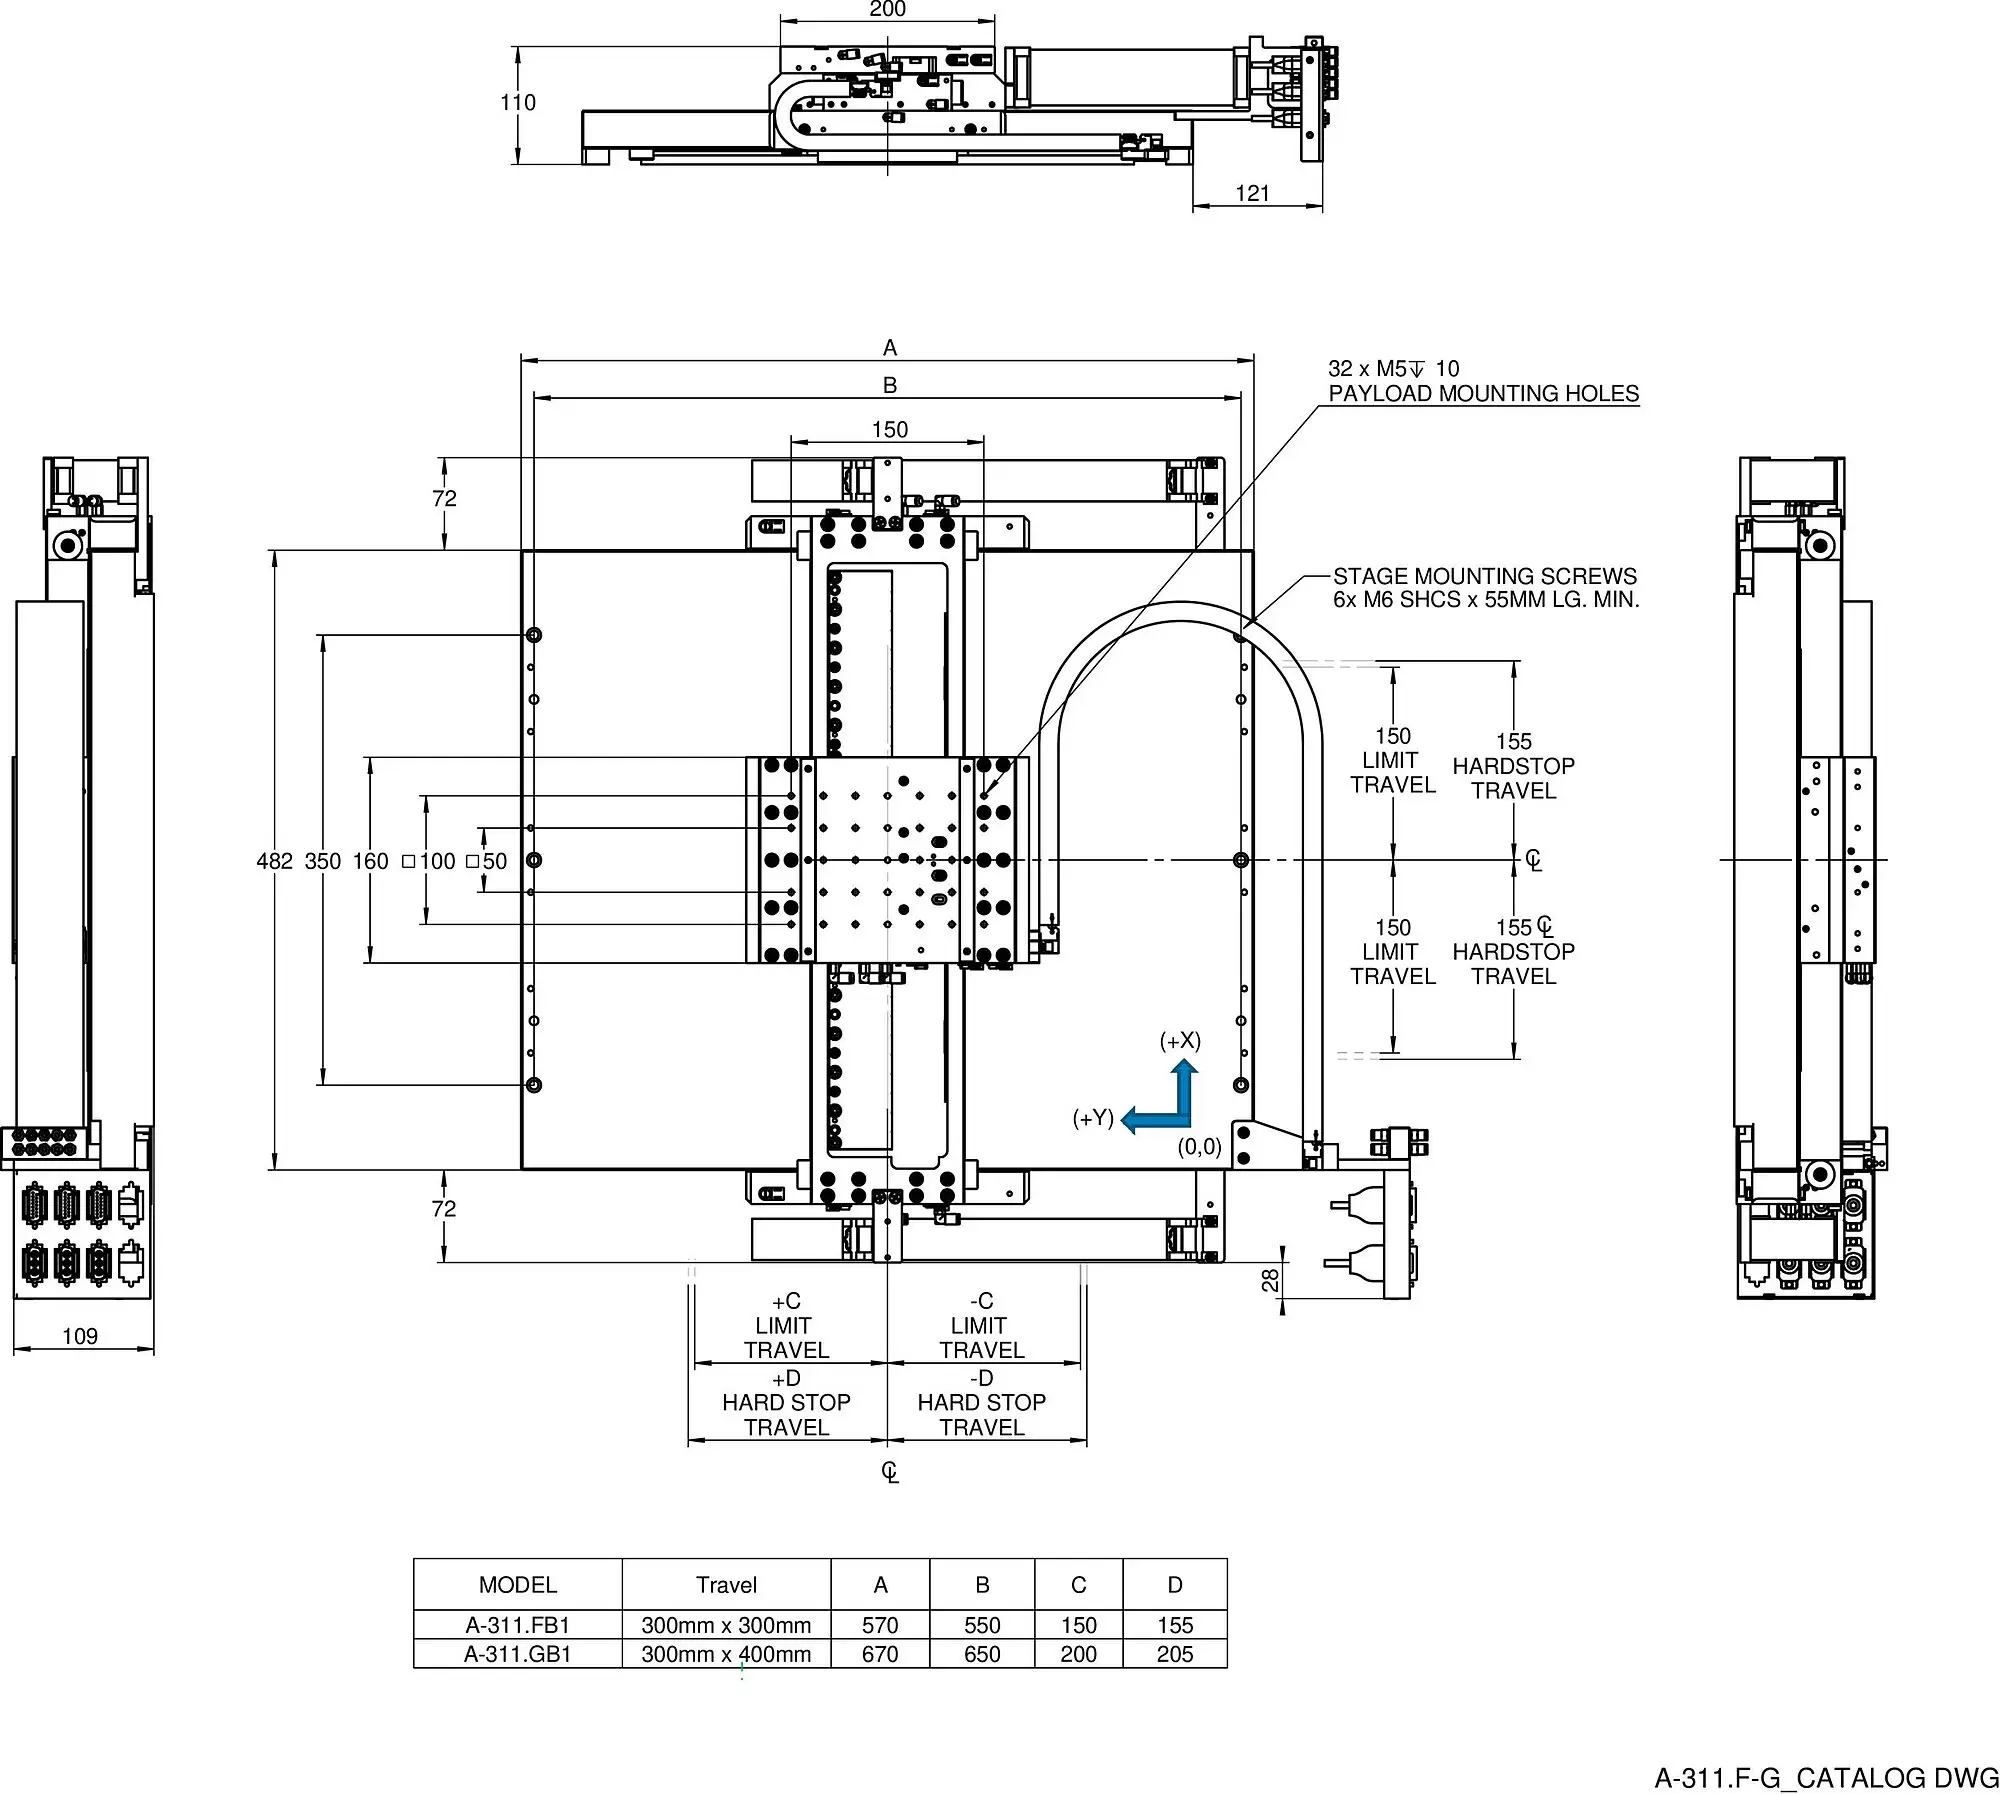
Travel range in X 50 mm 50 mm 100 mm 100 mm 150 mm 150 mm 200 mm 200 mm 300 mm 300 mm  
Travel range in Y 50 mm 50 mm 100 mm 100 mm 150 mm 150 mm 200 mm 200 mm 300 mm 400 mm  
Acceleration in X, unloaded 27.5 m/s² 27.5 m/s² 27.5 m/s² 27.5 m/s² 27.5 m/s² 27.5 m/s² 27.5 m/s² 27.5 m/s² 10 m/s² 10 m/s² max.
Acceleration in Y, unloaded 15 m/s² 15 m/s² 13 m/s² 13 m/s² 11 m/s² 11 m/s² 10 m/s² 10 m/s² 10 m/s² 10 m/s² max.
Maximum velocity in X, unloaded 2000 mm/s 2000 mm/s 2000 mm/s 2000 mm/s 2000 mm/s 2000 mm/s 2000 mm/s 2000 mm/s 1000 mm/s 1000 mm/s  
Maximum velocity in Y, unloaded 2000 mm/s 2000 mm/s 2000 mm/s 2000 mm/s 2000 mm/s 2000 mm/s 2000 mm/s 2000 mm/s 1000 mm/s 1000 mm/s  
Orthogonality ± 12.5 µrad ± 12.5 µrad ± 12.5 µrad ± 12.5 µrad ± 12.5 µrad ± 12.5 µrad ± 12.5 µrad ± 12.5 µrad ± 5 µrad ± 25 µrad typ.
Straightness (Linear crosstalk in X with motion in Y) ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.5 µm ± 0.5 µm ± 1 µm ± 0.5 µm max.
Straightness (Linear crosstalk in Y with motion in X) ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.5 µm ± 0.5 µm ± 1 µm ± 0.5 µm max.
Flatness (Linear crosstalk in Z with motion in X) ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.5 µm ± 0.5 µm ± 0.75 µm ± 0.75 µm ± 1.5 µm ± 0.75 µm max.
Flatness (Linear crosstalk in Z with motion in Y) ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.25 µm ± 0.5 µm ± 0.5 µm ± 0.75 µm ± 0.75 µm ± 1.5 µm ± 0.75 µm max.
Pitch (Rotational crosstalk in θX with motion in Y) ± 10 µrad ± 10 µrad ± 12.5 µrad ± 12.5 µrad ± 17.5 µrad ± 17.5 µrad ± 20 µrad ± 20 µrad ± 40 µrad ± 20 µrad max.
Pitch (Rotational crosstalk in θY with motion in X) ± 10 µrad ± 10 µrad ± 12.5 µrad ± 12.5 µrad ± 17.5 µrad ± 17.5 µrad ± 20 µrad ± 20 µrad ± 40 µrad ± 20 µrad max.
Yaw (Rotational crosstalk in θZ with motion in X) ± 5 µrad ± 5 µrad ± 5 µrad ± 5 µrad ± 7.5 µrad ± 7.5 µrad ± 10 µrad ± 10 µrad ± 20 µrad ± 10 µrad max.
Yaw (Rotational crosstalk in θZ with motion in Y) ± 5 µrad ± 5 µrad ± 5 µrad ± 5 µrad ± 7.5 µrad ± 7.5 µrad ± 10 µrad ± 10 µrad ± 20 µrad ± 10 µrad max.
Positioning A-311.DA1 A-311.DB1 A-311.AA1 A-311.AB1 A-311.BA1 A-311.BB1 A-311.CA1 A-311.CB1 A-311.FB1 A-311.GB1 Tolerance
Positioning accuracy in X, calibrated ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm typ.
Positioning accuracy in X, uncalibrated ± 1 µm ± 1 µm ± 1.5 µm ± 1.5 µm ± 2 µm ± 2 µm ± 2.5 µm ± 2.5 µm     typ.
Positioning accuracy in Y, calibrated ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm ± 0.2 µm typ.
Positioning accuracy in Y, uncalibrated ± 1 µm ± 1 µm ± 1.5 µm ± 1.5 µm ± 2 µm ± 2 µm ± 2.5 µm ± 2.5 µm     typ.
Bidirectional repeatability in X 0.1 µm 0.1 µm 0.1 µm 0.1 µm 0.1 µm 0.1 µm 0.1 µm 0.1 µm 0.15 µm 0.1 µm typ.
Bidirectional repeatability in Y 0.1 µm 0.1 µm 0.1 µm 0.1 µm 0.1 µm 0.1 µm 0.1 µm 0.1 µm 0.15 µm 0.1 µm typ.
Reference switch Encoder index   Encoder index   Encoder index   Encoder index        
Limit switches Hall effect, N/O contact, 5 V to 24 V, open collector   Hall effect, N/O contact, 5 V to 24 V, open collector   Hall effect, N/O contact, 5 V to 24 V, open collector   Hall effect, N/O contact, 5 V to 24 V, open collector        
Integrated sensor Incremental linear encoder Absolute linear encoder Incremental linear encoder Absolute linear encoder Incremental linear encoder Absolute linear encoder Incremental linear encoder Absolute linear encoder Absolute linear encoder Absolute linear encoder  
Sensor signal Sin/cos, 1 V peak-peak BiSS-C Sin/cos, 1 V peak-peak BiSS-C Sin/cos, 1 V peak-peak BiSS-C Sin/cos, 1 V peak-peak BiSS-C BiSS-C BiSS-C  
Sensor signal period 20 µm   20 µm   20 µm   20 µm        
Sensor resolution 1.2 nm 1 nm 1.2 nm 1 nm 1.2 nm 1 nm 1.2 nm 1 nm 1 nm 1 nm  
Drive Properties A-311.DA1 A-311.DB1 A-311.AA1 A-311.AB1 A-311.BA1 A-311.BB1 A-311.CA1 A-311.CB1 A-311.FB1 A-311.GB1 Tolerance
Drive type Ironless 3-phase linear motor Ironless 3-phase linear motor Ironless 3-phase linear motor Ironless 3-phase linear motor Ironless 3-phase linear motor Ironless 3-phase linear motor Ironless 3-phase linear motor Ironless 3-phase linear motor Ironless 3-phase linear motor Ironless 3-phase linear motor  
Nominal voltage 48 V 48 V 48 V 48 V 48 V 48 V 48 V 48 V 48 V 48 V  
Peak voltage 80 V 80 V 80 V 80 V 80 V 80 V 80 V 80 V 300 V 80 V  
Nominal current, RMS 3.2 A 3.2 A 3.2 A 3.2 A 3.2 A 3.2 A 3.2 A 3.2 A 2.9 A 3.2 A typ.
Peak current, RMS 6.9 A 6.9 A 6.9 A 6.9 A 6.9 A 6.9 A 6.9 A 6.9 A 10 A 6.9 A typ.
Drive force in positive direction of motion in X 39 N 39 N 39 N 39 N 39 N 39 N 39 N 39 N 58 N 39 N typ.
Drive force in positive direction of motion in Y 39 N 39 N 39 N 39 N 39 N 39 N 39 N 39 N 58 N 39 N typ.
Drive force in negative direction of motion in X 39 N 39 N 39 N 39 N 39 N 39 N 39 N 39 N 58 N 39 N typ.
Drive force in negative direction of motion in Y 39 N 39 N 39 N 39 N 39 N 39 N 39 N 39 N 58 N 39 N typ.
Peak force in positive direction of motion in X 85 N 85 N 85 N 85 N 85 N 85 N 85 N 85 N 85 N 85 N  
Peak force in positive direction of motion in Y 85 N 85 N 85 N 85 N 85 N 85 N 85 N 85 N 85 N 85 N  
Peak force in negative direction of motion in X 85 N 85 N 85 N 85 N 85 N 85 N 85 N 85 N 200 N 85 N  
Peak force in negative direction of motion in Y 85 N 85 N 85 N 85 N 85 N 85 N 85 N 85 N 200 N 85 N  
Force constant 12.3 N/A 12.3 N/A 12.3 N/A 12.3 N/A 12.3 N/A 12.3 N/A 12.3 N/A 12.3 N/A 19.9 N/A 12.3 N/A  
Resistance phase-phase 3.6 Ω 3.6 Ω 3.6 Ω 3.6 Ω 3.6 Ω 3.6 Ω 3.6 Ω 3.6 Ω 5.6 Ω 3.6 Ω typ.
Inductance phase-phase 1.24 mH 1.24 mH 1.24 mH 1.24 mH 1.24 mH 1.24 mH 1.24 mH 1.24 mH 1.8 mH 1.24 mH  
Back EMF phase-phase 10.1 V·s/m 10.1 V·s/m 10.1 V·s/m 10.1 V·s/m 10.1 V·s/m 10.1 V·s/m 10.1 V·s/m 10.1 V·s/m 16 V·s/m 10.1 V·s/m max.
Pole pitch N-N 24 mm 24 mm 24 mm 24 mm 24 mm 24 mm 24 mm 24 mm 24 mm 24 mm  
Mechanical Properties A-311.DA1 A-311.DB1 A-311.AA1 A-311.AB1 A-311.BA1 A-311.BB1 A-311.CA1 A-311.CB1 A-311.FB1 A-311.GB1 Tolerance
Permissible push force in Z 147 N 147 N 147 N 147 N 147 N 147 N 147 N 147 N 147 N 147 N max.
Moved mass in X, unloaded 3000 g 3000 g 3000 g 3000 g 3000 g 3000 g 3000 g 3000 g 4000 g 4000 g  
Moved mass in Y, unloaded 5500 g 5500 g 6500 g 6500 g 7500 g 7500 g 8500 g 8500 g 8500 g 8500 g  
Guide Air bearing guide with air preload Air bearing guide with air preload Air bearing guide with air preload Air bearing guide with air preload Air bearing guide with air preload Air bearing guide with air preload Air bearing guide with air preload Air bearing guide with air preload Air bearing guide with vacuum preload Air bearing guide with vacuum preload  
Overall mass 14500 g 14500 g 18500 g 18500 g 22500 g 22500 g 27500 g 27500 g 48000 g 55000 g  
Material

Hardcoat aluminum, stainless steel mounting hardware

Hardcoat aluminum, stainless steel mounting hardware

Hardcoat aluminum, stainless steel mounting hardware

Hardcoat aluminum, stainless steel mounting hardware

Hardcoat aluminum, stainless steel mounting hardware

Hardcoat aluminum, stainless steel mounting hardware

Hardcoat aluminum, stainless steel mounting hardware

Hardcoat aluminum, stainless steel mounting hardware

Hardcoat aluminum, stainless steel mounting hardware

Hardcoat aluminum, stainless steel mounting hardware

 
Miscellaneous A-311.DA1 A-311.DB1 A-311.AA1 A-311.AB1 A-311.BA1 A-311.BB1 A-311.CA1 A-311.CB1 A-311.FB1 A-311.GB1 Tolerance
Operating temperature range +15 to +25 °C +15 to +25 °C +15 to +25 °C +15 to +25 °C +15 to +25 °C +15 to +25 °C +15 to +25 °C +15 to +25 °C +15 to +25 °C +15 to +25 °C  
Connector D-sub 9W4 (m) D-sub 9W4 (m) D-sub 9W4 (m) D-sub 9W4 (m) D-sub 9W4 (m) D-sub 9W4 (m) D-sub 9W4 (m) D-sub 9W4 (m) D-sub 3W3 (m) D-sub 3W3 (m)  
Sensor connector D-sub 15-pin (m) D-sub 15-pin (m) D-sub 15-pin (m) D-sub 15-pin (m) D-sub 15-pin (m) D-sub 15-pin (m) D-sub 15-pin (m) D-sub 15-pin (m) D-sub 15-pin (m) D-sub 15-pin (m)  
Operating pressure 415 to 485 (60 to 70 psi) kPa 415 to 485 (60 to 70 psi) kPa 415 to 485 (60 to 70 psi) kPa 415 to 485 (60 to 70 psi) kPa 415 to 485 (60 to 70 psi) kPa 415 to 485 (60 to 70 psi) kPa 415 to 485 (60 to 70 psi) kPa 415 to 485 (60 to 70 psi) kPa 415 to 485 (60 to 70 psi) kPa 415 to 485 (60 to 70 psi) kPa  
Air consumption 56 L/min 56 L/min 56 L/min 56 L/min 56 L/min 56 L/min 56 L/min 56 L/min 56 L/min 56 L/min max.
Air quality Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3 Clean (filtered up to 1.0 µm or better) - ISO 8573–1 class 1 Oil free - ISO 8573–1 class 1 Dry (-15 °C dew point) - ISO 8573–1 class 3  
Recommended controllers / drivers

A-81x ACS-based motion controller for medium power requirements, 2 / 4 / 6 axes

A-82x ACS-based motion controller for high power requirements, 4 / 6 / 8 axes

A-81x ACS-based motion controller for medium power requirements, 2 / 4 / 6 axes

A-82x ACS-based motion controller for high power requirements, 4 / 6 / 8 axes

A-81x ACS-based motion controller for medium power requirements, 2 / 4 / 6 axes

A-82x ACS-based motion controller for high power requirements, 4 / 6 / 8 axes

A-81x ACS-based motion controller for medium power requirements, 2 / 4 / 6 axes

A-82x ACS-based motion controller for high power requirements, 4 / 6 / 8 axes

A-81x ACS-based motion controller for medium power requirements, 2 / 4 / 6 axes

A-82x ACS-based motion controller for high power requirements, 4 / 6 / 8 axes

A-81x ACS-based motion controller for medium power requirements, 2 / 4 / 6 axes

A-82x ACS-based motion controller for high power requirements, 4 / 6 / 8 axes

A-81x ACS-based motion controller for medium power requirements, 2 / 4 / 6 axes

A-82x ACS-based motion controller for high power requirements, 4 / 6 / 8 axes

A-81x ACS-based motion controller for medium power requirements, 2 / 4 / 6 axes

A-82x ACS-based motion controller for high power requirements, 4 / 6 / 8 axes

A-81x ACS-based motion controller for medium power requirements, 2 / 4 / 6 axes

A-82x ACS-based motion controller for high power requirements, 4 / 6 / 8 axes

A-81x ACS-based motion controller for medium power requirements, 2 / 4 / 6 axes

A-82x ACS-based motion controller for high power requirements, 4 / 6 / 8 axes


Note on the linear and rotational crosstalk: Dependent on the flatness of the surface, on which the stage is mounted.

Note on the velocity and acceleration: It can be limited by payload, controller, or drive performance.

Note on the permissible push force: Assumes that the payload center of gravity is centered no more than 50 mm above the motion platform. The stage is designed for horizontal operation only.

Note on the sensor resolution: Assumes a 4096x interpolation. Contact PI for the use of other factors.

Note on the positioning accuracy: Improved accuracy can be obtained with controller-based error compensation. The stage must be ordered with a controller from PI to reach these values.

Accuracy values assume short duration and do not consider the long-term effects of thermal drift on the stage.

Note on the operating pressure: To protect the stage against damage, it is recommended to connect an air pressure sensor to the Motion-Stop input of the controller.

All specifications apply per axis, if not otherwise described.

3D Models
3D Models
3-D model A-311
Version / Date
2021-11-12
zip - 15 MB
Datasheet
Datasheet
Datasheet A-311
Version / Date
2023-09-04
pdf - 2 MB
Documentation
Documentation
User Manual A311D0002
A-311.FXx/.GXx PIglide: XY Planar Scanner with Air Bearings
Version / Date
2.0 2021-11-11
pdf - 955 KB
Documentation
User Manual A311D0001
A-311 PIglide IS: Planar XY Air Bearing Stage
Version / Date
1.5 2019-01-28
pdf - 1 MB
White Papers
White Papers
Air Bearings: When to Use and When to Avoid in Your Motion Application
All Positioning Stages are not Created Equal. Author: Matt Reck, PI
Version / Date
WP4003 2015-09
pdf - 3 MB
A-311.DA1
PIglide IS planar scanner with air bearings; Ironless 3-phase linear motor; 50 mm × 50 mm travel range (X × Y); 147 N load capacity; 2000 mm/s × 2000 mm/s maximum velocity; Incremental linear encoder, 20 µm sensor signal period, sin/cos, 1 V peak-peak
A-311.DB1
PIglide IS planar scanner with air bearings; Ironless 3-phase linear motor; 50 mm × 50 mm travel range (X × Y); 147 N load capacity; 2000 mm/s × 2000 mm/s maximum velocity; Absolute linear encoder, 1 nm sensor resolution, BiSS-C
A-311.AA1
PIglide IS planar scanner with air bearings; Ironless 3-phase linear motor; 100 mm × 100 mm travel range (X × Y); 147 N load capacity; 2000 mm/s × 2000 mm/s maximum velocity; Incremental linear encoder, 20 µm sensor signal period, sin/cos, 1 V peak-peak
A-311.AB1
PIglide IS planar scanner with air bearings; Ironless 3-phase linear motor; 100 mm × 100 mm travel range (X × Y); 147 N load capacity; 2000 mm/s × 2000 mm/s maximum velocity; Absolute linear encoder, 1 nm sensor resolution, BiSS-C
A-311.BA1
PIglide IS planar scanner with air bearings; Ironless 3-phase linear motor; 150 mm × 150 mm travel range (X × Y); 147 N load capacity; 2000 mm/s × 2000 mm/s maximum velocity; Incremental linear encoder, 20 µm sensor signal period, sin/cos, 1 V peak-peak
A-311.BB1
PIglide IS planar scanner with air bearings; Ironless 3-phase linear motor; 150 mm × 150 mm travel range (X × Y); 147 N load capacity; 2000 mm/s × 2000 mm/s maximum velocity; Absolute linear encoder, 1 nm sensor resolution, BiSS-C
A-311.CA1
PIglide IS planar scanner with air bearings; Ironless 3-phase linear motor; 200 mm × 200 mm travel range (X × Y); 147 N load capacity; 2000 mm/s × 2000 mm/s maximum velocity; Incremental linear encoder, 20 µm sensor signal period, sin/cos, 1 V peak-peak
A-311.CB1
PIglide IS planar scanner with air bearings; Ironless 3-phase linear motor; 200 mm × 200 mm travel range (X × Y); 147 N load capacity; 2000 mm/s × 2000 mm/s maximum velocity; Absolute linear encoder, 1 nm sensor resolution, BiSS-C
A-311.FB1
PIglide IS planar scanner with air bearings; ironless 3-phase linear motor; 300 mm × 300 mm travel range (X × Y); 147 N load capacity; 1000 mm/s × 1000 mm/s maximum velocity; absolute linear encoder, 1 nm sensor resolution, BiSS-C
A-311.GB1
PIglide IS planar scanner with air bearings; Ironless 3-phase linear motor; 300 mm × 400 mm travel range (X × Y); 147 N load capacity; 1000 mm/s × 1000 mm/s maximum velocity; Absolute linear encoder, 1 nm sensor resolution, BiSS-C
Direct the future with the power of the past.
Expertise
Markets Technologies
Contact
Nano Dünya Mak. San. Tic. Ltd. Şti.
Parseller Mah. Gündoğan Sok. No:8/A
Ümraniye/İstanbul

02166140039
info@nanodunya.com.tr
Copyright © 2024 by Nano Dünya. All rights reserved.
x
Quote List
Your quote list is currently empty.
x
Download Request
Your download list is currently empty.
0 0 Whatsapp