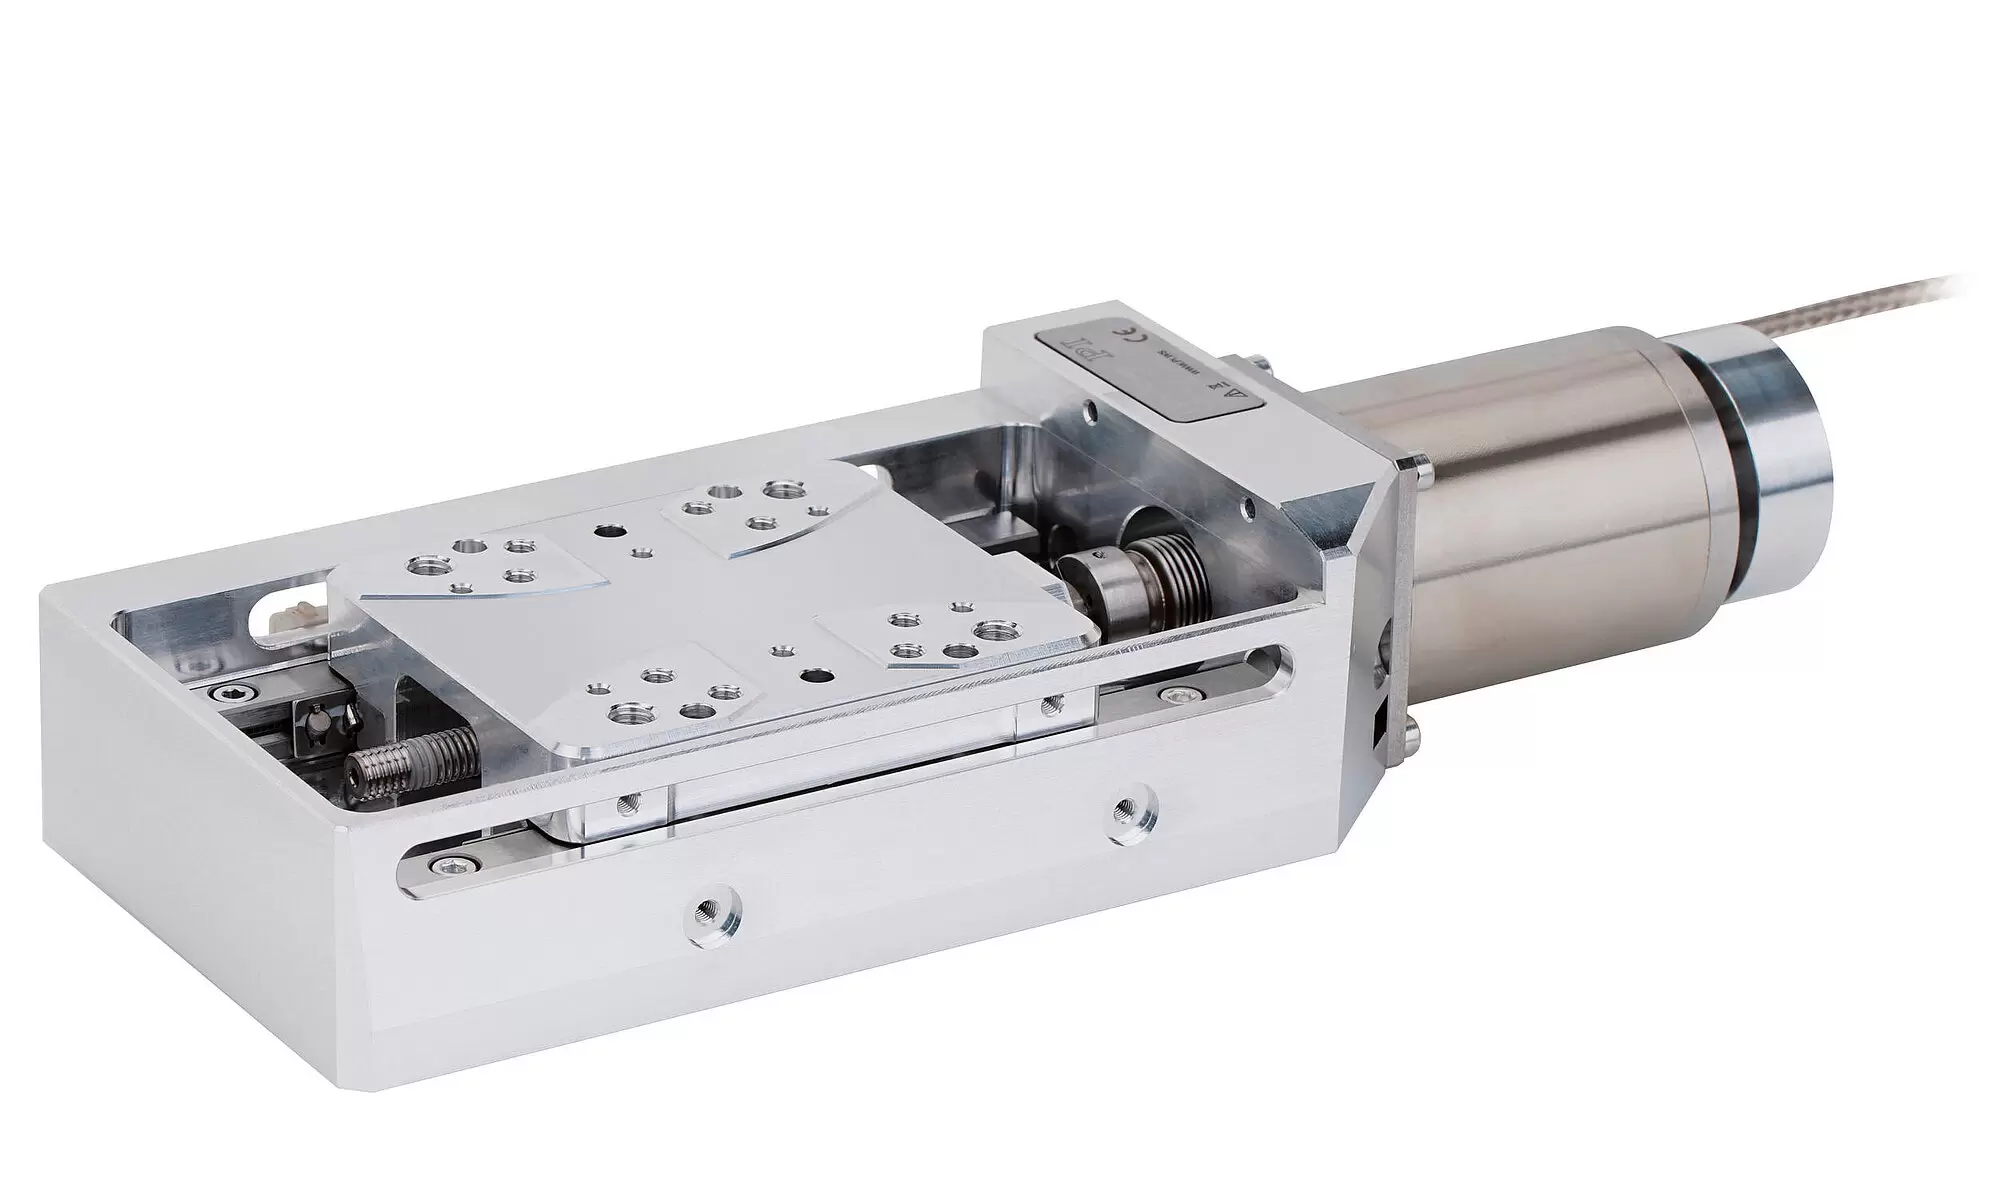
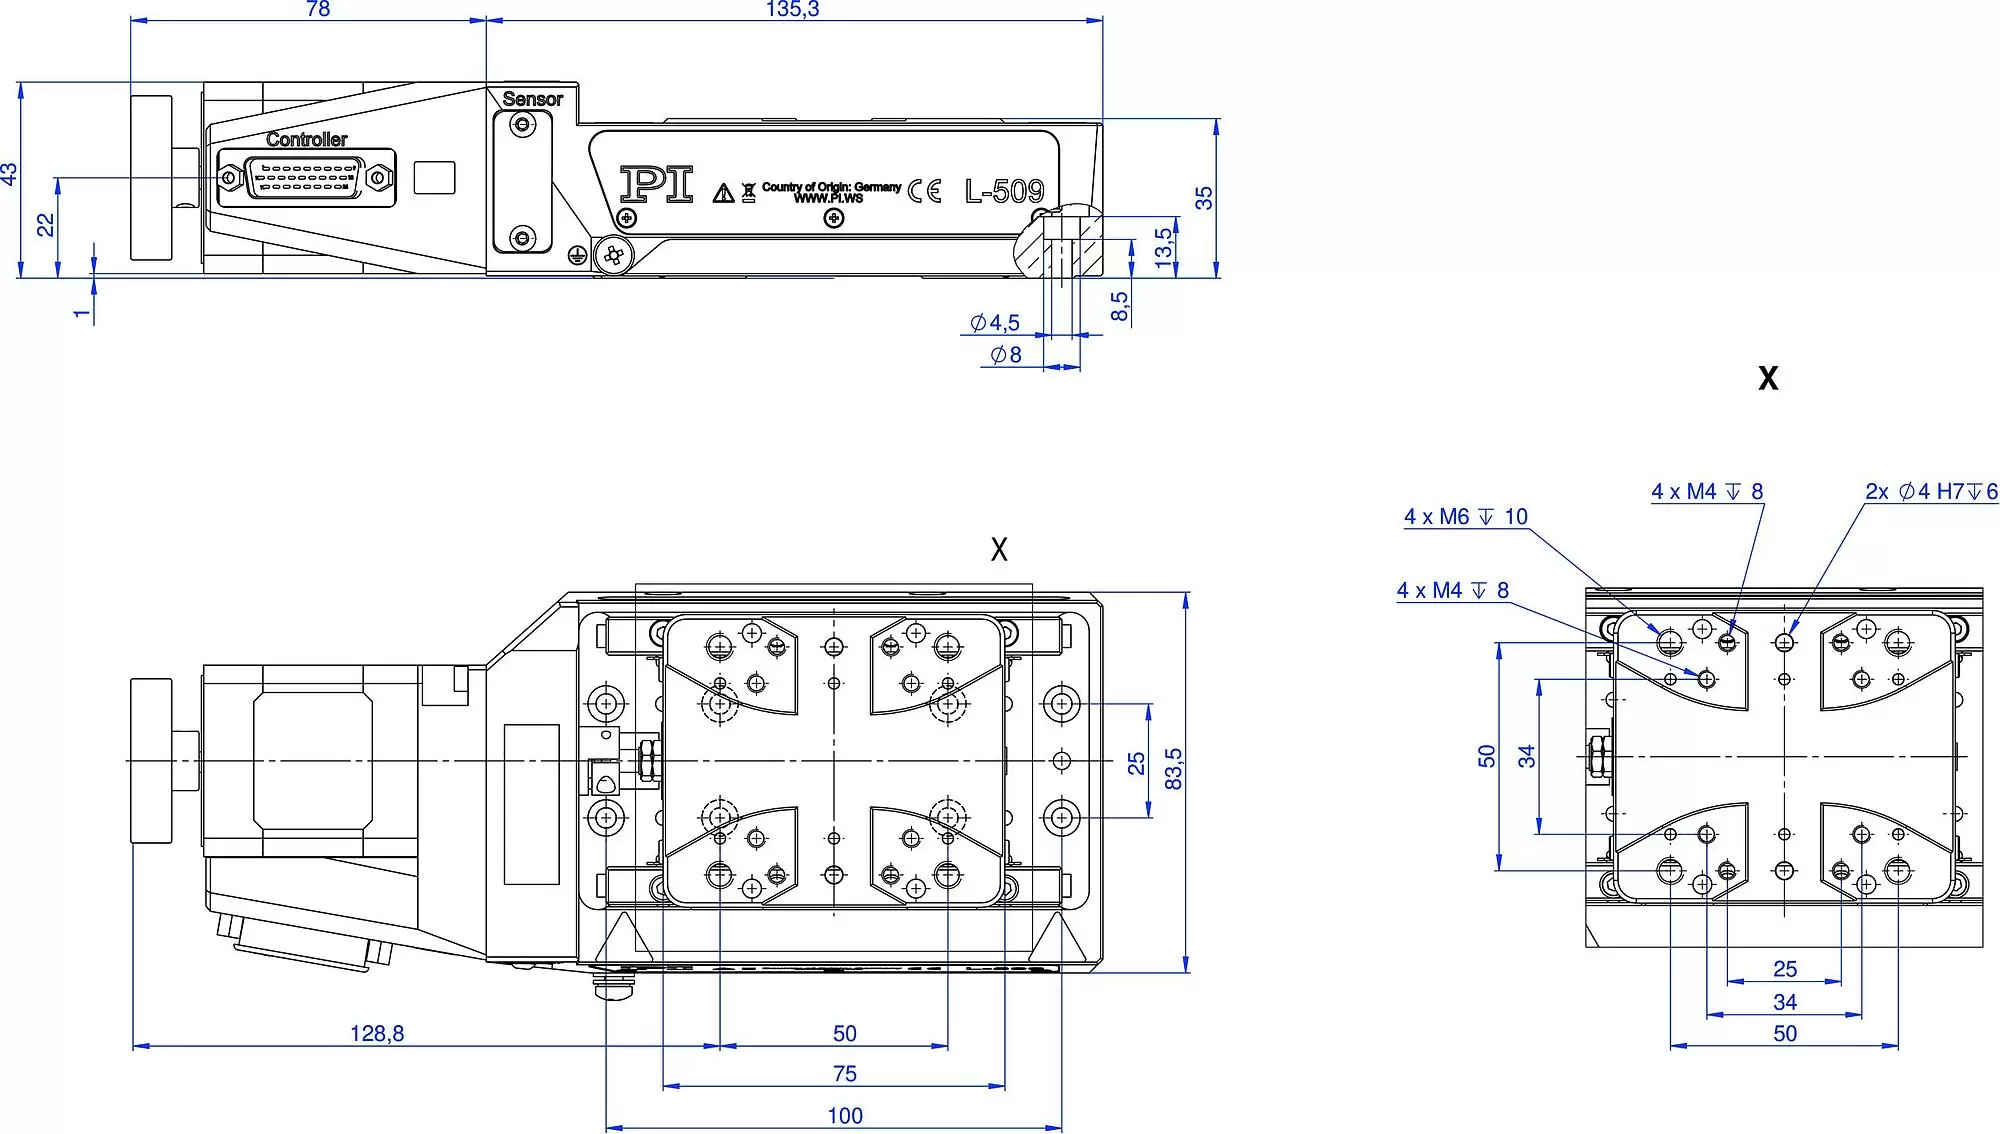
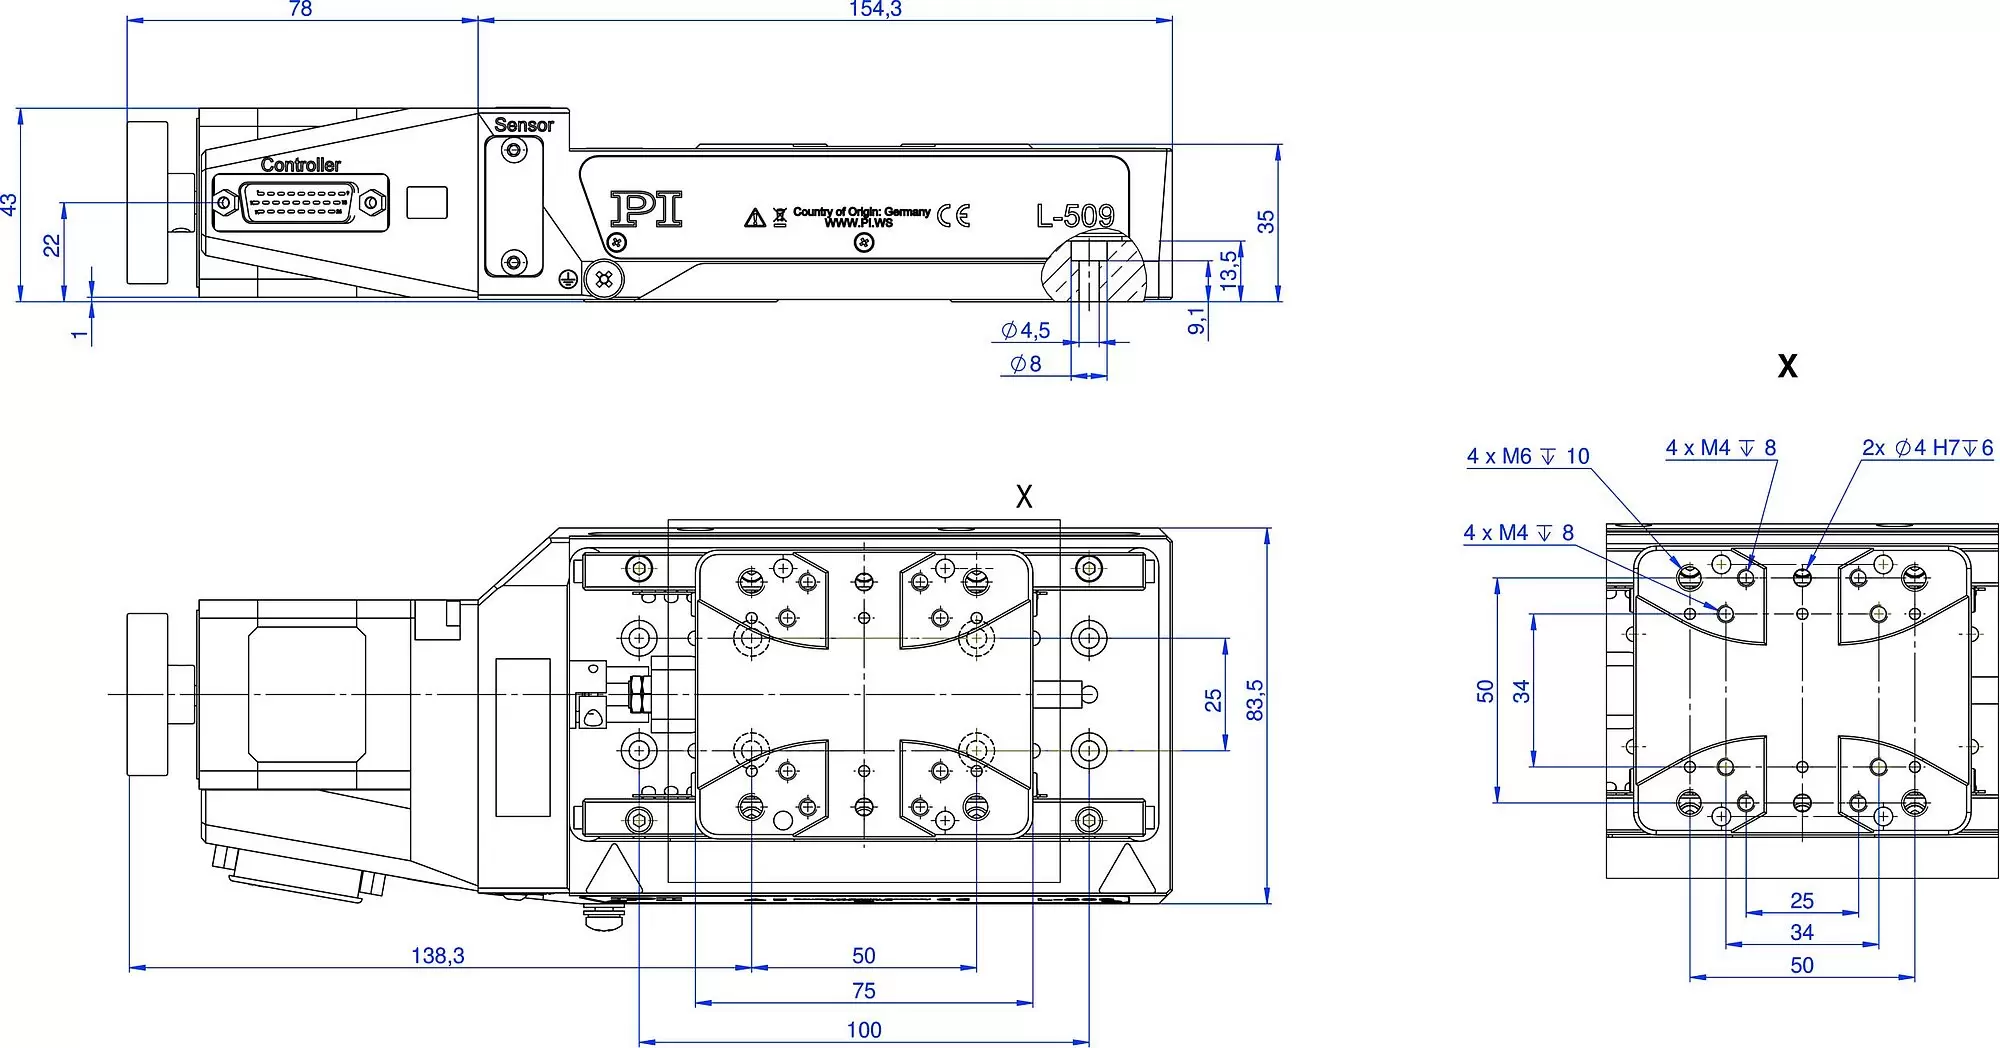
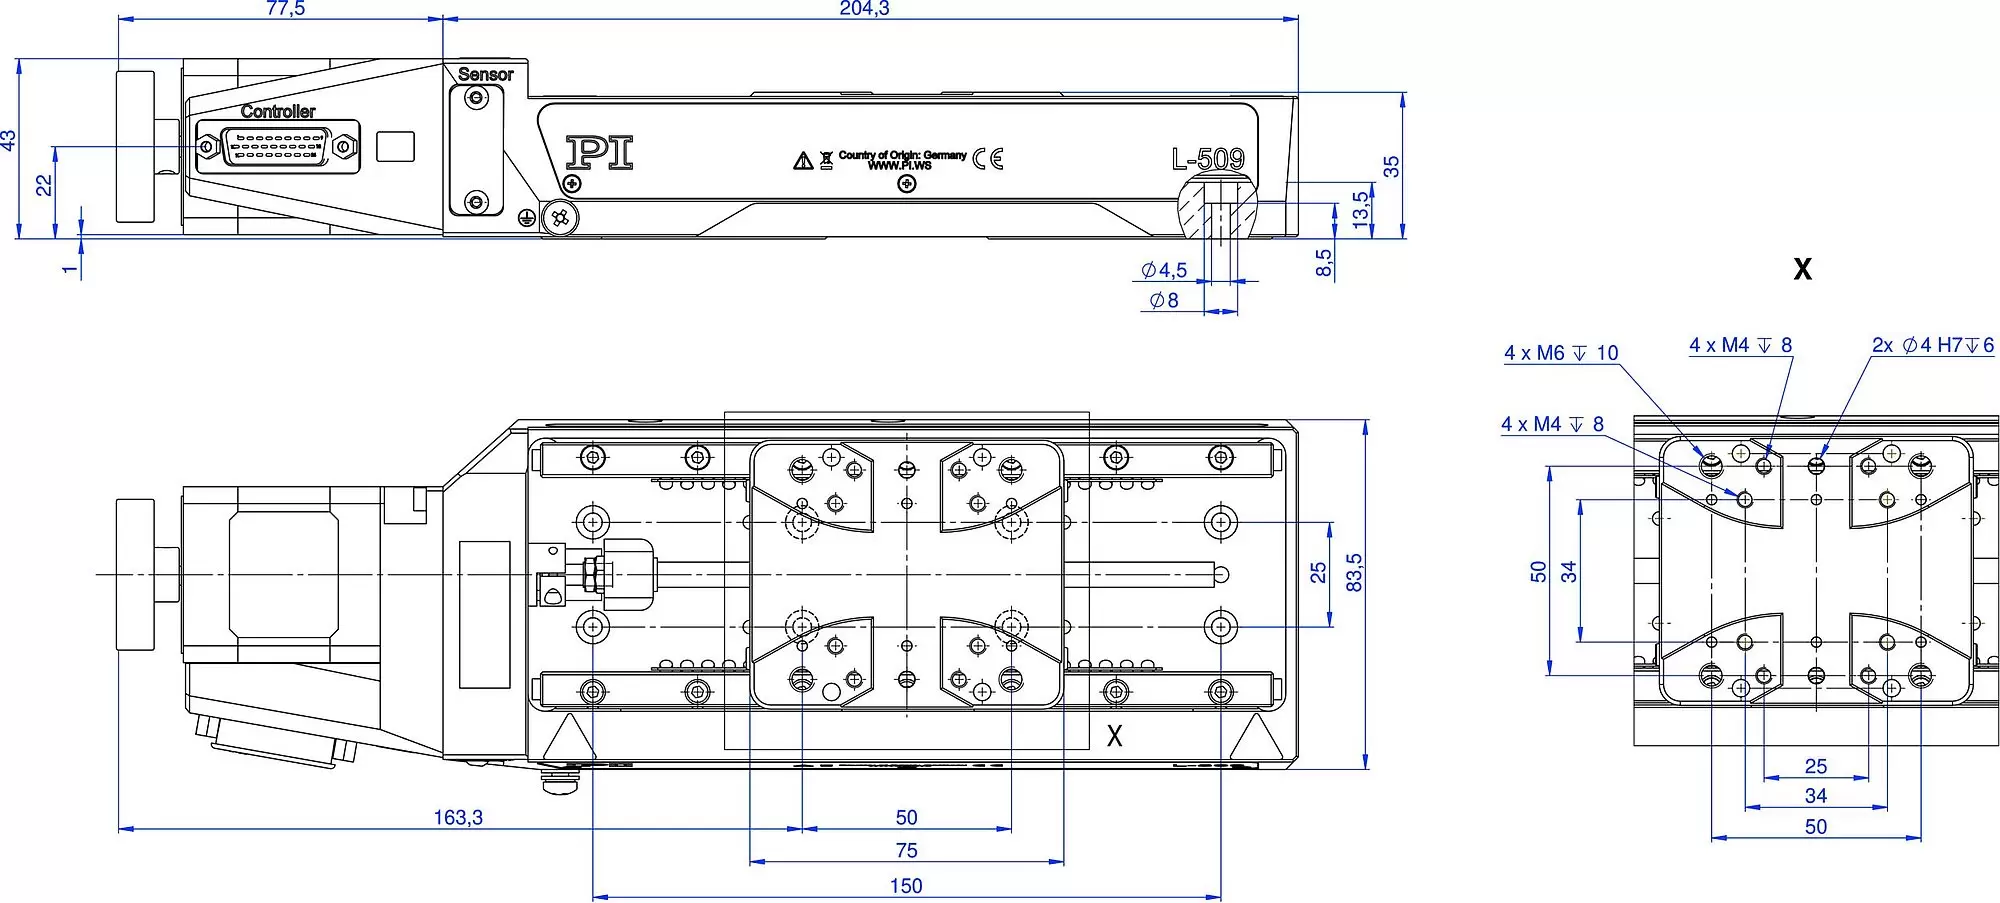
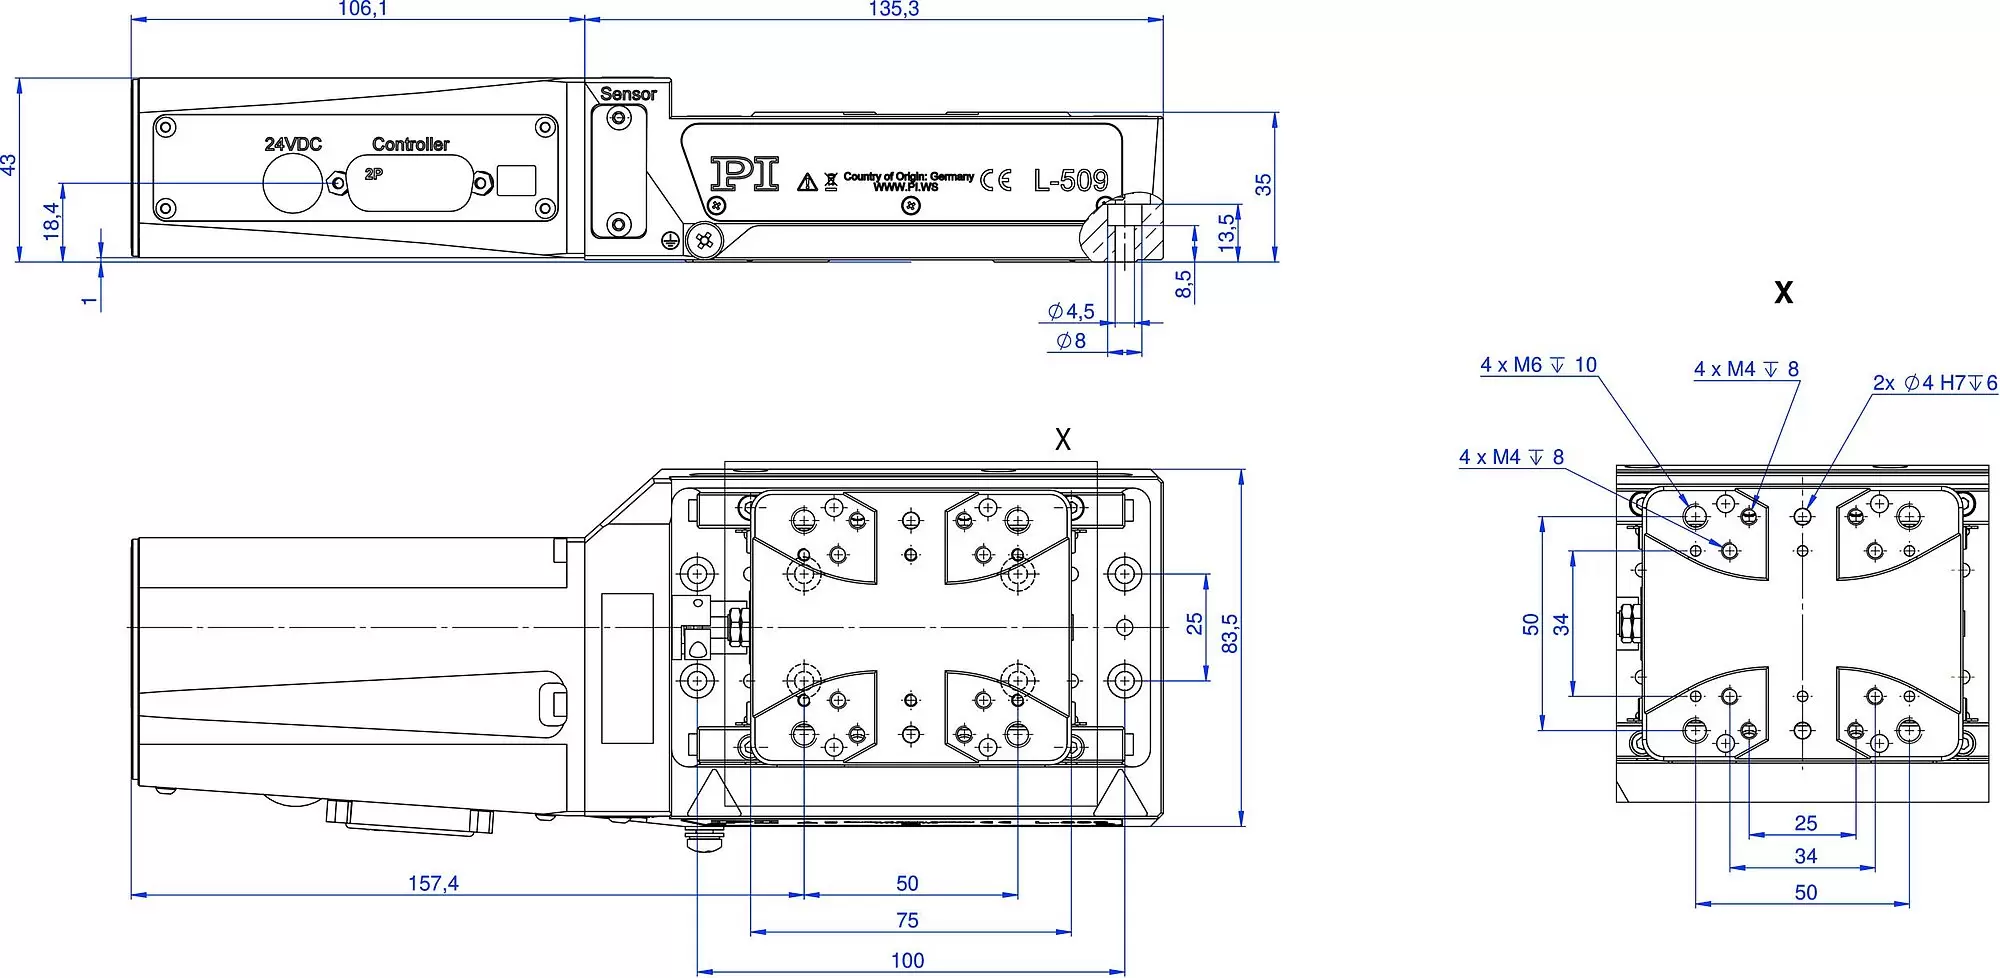
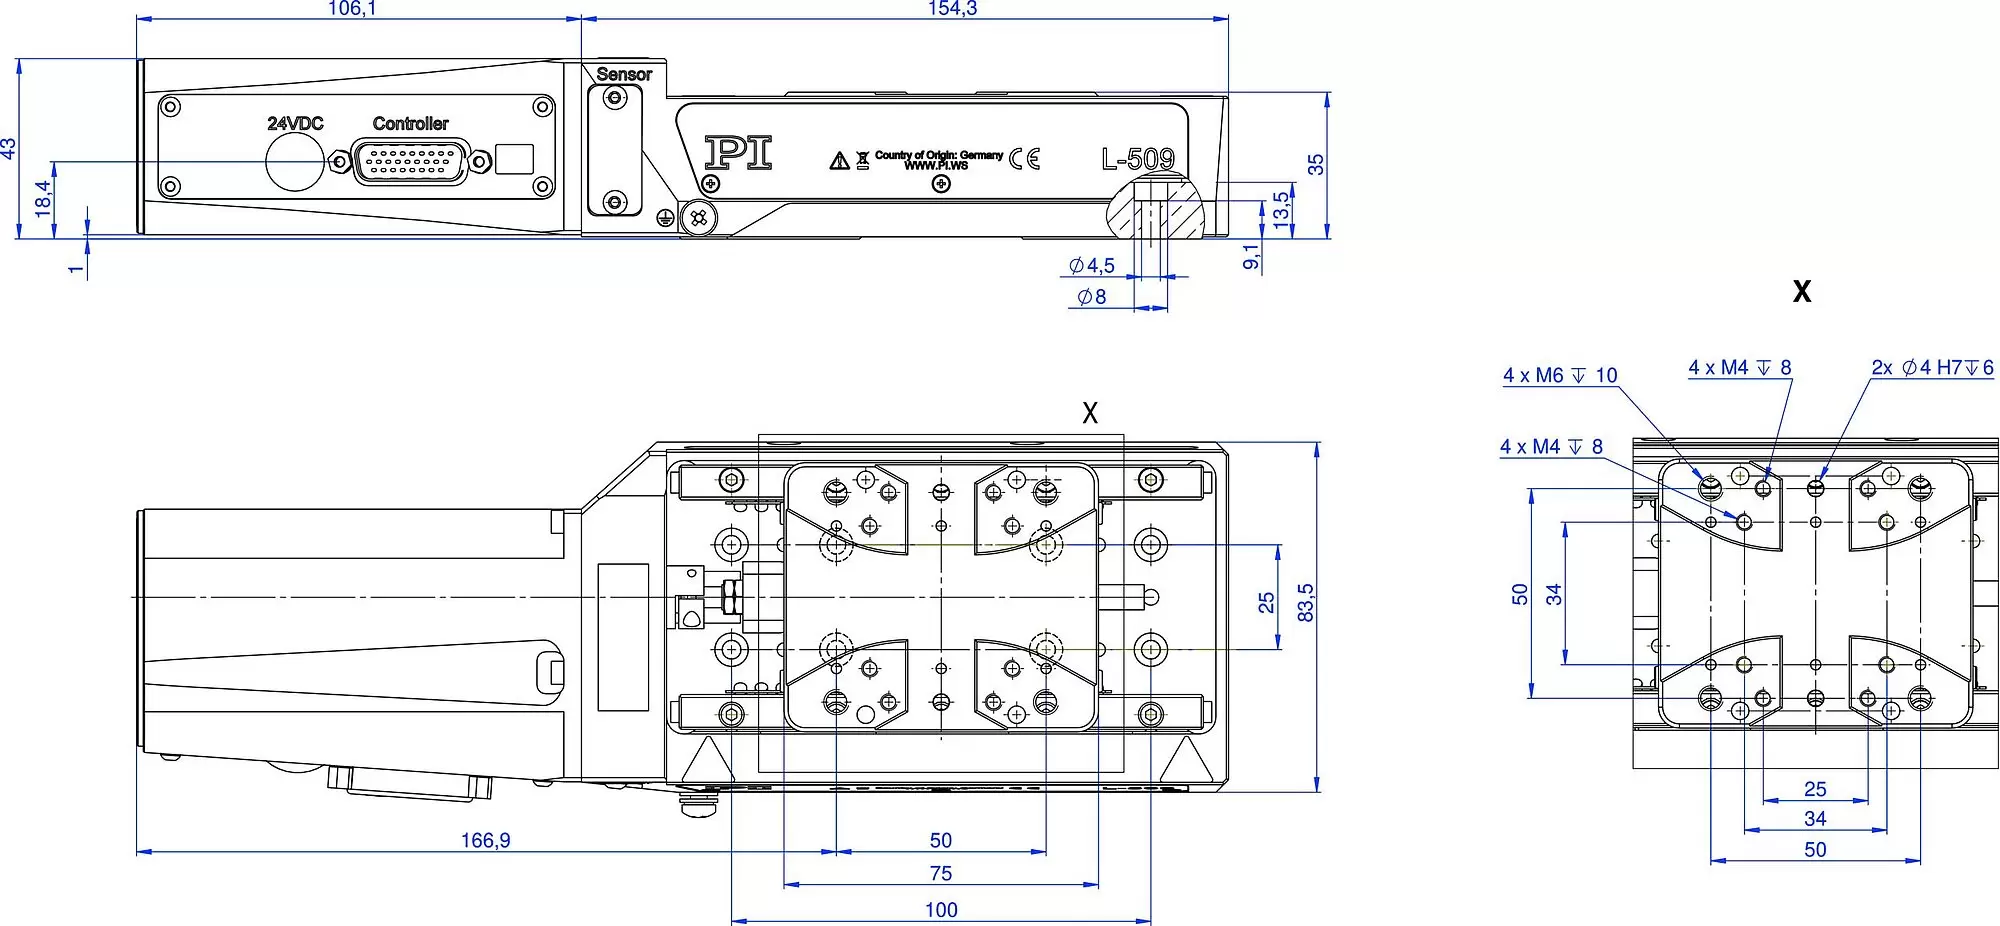
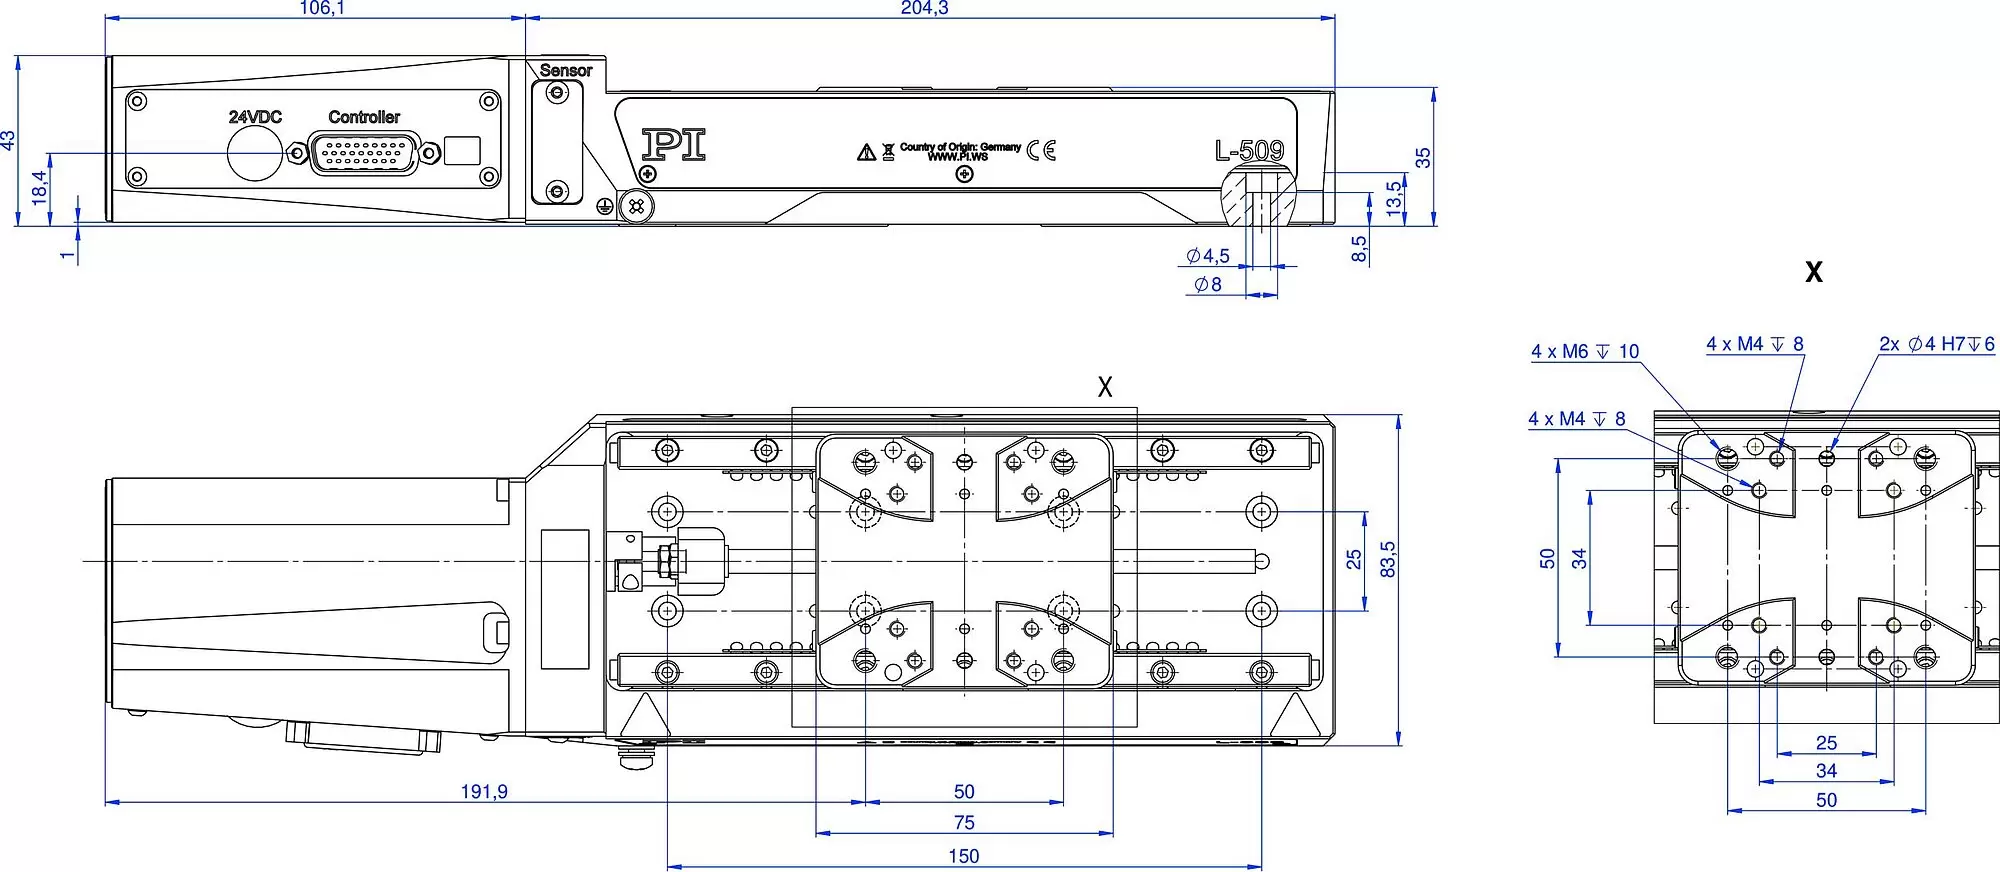
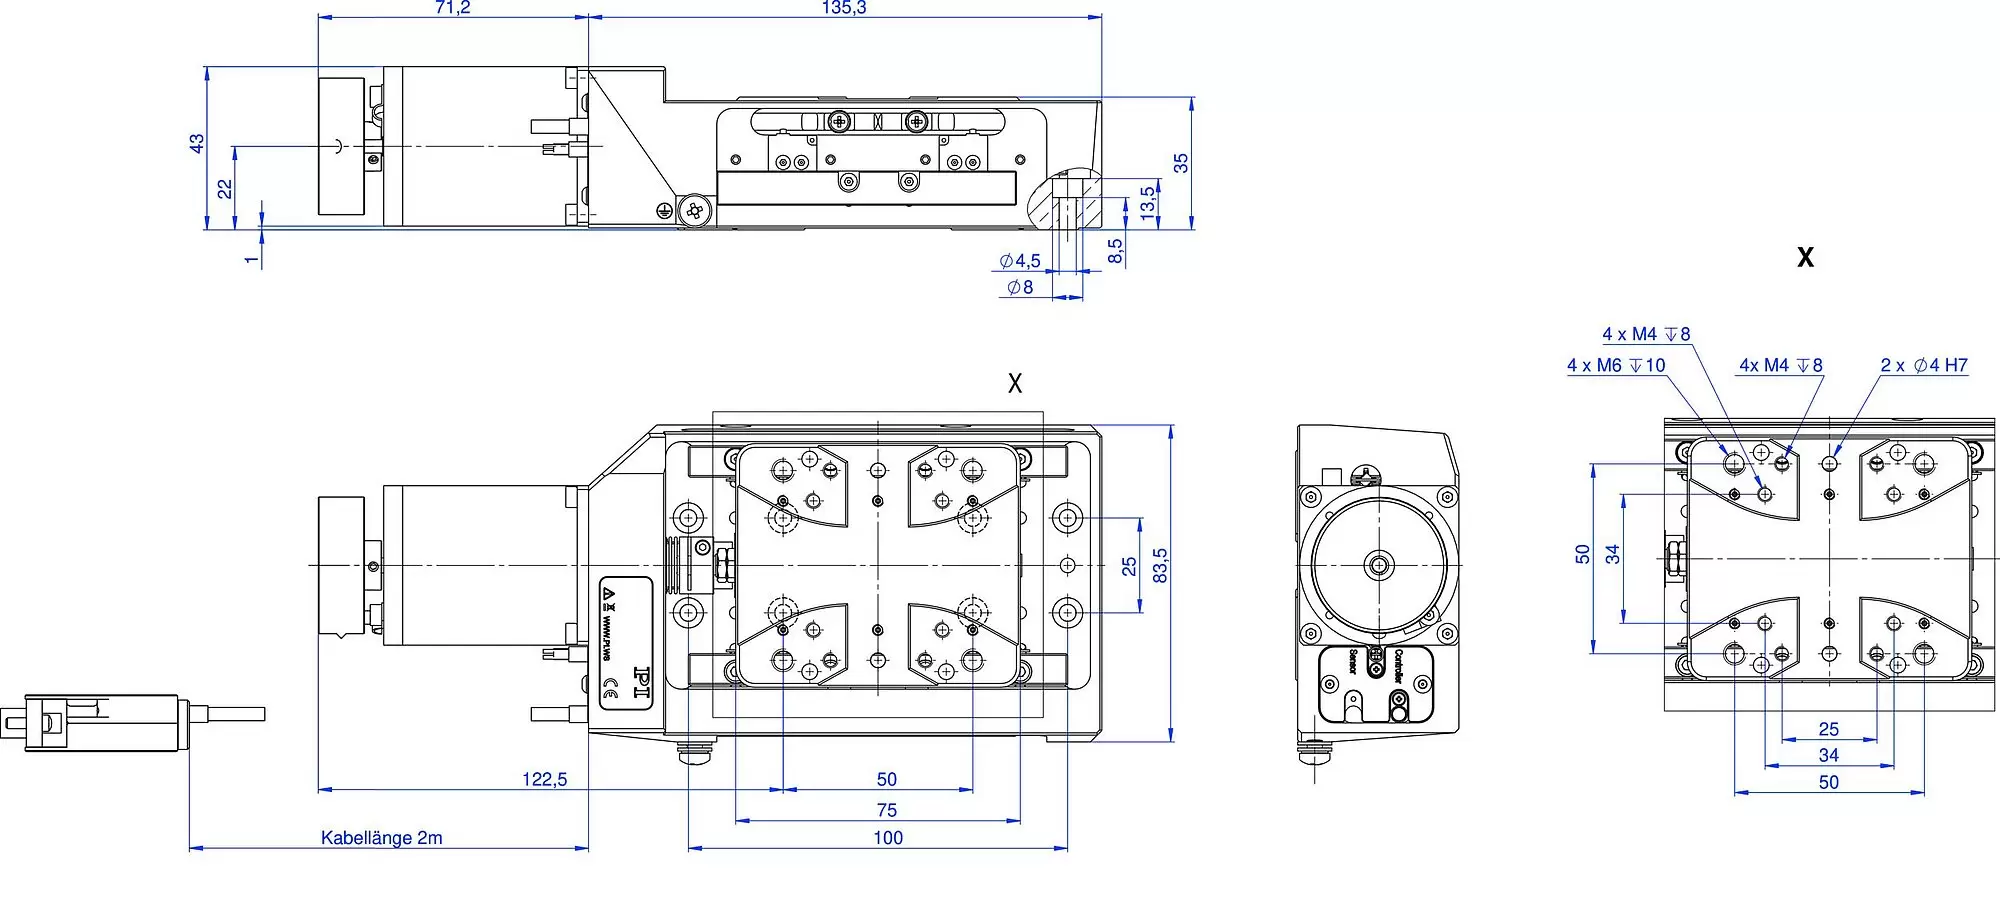
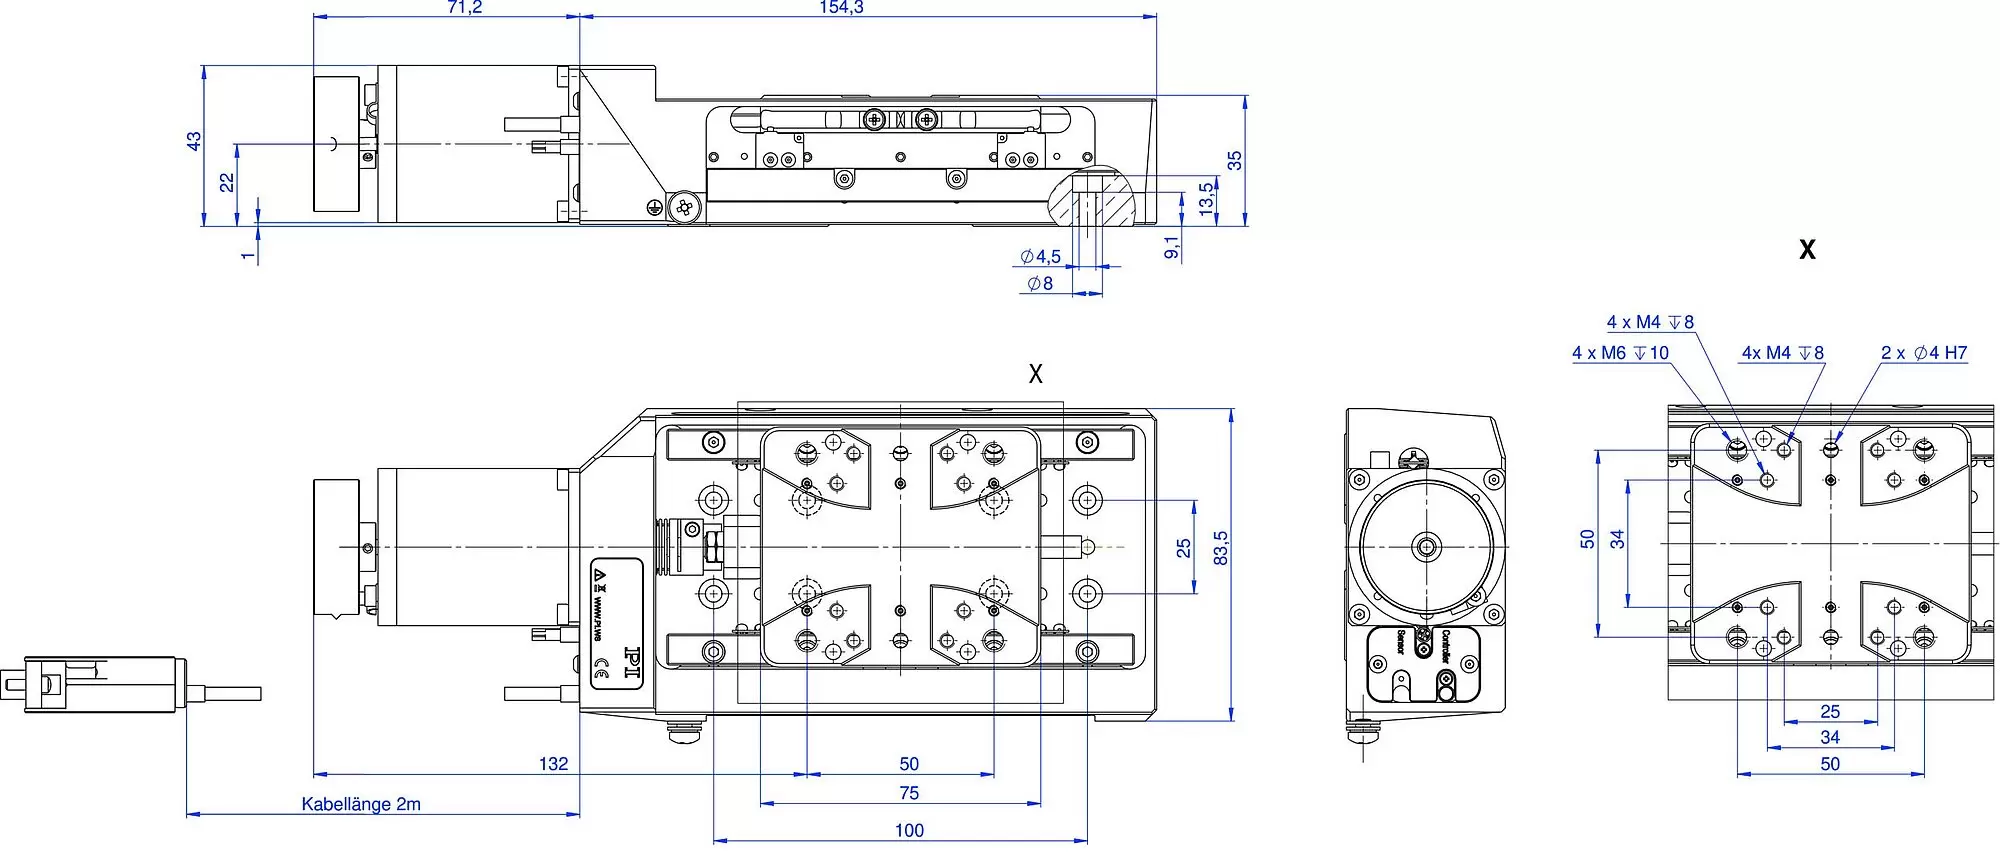
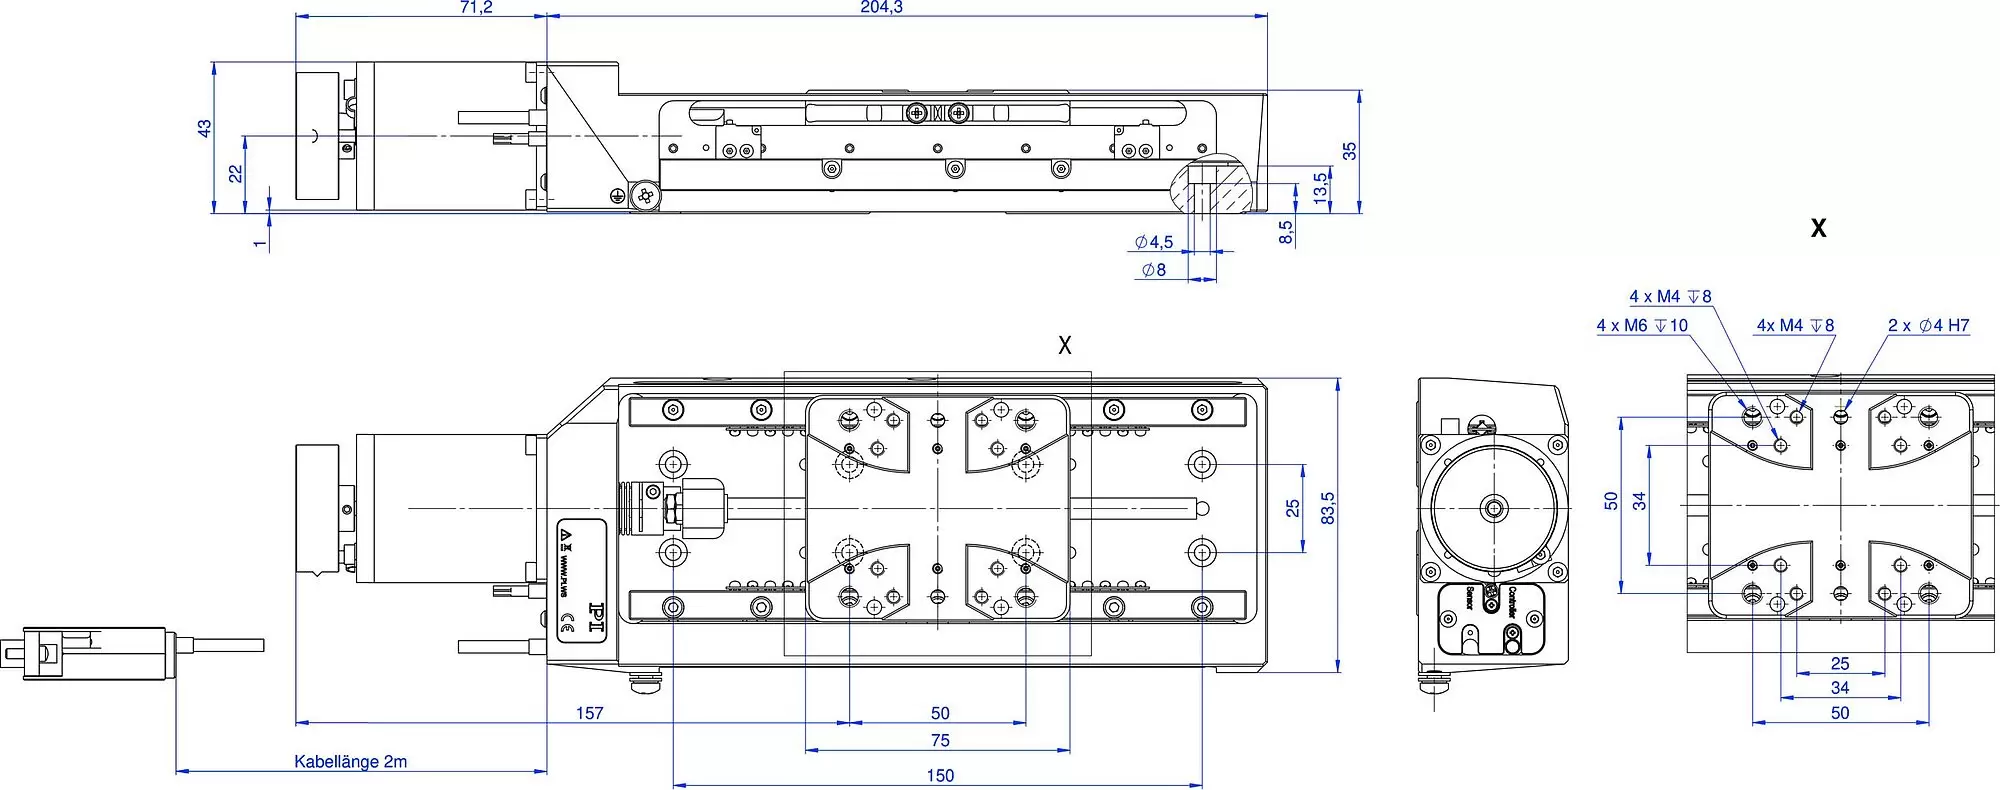
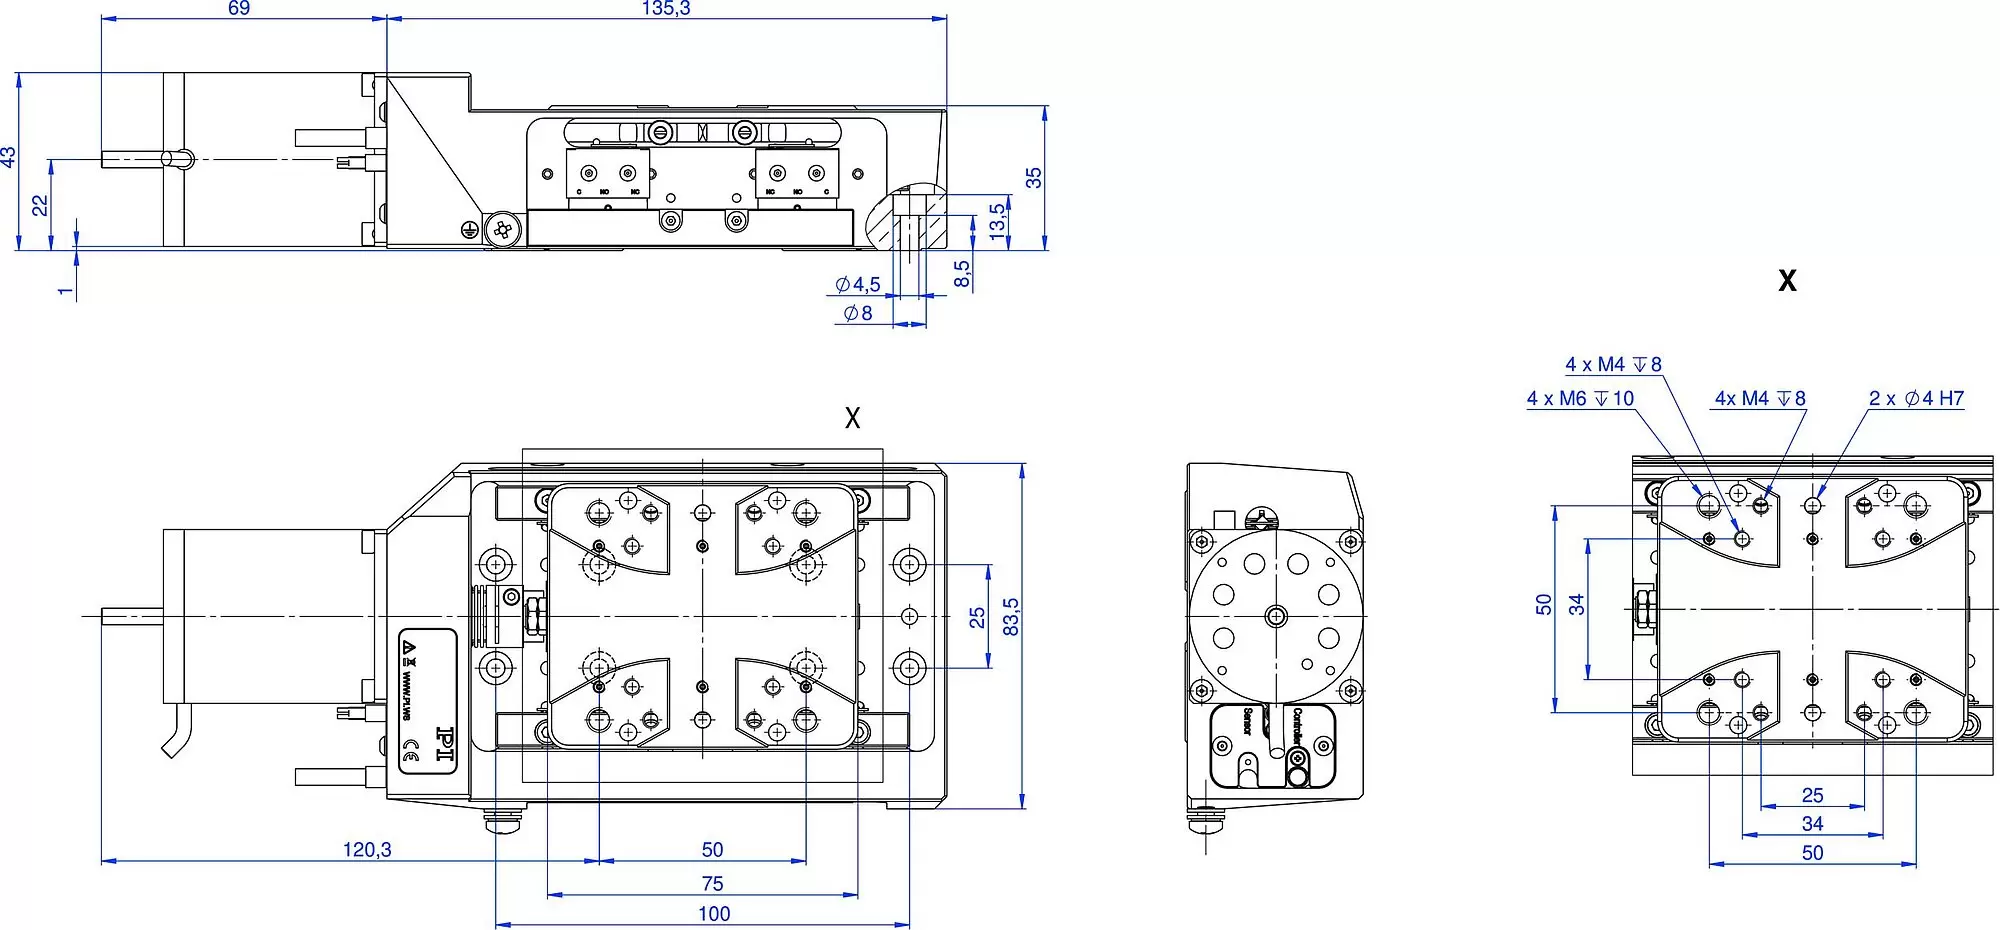
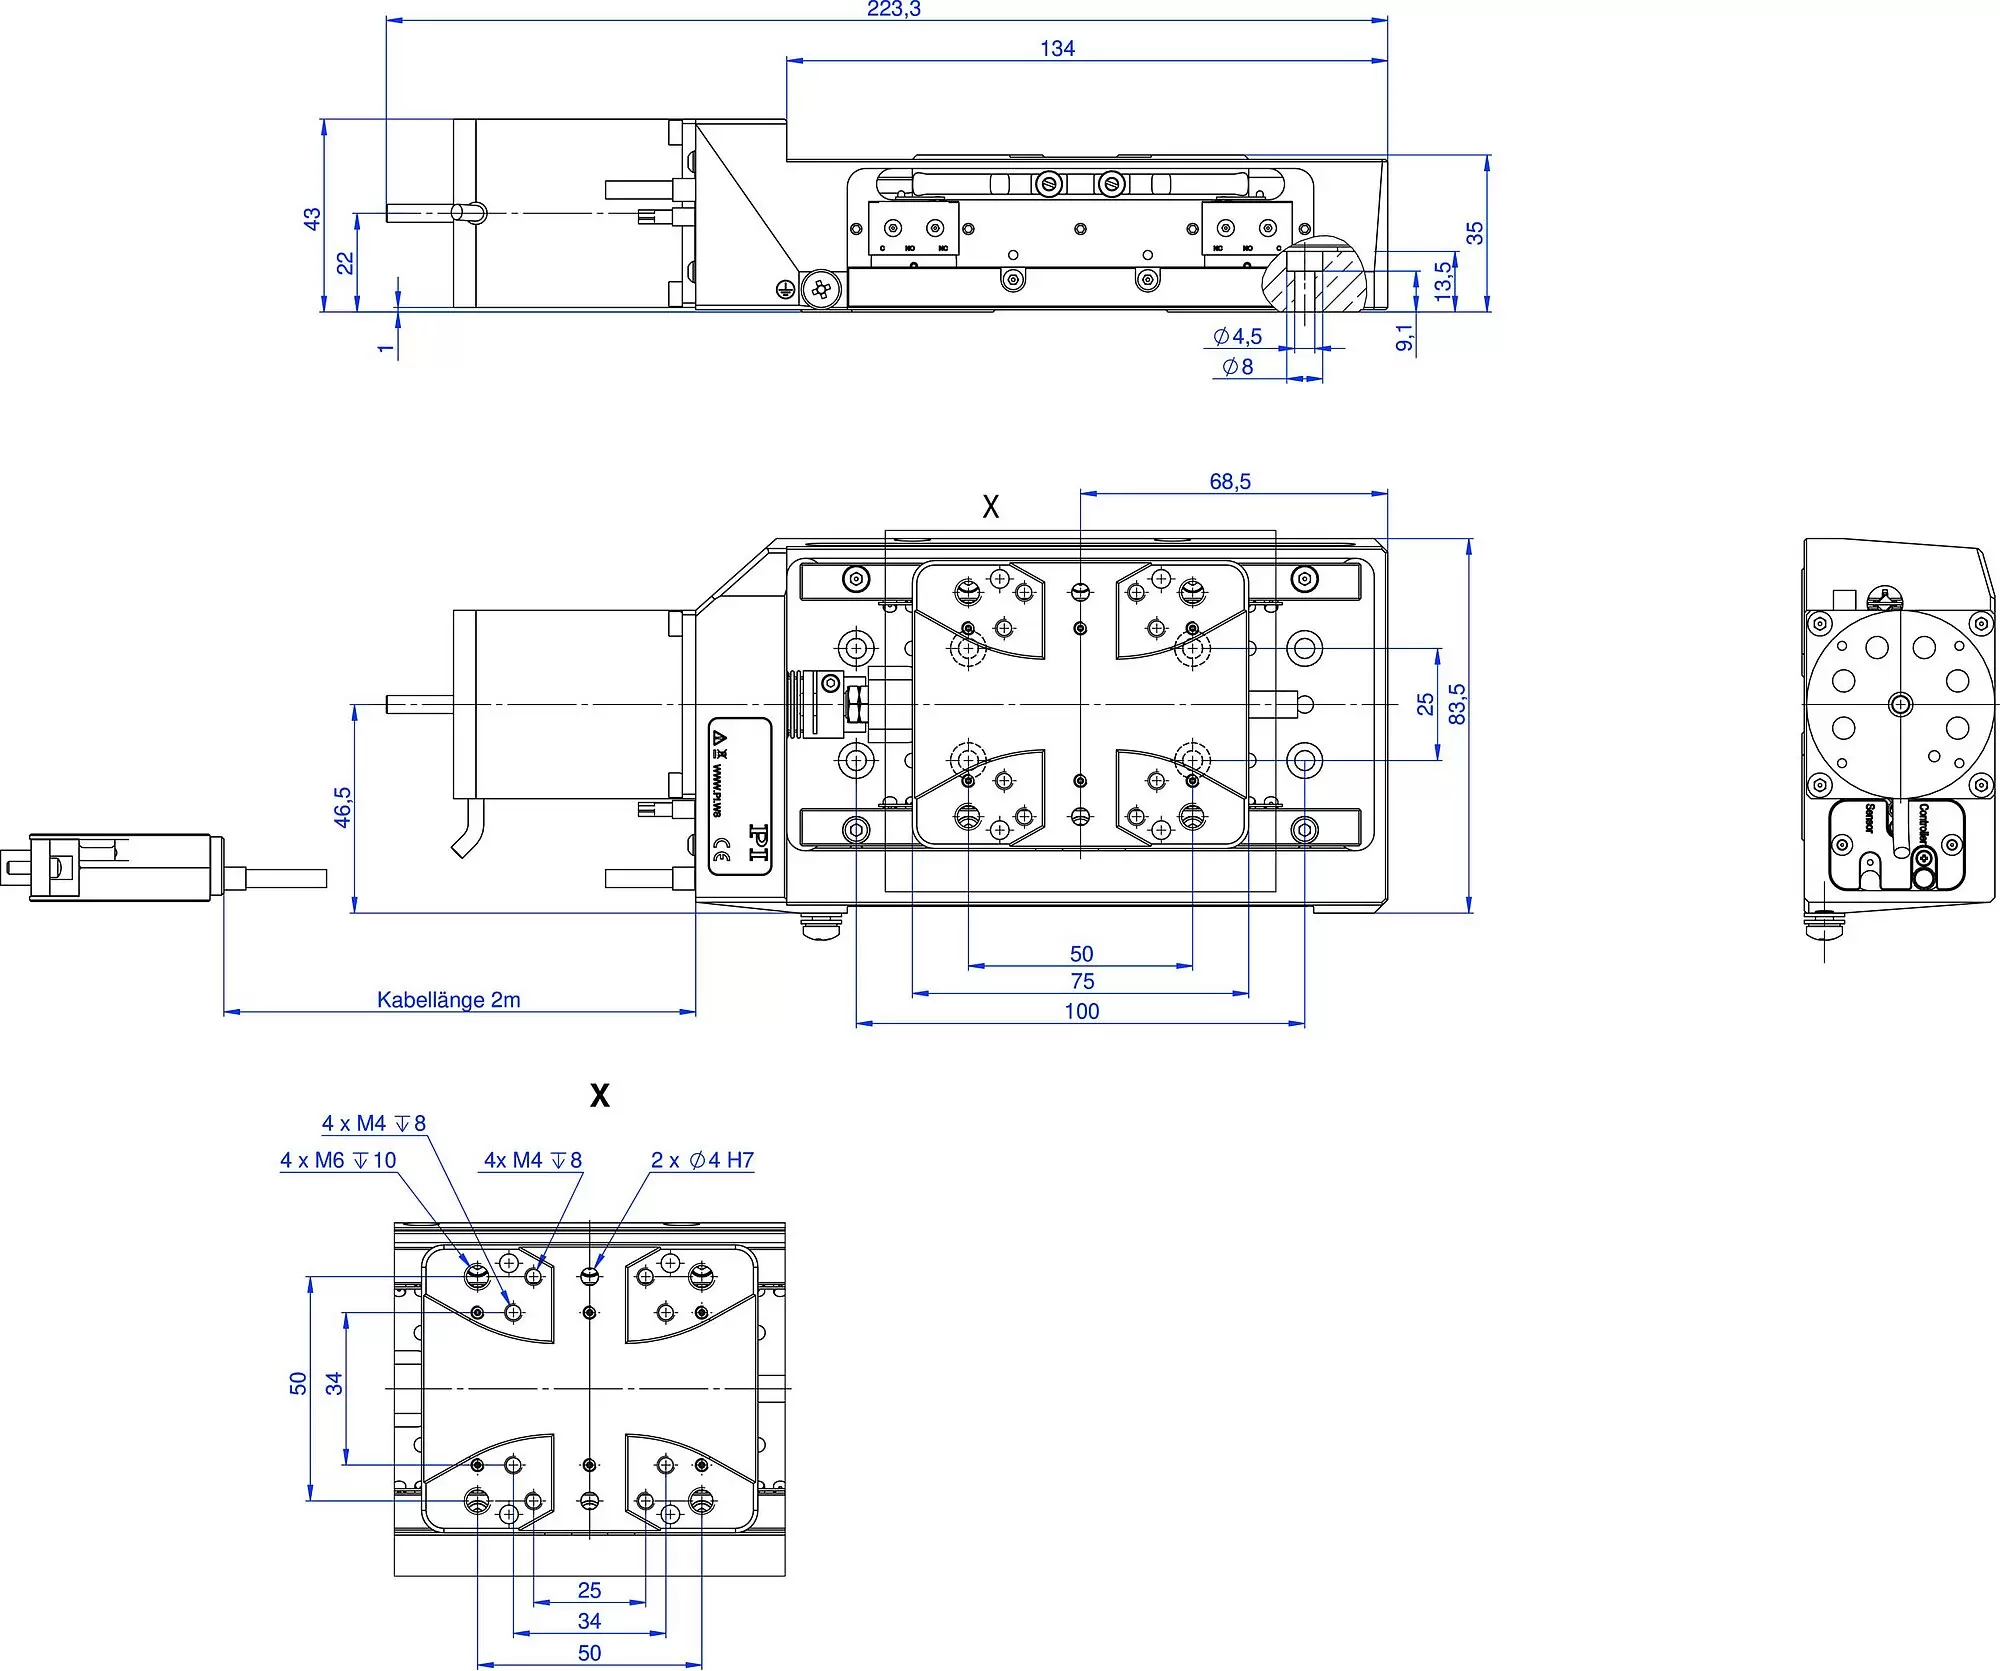
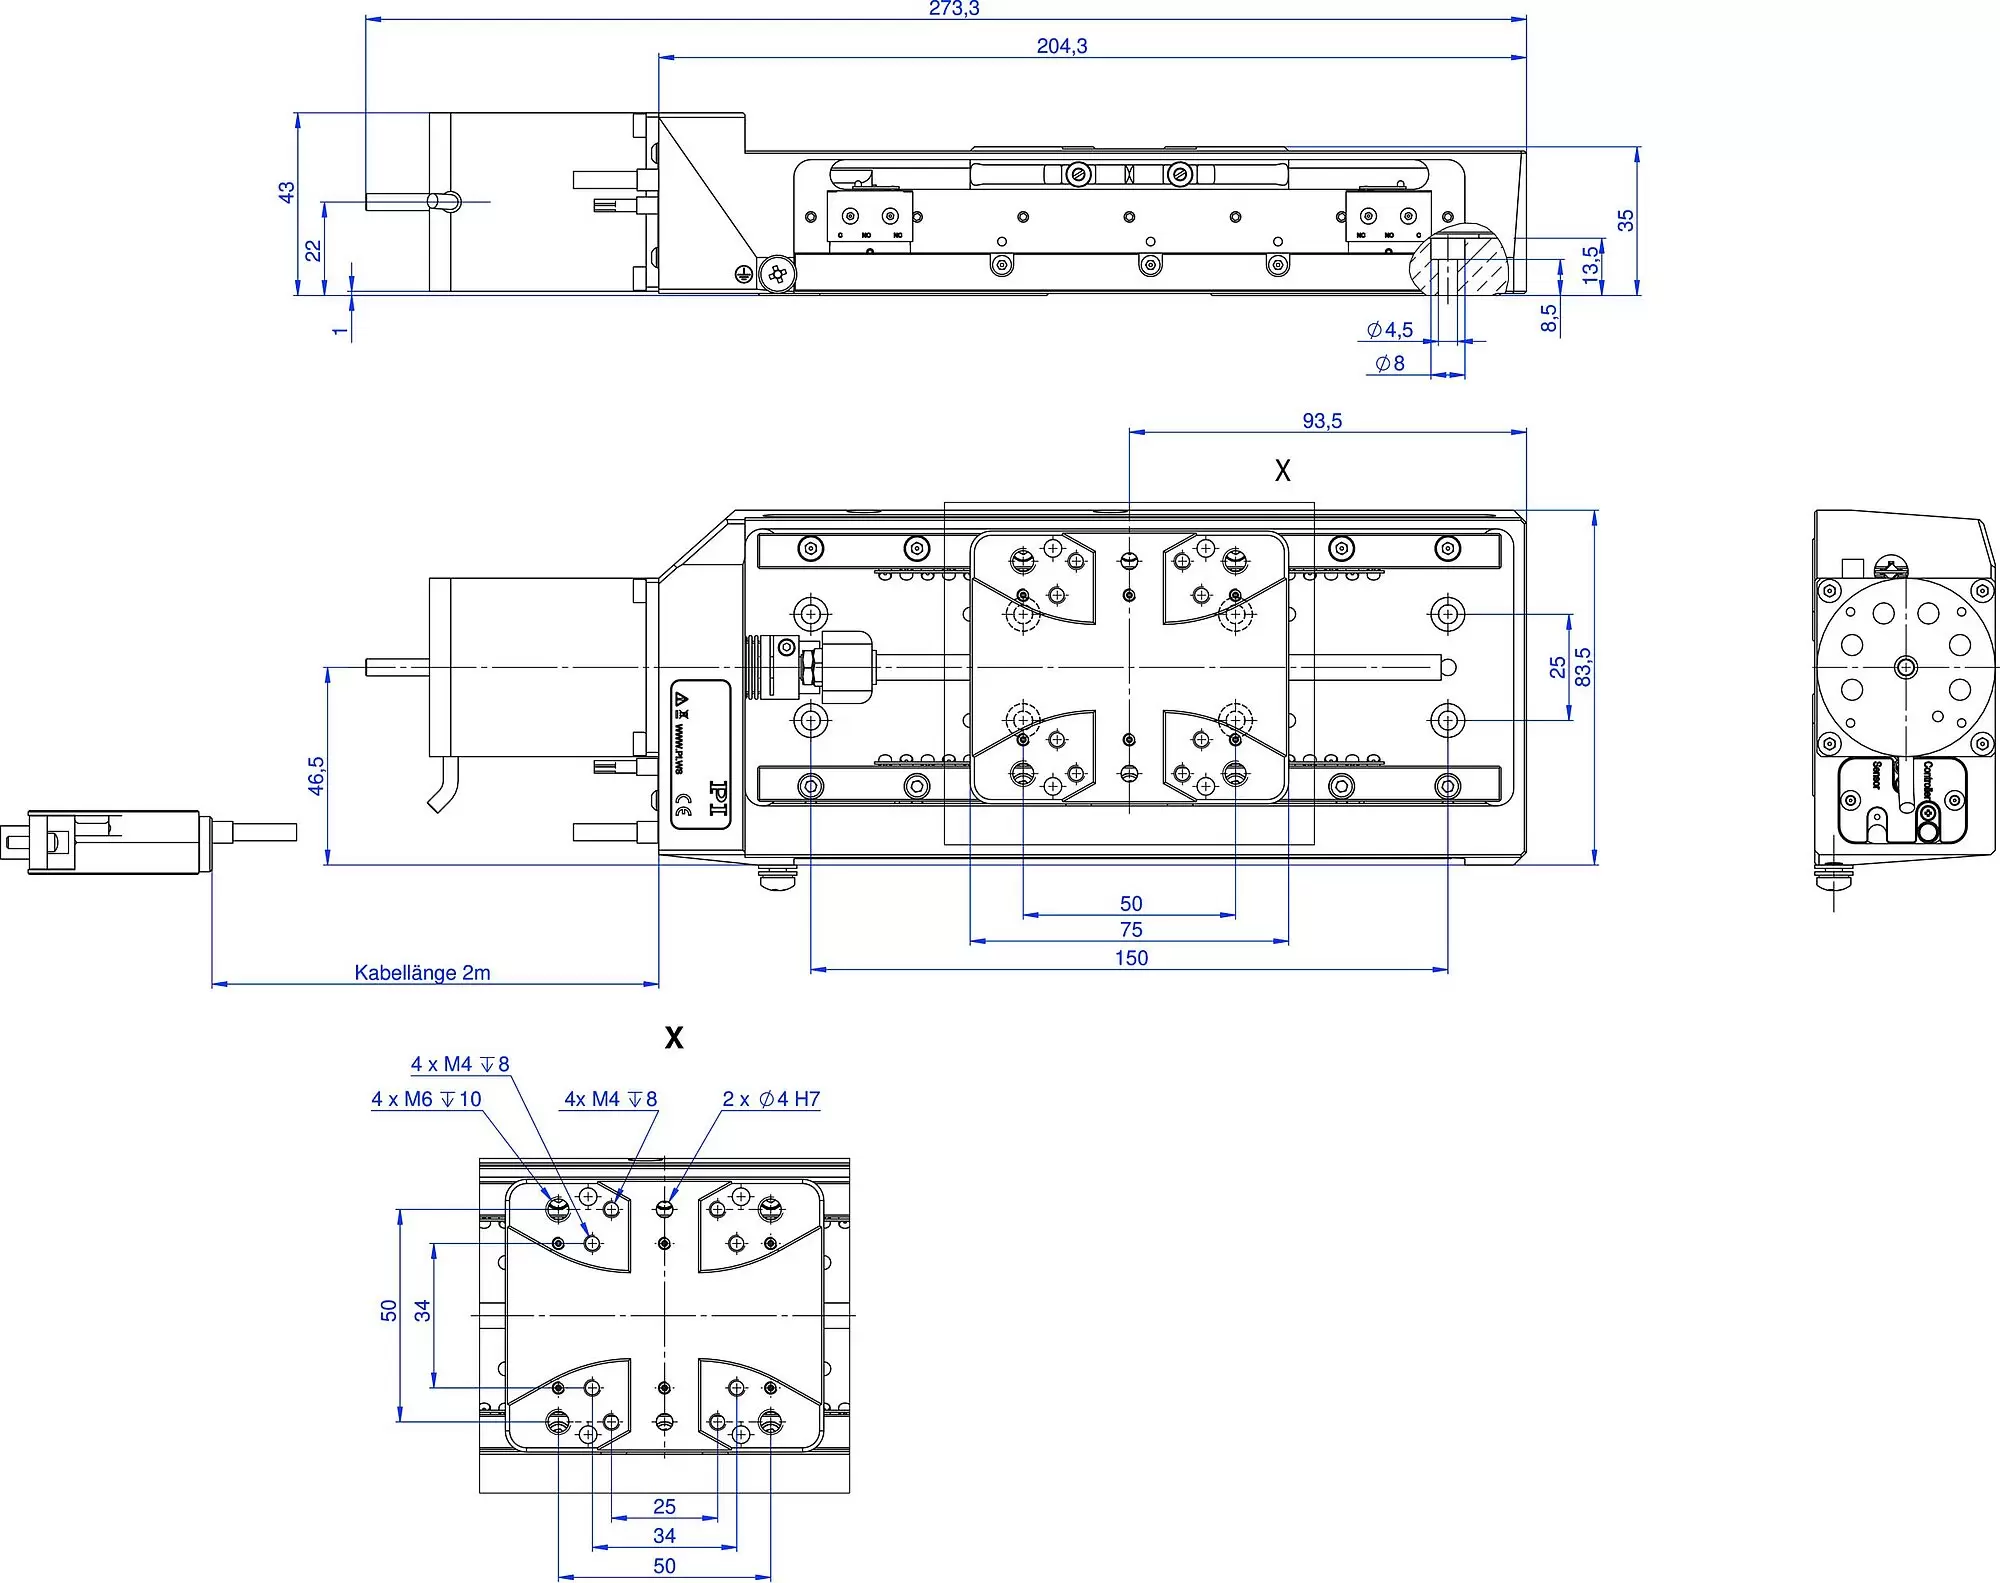
Please note that at the moment only a limited selelction of variants of this product family is available. This selection can be found here on the web page. The complete list of products can be found in the PDF datasheet that is available for download.
Product overview
High travel accuracy and load capacity due to crossed roller guides with anti-creep system. Precision ball screw with 1 mm pitch. Compact design. Stress-relieved aluminum base for high stability. Limit switch. Noncontact optical reference switch with direction sensing in the middle of the travel range.
Reduced outgassing especially for use in vacuum environments
Most notably, for the lubrication of the guides and the spindle a material with particularly low outgassing is used. This allows a bakeout temperature of up to 80° C. With this and other modifications of the PI V6 vacuum class, this positioner can be used up to 10-6 hPa.
Higher quality for applications in high vacuum
In this case, special components suitable for high vacuum are used, such as motor, measuring system, and limit switches. In addition, the surface is made of uncoated aluminum and the spindles and guides are made of stainless steel. With this, the PI V7 vacuum class is reached, which means up to 10-7 hPa.
The highest quality for special requirements in ultrahigh vacuum
In this vacuum class, the product is optimized in all details thanks to components suitable for ultrahigh vacuum in order to reach PI V9 vacuum class up to 10-9 hPa. Among other things, only selected types of plastic are used for this purpose and bakeout temperatures of 120 °C with measuring system, respectively 150 °C without measuring system are applied.
Motor types available
Types of position measuring
Application fields
Vacuum chambers. Research. Beamline instrumentation. Microscopy. Electronics assembly and inspection.
| Motion | Filter | L-509.021100V6 | L-509.031100V6 | L-509.051100V6 | L-509.024132V6 | L-509.034132V6 | L-509.054132V6 | L-509.021300V7 | L-509.031300V7 | L-509.051300V7 | L-509.031600V9 | L-509.051600V9 | Tolerance |
|---|---|---|---|---|---|---|---|---|---|---|---|---|---|
| Active axes | X | X | X | X | X | X | X | X | X | X | X | ||
| Travel range in X | 26 mm | 52 mm | 102 mm | 26 mm | 52 mm | 102 mm | 26 mm | 52 mm | 102 mm | 52 mm | 102 mm | ||
| Maximum velocity in X, unloaded | 10 mm/s | 10 mm/s | 10 mm/s | 1.5 mm/s | 1.5 mm/s | 1.5 mm/s | 10 mm/s | 10 mm/s | 10 mm/s | 10 mm/s | 10 mm/s | ||
| Straightness (Linear crosstalk in Y with motion in X) | ± 2 µm | ± 4 µm | ± 8 µm | ± 2 µm | ± 4 µm | ± 8 µm | ± 2 µm | ± 4 µm | ± 8 µm | ± 4 µm | ± 8 µm | typ. | |
| Flatness (Linear crosstalk in Z with motion in X) | ± 2 µm | ± 4 µm | ± 8 µm | ± 2 µm | ± 4 µm | ± 8 µm | ± 2 µm | ± 4 µm | ± 8 µm | ± 4 µm | ± 8 µm | typ. | |
| Pitch (Rotational crosstalk in θY with motion in X) | ± 60 µrad | ± 90 µrad | ± 120 µrad | ± 60 µrad | ± 90 µrad | ± 120 µrad | ± 60 µrad | ± 90 µrad | ± 120 µrad | ± 90 µrad | ± 120 µrad | typ. | |
| Yaw (Rotational crosstalk in θZ with motion in X) | ± 60 µrad | ± 90 µrad | ± 120 µrad | ± 60 µrad | ± 90 µrad | ± 120 µrad | ± 60 µrad | ± 90 µrad | ± 120 µrad | ± 90 µrad | ± 120 µrad | typ. | |
| Positioning | Filter | L-509.021100V6 | L-509.031100V6 | L-509.051100V6 | L-509.024132V6 | L-509.034132V6 | L-509.054132V6 | L-509.021300V7 | L-509.031300V7 | L-509.051300V7 | L-509.031600V9 | L-509.051600V9 | Tolerance |
| Minimum incremental motion in X | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | typ. | |
| Unidirectional repeatability in X | ± 0.3 µm | ± 0.3 µm | ± 0.3 µm | ± 0.1 µm | ± 0.1 µm | ± 0.1 µm | ± 0.3 µm | ± 0.3 µm | ± 0.3 µm | ± 0.3 µm | ± 0.3 µm | typ. | |
| Limit switches | Forked photoelectric sensor, N/C contact, 5 V, NPN | Forked photoelectric sensor, N/C contact, 5 V, NPN | Forked photoelectric sensor, N/C contact, 5 V, NPN | Forked photoelectric sensor, N/C contact, 5 V, NPN | Forked photoelectric sensor, N/C contact, 5 V, NPN | Forked photoelectric sensor, N/C contact, 5 V, NPN | Mechanical | Mechanical | Mechanical | Mechanical | Mechanical | ||
| Motor encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | ||||||||||
| Motor encoder: Sensor signal | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | ||||||||||
| Drive Properties | Filter | L-509.021100V6 | L-509.031100V6 | L-509.051100V6 | L-509.024132V6 | L-509.034132V6 | L-509.054132V6 | L-509.021300V7 | L-509.031300V7 | L-509.051300V7 | L-509.031600V9 | L-509.051600V9 | Tolerance |
| Drive type | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | DC gear motor | DC gear motor | DC gear motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | 2-phase stepper motor | ||
| Nominal voltage | 24 V | 24 V | 24 V | 12 V | 12 V | 12 V | 24 V | 24 V | 24 V | 24 V | 24 V | ||
| Peak voltage | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | 48 V | |||||
| Maximum power consumption | 10 W | 10 W | 10 W | 10 W | 10 W | 10 W | 10 W | 10 W | |||||
| Motor resolution | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | 200 Full steps/rev. | |||||
| Drive force in positive direction of motion in X | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | typ. | |
| Drive force in negative direction of motion in X | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | 60 N | typ. | |
| Resistance phase-phase | 3.3 Ω | 3.3 Ω | 3.3 Ω | 4.09 Ω | 4.09 Ω | 4.09 Ω | 1.7 Ω | 1.7 Ω | 1.7 Ω | 1.7 Ω | 1.7 Ω | typ. | |
| Inductance phase-phase | 2.8 mH | 2.8 mH | 2.8 mH | 0.18 mH | 0.18 mH | 0.18 mH | 3 mH | 3 mH | 3 mH | 3 mH | 3 mH | ||
| Back EMF, phase-phase, rotational | 1.68 V/kRPM | 1.68 V/kRPM | 1.68 V/kRPM | max. | |||||||||
| Mechanical Properties | Filter | L-509.021100V6 | L-509.031100V6 | L-509.051100V6 | L-509.024132V6 | L-509.034132V6 | L-509.054132V6 | L-509.021300V7 | L-509.031300V7 | L-509.051300V7 | L-509.031600V9 | L-509.051600V9 | Tolerance |
| Permissible push force in Y | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | max. | |
| Permissible push force in Z | 100 N | 100 N | 100 N | 100 N | 100 N | 100 N | 100 N | 100 N | 100 N | 100 N | 100 N | max. | |
| Permissible torque in θx | 30 N·m | 30 N·m | 30 N·m | 30 N·m | 30 N·m | 30 N·m | 30 N·m | 30 N·m | 30 N·m | 30 N·m | 30 N·m | max. | |
| Permissible torque in θY | 25 N·m | 25 N·m | 25 N·m | 25 N·m | 25 N·m | 25 N·m | 25 N·m | 25 N·m | 25 N·m | 25 N·m | 25 N·m | max. | |
| Permissible torque in θZ | 20 N·m | 20 N·m | 20 N·m | 20 N·m | 20 N·m | 20 N·m | 20 N·m | 20 N·m | 20 N·m | 20 N·m | 20 N·m | max. | |
| Holding force in X, passive | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | 50 N | 30 N | 30 N | ||
| Moved mass in X, unloaded | 220 g | 220 g | 220 g | 220 g | 220 g | 220 g | 220 g | 220 g | 220 g | 220 g | 220 g | ||
| Drive screw type | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | ||
| Drive screw pitch | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm |
3D Models
Datasheet
Documentation
x
Quote List
Your quote list is currently empty.
x
0
0
Whatsapp
Download Request
Your download list is currently empty.
|