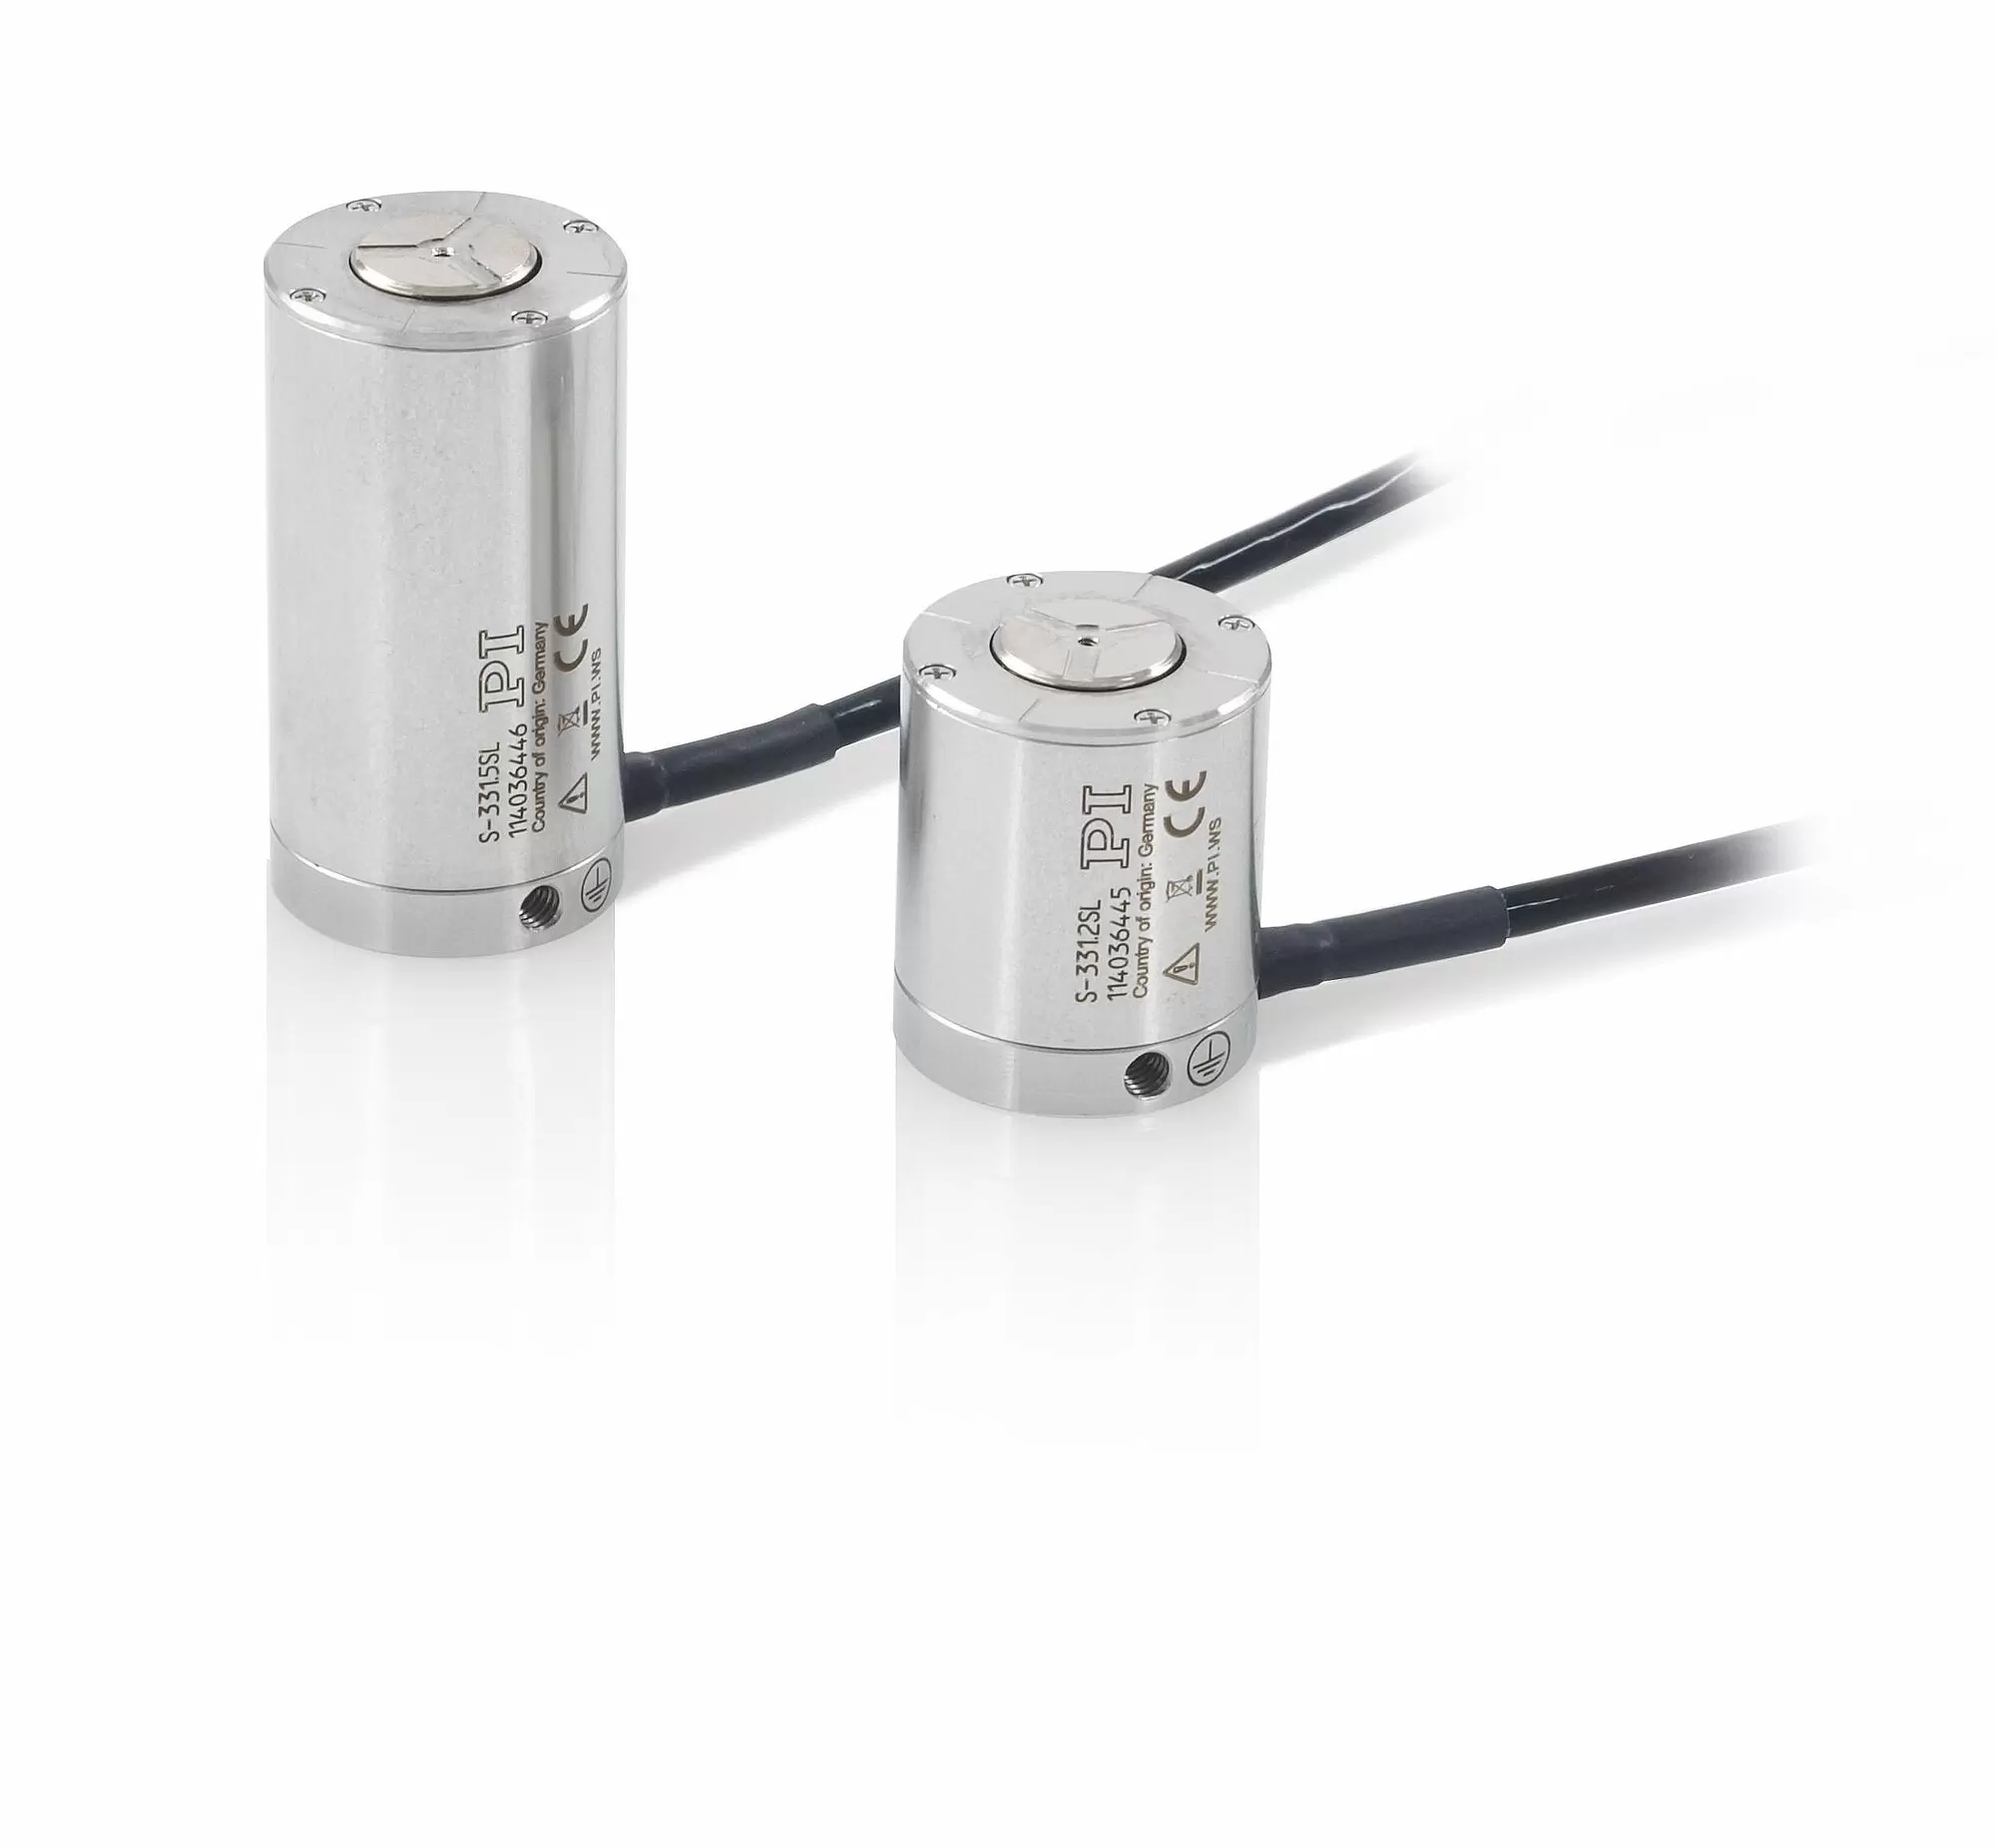
The patented PICMA® piezo actuators are all-ceramic insulated. This protects them against humidity and failure resulting from an increase in leakage current. PICMA® actuators offer an up to ten times longer lifetime than conventional polymer-insulated actuators. 100 billion cycles without a single failure are proven.
Flexure guides are free of maintenance, friction, and wear, and do not require lubrication. Their stiffness allows high load capacity and they are insensitive to shock and vibration. They work in a wide temperature range.
In a parallel-kinematic multi-axis system, all actuators act on a common platform. The minimum mass inertia and the identical design of all axes allow fast, dynamic, and nevertheless precision motion.
| Motion | S-331.2SH | S-331.2SL | S-331.5SH | S-331.5SL | Tolerance |
|---|---|---|---|---|---|
| Active axes | θX θY | θX θY | θX θY | θX θY | |
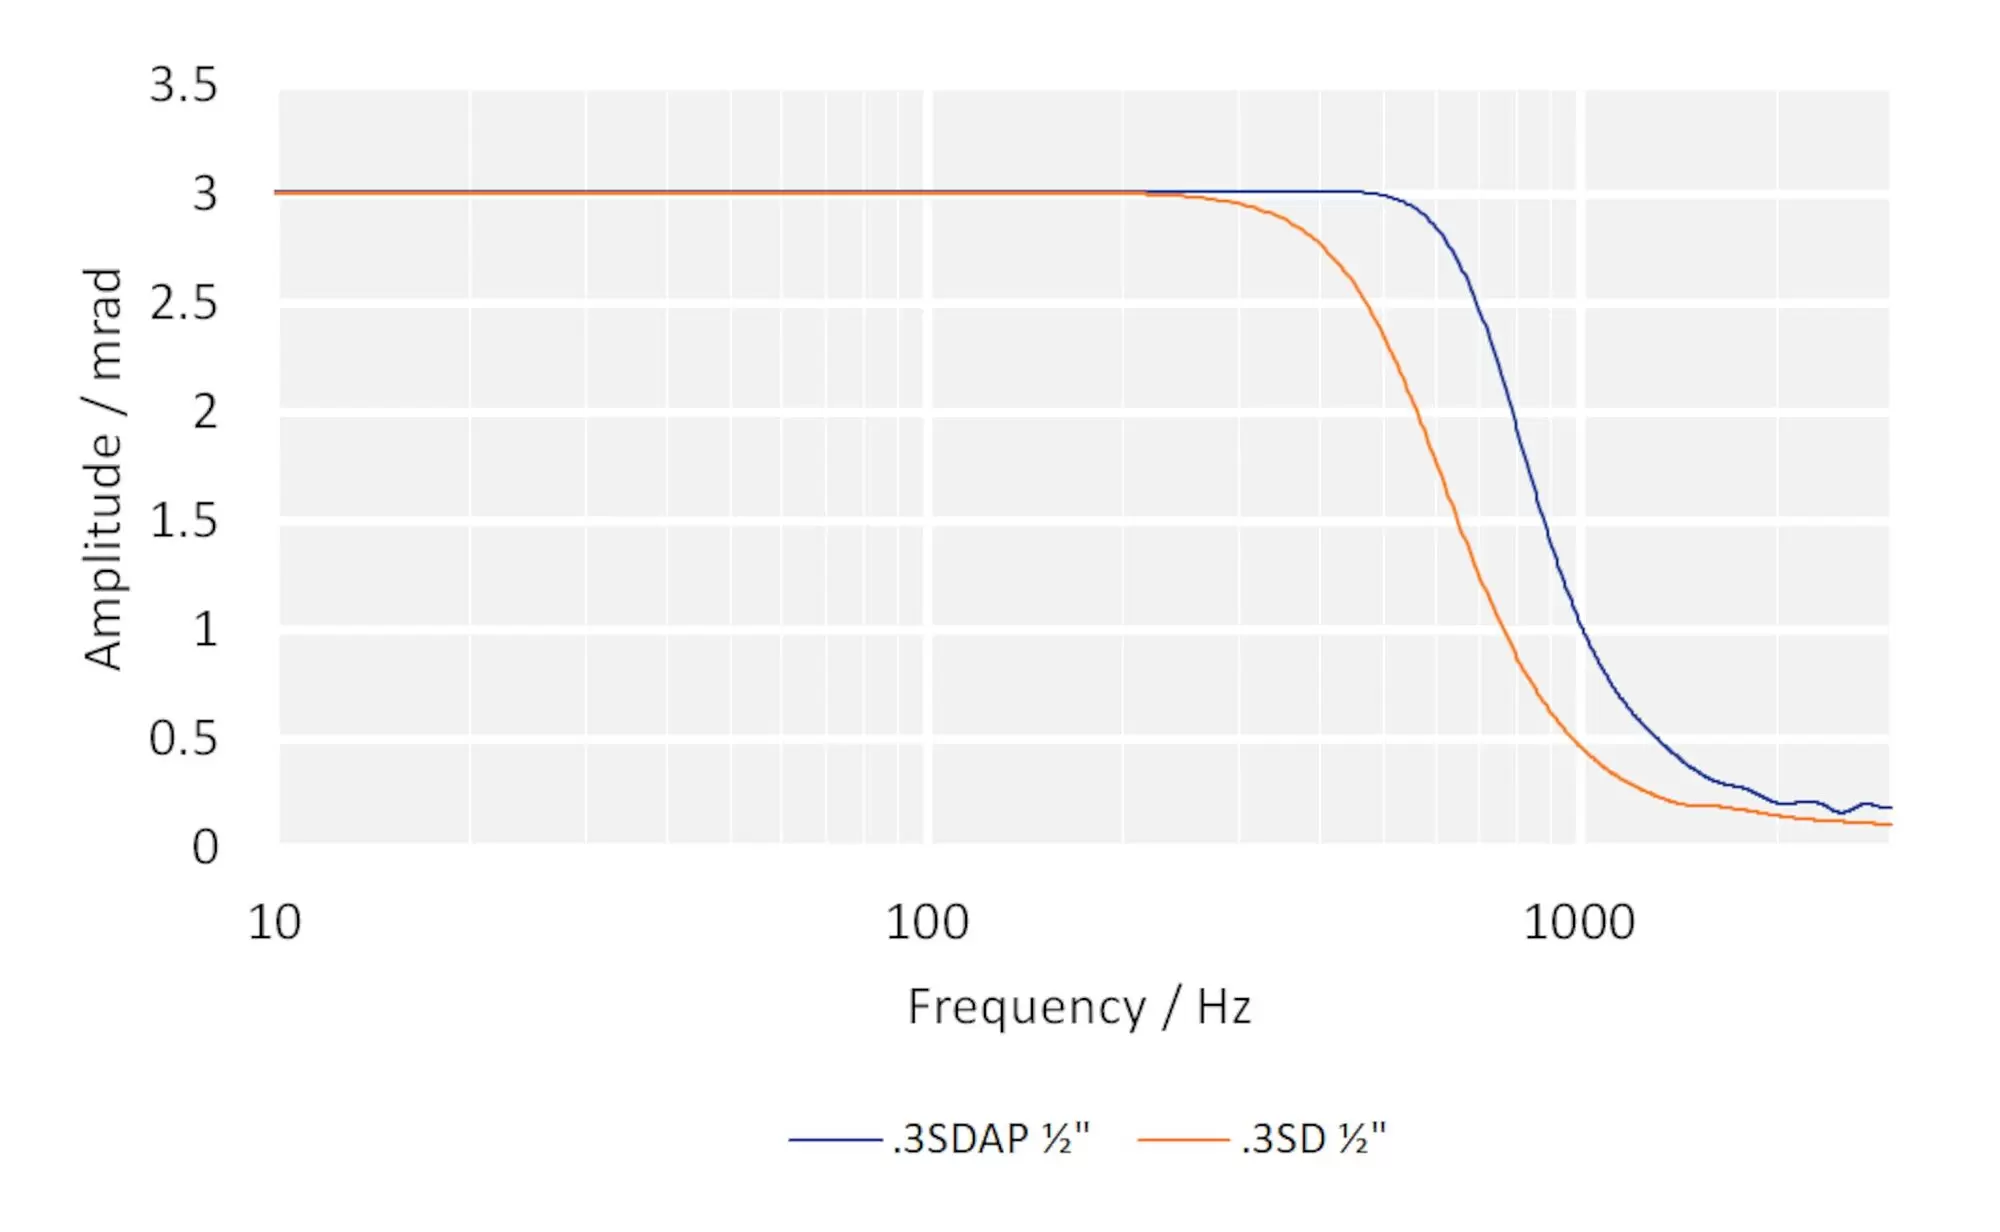
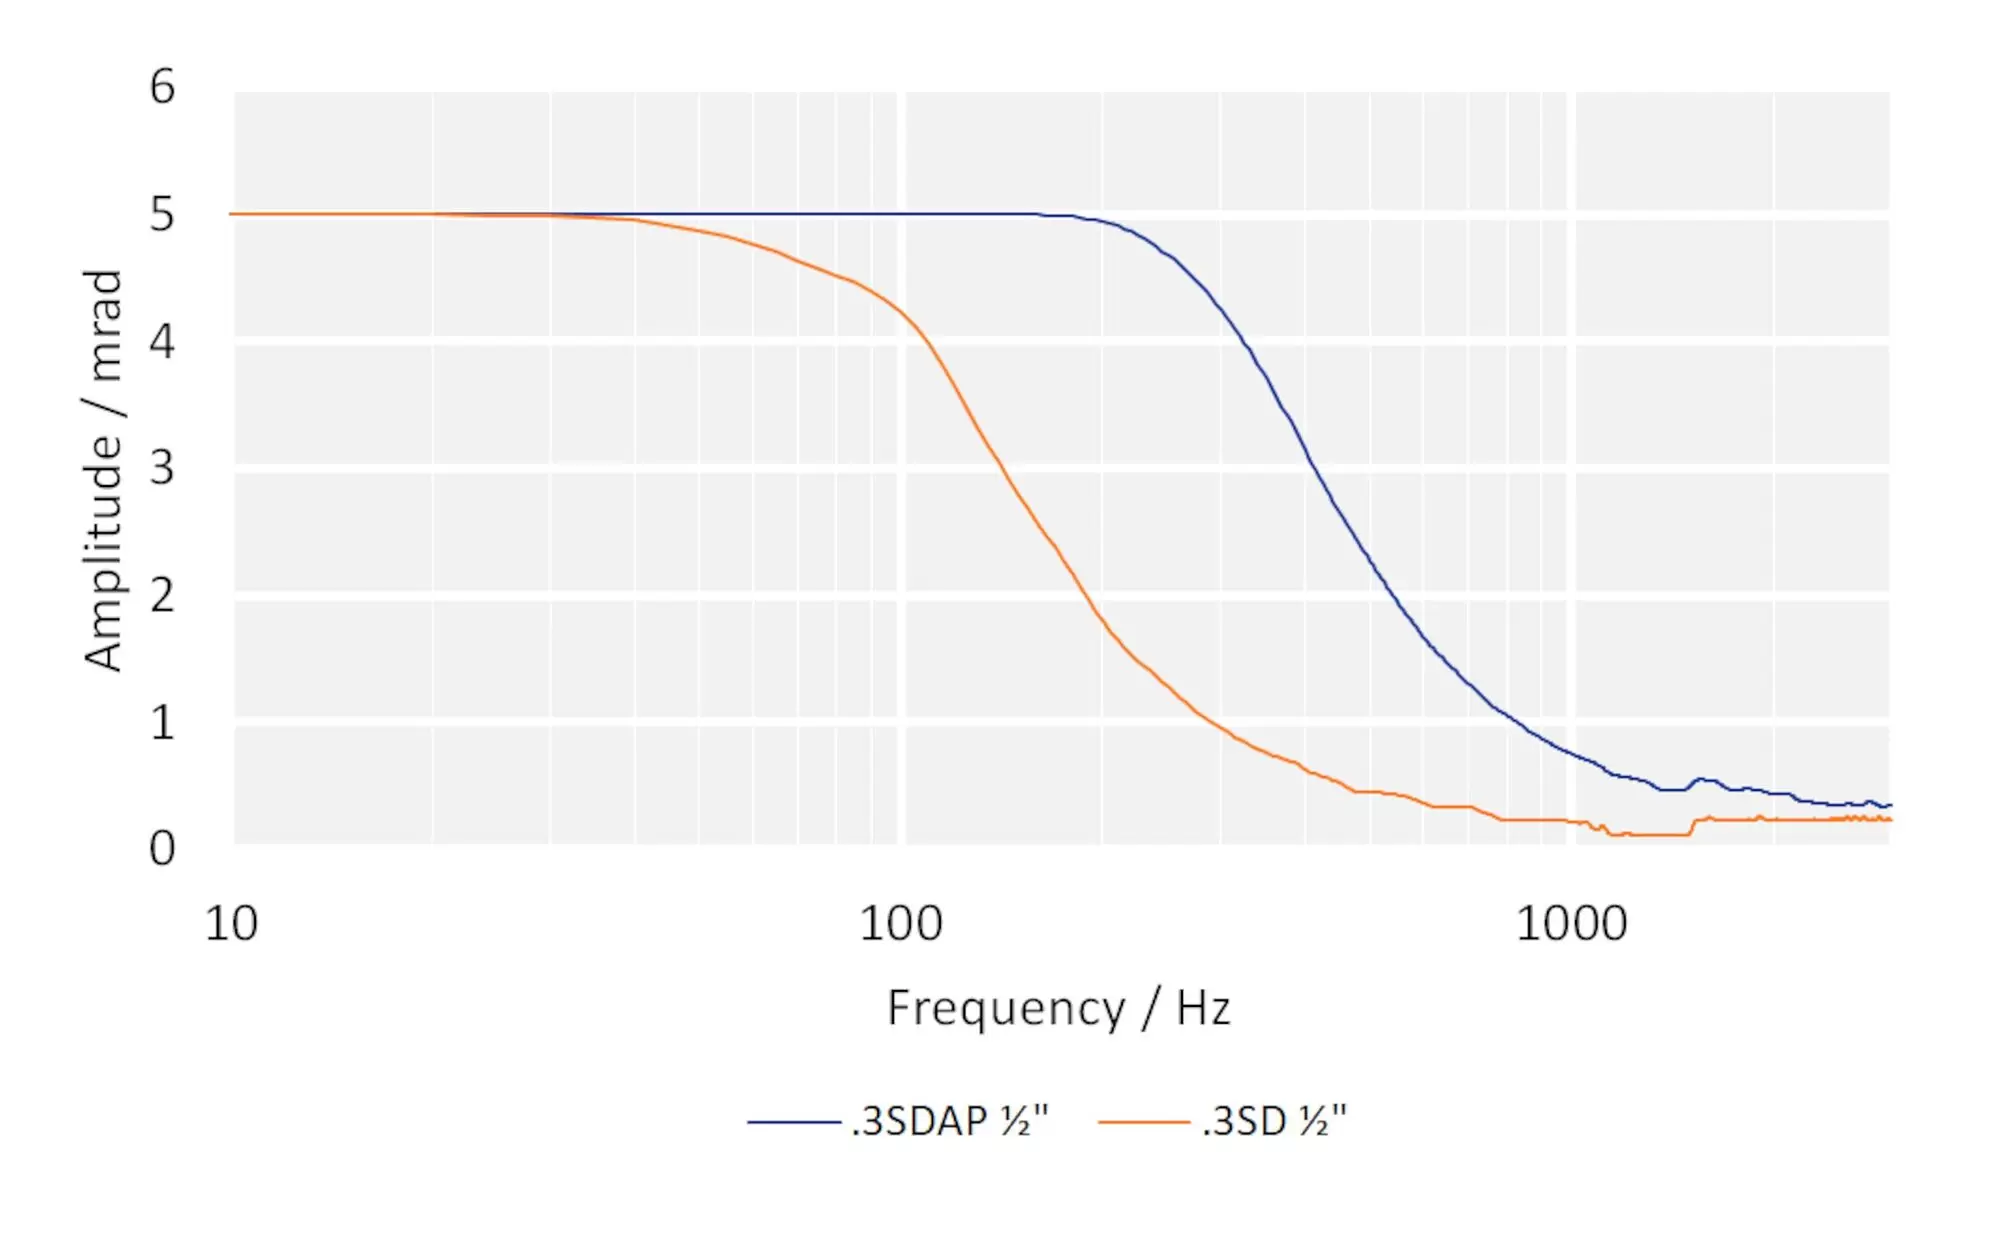
| Rotation range in θX | 3 mrad | 3 mrad | 5 mrad | 5 mrad | |
| Rotation range in θY | 3 mrad | 3 mrad | 5 mrad | 5 mrad | |
| Rotation range in θX, open loop | 4.2 mrad | 4.2 mrad | 7 mrad | 7 mrad | ±20% |
| Rotation range in θY, open loop | 4.2 mrad | 4.2 mrad | 7 mrad | 7 mrad | ±20% |
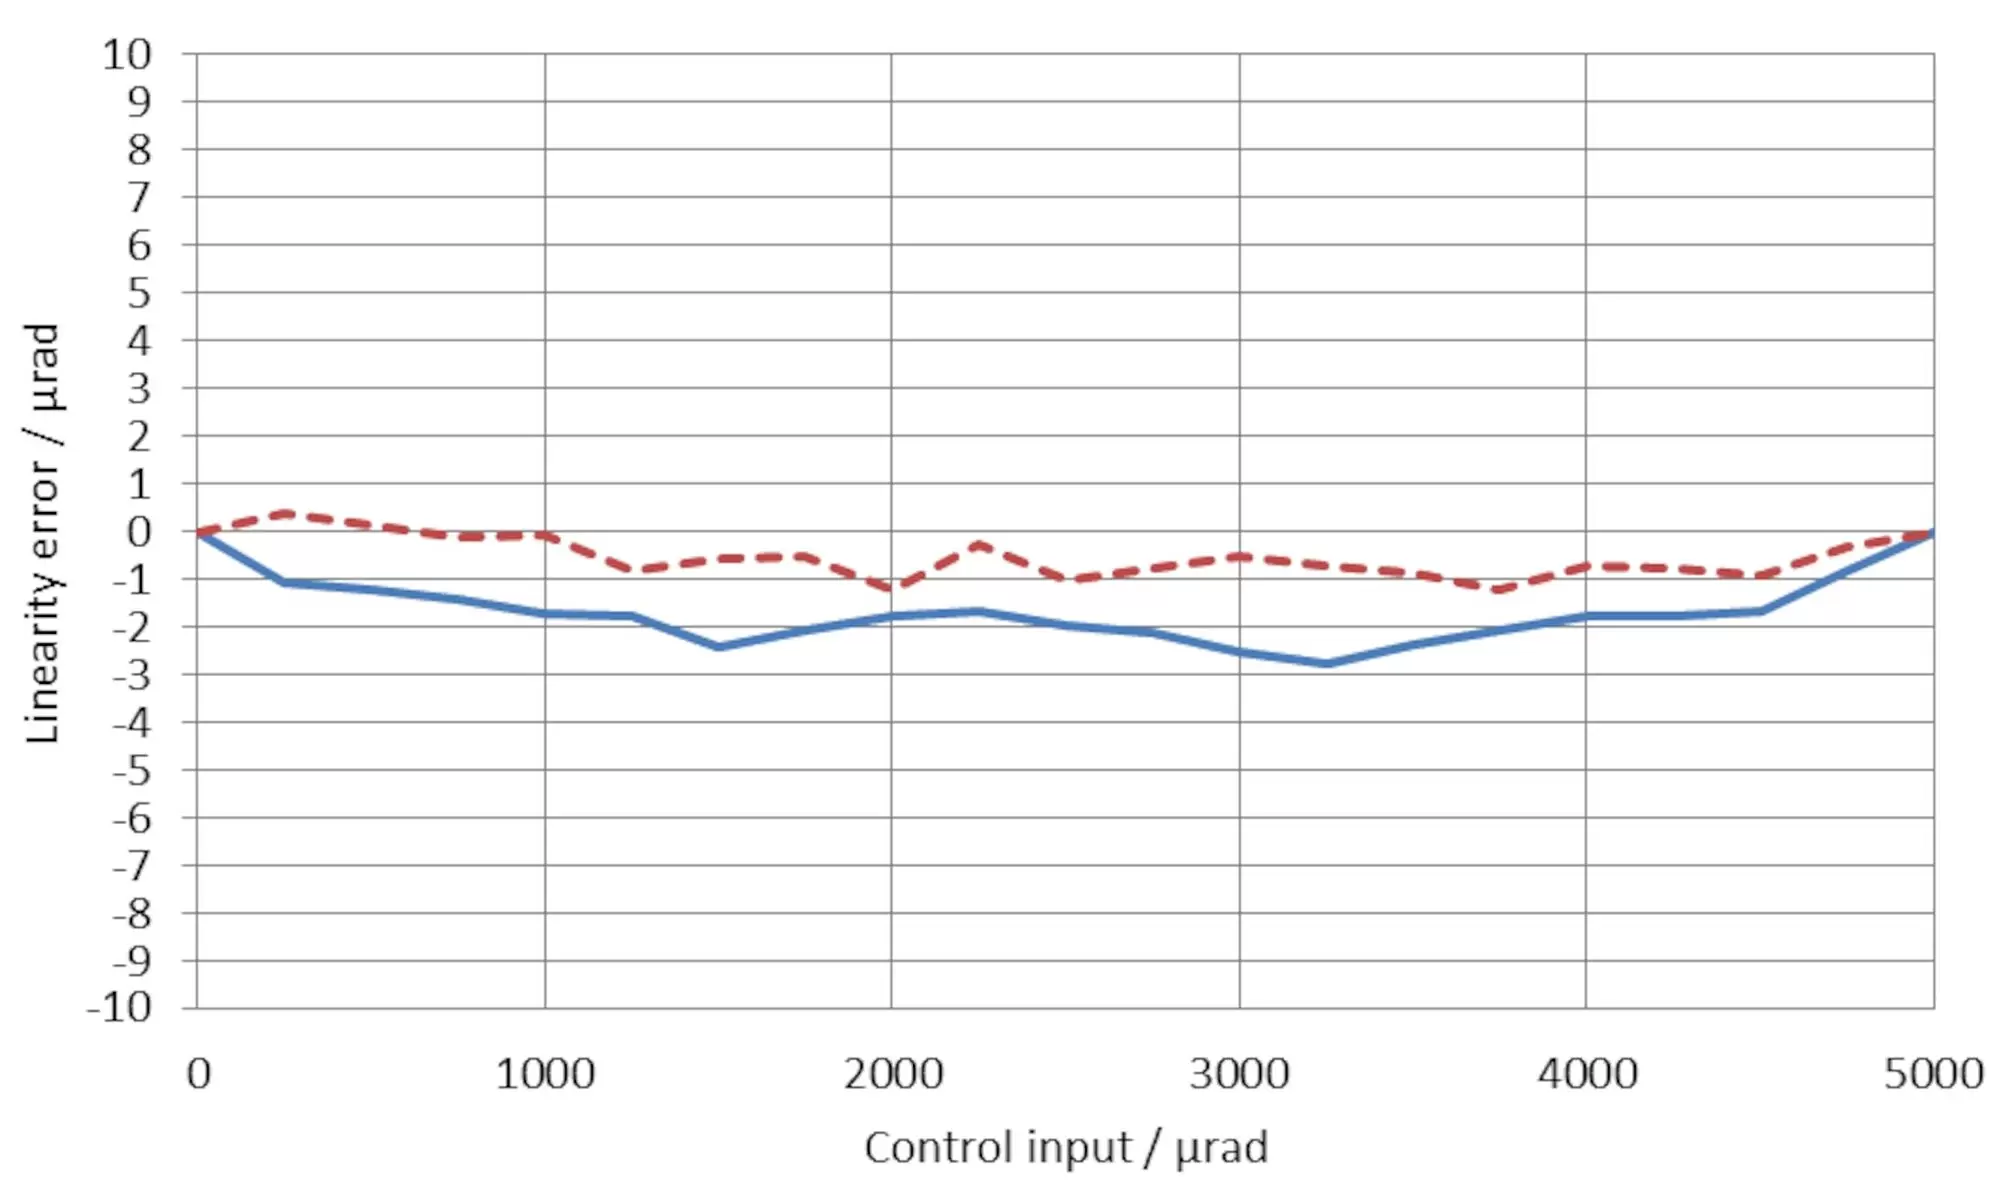
| Linearity error in θX | 0.1 % | 0.3 % | 0.1 % | 0.3 % | typ. |
| Linearity error in θY | 0.1 % | 0.3 % | 0.1 % | 0.3 % | typ. |
| Positioning | S-331.2SH | S-331.2SL | S-331.5SH | S-331.5SL | Tolerance |
| Integrated sensor | SGS, indirect position measuring | SGS, indirect position measuring | SGS, indirect position measuring | SGS, indirect position measuring | |
| Resolution in θX, open loop | 0.05 µrad | 0.05 µrad | 0.1 µrad | 0.1 µrad | typ. |
| Resolution in θY, open loop | 0.05 µrad | 0.05 µrad | 0.1 µrad | 0.1 µrad | typ. |
| Bidirectional repeatability in θX | ± 1.5 µrad | ± 1.5 µrad | ± 2.5 µrad | ± 2.5 µrad | typ. |
| Bidirectional repeatability in θY | ± 1.5 µrad | ± 1.5 µrad | ± 2.5 µrad | ± 2.5 µrad | typ. |
| Sensor resolution, rotational | 0.1 µrad | 0.1 µrad | 0.25 µrad | 0.25 µrad | |
| Drive Properties | S-331.2SH | S-331.2SL | S-331.5SH | S-331.5SL | Tolerance |
| Drive type | PICMA® | PICMA® | PICMA® | PICMA® | |
| Nominal voltage | 120 V | 120 V | 120 V | 120 V | |
| Electrical capacitance in θX | 0.96 µF | 0.96 µF | 6.2 µF | 6.2 µF | ±20% |
| Electrical capacitance in θY | 0.96 µF | 0.96 µF | 6.2 µF | 6.2 µF | ±20% |
| Mechanical Properties | S-331.2SH | S-331.2SL | S-331.5SH | S-331.5SL | Tolerance |
| Distance of pivot point to platform surface | 4 mm | 4 mm | 4 mm | 4 mm | ±0,1 mm |
| Guide | Flexure guide with lever amplification | Flexure guide with lever amplification | Flexure guide with lever amplification | Flexure guide with lever amplification | |
| Resonant frequency in θX, under load with glass mirror (Ø 12.7 mm; thickness 3 mm) | 9020 Hz | 9020 Hz | 2980 Hz | 2980 Hz | ±20% |
| Resonant frequency in θX, unloaded | 10050 Hz | 10050 Hz | 2990 Hz | 2990 Hz | ±20% |
| Resonant frequency in θY, under load with glass mirror (Ø 12.7 mm; thickness 3 mm) | 9020 Hz | 9020 Hz | 2980 Hz | 2980 Hz | ±20% |
| Resonant frequency in θY, unloaded | 10050 Hz | 10050 Hz | 2990 Hz | 2990 Hz | ±20% |
| Moment of inertia in θX, unloaded | 30 g·mm² | 30 g·mm² | 30 g·mm² | 30 g·mm² | ±20 % |
| Moment of inertia in θY, unloaded | 30 g·mm² | 30 g·mm² | 30 g·mm² | 30 g·mm² | ±20 % |
| Overall mass | 130 g | 130 g | 280 g | 280 g | |
| Material | Steel, platform titanium | Steel, platform titanium | Steel, platform titanium | Steel, platform titanium | |
| Miscellaneous | S-331.2SH | S-331.2SL | S-331.5SH | S-331.5SL | Tolerance |
| Connector | D-sub 37-pin (m) | LEMO LVPZT | D-sub 37-pin (m) | LEMO LVPZT | |
| Recommended controllers / drivers | E-727 | E-509.S3 + E-505.00 (2×) + E-505.00S + E-500.00 | E-727 | E-509.S3 + E-505.00 (2×) + E-505.00S + E-500.00 | |
| Cable length | 2 m | 2 m | 2 m | 2 m | |
| Operating temperature range | -20 to 80 °C | -20 to 80 °C | -20 to 80 °C | -20 to 80 °C | |
| Sensor connector | LEMO for strain gauge sensors | LEMO for strain gauge sensors |