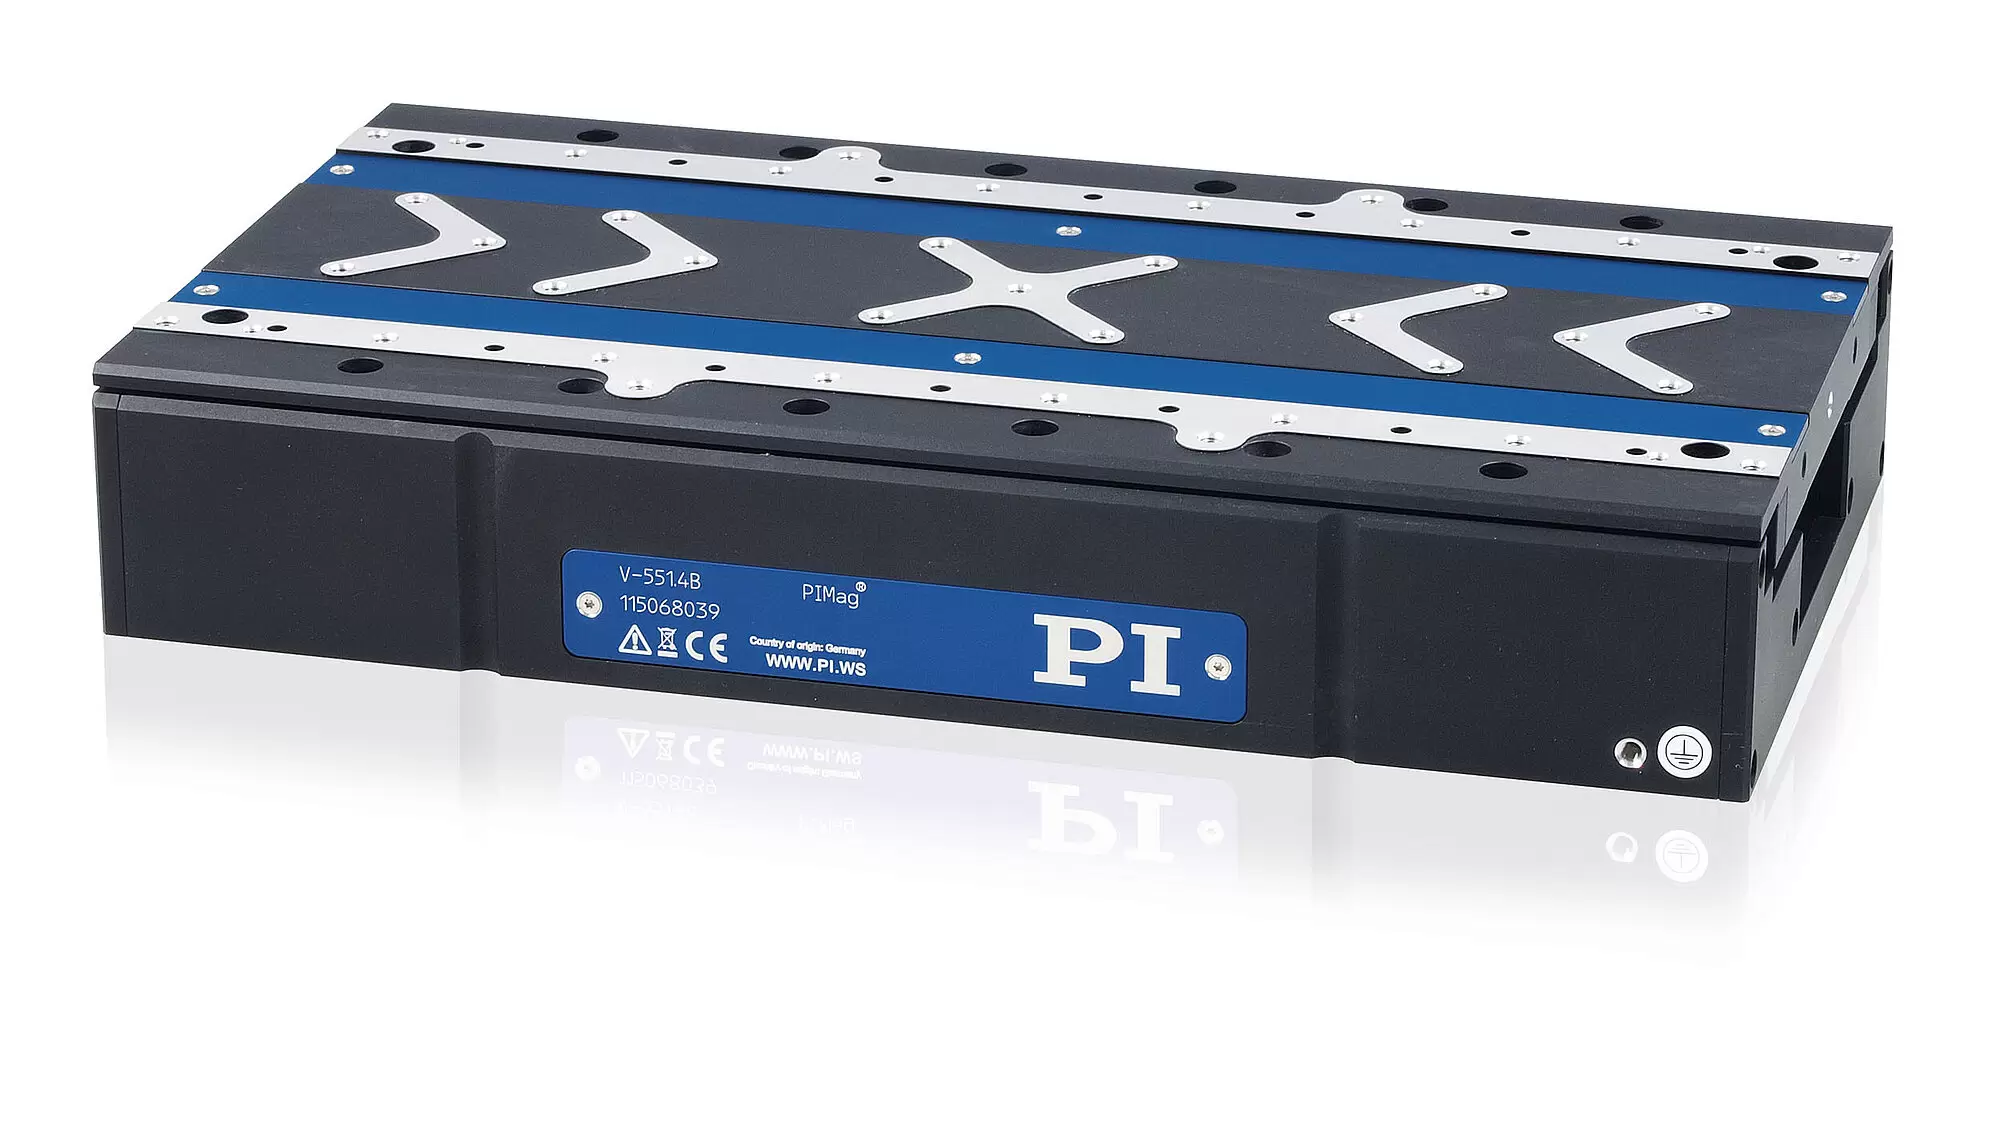
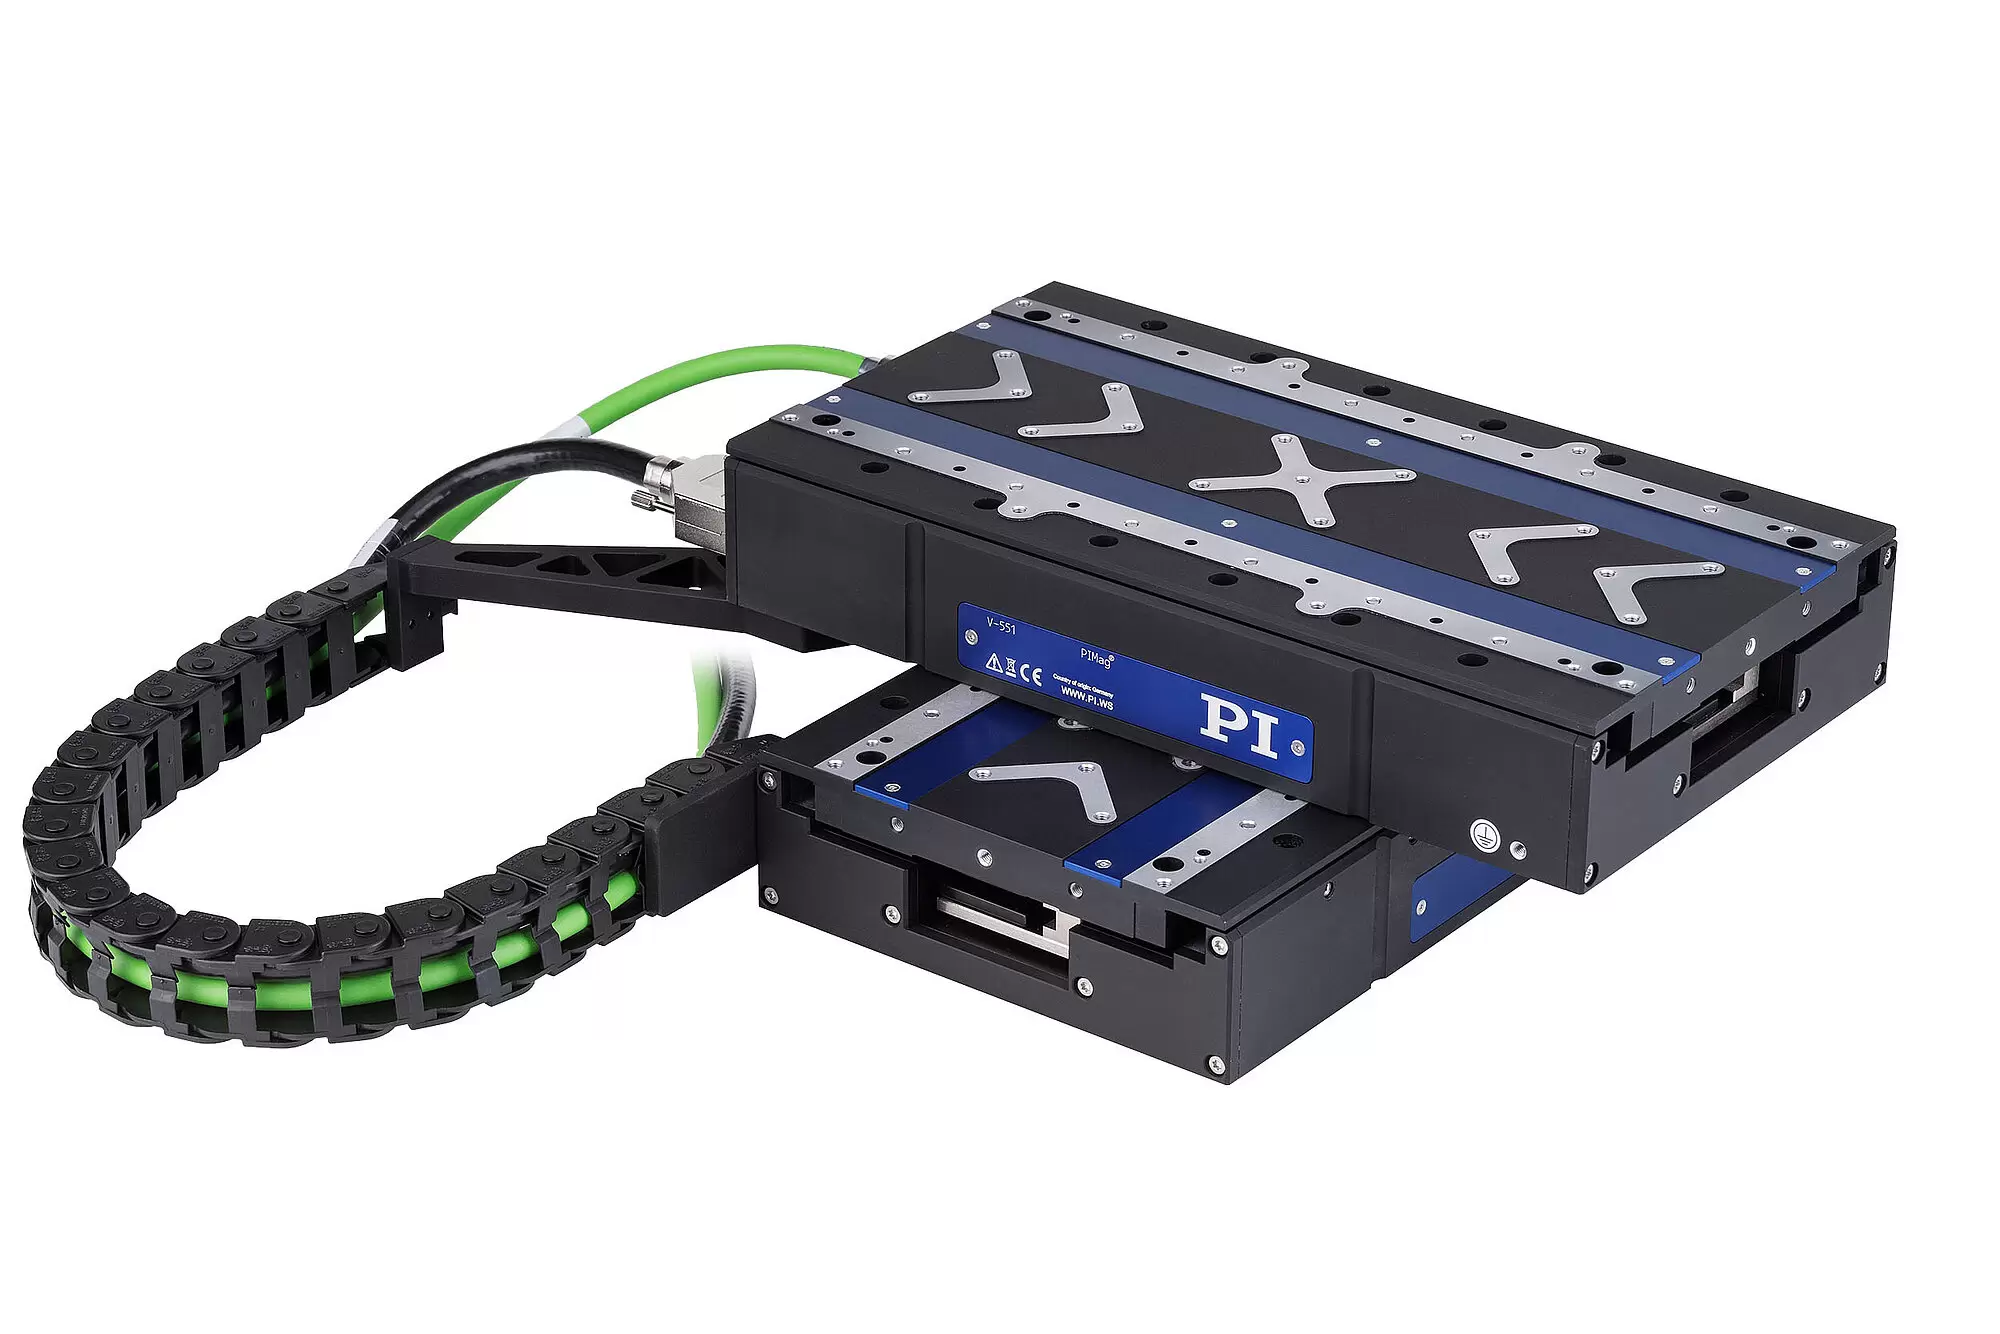
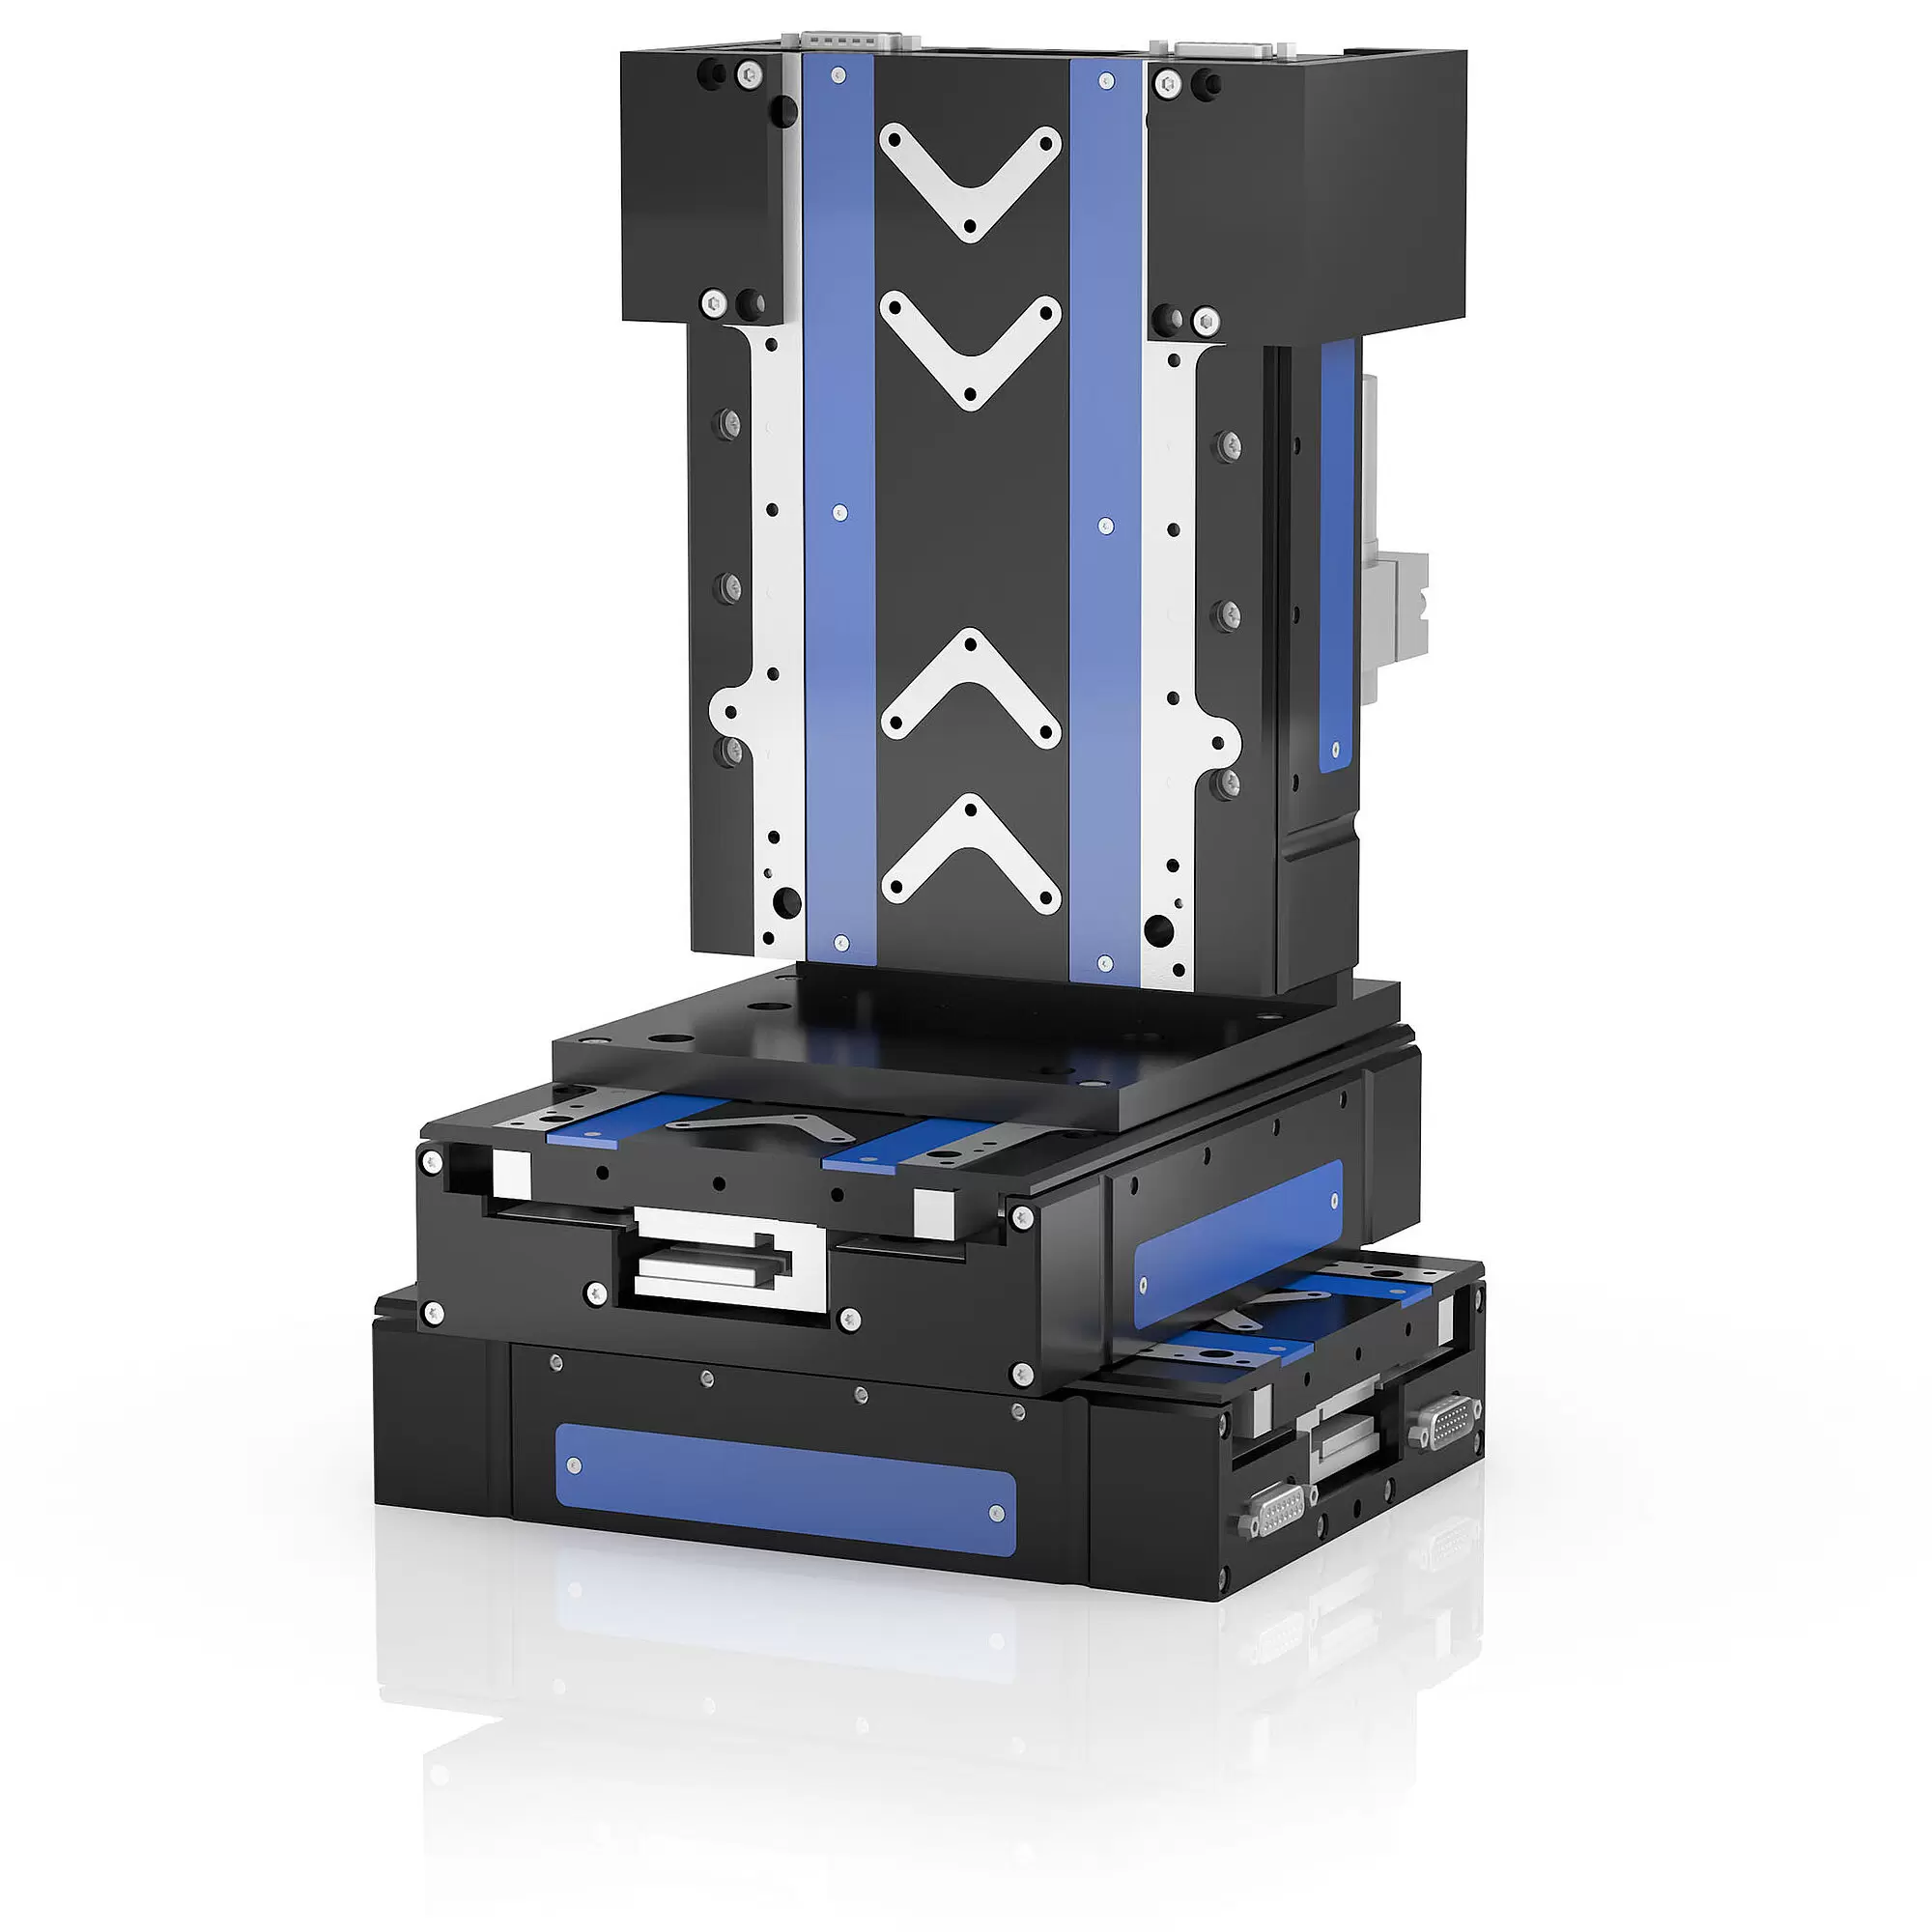
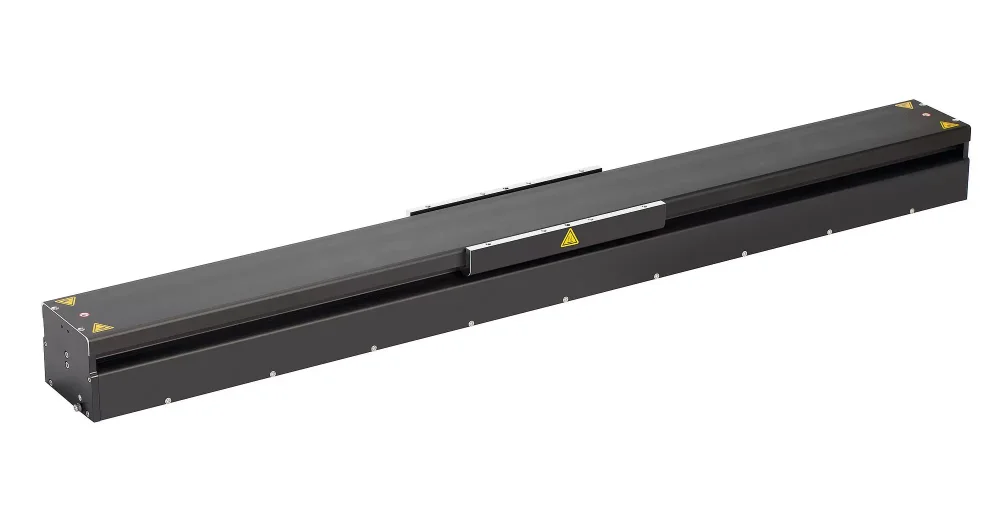
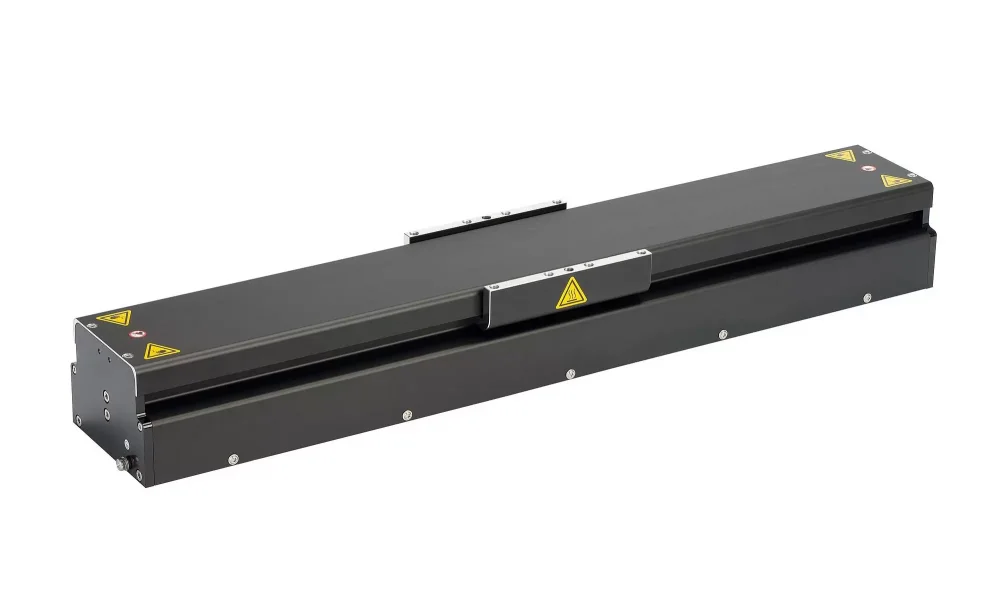
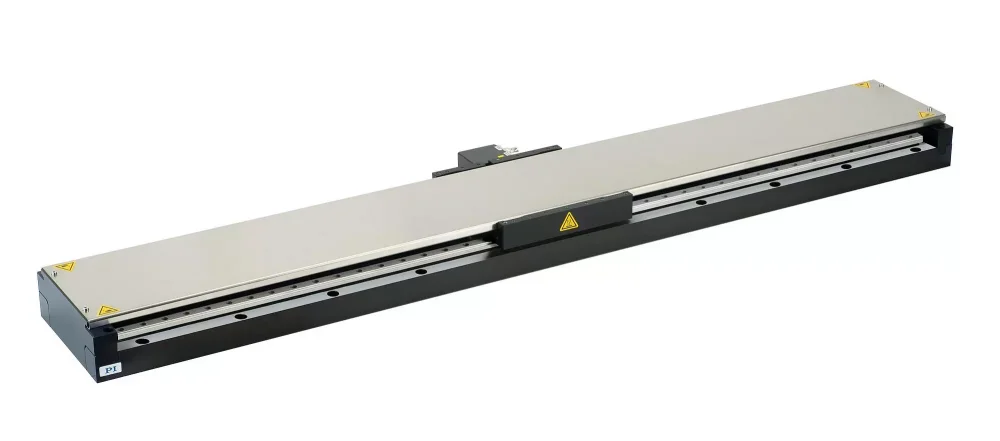
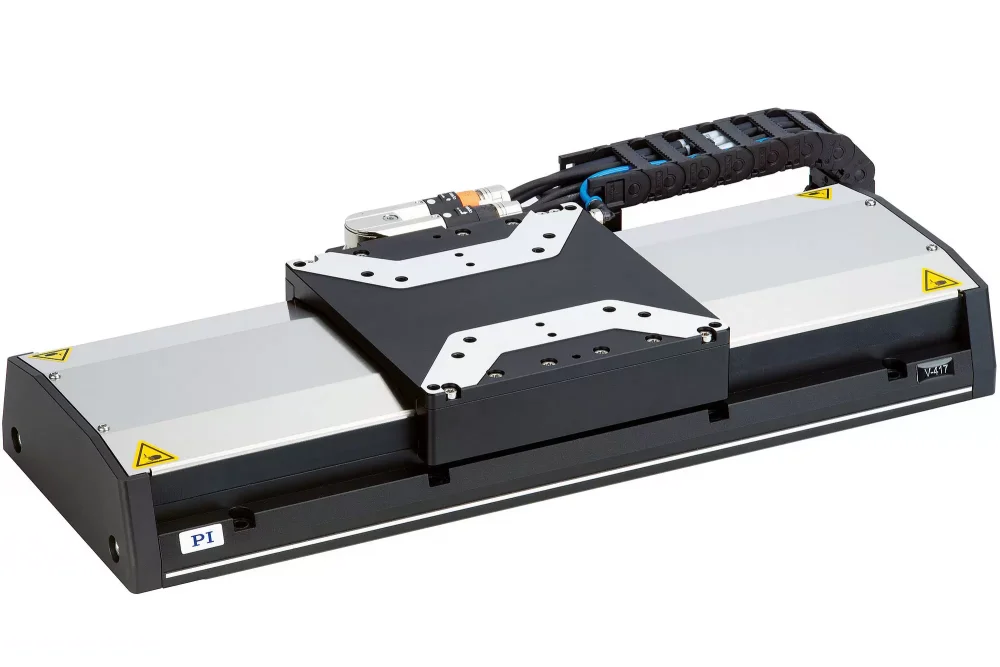
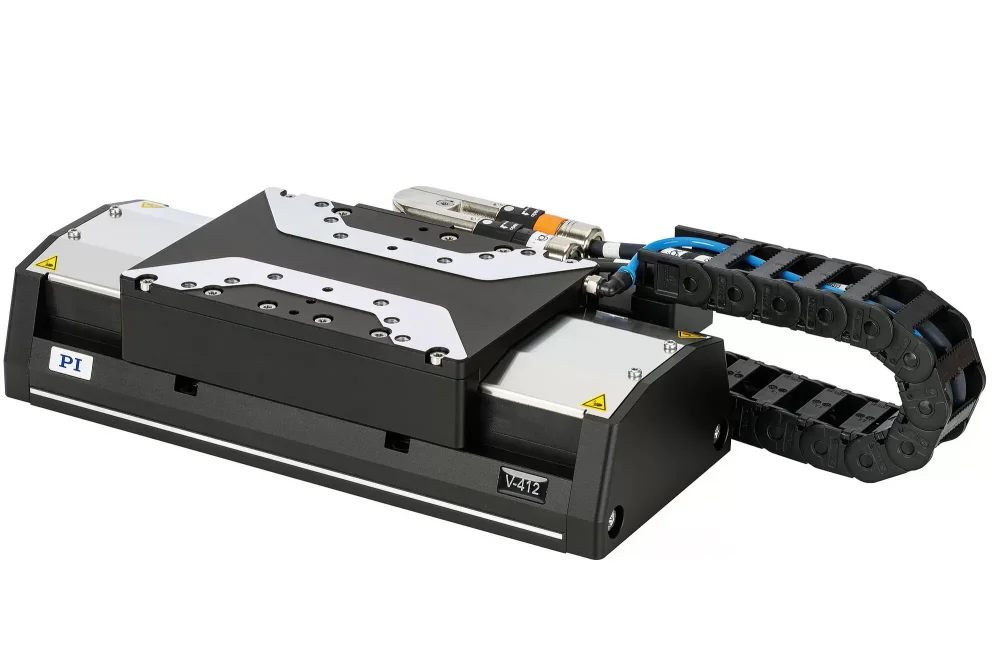
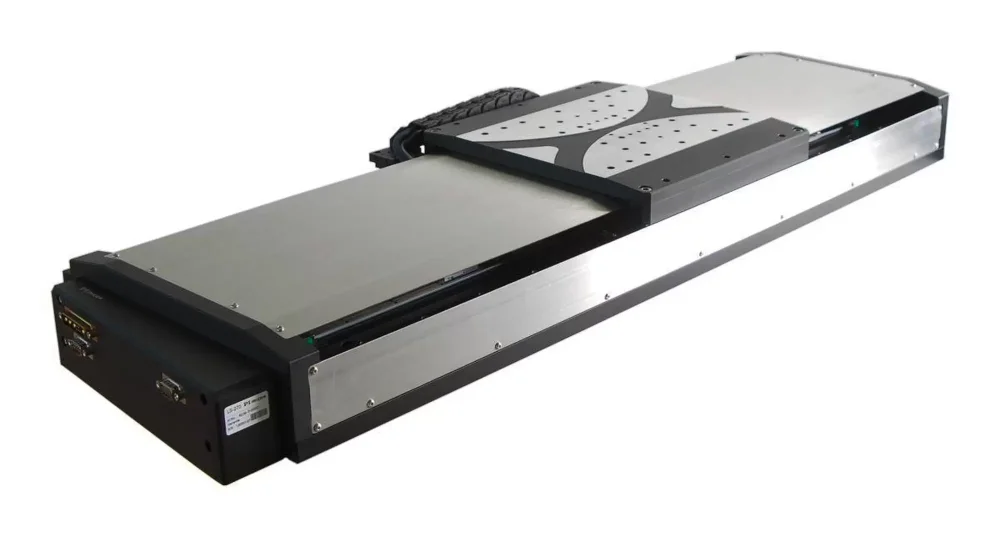
Thanks to the smooth-running precision linear guides with crossed roller bearings, the linear positioner is particularly suitable for scanning applications with constant velocity. The anti-creep system reliably prevents cage creep. The guides have high load capacity and high precision under all operating conditions.
Position measuring is performed with the highest accuracy directly at the motion platform so that nonlinearity, mechanical play or elastic deformation have no influence on position measuring.
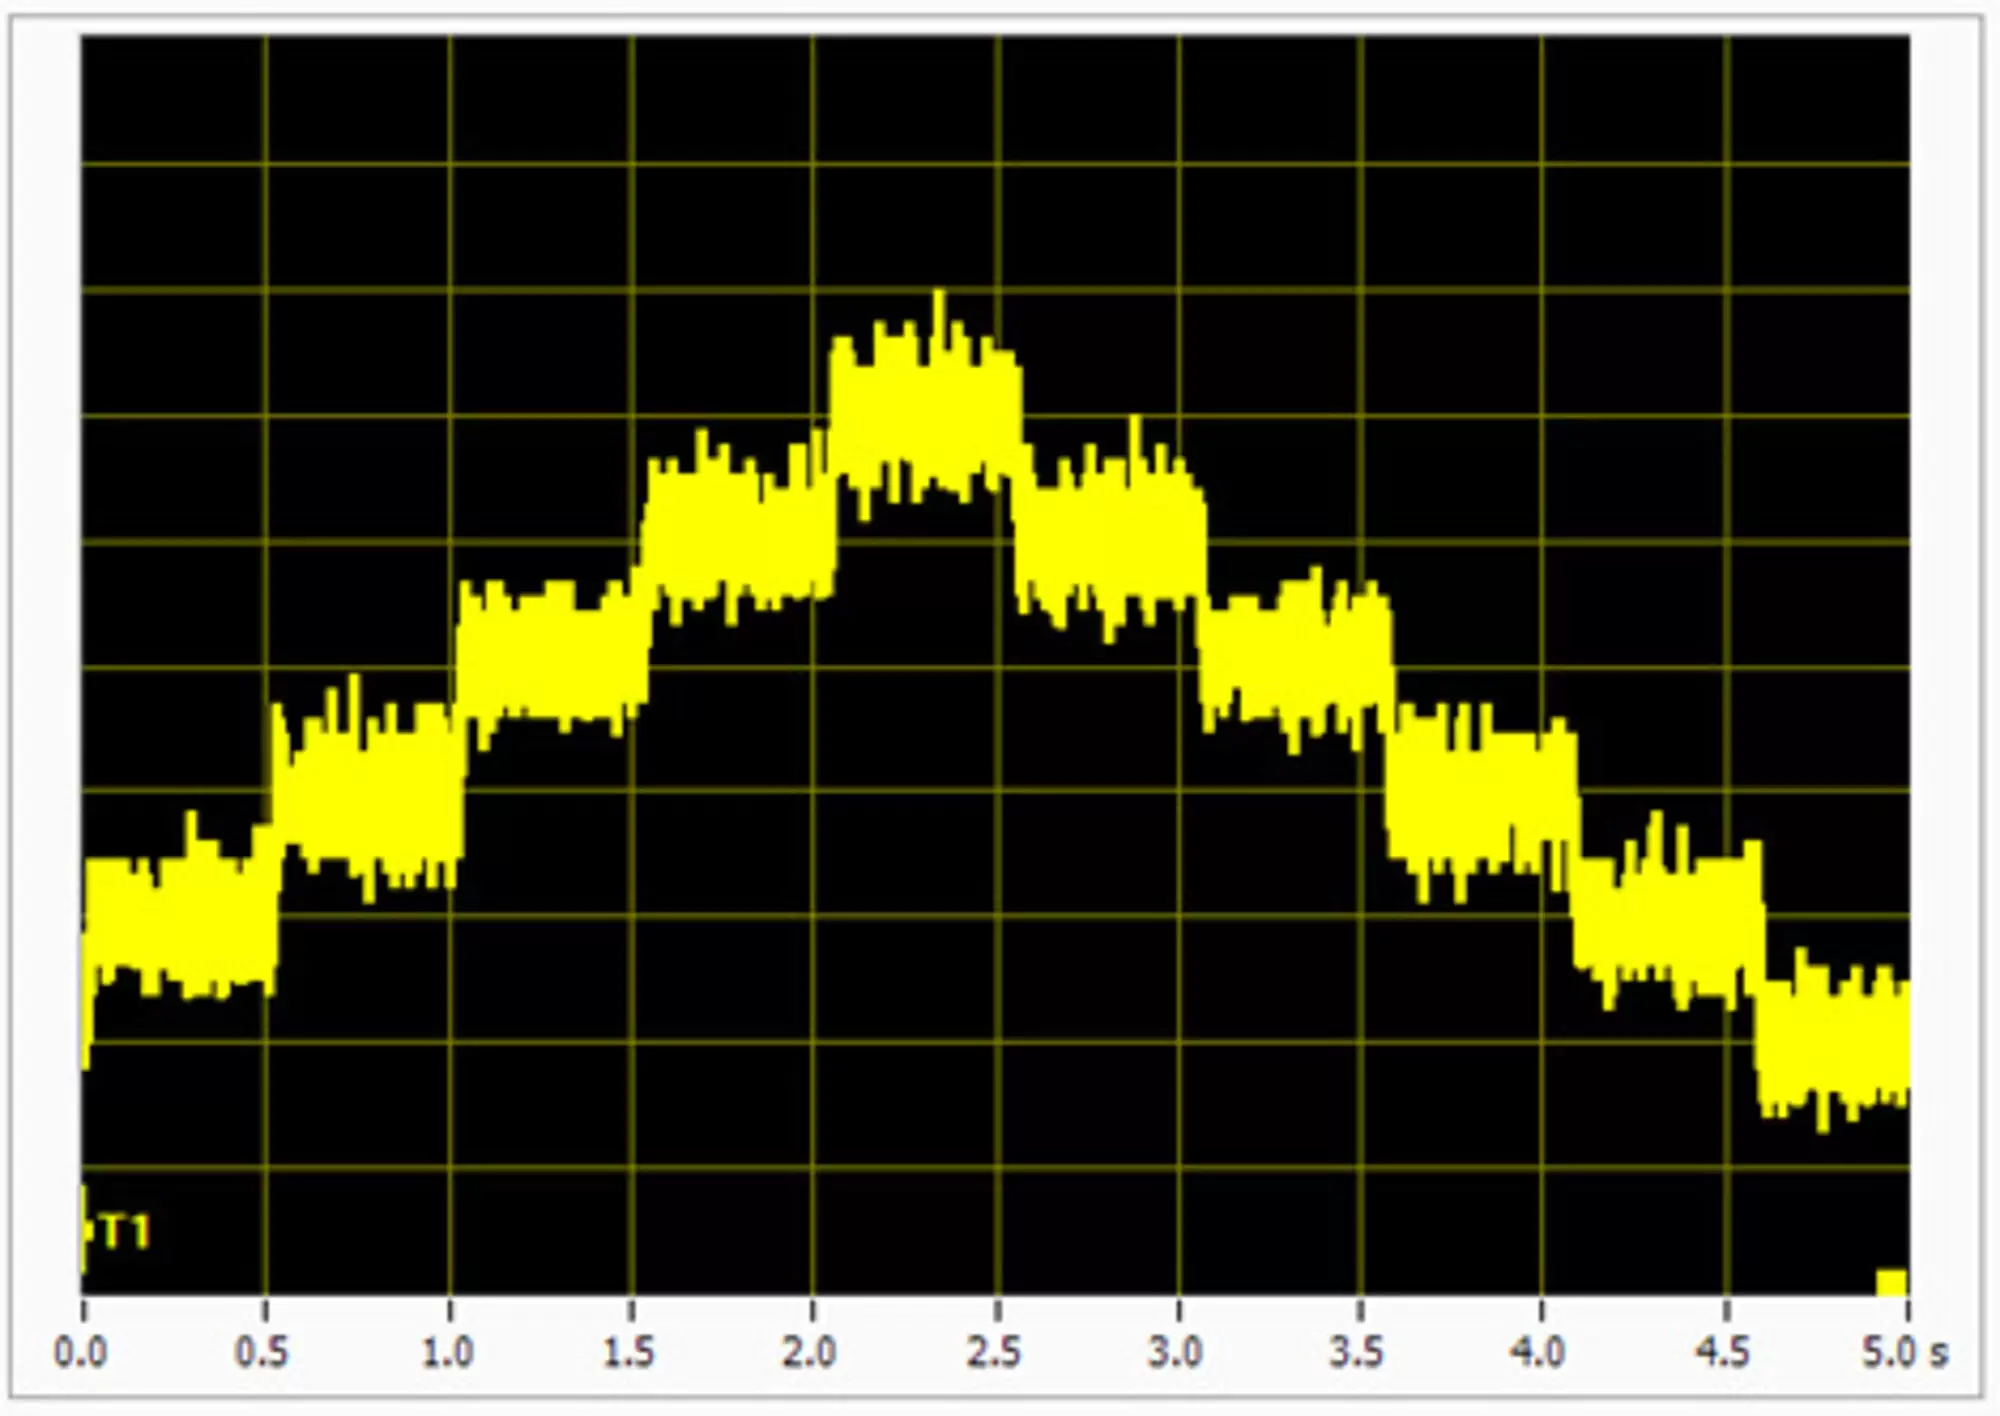
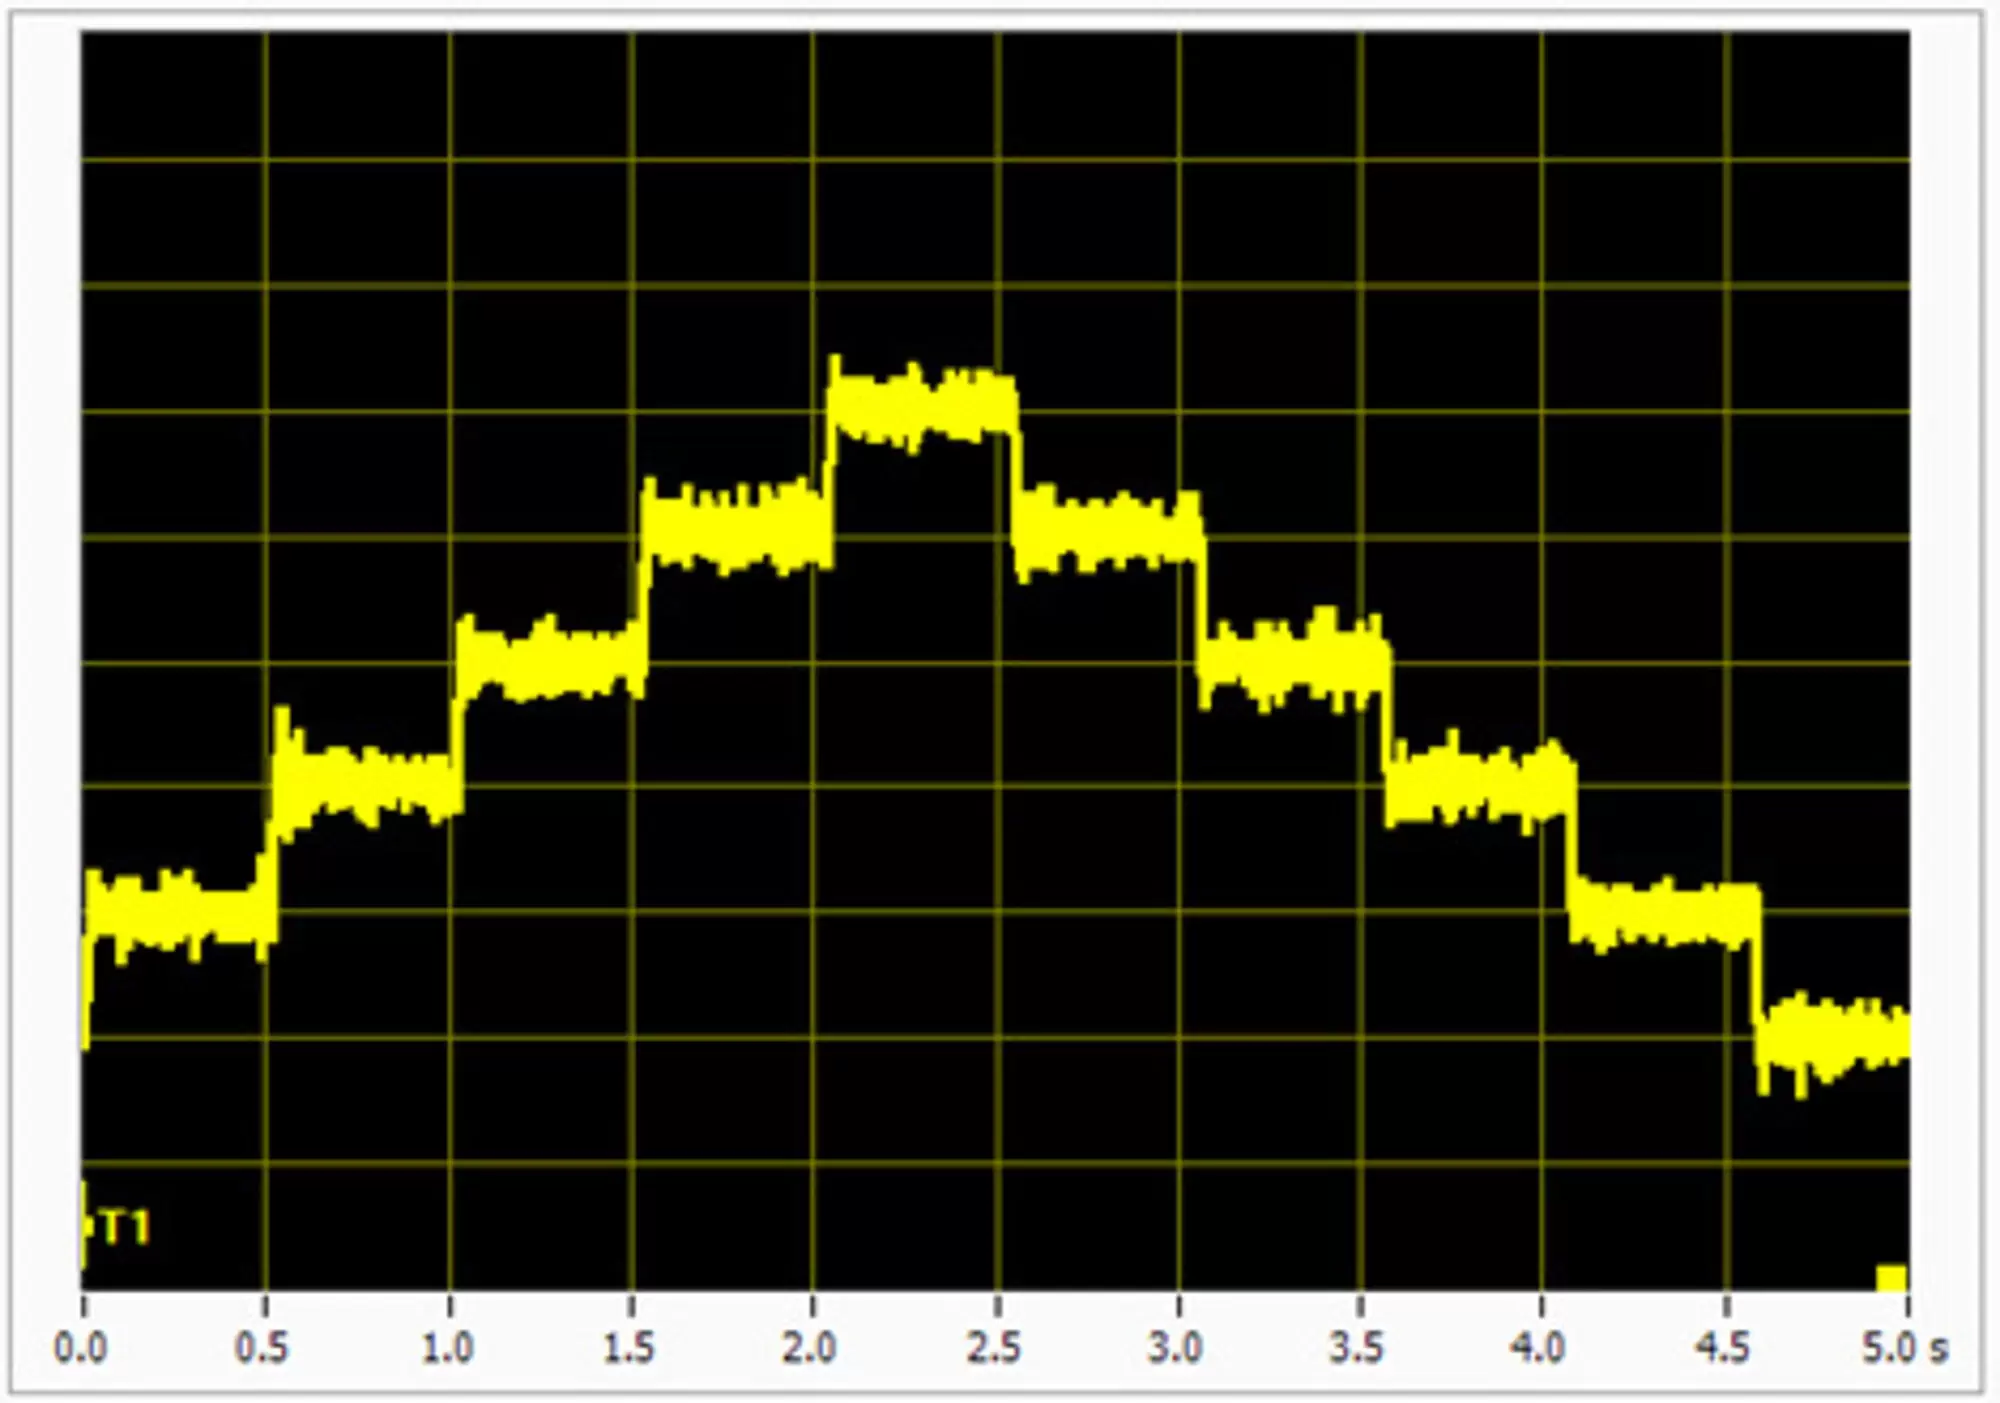
The high-resolution PIOne encoder was developed by PI and, with corresponding processing of the measured values, allows a position resolution of much less than one nanometer. The optical and noncontact PIOne encoders are based on an interferometric measuring principle. Due to the short signal period and the high quality of the signals, the linearity error of PIOne encoders is less than 1 %. PIOne encoders support direction sensing when evaluating a reference signal.
Absolute encoders supply explicit position information that enables immediate determination of the position. This means that referencing is not required during switch-on, which increases efficiency and safety during operation.
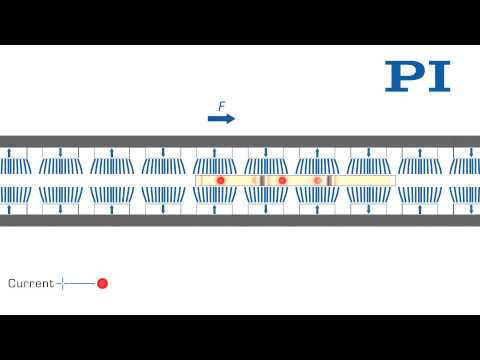
Linear motors are electromagnetic direct drives. They dispense with mechanical components in the drivetrain and transfer the drive force directly and friction-free to the motion platform. The drives reach high velocities and accelerations. Ironless motors are particularly suitable for positioning tasks with the highest demands on precision because there is no undesirable interaction with the permanent magnets. This allows smooth running even at the lowest velocities and at the same time, there is no vibration at high velocities. Nonlinearity in control behavior is avoided and any position can be controlled easily. The drive force can be set freely.
Industry and research. Automation. Metrology. Photonics and precision scanning in semiconductor or flat panel display manufacturing
Motion and positioning | V-551.2x | V-551.4x | V-551.7x | Unit | Tolerance |
|---|---|---|---|---|---|
Active axes | X | X | X | ||
Travel range | 60 | 130 | 230 | mm | |
Pitch | ±50 | ±100 | ±100 | µrad | Typ. |
Yaw | ±50 | ±50 | ±50 | µrad | Typ. |
Straightness | ±1 | ±1 | ±2 | µm | Typ. |
Flatness | ±2 | ±2 | ±2 | µm | Typ. |
Velocity | 0.5 (1) | 0.5 (1) | 0.5 (1) | m/s | Max. |
Mechanical properties | V-551.2x | V-551.4x | V-551.7x | Unit | Tolerance |
|---|---|---|---|---|---|
Load capacity in Z | 150 | 150 | 150 | N | Max. |
Load capacity in Y | 50 | 50 | 50 | N | Max. |
Moved mass | 2.2 | 2.7 | 4.9 | kg | |
Overall mass | 4.2 | 5.5 | 9.7 | kg | |
Linear guide | Crossed roller bearing with anti-creep system | Crossed roller bearing with anti-creep system | Crossed roller bearing with anti-creep system |
Drive properties | V-551 | Unit | Tolerance |
|---|---|---|---|
Drive type | Linear motor, ironless, 3-phase | ||
Intermediate circuit voltage | 48 (2) | V DC | Max. |
Peak force | 180 | N | Typ. |
Nominal force | 27 | N | Typ. |
Peak current, RMS | 10 | A | Typ. |
Nominal current, RMS | 1.5 | A | Typ. |
Force constant, RMS | 18 | N/A | Typ. |
Resistance per phase | 3.15 | Ω | Typ. |
Inductance per phase | 0.9 | mH | Typ. |
Back EMF phase-phase | 16 | Vs/m | Max. |
Pole pitch N-N | 30 | mm |
Encoder options | V-551.xB | V-551.xD |
|---|---|---|
Integrated sensor | Absolute encoder | PIOne incremental linear encoder |
Sensor signal | BiSS-C | Sin/cos, 1 V peak-peak, 2 µm signal period |
Sensor resolution | 1 nm | 0.2 nm (3) |
Min. incremental motion | 2 nm | 0.5 nm (4) |
Unidirectional repeatability | 0.02 µm | 0.02 µm |
Bidirectional repeatability | ±0.05 µm | ±0.05 µm |
Travel range limit | Limits are set via software; additional mechanical stop buffers. | Hall effect limit switches, N/O contact, 5 V, TTL |
Reference switch | – | Optical, direction sensing (reference edge track), 5 V, TTL |
Reference switch repeatability | – | <1 µm |
Encoder options | V-551.xB | V-551.xD |
|---|---|---|
Integrated sensor | Absolute encoder | PIOne incremental linear encoder |
Sensor signal | BiSS-C | Sin/cos, 1 V peak-peak, 2 µm signal period |
Sensor resolution | 1 nm | 0.2 nm (3) |
Min. incremental motion | 2 nm | 0.5 nm (4) |
Unidirectional repeatability | 0.02 µm | 0.02 µm |
Bidirectional repeatability | ±0.05 µm | ±0.05 µm |
Travel range limit | Limits are set via software; additional mechanical stop buffers. | Hall effect limit switches, N/O contact, 5 V, TTL |
Reference switch | – | Optical, direction sensing (reference edge track), 5 V, TTL |
Reference switch repeatability | – | <1 µm |
Miscellaneous | V-551 |
|---|---|
Operating temperature range | 10 °C to 50 °C |
Humidity | 20 – 90% rel., not condensing |
Material | Aluminum, black anodized |
Motor connector | HD D-sub 26 (m) |
Sensor connector | D-sub 15 (f) |
(1) Max. 0.2 m/s for V-551.xD when combined with the C-891
(2) 24 VDC with C-891 and 24V power adapter
(3) interpolated
(4) with ACS NanoPWM
Connecting cables are not in the scope of delivery and must be ordered separately.