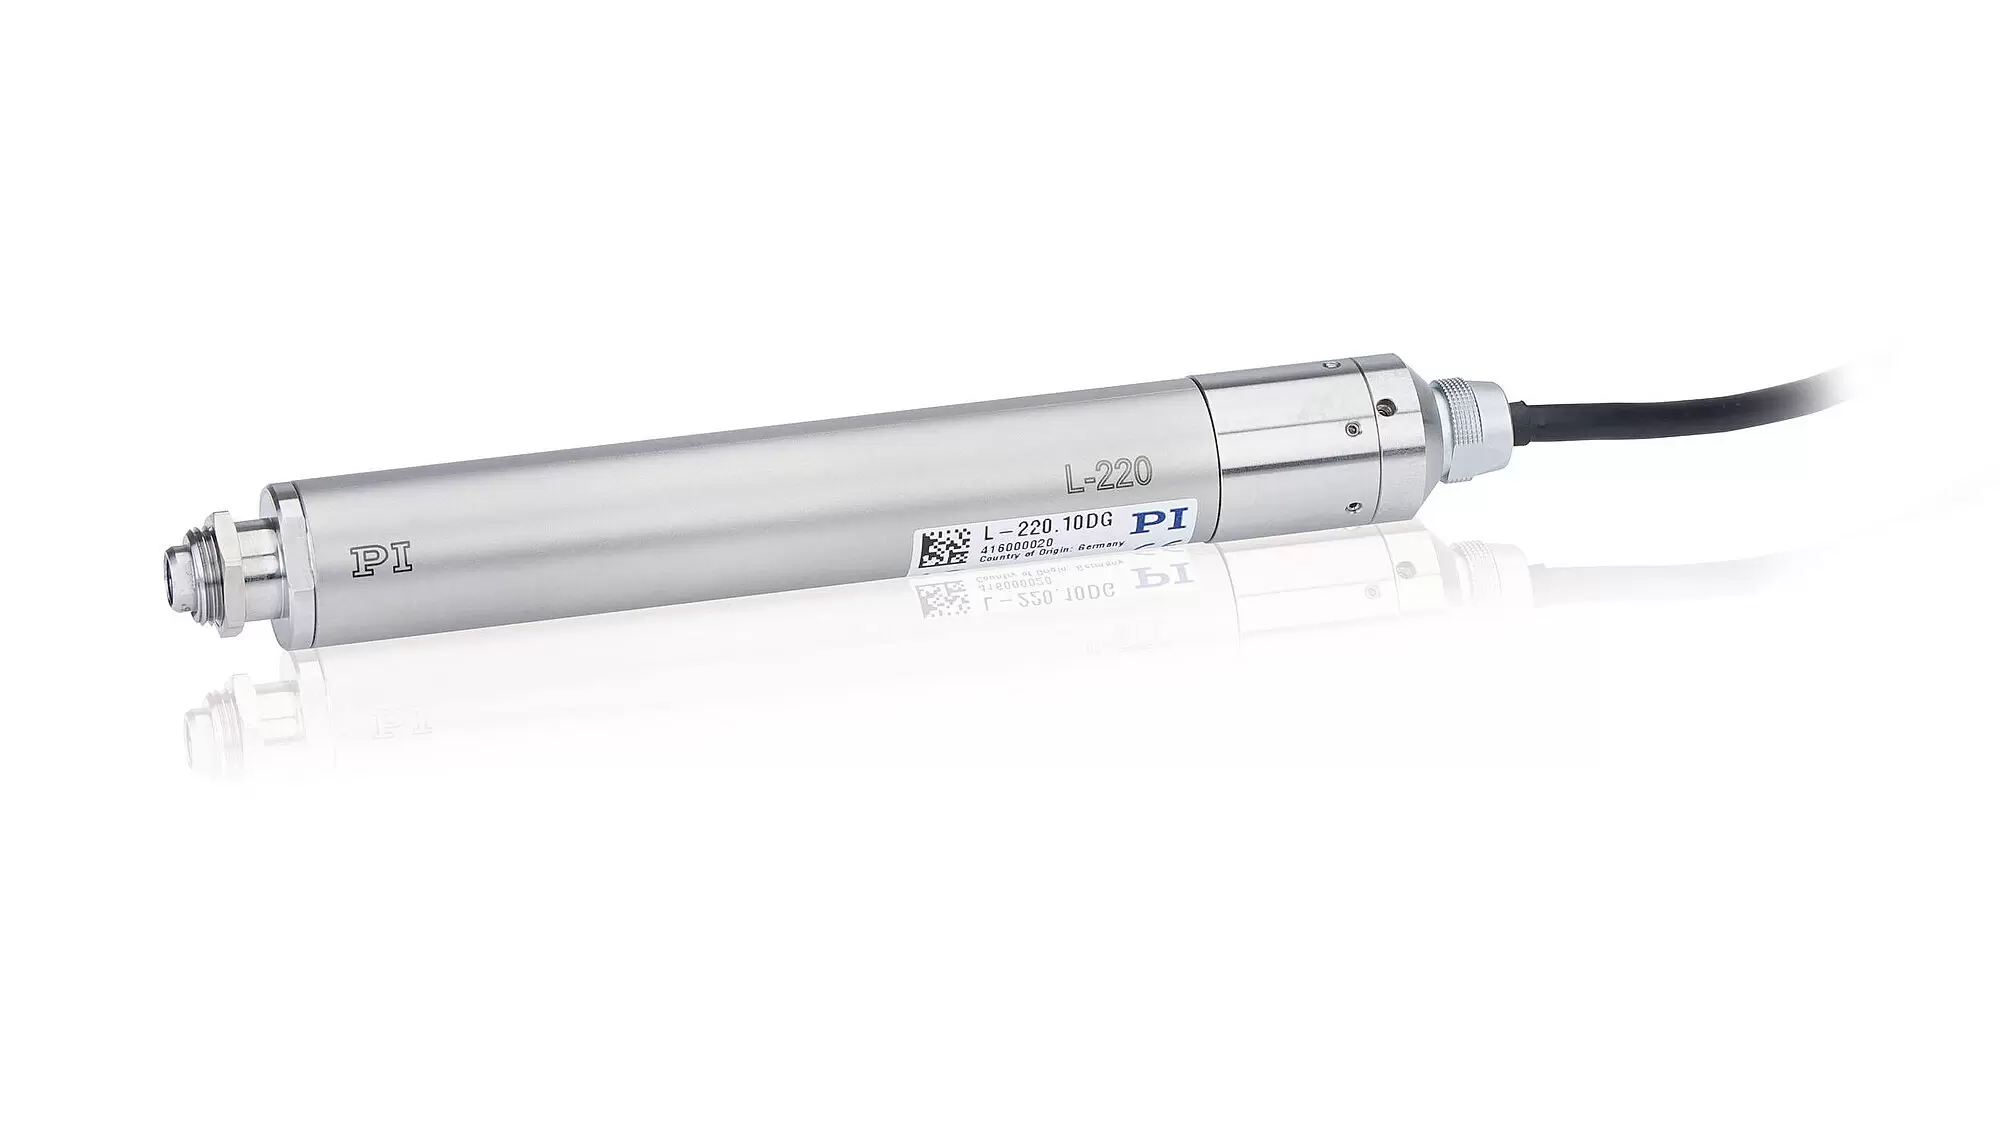
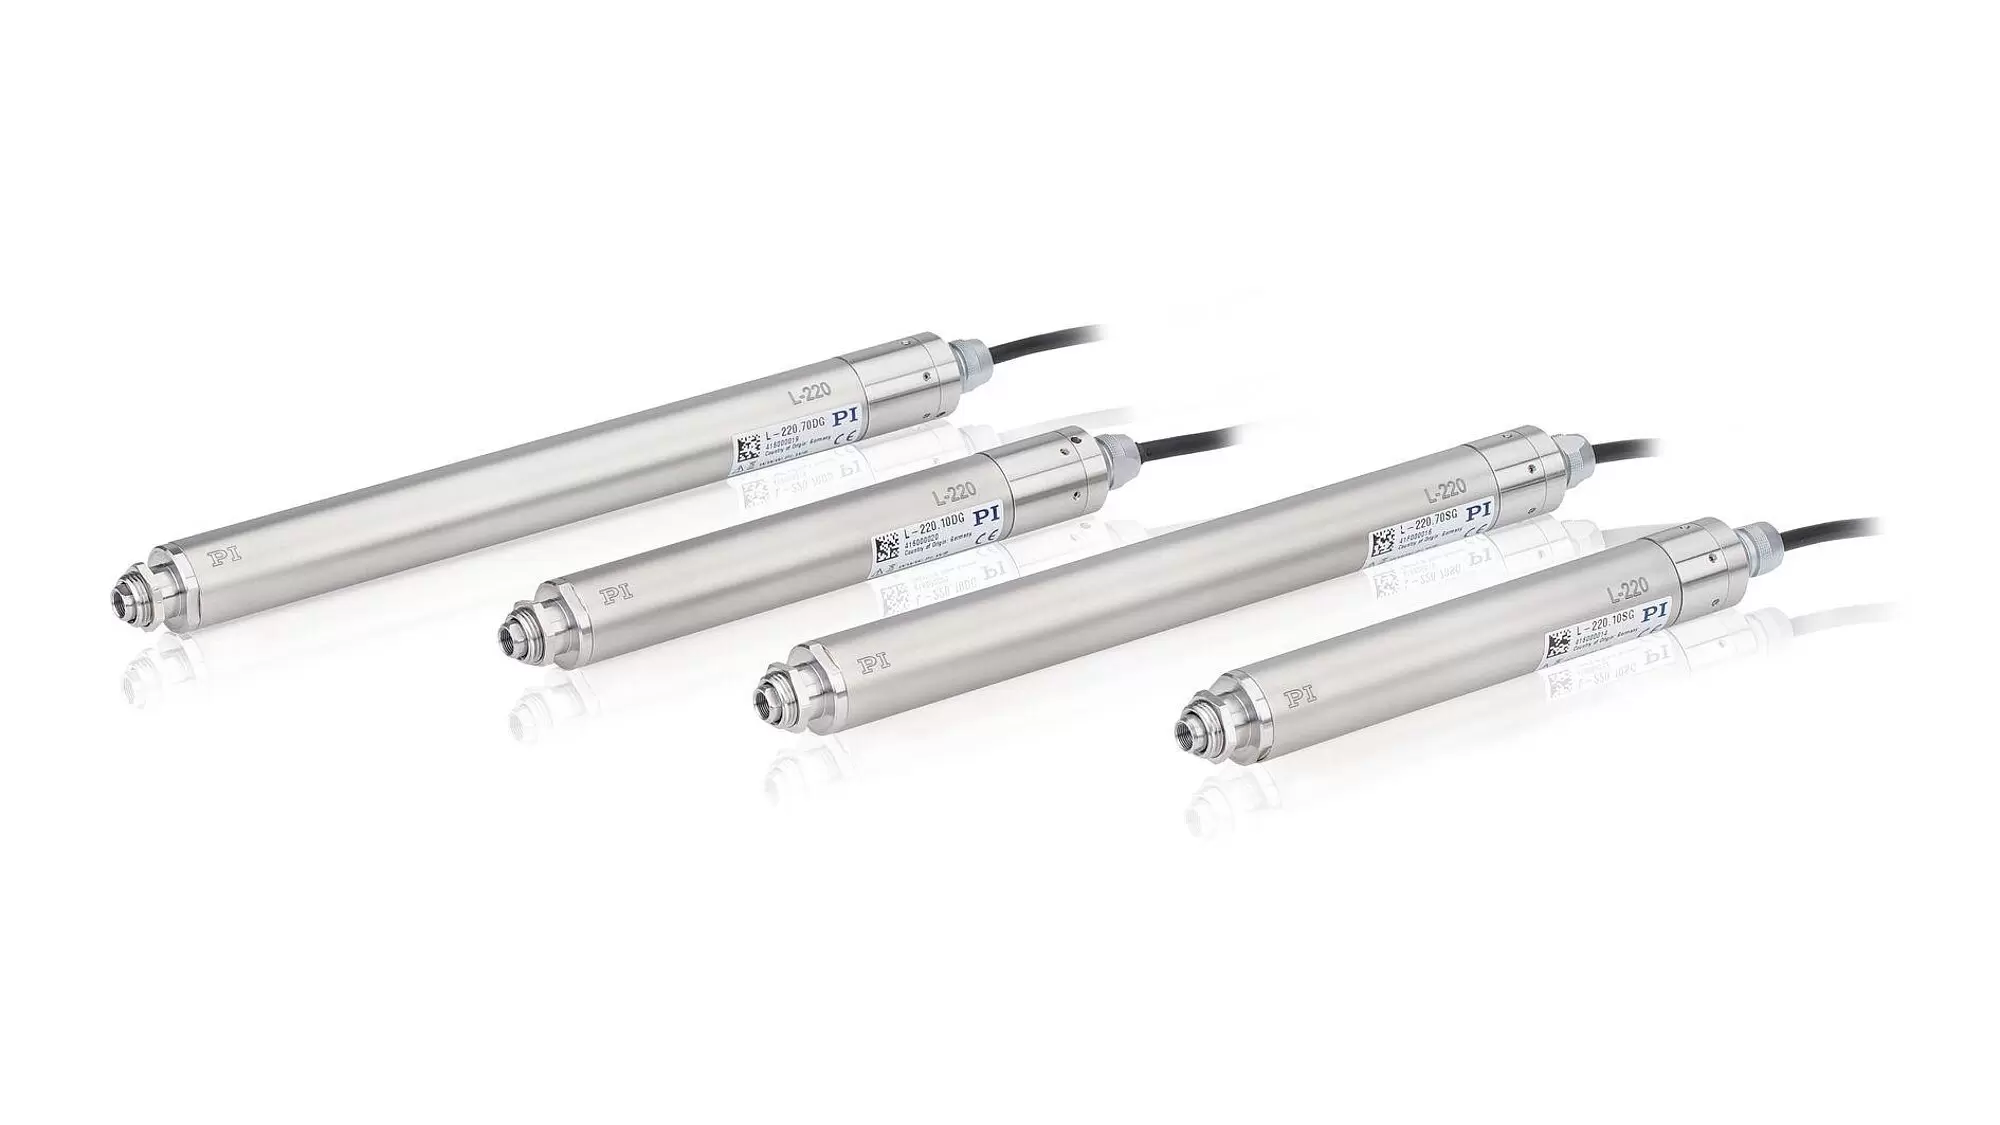
Combines high precision, high forces, and high dynamics. Versions available for vacuum environments to 10-9 hPa.
Ball screw for smooth feed. Nonrotating tip for uniform motion prevents wobble, torque, and wear at the point of contact. Incl. flat and spherical tip for decoupling forces. Noncontact limit switches protect the mechanics. A direction-sensing reference switch supports automation applications. Position-controlled variants with differential encoder driver in the connector for safe signal transfer over distances up to 10 m.
Research. Automation. Optical alignment.
| Motion | L-220.10DG | L-220.20DG | L-220.50DG | L-220.70DG | L-220.10SG | L-220.20SG | L-220.50SG | L-220.70SG | Tolerance |
|---|---|---|---|---|---|---|---|---|---|
| Active axes | X | X | X | X | X | X | X | X | |
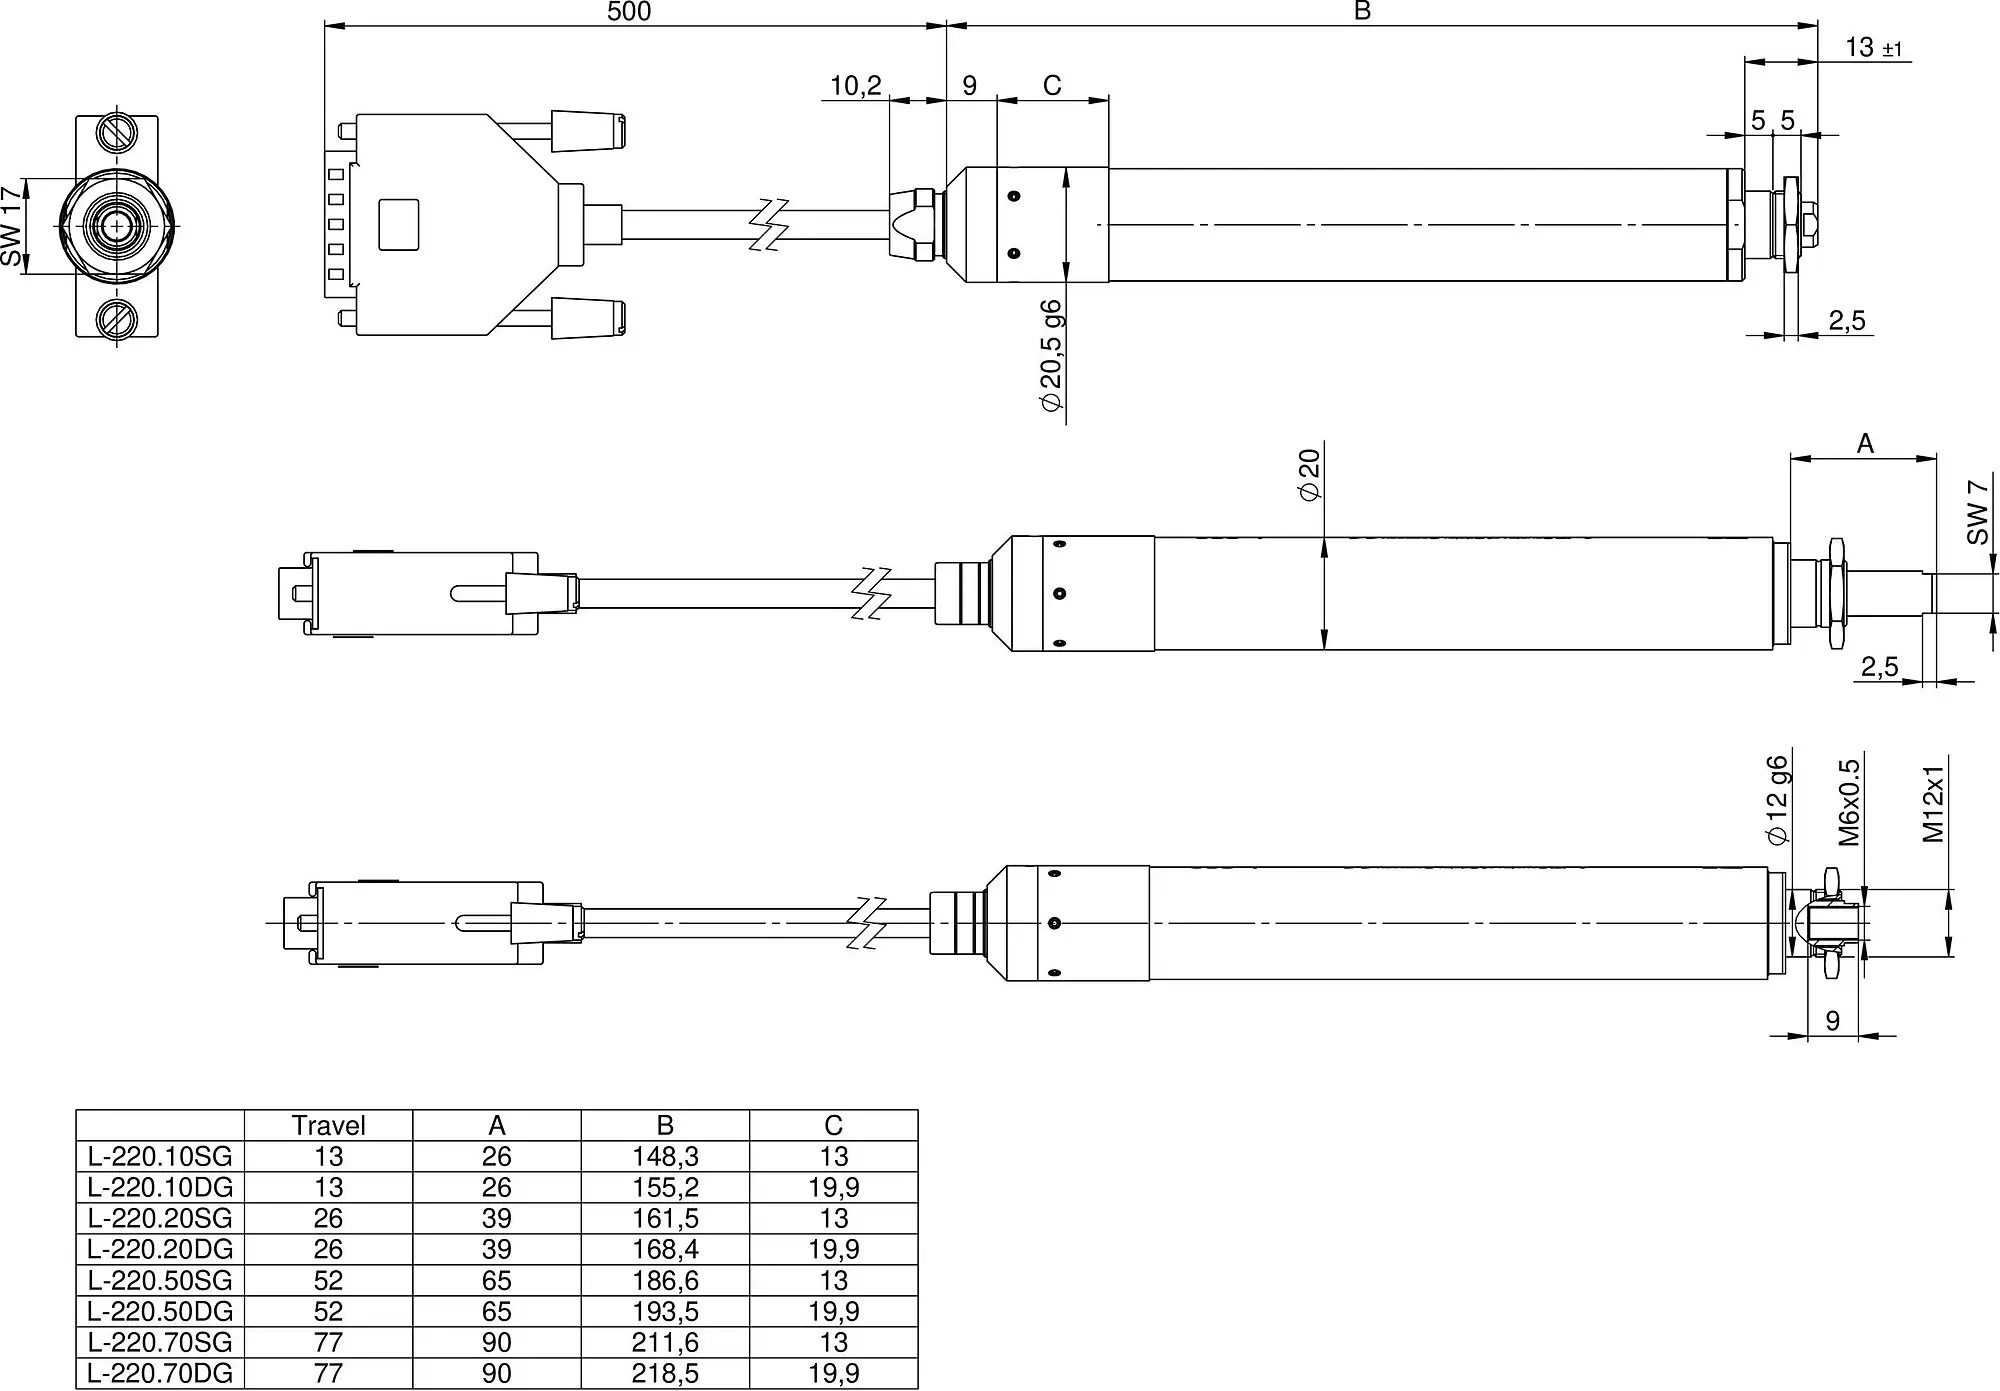
| Travel range in X | 13 mm | 26 mm | 52 mm | 77 mm | 13 mm | 26 mm | 52 mm | 77 mm | |
| Maximum velocity in X, unloaded | 3.5 mm/s | 3.5 mm/s | 3.5 mm/s | 3.5 mm/s | 0.8 mm/s | 0.8 mm/s | 0.8 mm/s | 0.8 mm/s | |
| Positioning | L-220.10DG | L-220.20DG | L-220.50DG | L-220.70DG | L-220.10SG | L-220.20SG | L-220.50SG | L-220.70SG | Tolerance |
| Unidirectional repeatability in X | 0.5 µm | 0.5 µm | 0.5 µm | 0.5 µm | 0.5 µm | 0.5 µm | 0.5 µm | 0.5 µm | typ. |
| Bidirectional repeatability in X | ± 1 µm | ± 1 µm | ± 1 µm | ± 1 µm | ± 1 µm | ± 1 µm | ± 1 µm | ± 1 µm | typ. |
| Minimum incremental motion in X | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | 0.1 µm | typ. |
| Reference switch | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | |
| Limit switches | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | Hall effect, N/C contact, 5 V, NPN | |
| Motor encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | Incremental rotary encoder | |||||
| Resolution, motor encoder | 512 Cts./rev. | 512 Cts./rev. | 512 Cts./rev. | 512 Cts./rev. | |||||
| Motor encoder: Sensor signal | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | A/B quadrature, RS-422 | |||||
| Drive Properties | L-220.10DG | L-220.20DG | L-220.50DG | L-220.70DG | L-220.10SG | L-220.20SG | L-220.50SG | L-220.70SG | Tolerance |
| Drive type | DC gear motor | DC gear motor | DC gear motor | DC gear motor | 2-phase stepper motor with gearhead | 2-phase stepper motor with gearhead | 2-phase stepper motor with gearhead | 2-phase stepper motor with gearhead | |
| Maximum power consumption | 4 W | 4 W | 4 W | 4 W | |||||
| Nominal voltage | 12 V | 12 V | 12 V | 12 V | 3.5 V | 3.5 V | 3.5 V | 3.5 V | |
| Nominal current, RMS | 0.28 A | 0.28 A | 0.28 A | 0.28 A | 0.25 A | 0.25 A | 0.25 A | 0.25 A | typ. |
| Peak current, RMS | 0.56 A | 0.56 A | 0.56 A | 0.56 A | typ. | ||||
| Drive force in negative direction of motion in X | 125 N | 125 N | 125 N | 125 N | 125 N | 125 N | 125 N | 125 N | typ. |
| Drive force in positive direction of motion in X | 125 N | 125 N | 125 N | 125 N | 125 N | 125 N | 125 N | 125 N | typ. |
| Torque constant | 0.0115 N·m/A | 0.0115 N·m/A | 0.0115 N·m/A | 0.0115 N·m/A | typ. | ||||
| Resistance phase-phase | 19.8 Ω | 19.8 Ω | 19.8 Ω | 19.8 Ω | 12.5 Ω | 12.5 Ω | 12.5 Ω | 12.5 Ω | typ. |
| Inductance phase-phase | 0.42 mH | 0.42 mH | 0.42 mH | 0.42 mH | 6.3 mH | 6.3 mH | 6.3 mH | 6.3 mH | |
| Back EMF, phase-phase, rotational | 1.21 V/kRPM | 1.21 V/kRPM | 1.21 V/kRPM | 1.21 V/kRPM | 11 V/kRPM | 11 V/kRPM | 11 V/kRPM | 11 V/kRPM | max. |
| Number of pole pairs | 1 | 1 | 1 | 1 | |||||
| Motor resolution | 24 Full steps/rev. | 24 Full steps/rev. | 24 Full steps/rev. | 24 Full steps/rev. | |||||
| Mechanical Properties | L-220.10DG | L-220.20DG | L-220.50DG | L-220.70DG | L-220.10SG | L-220.20SG | L-220.50SG | L-220.70SG | Tolerance |
| Drive screw type | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | Ball screw | |
| Drive screw pitch | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | 1 mm | |
| Gear ratio i | 12493 : 567 | 12493 : 567 | 12493 : 567 | 12493 : 567 | 387283 : 5103 | 387283 : 5103 | 387283 : 5103 | 387283 : 5103 | |
| Moved mass in X, unloaded | 20 g | 20 g | 25 g | 30 g | 20 g | 20 g | 25 g | 30 g | |
| Permissible push force in Y | 1 N | 1 N | 1 N | 1 N | 1 N | 1 N | 1 N | 1 N | max. |
| Overall mass | 210 g | 230 g | 260 g | 290 g | 230 g | 250 g | 280 g | 320 g | |
| Material | Stainless steel, bronze | Stainless steel, bronze | Stainless steel, bronze | Stainless steel, bronze | Stainless steel, bronze | Stainless steel, bronze | Stainless steel, bronze | Stainless steel, bronze | |
| Holding force in X, passive | 125 N | 125 N | 125 N | 125 N | |||||
| Miscellaneous | L-220.10DG | L-220.20DG | L-220.50DG | L-220.70DG | L-220.10SG | L-220.20SG | L-220.50SG | L-220.70SG | Tolerance |
| Operating temperature range | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | 5 to 40 °C | |
| Connector | HD D-sub 26-pin (m) | HD D-sub 26-pin (m) | HD D-sub 26-pin (m) | HD D-sub 26-pin (m) | HD D-sub 26-pin (m) | HD D-sub 26-pin (m) | HD D-sub 26-pin (m) | HD D-sub 26-pin (m) | |
| Cable length | 0.5 m | 0.5 m | 0.5 m | 0.5 m | 0.5 m | 0.5 m | 0.5 m | 0.5 m | |
| Recommended controllers / drivers | C-863 C-885 with C-863.20C885 C-884 ACS modular controller | C-863 C-885 with C-863.20C885 C-884 ACS modular controller | C-863 C-885 with C-863.20C885 C-884 ACS modular controller | C-863 C-885 with C-863.20C885 C-884 ACS modular controller | C-663.12 C-885 with C-663.12C885 ACS modular controller | C-663.12 C-885 with C-663.12C885 ACS modular controller | C-663.12 C-885 with C-663.12C885 ACS modular controller | C-663.12 C-885 with C-663.12C885 ACS modular controller |